3D inverse dynamics in non-orthonormal segment coordinate system
Related Experiment Video
Updated: Jul 17, 2026
Four-Dimensional CT Analysis Using Sequential 3D-3D Registration
Published on: November 23, 2019
1Laboratoire de Biomécanique et Modélisation Humaine, Université de Lyon 1, Bâtiment Omega, Boulevard du 11 Novembre 1918, Villeurbanne 69622, France. raphael.dumas@univ-lyon1.fr

Abstract:
The net joint forces and moments may be computed by several 3D inverse dynamic methods. To do so, an orthonormal segment coordinate system (SCS) is generally mandatory. However, the segment axes ought to be selected following anatomical, functional, and inertial requirements that are hardly compatible with orthogonal axes. An alternative method based on generalized coordinates allows computing inverse dynamics using directly a set of basic points and unitary vectors. A segment definition is put forward in order to follow all of the anatomical, functional, and inertial requirements and the inverse dynamics is performed in a non orthonormal segment coordinate system (NSCS). The NSCS seems a convenient definition in biomechanics as far as anatomical, functional and inertial axes are concerned, but providing that the 3D joint forces and moments are still computable. The inverse dynamic method in NSCS is applied to the gait of a knee valgus subject and compared to a classical inverse dynamic method. The inverse dynamic method in NSCS shows comparable results but implies further clinical interpretations.
More Related Videos
Related Concept Videos
 01:27
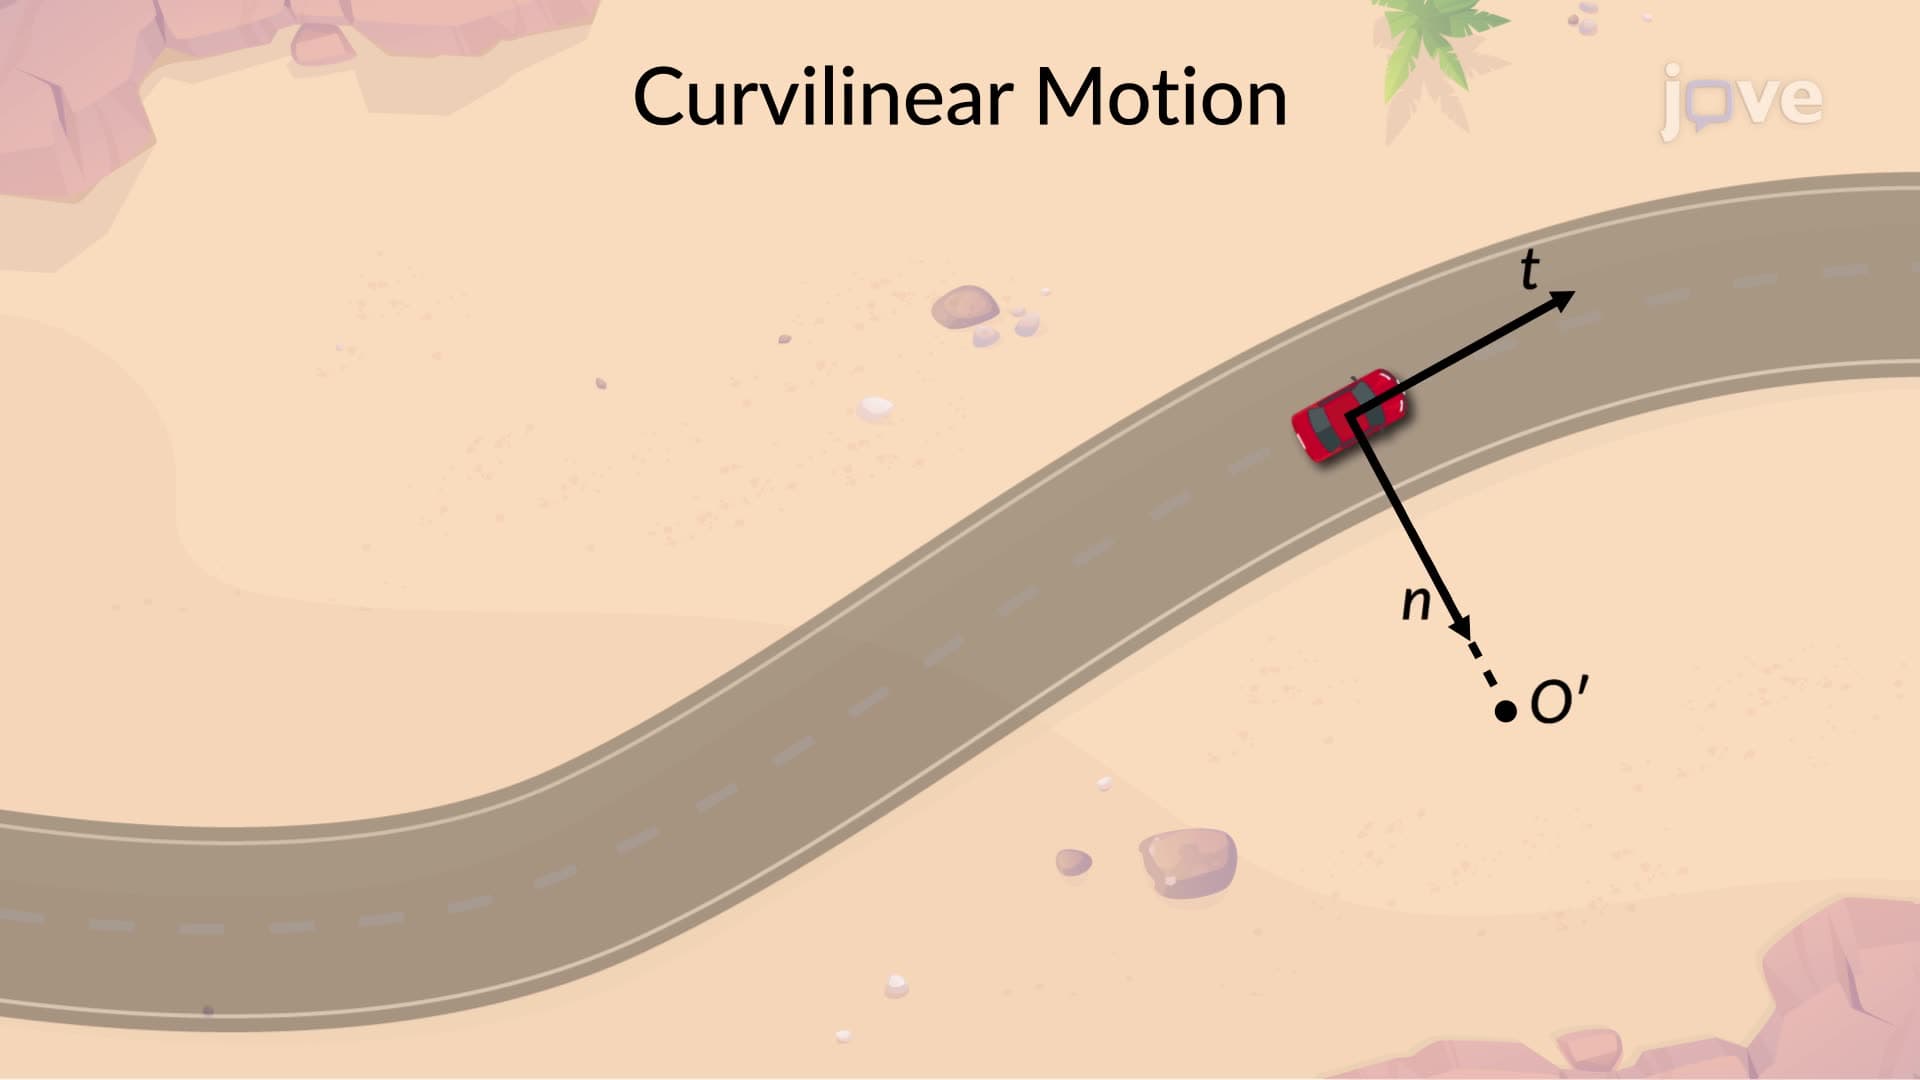
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:20
Divergence Theorem in 3D Space
 01:27
Tangential and Normal Components of Acceleration
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:27
Curvilinear Motion: Polar Coordinates
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position with respect to time...