Related Experiment Video
Updated: Jul 17, 2026


Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
Motor equivalent control of the center of mass in response to support surface perturbations
J P Scholz1, G Schöner, W L Hsu
1Department of Physical Therapy, University of Delaware, 307 McKinly Laboratory, Newark, DE 19716-2591, USA. jpscholz@udel.edu

Abstract:
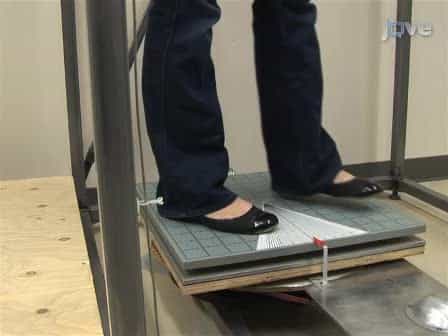
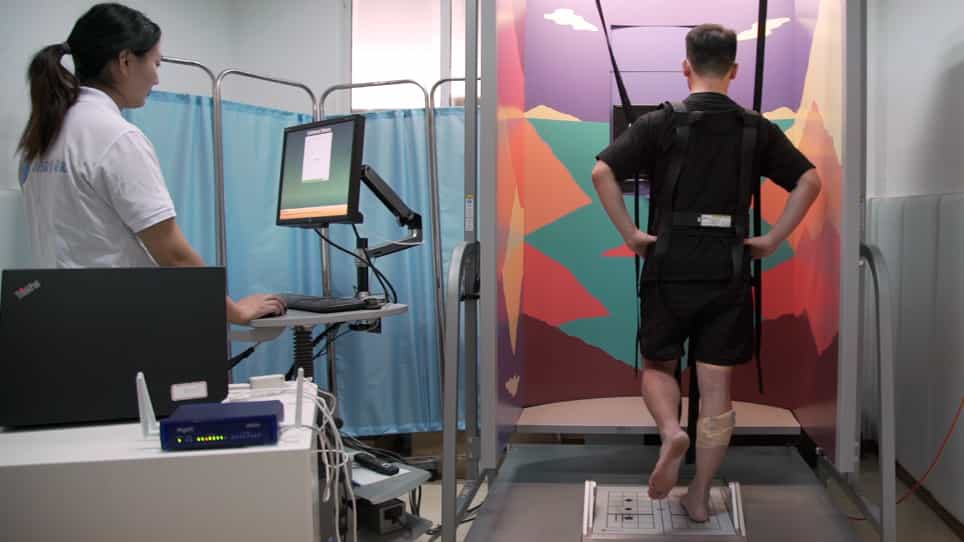
To claim that the center of mass (CM) of the body is a controlled variable of the postural system is difficult to verify experimentally. In this report, a new variant of the method of the uncontrolled manifold (UCM) hypothesis was used to evaluate CM control in response to an abrupt surface perturbation during stance. Subjects stood upright on a support surface that was displaced in the posterior direction. Support surface translations between 0.03 and 0.12 m, each lasting for 275 ms, were presented randomly. The UCM corresponding to all possible combinations of joints that are equivalent with respect to producing the average pre-perturbation anterior-posterior position of the center of mass (CM(AP)) were linearly estimated for each trial. At each point in time thereafter, the difference between the current joint configuration and the average pre-perturbation joint configuration was computed. This joint difference vector was then projected onto the pre-perturbation UCM as a measure of motor equivalence, and onto its complementary subspace, which represents joint combinations that lead to a different CM(AP) position. A similar analysis was performed related to control of the trunk's spatial orientation. The extent to which the joint velocity vector acted to stabilize the CM(AP) position was also examined. Excursions of the hip and ankle joints both increased linearly with perturbation magnitude. The configuration of joints at each instance during the perturbation differed from the mean configuration prior to the perturbation, as evidenced by the joint difference vector. Most of this joint difference vector was consistent, however, with the average pre-perturbation CM(AP) position rather than leading to a different CM(AP )position. This was not the case, however, when performing this analysis with respect to the UCM corresponding to the control of the pre-perturbation trunk orientation. The projection of the instantaneous joint velocity vector also was found to lie primarily in the UCM corresponding to the pre-perturbation CM(AP) position, indicating that joint motion was damped in directions leading to a change away from the pre-perturbation CM(AP) position. These results provide quantitative support for the argument that the CM position is a planned variable of the postural system and that its control is achieved through selective, motor equivalent changes in the joint configuration in response to support surface perturbations. The results suggest that the nervous system accomplishes postural control by a control strategy that considers all DOFs. This strategy presumably resists combinations of DOFs that affect the stability of important task-relevant variables (CM(AP) position) while, to a large extent, freeing from control combinations of those DOFs that have no effect on the task-relevant variables (Schöner in Ecol Psychol 8:291-314, 1995).
Related Concept Videos
 01:14
Equation of Motion: Center of Mass
Internal forces between any pair of particles manifest as collinear pairs of equal magnitude but opposite directions,...
 01:12
Equation of Motion for a Rigid Body
The combined moments generated about the center of mass of the object are equal to the rate of change of the angular momentum of the body. An external force, when applied at a different point...
 01:03
Center of Mass: Introduction
 01:22
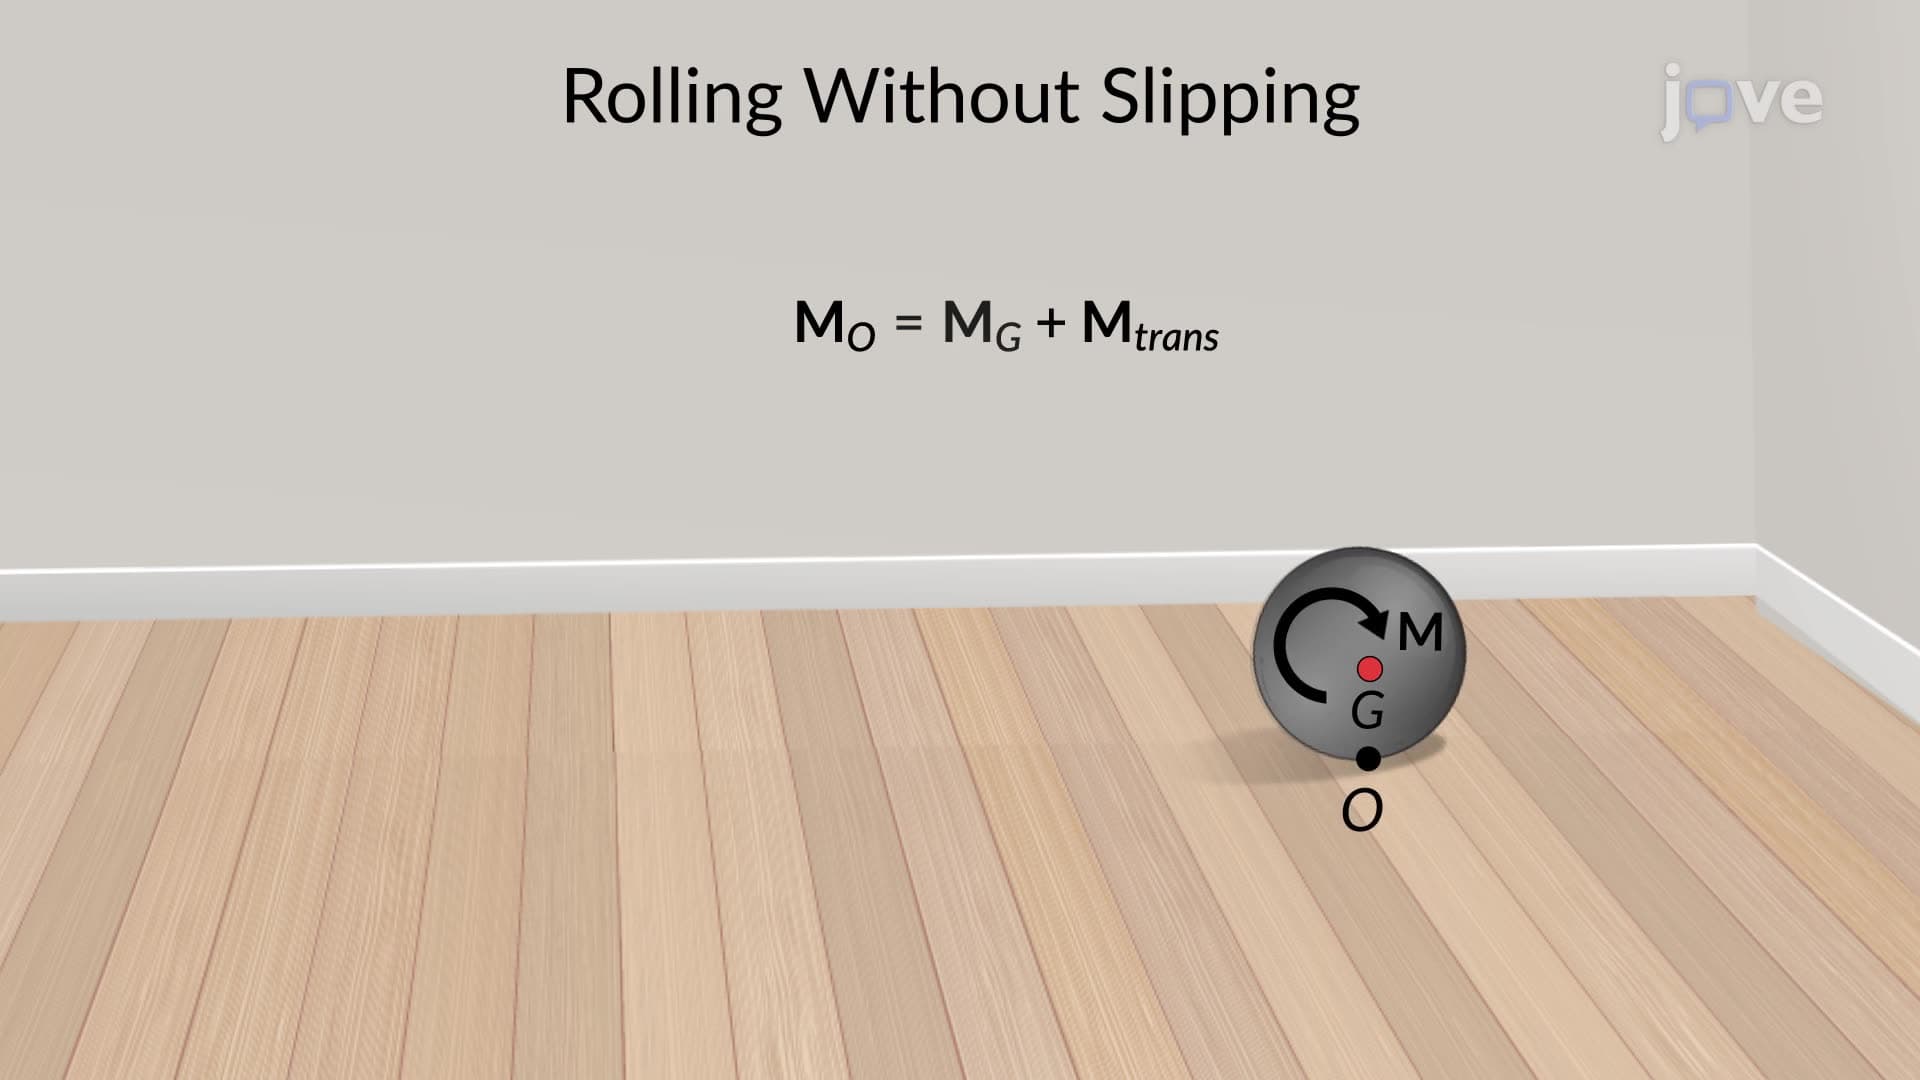
Equation of Motion: General Plane motion
Moreover, the body's center of mass experiences a rotational effect as a result of these couple moments. This rotation can be articulated as the product of the...
 01:27
Support Reactions in Three Dimensions
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...
 00:59
Center of Mass
The knowledge of the center of mass can also help us to describe and predict the motion of objects. For example, when a ball is thrown into...