Related Experiment Video
Updated: Jul 16, 2026

Postural Organization of Gait Initiation for Biomechanical Analysis Using Force Platform Recordings
Published on: July 26, 2022
Stability of an underactuated bipedal gait
S Mukherjee1, V Sangwan, A Taneja
1Department of Mechanical Engineering, Indian Institute of Technology, Hauz Khas, New Delhi 110016, India. sudipto@mech.iitd.ernet.in

Abstract:
A self-excited biped walking mechanism consisting of two legs that are connected in series at the hip joint through a servomotor is studied as a cyclic system with collisions. A torque proportional to angle between the shank of the swinging leg and the vertical is seen to sustain a gait. Each leg has a thigh and a shank connected at a passive knee joint that has a knee stopper restricting hyperextension similar to the human knee. A mathematical model for the dynamics of the system including the impact equations is used to analyse the stability of the system through examination of phase plane plots. Attractor lines along which the system approaches stability have been identified. A leg length for optimal stability has been identified. The biological basis for the proposed system has been identified by comparison with human gait.


Related Concept Videos
 01:28
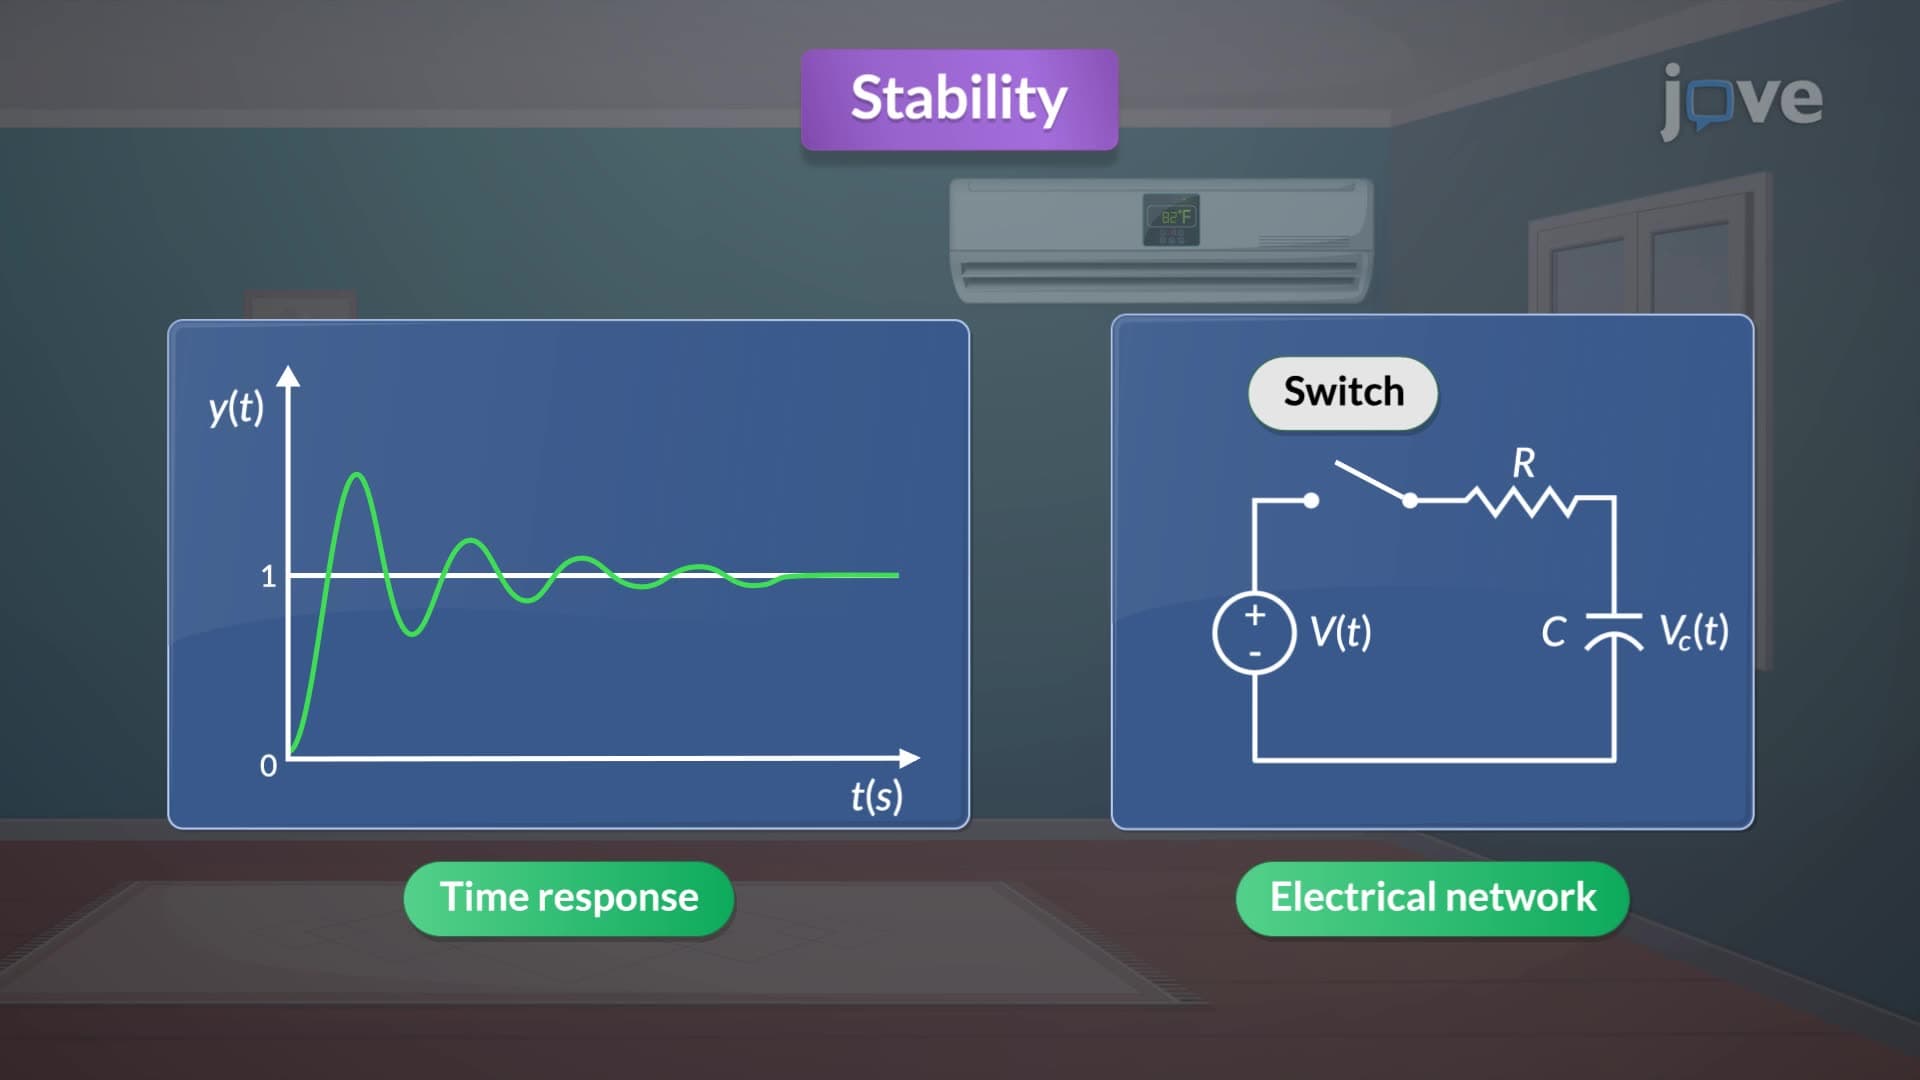
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:23
Stability of Equilibrium Configuration
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
 01:14
Stability of structures
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's response.
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 00:49
Rigid Body Equilibrium Problems - I