Semianalytical transient solution of a delayed differential equation and its application to the tracking motion in

Fumihiko Ishida1, Yasuji E Sawada

  • 1Graduate School of Information Systems, University of Electro-Communications, 1-5-1 Chofu-ga-oka, Chofu, Tokyo 182-8585, Japan. ishida@is.uec.ac.jp

Related Concept Videos

Linear Approximation in Time Domain01:21

Linear Approximation in Time Domain

Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
Second Order systems II01:18

Second Order systems II

In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
If  ζ...
Linear Differential Equations01:27

Linear Differential Equations

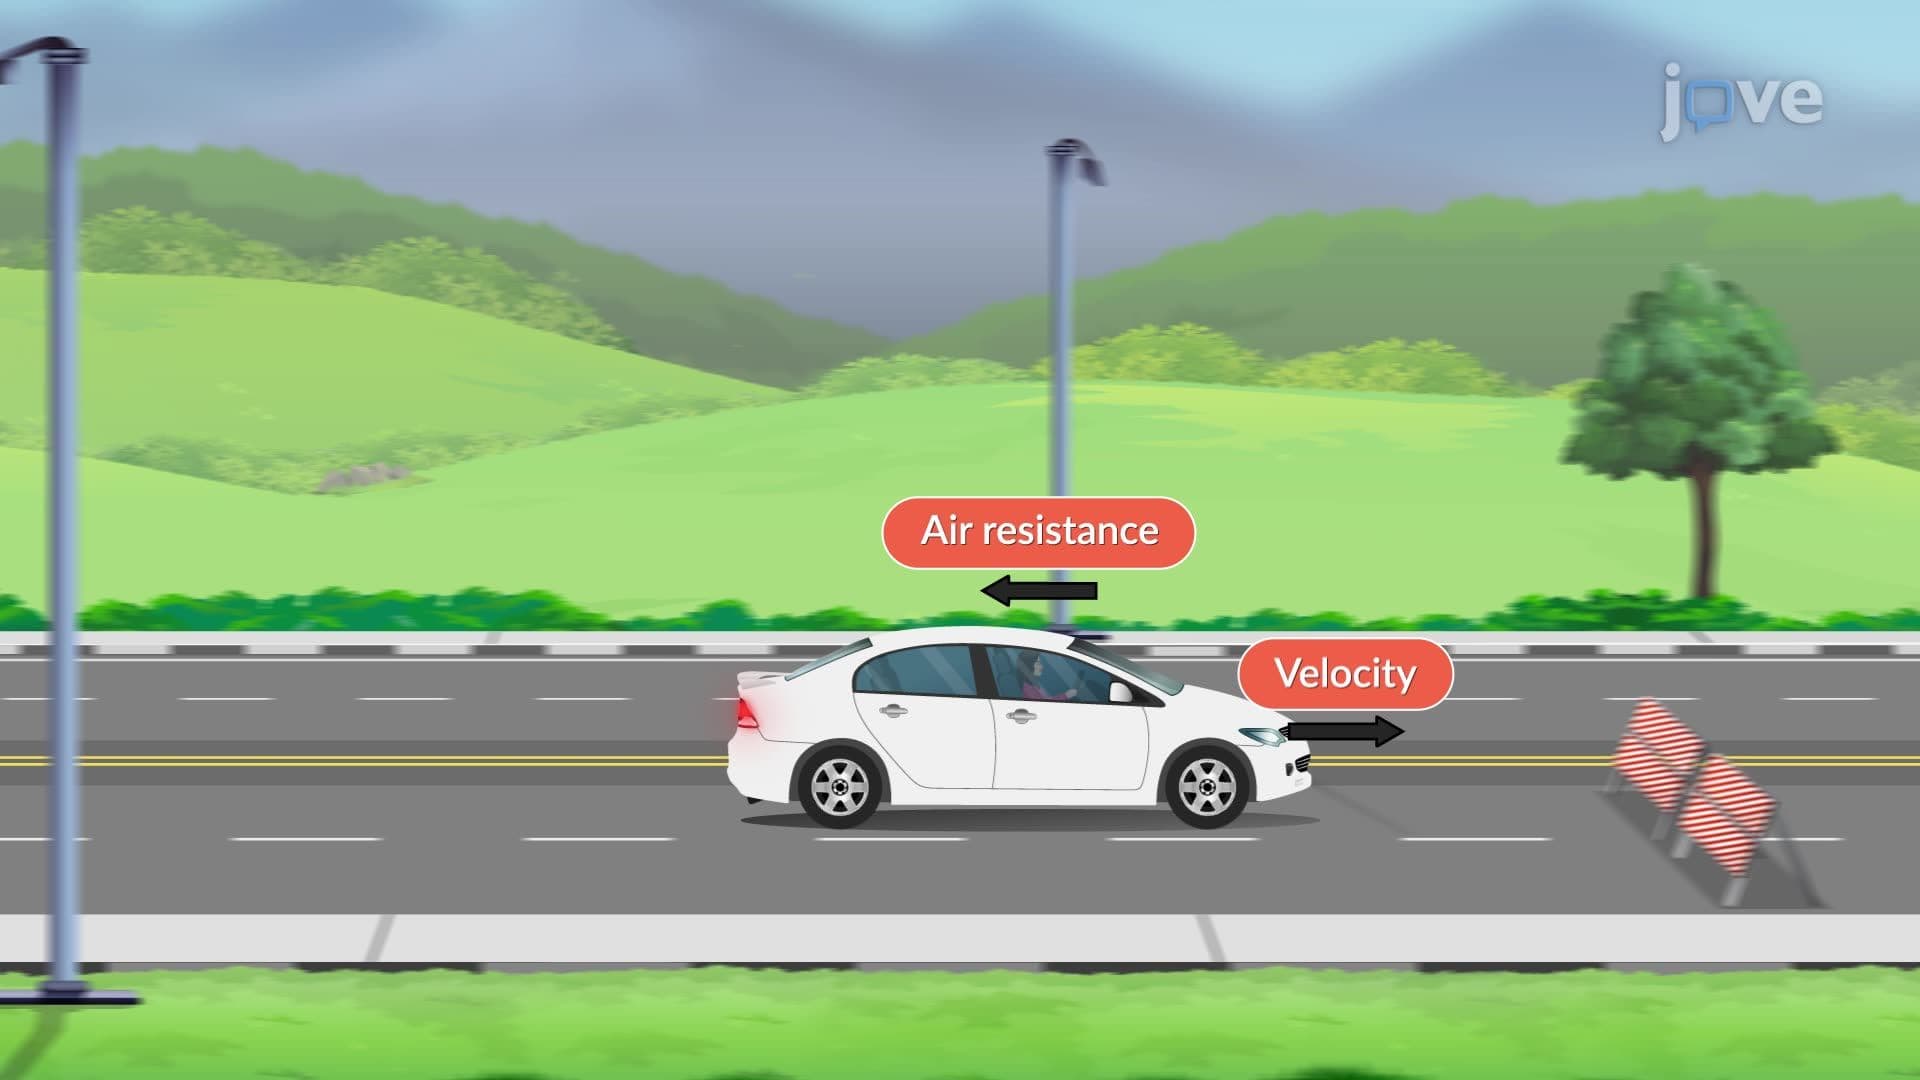
The integrating factor method provides a systematic way to solve first-order linear differential equations, especially those that cannot be handled by separation of variables. This method is particularly useful in modeling time-dependent physical systems influenced by both constant inputs and resistive forces. A common example is the motion of a car subjected to a constant engine force while experiencing air resistance proportional to its velocity.In such scenarios, Newton’s second law yields a...
Relation between Mathematical Equations and Block Diagrams01:20

Relation between Mathematical Equations and Block Diagrams

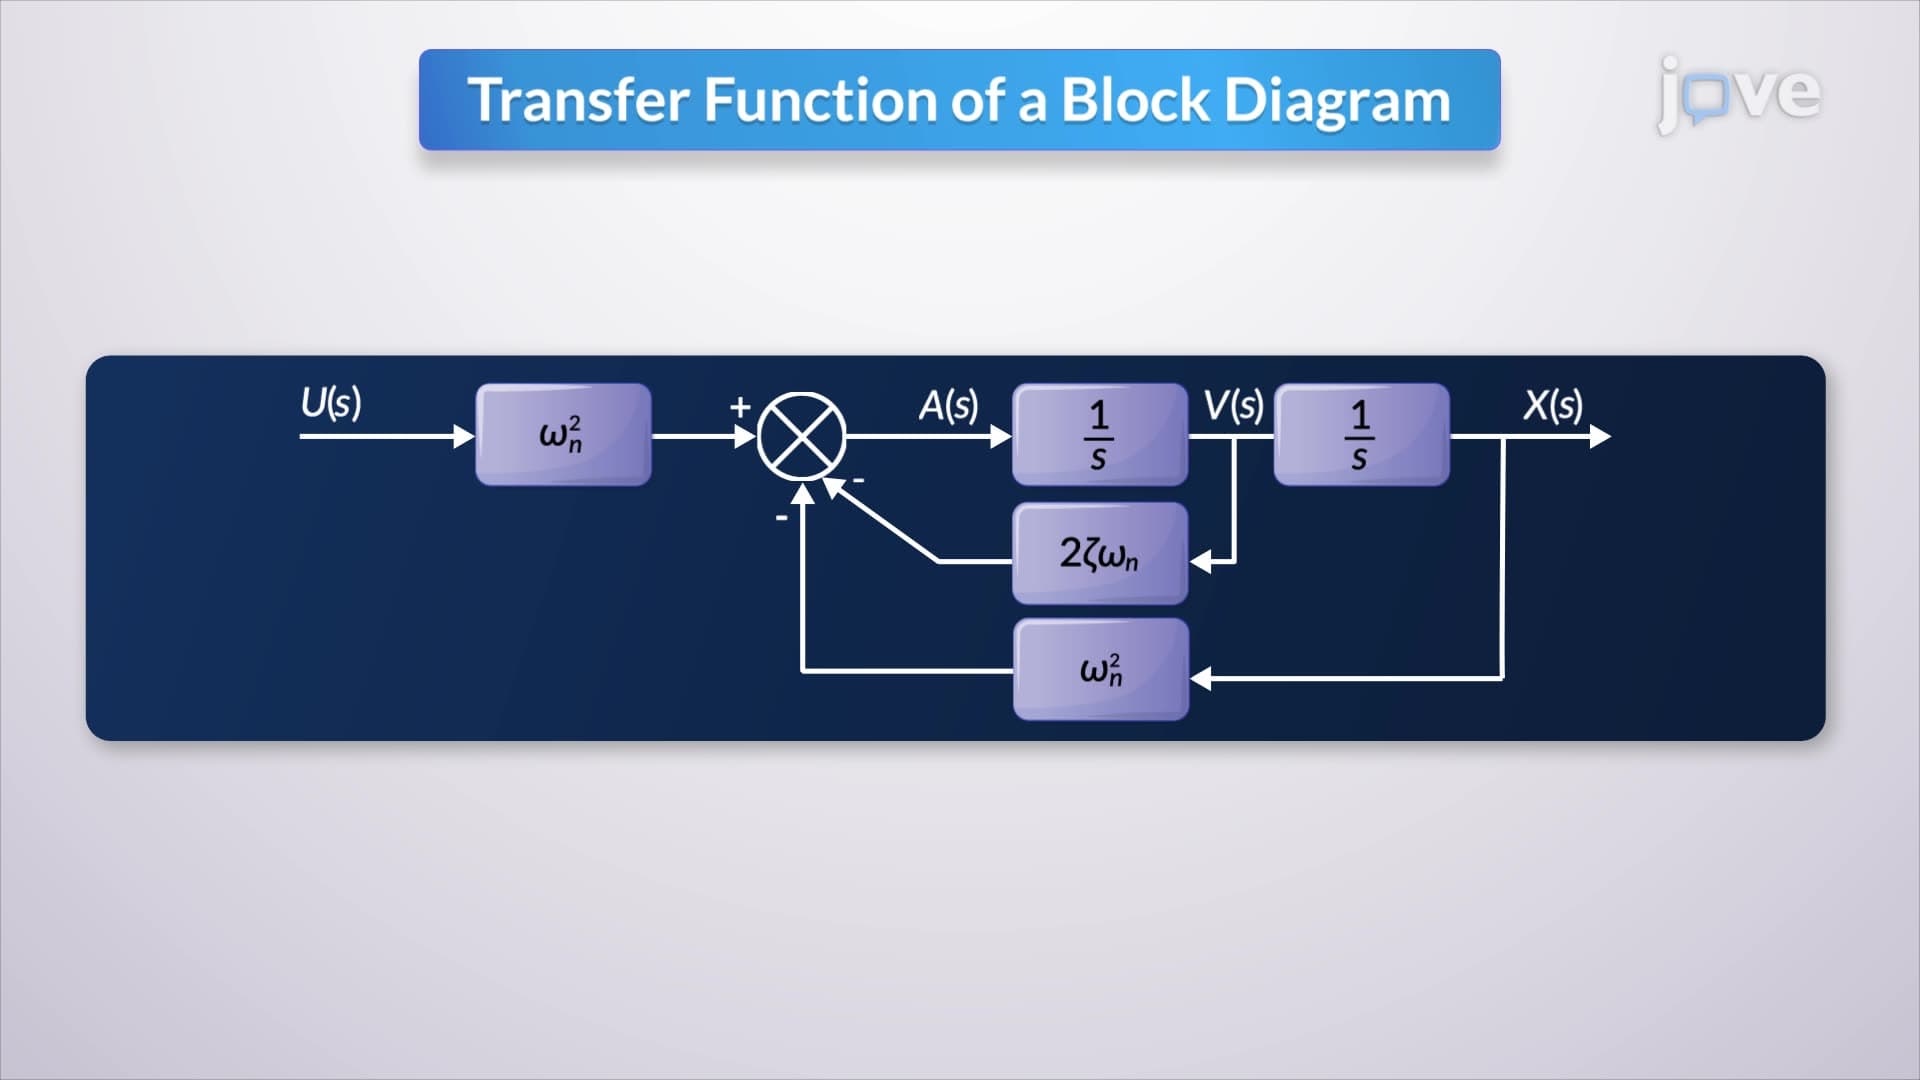
In a spring-mass-damper system, the second-order differential equation describes the dynamic behavior of the system. When transformed into the Laplace domain under zero initial conditions, this equation can be effectively analyzed and manipulated. The transformation into the Laplace domain converts differential equations into algebraic equations, simplifying the process of isolating the output.
Linear Approximation in Frequency Domain01:26

Linear Approximation in Frequency Domain

Linear systems are characterized by two main properties: superposition and homogeneity. Superposition allows the response to multiple inputs to be the sum of the responses to each individual input. Homogeneity ensures that scaling an input by a scalar results in the response being scaled by the same scalar.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
Second Order systems I01:20

Second Order systems I

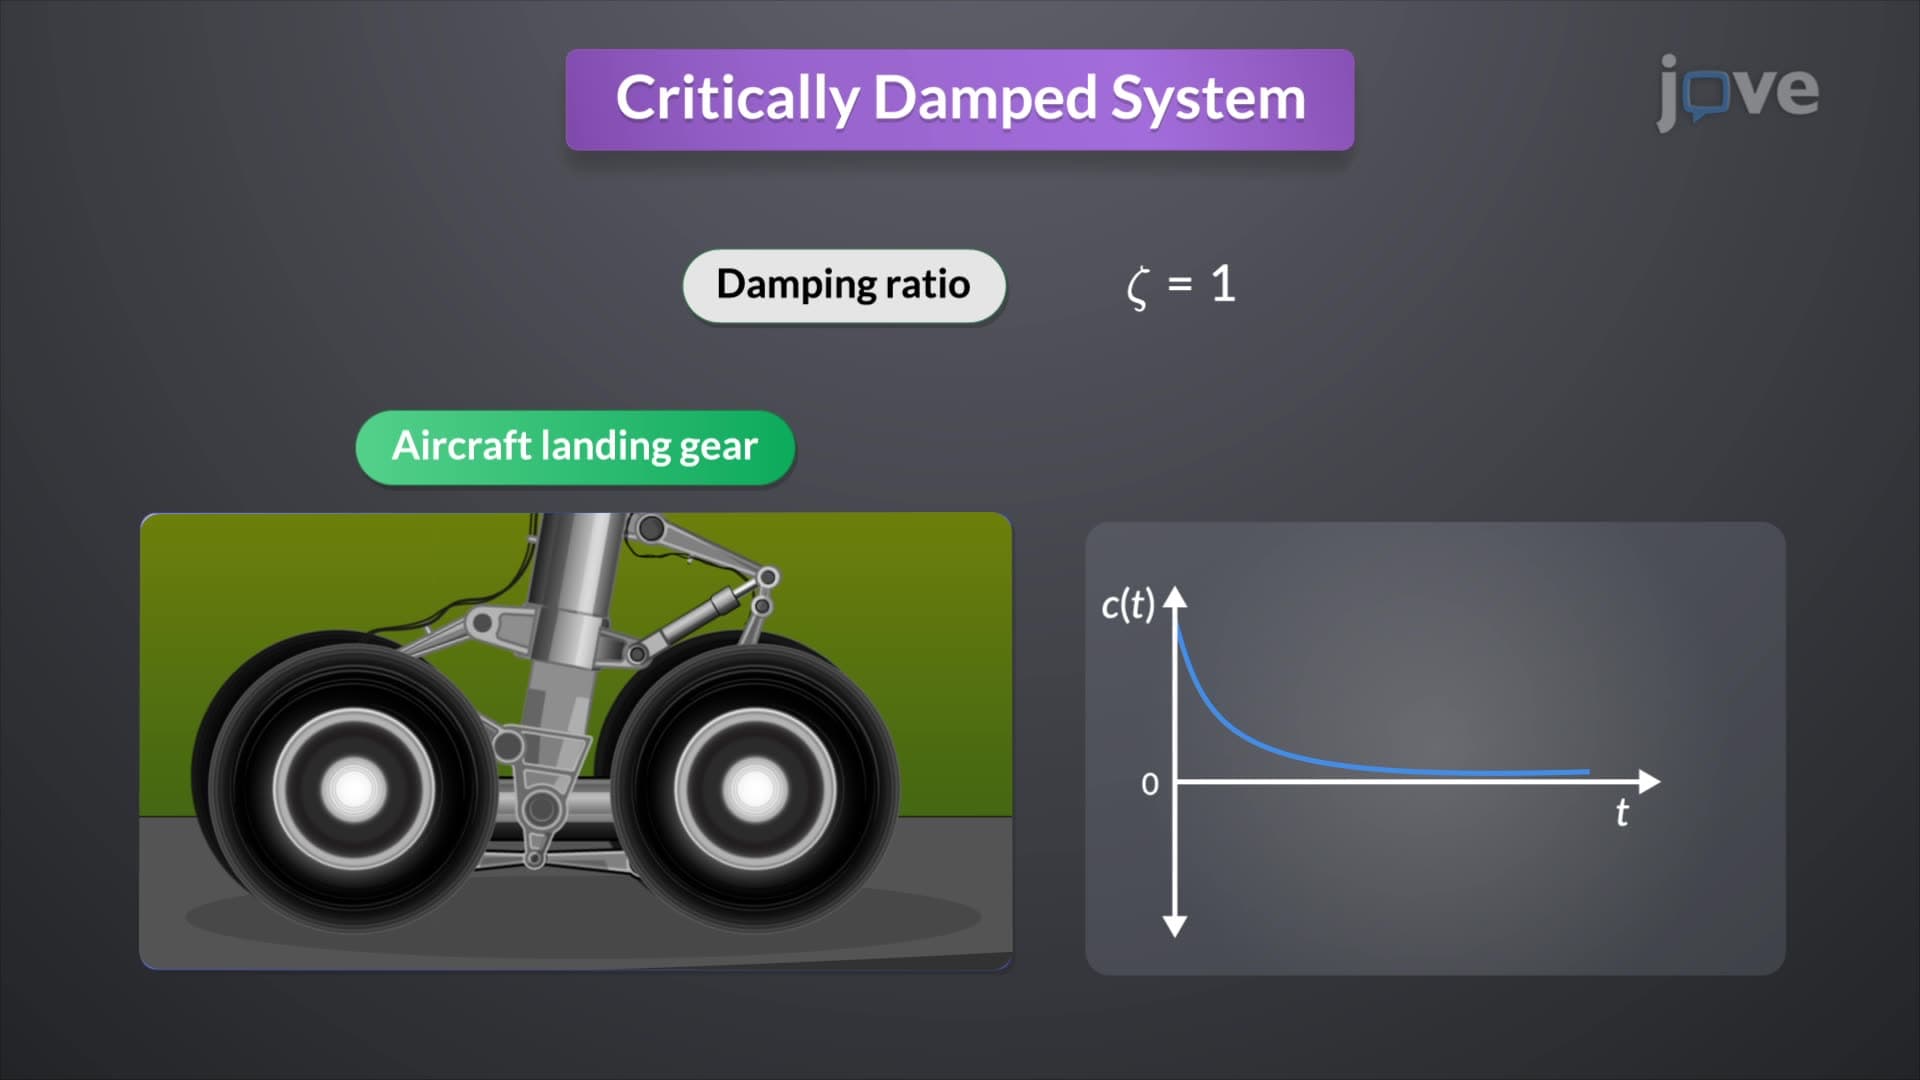
A servo system exemplifies a second-order system, featuring a proportional controller and load elements that ensure the output position aligns with the input position. The relationship between these components is described by a second-order differential equation. Applying the Laplace transform under zero initial conditions yields the transfer function, showing how inputs are converted to outputs in the system.
By reinterpreting the system, one can derive the closed-loop transfer function, which...