A new orientation-adaptive interpolation method

Qing Wang1, Rabab Kreidieh Ward

  • 1Microsoft Corporation, Redmond, WA 98052, USA. qingw@ece.ubc.ca

Related Concept Videos

Reconstruction of Signal using Interpolation01:10

Reconstruction of Signal using Interpolation
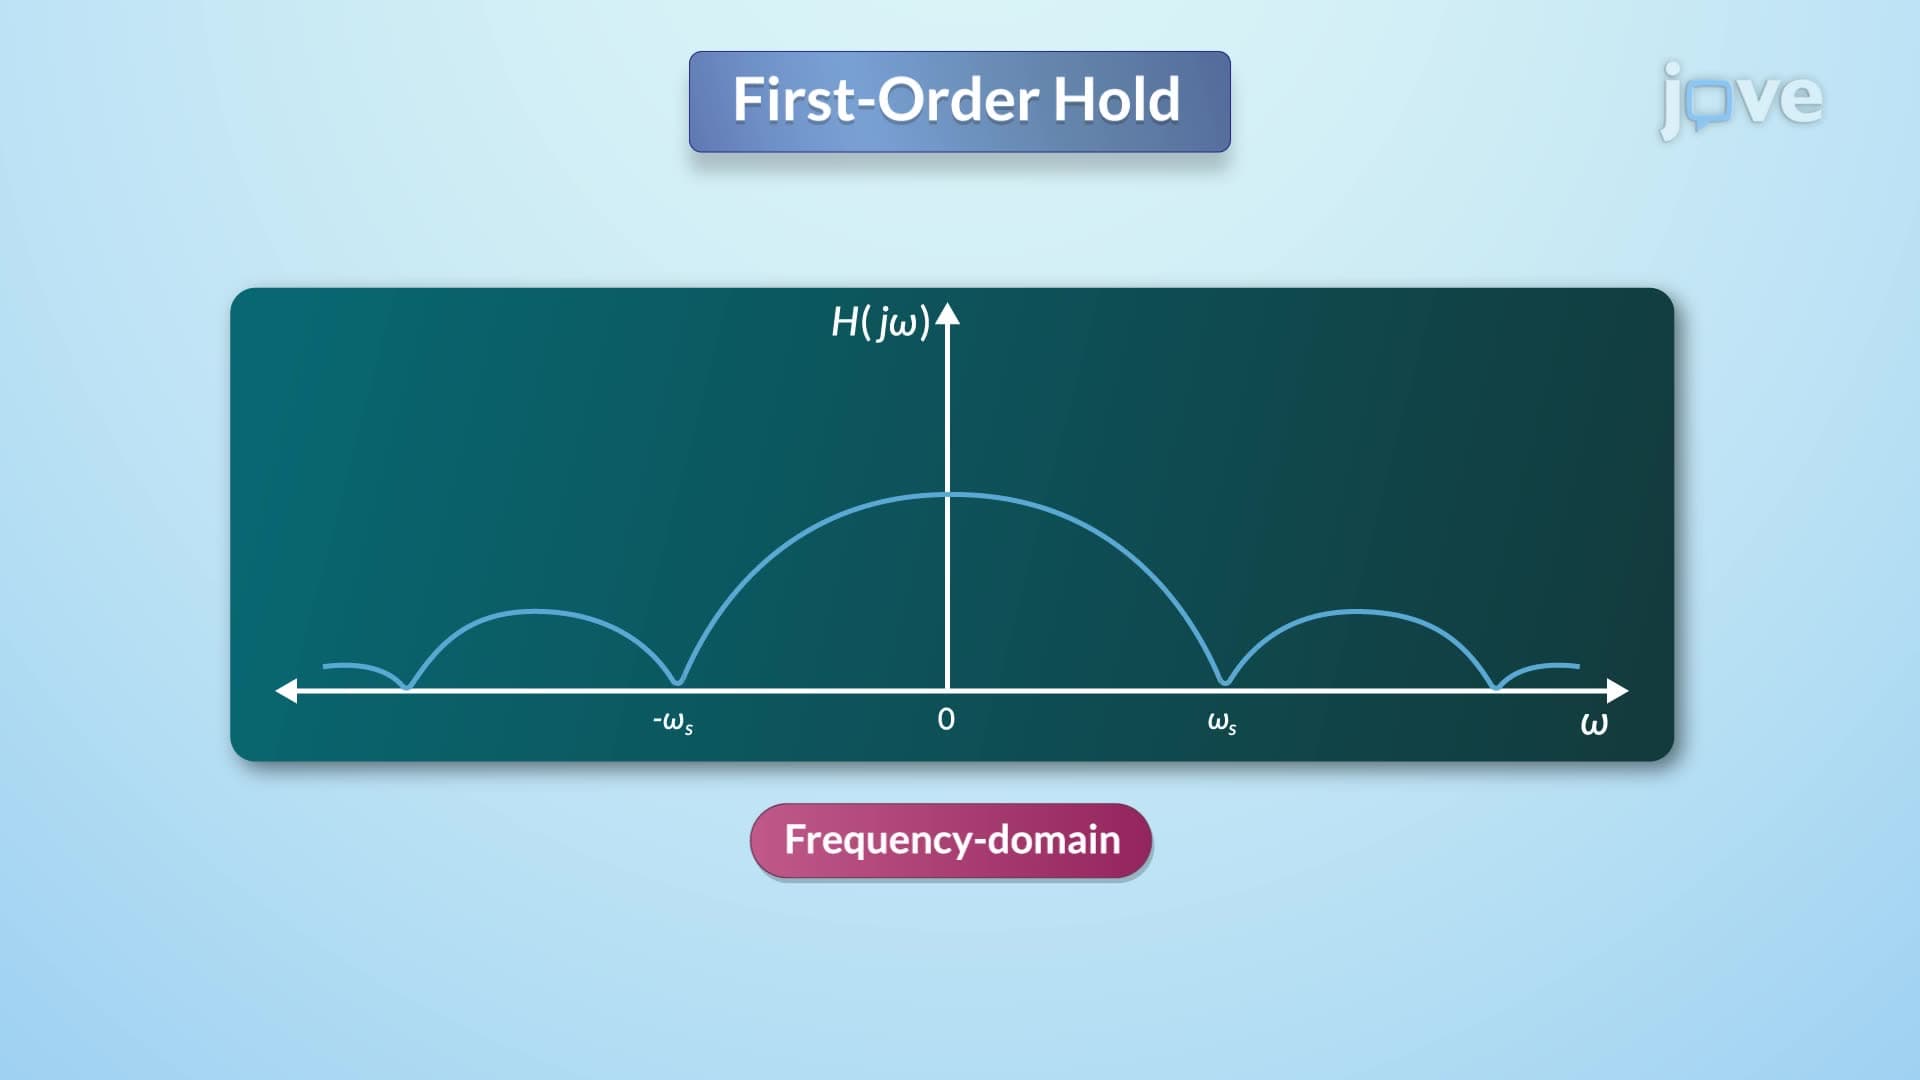
Signal processing techniques are essential for accurately converting continuous signals to digital formats and vice versa. When a continuous signal is sampled with a period T, the resulting sampled signal exhibits replicas of the original spectrum in the frequency domain, spaced at intervals equal to the sampling frequency. To handle this sampled signal, a zero-order hold method can be applied, which creates a piecewise constant signal by retaining each sample's value until the next sampling...
Maximizing the Directional Derivative01:25

Maximizing the Directional Derivative
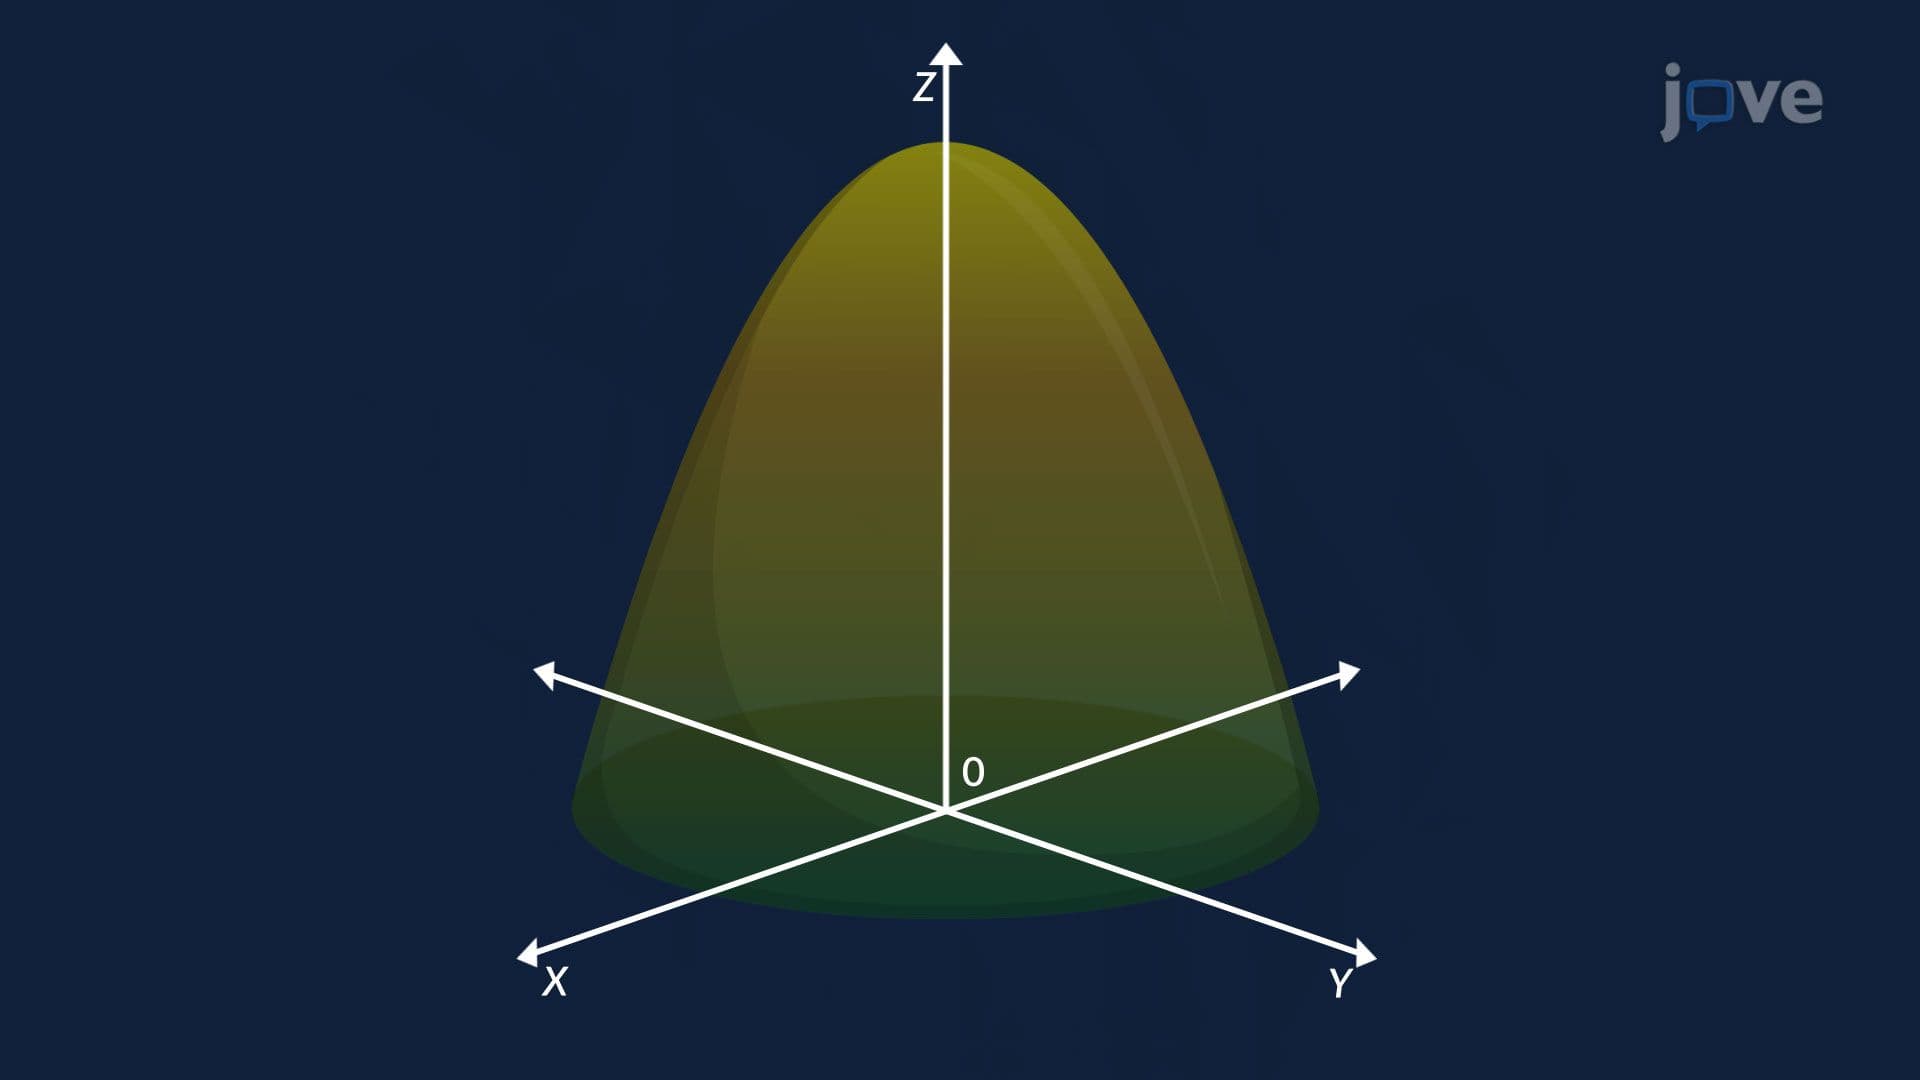
The directional derivative is a central concept in multivariable calculus that describes how a function changes at a given point when moving in a specified direction. This direction is represented by a unit vector, ensuring that only the orientation influences the rate of change. By varying the direction, different rates of change can be observed, demonstrating that the directional derivative depends strongly on the chosen direction.The directional derivative is computed using the gradient...
Rotation with Constant Angular Acceleration - II01:16

Rotation with Constant Angular Acceleration - II

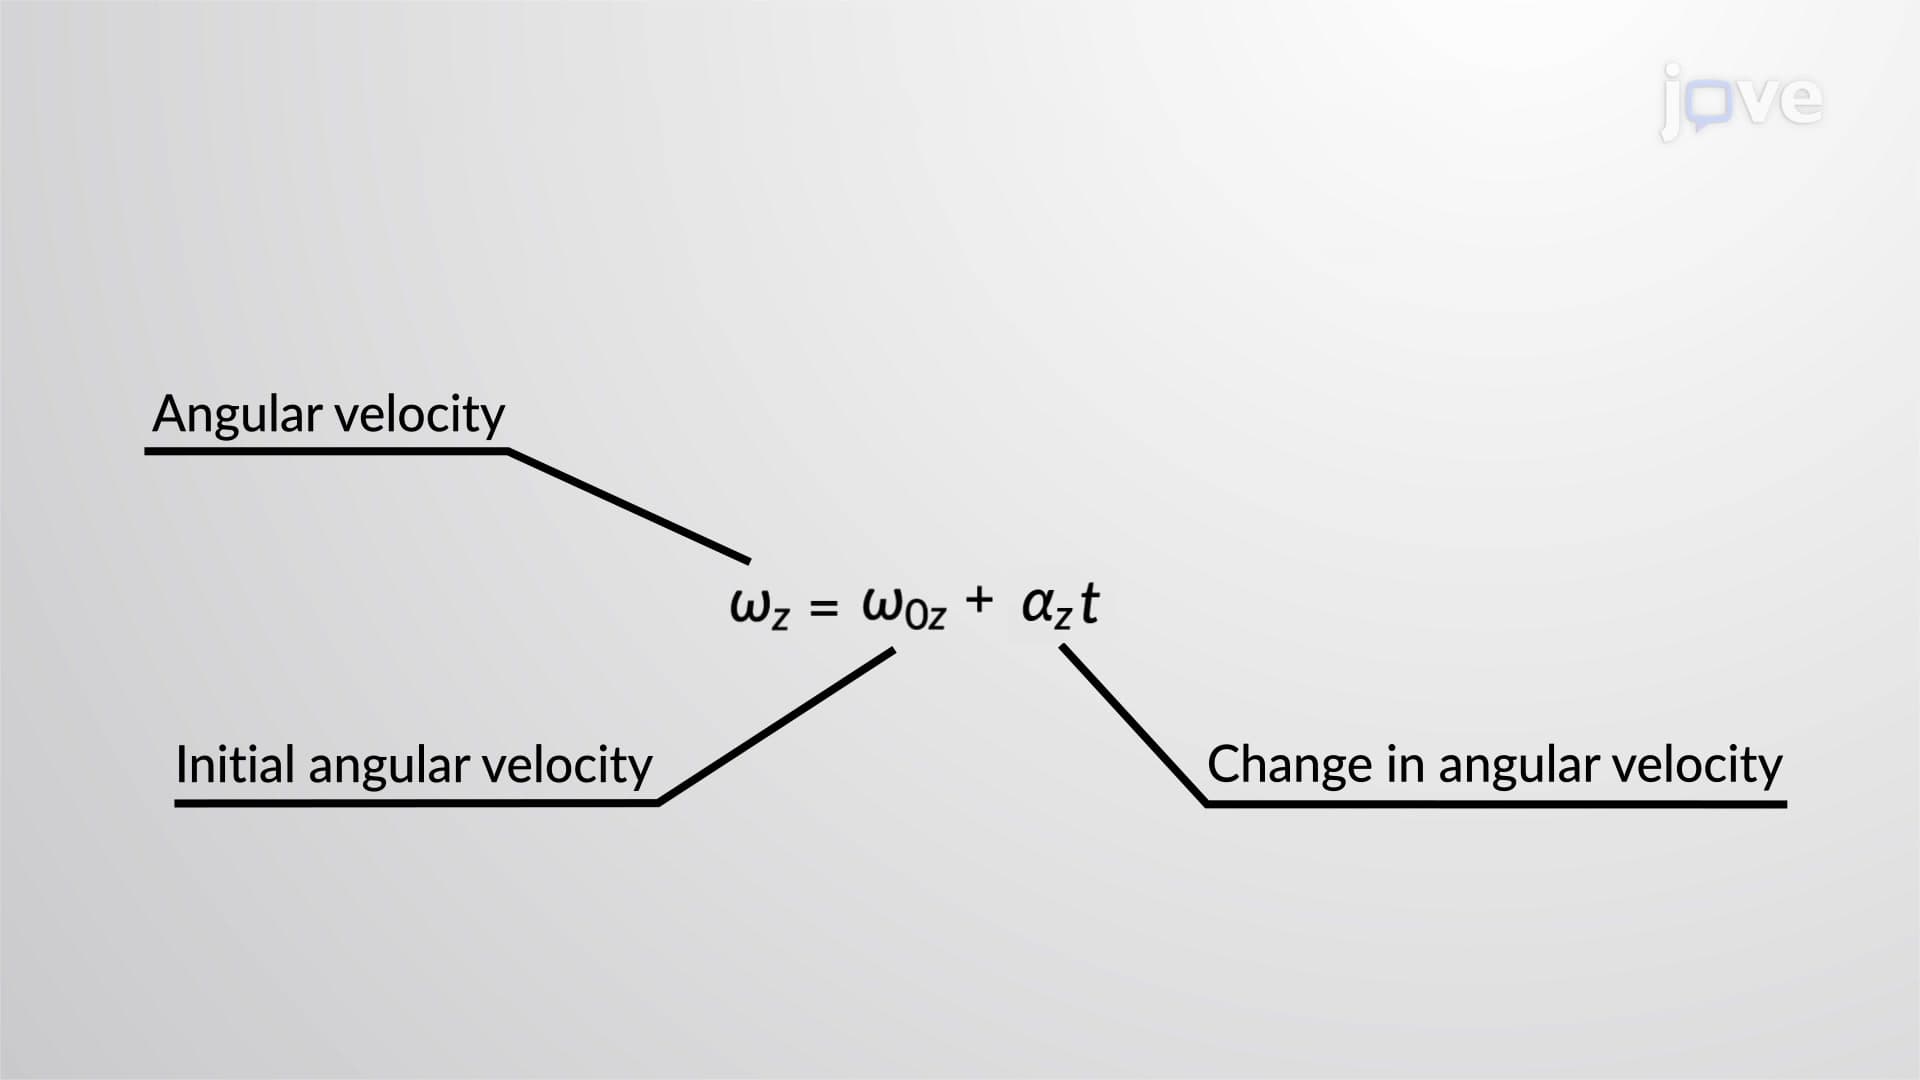
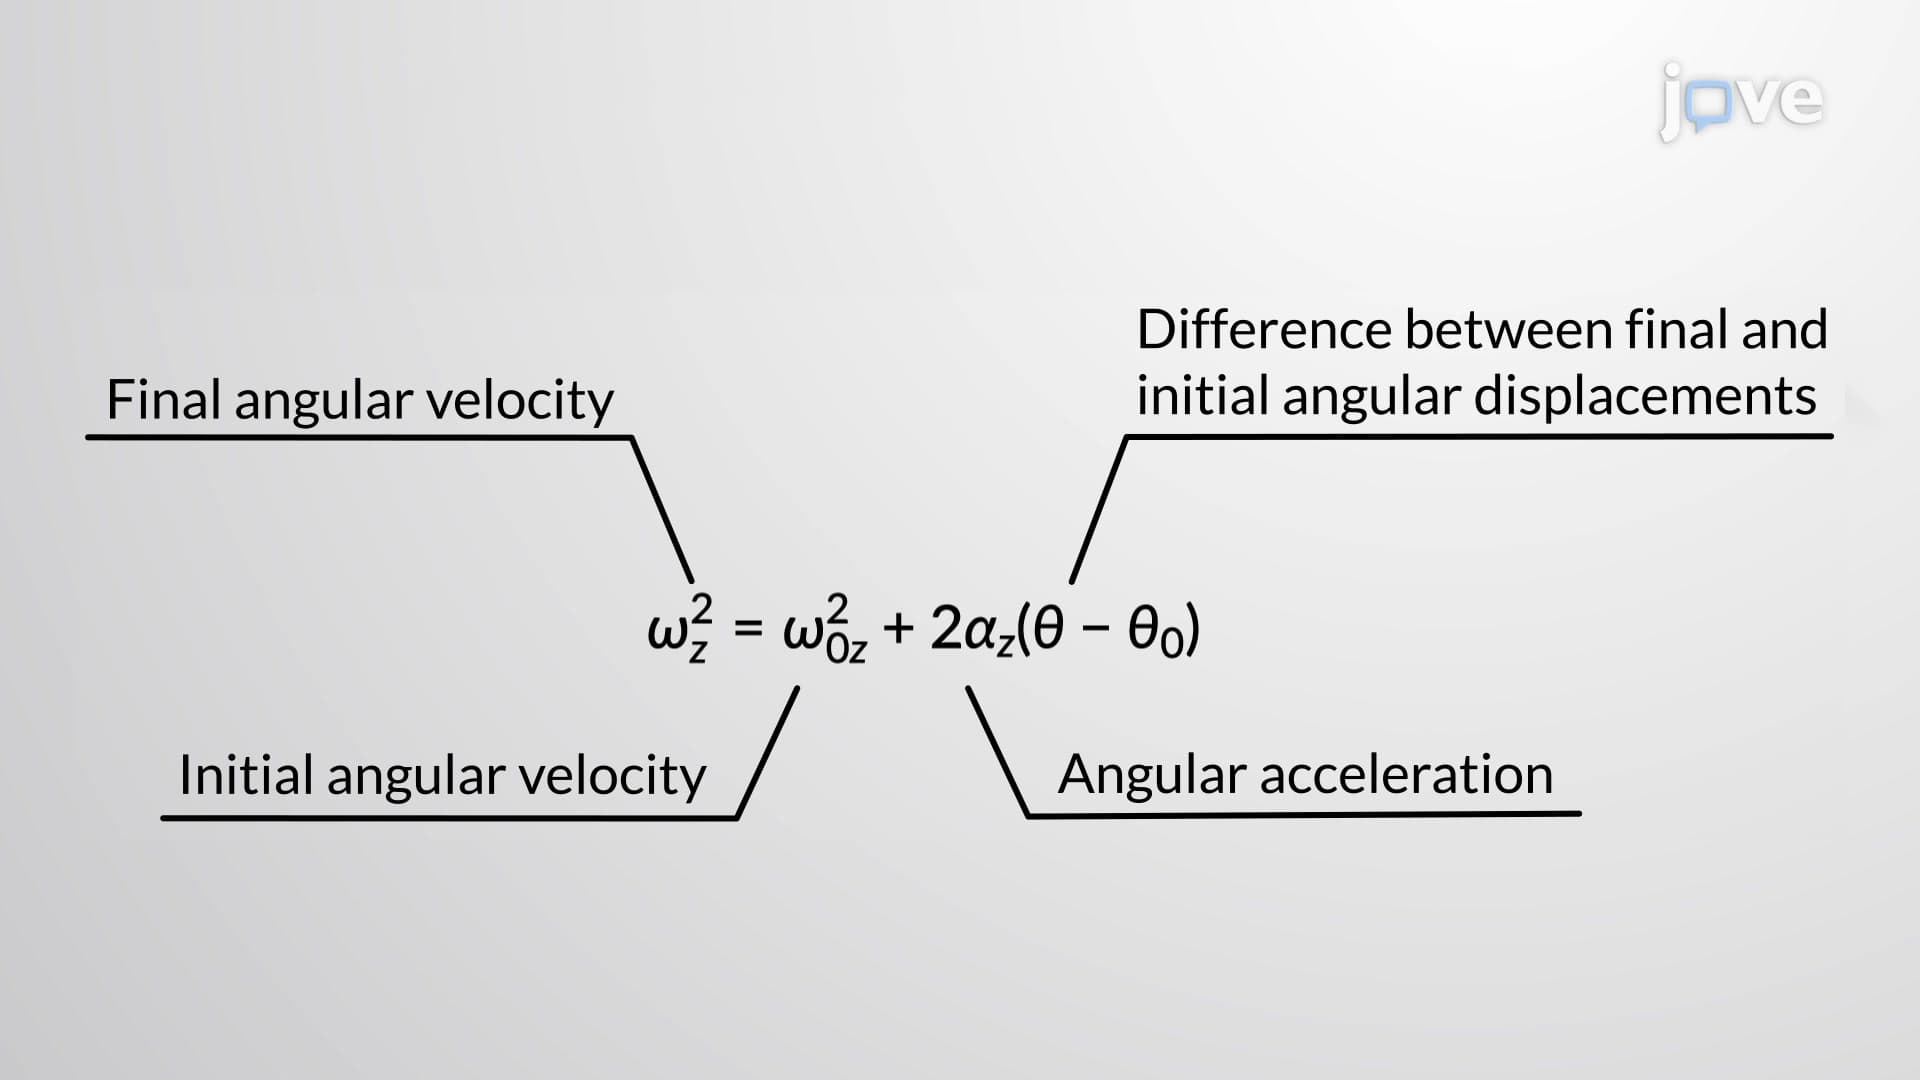
Kinematics is the description of motion. The kinematics of rotational motion discusses the relationships between rotation angle, angular velocity, angular acceleration, and time. One can describe many things with great precision using kinematics, but kinematics does not consider causes. For example, a large angular acceleration describes a very rapid change in angular velocity without any consideration of its cause. Thus, rotational kinematics does not represent the laws of nature.
The first...
Linear Approximations01:23

Linear Approximations

For a differentiable function of two variables, linear approximation estimates values near a known point by replacing the curved surface with its tangent plane. Consider the function\begin{equation*}f(x,y)=x^2+3y^2\end{equation*}near the point (2, 1). The exact value at this point is f(2, 1) = 22 + 3(1)2 = 4 + 3 = 7.The linear approximation of f(x, y)) near (a, b) is\begin{equation*}L(x,y)=f(a,b)+f_x(a,b)(x-a)+f_y(a,b)(y-b)\end{equation*}First, compute the partial derivatives: fx(x, y) = 2x and...
Rotation with Constant Angular Acceleration - I01:37

Rotation with Constant Angular Acceleration - I

If angular acceleration is constant, then we can simplify equations of rotational kinematics, similar to the equations of linear kinematics. This simplified set of equations can be used to describe many applications in physics and engineering where the angular acceleration of a system is constant.
Using our intuition, we can begin to see how rotational quantities such as angular displacement, angular velocity, angular acceleration, and time are related to one another. For example, if a flywheel...
Design Example: Traverse Angle Computations01:25

Design Example: Traverse Angle Computations

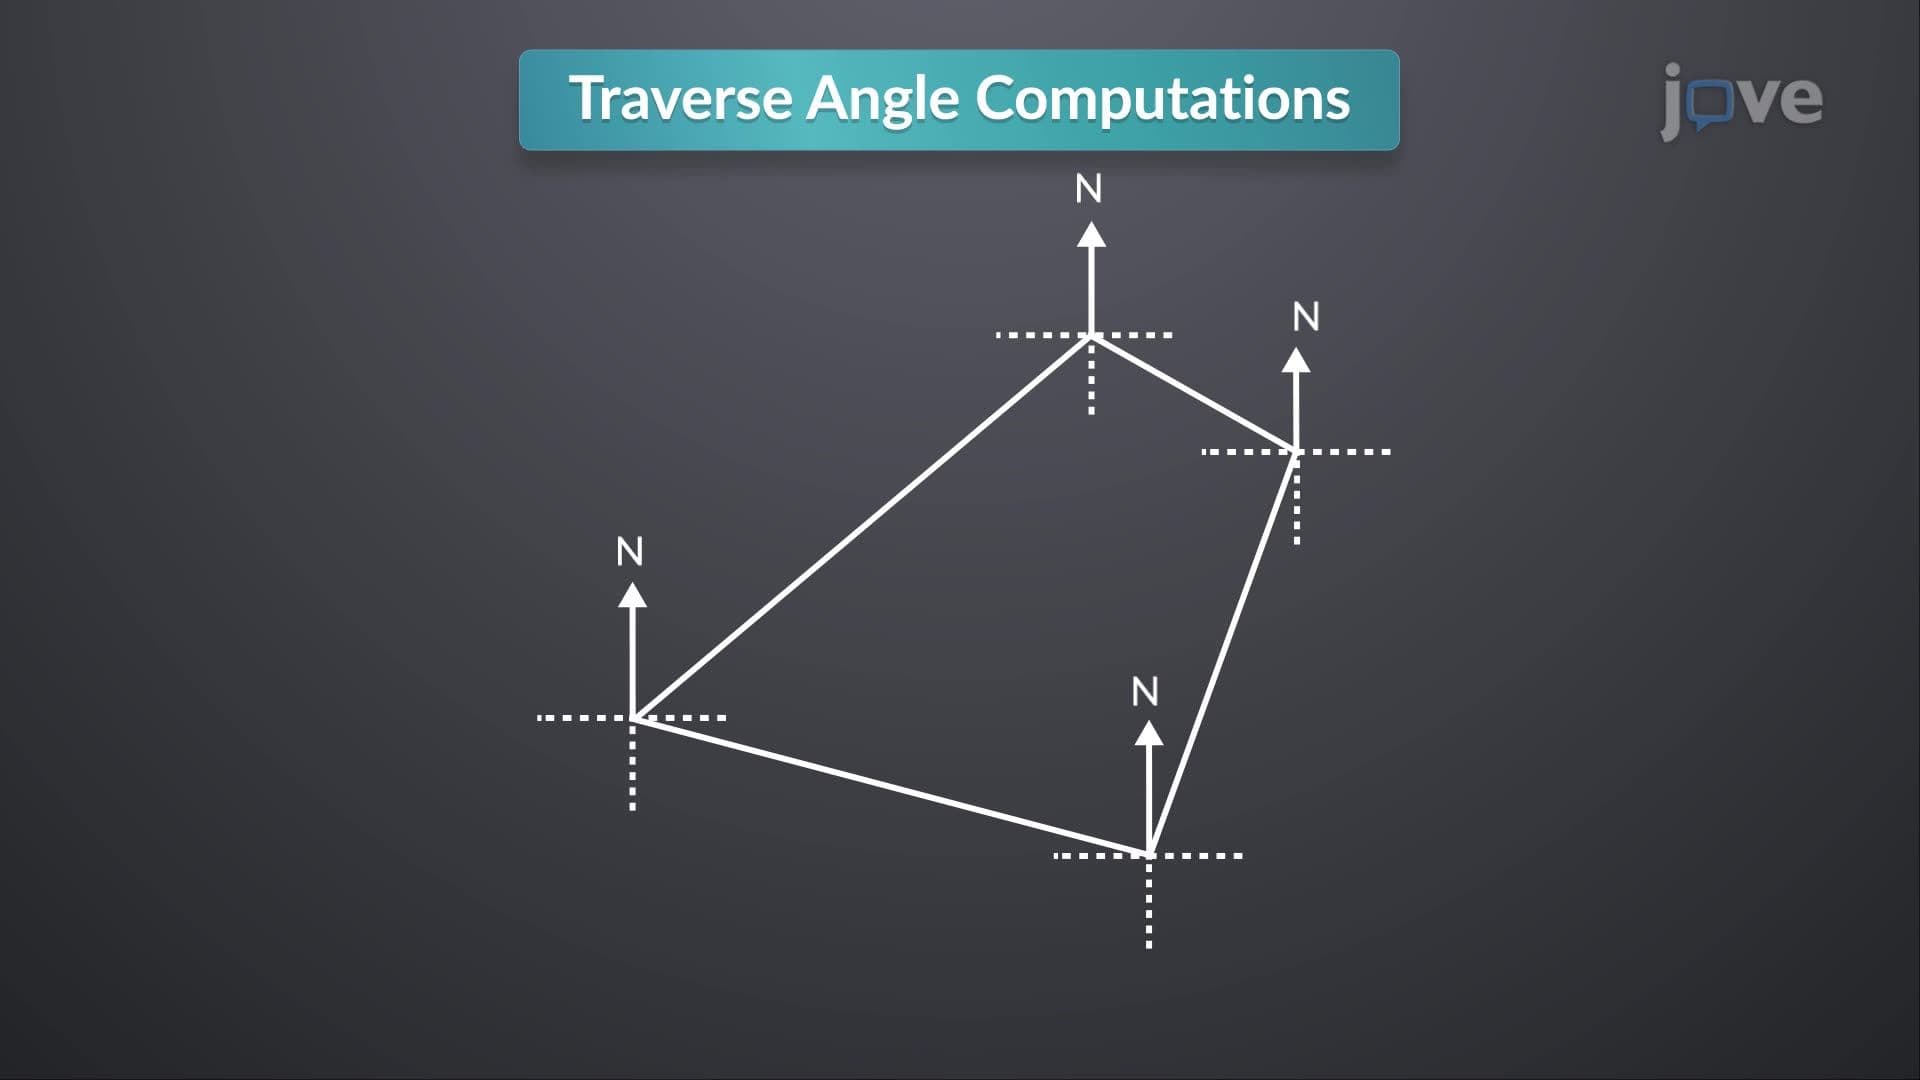
Traverse angle computations are a critical component of surveying, used to compute the internal angles within a closed traverse. A traverse consists of a series of connected lines forming a closed loop, often used for land boundary delineation or mapping. Calculating the internal angles ensures accuracy in the traverse geometry and is essential for checking survey data integrity.The process begins with known azimuths and bearings of the traverse sides. Internal angles at each vertex are...