Low-coherence self-referencing velocimetry
Related Experiment Video
Updated: Jul 15, 2026
Meso-Scale Particle Image Velocimetry Studies of Neurovascular Flows In Vitro
Published on: December 3, 2018
Andreas Kempe1, Stefan Schlamp, Thomas Rösgen
1Institute of Fluid Dynamics, ETH Zürich, Zürich, Switzerland. kempe@ifd.mavt.ethz.ch

Abstract:
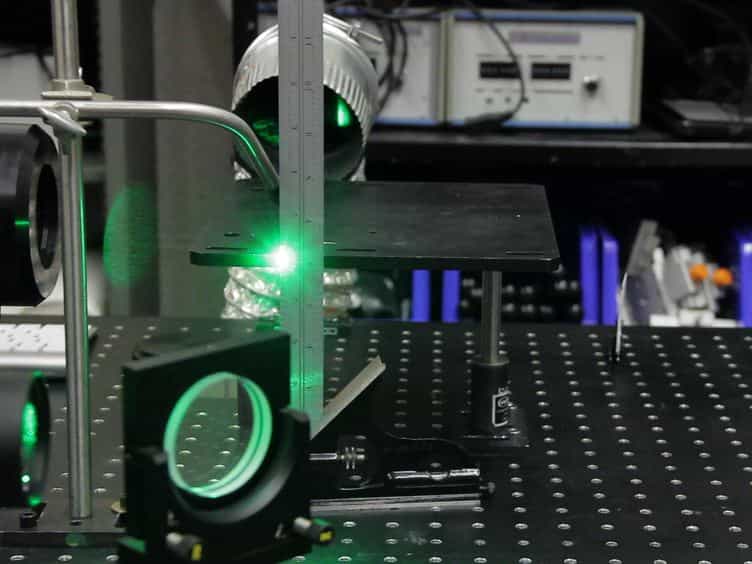
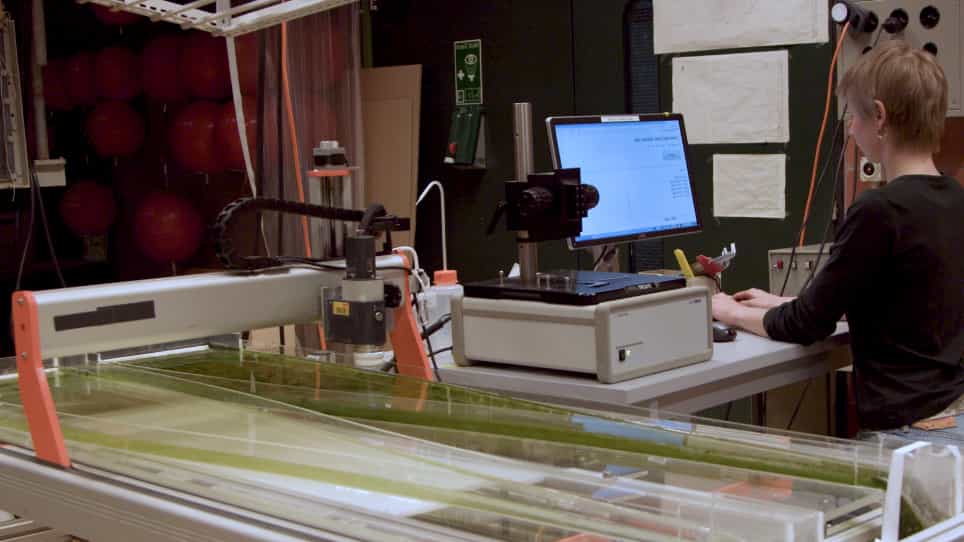
Low-coherence self-referencing velocimetry optically measures the relative velocity between a point in a particle-laden fluid and a (potentially moving) reference surface. Low-coherence light scattered off the particles and off the reference surface is coupled into an interferometer with variable optical delay in one arm and an acousto-optical modulator in the second arm. The measurement location is set relative to the reference surface. Its location can be scanned along a line by adjusting the optical delay in the interferometer. The spatial resolution is typically tens of micrometers. Only one low-coherence light beam is required for each component of the velocity vector. Proof-of-principle measurements in Taylor-Couette flow are presented.
Related Concept Videos
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:18
Distance Measurements by Taping
 01:03
Inertial Frames of Reference
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:27
Non-inertial Frames of Reference
 01:12
Average and Instantaneous Velocity Vectors