Related Experiment Video
Updated: Jul 14, 2026
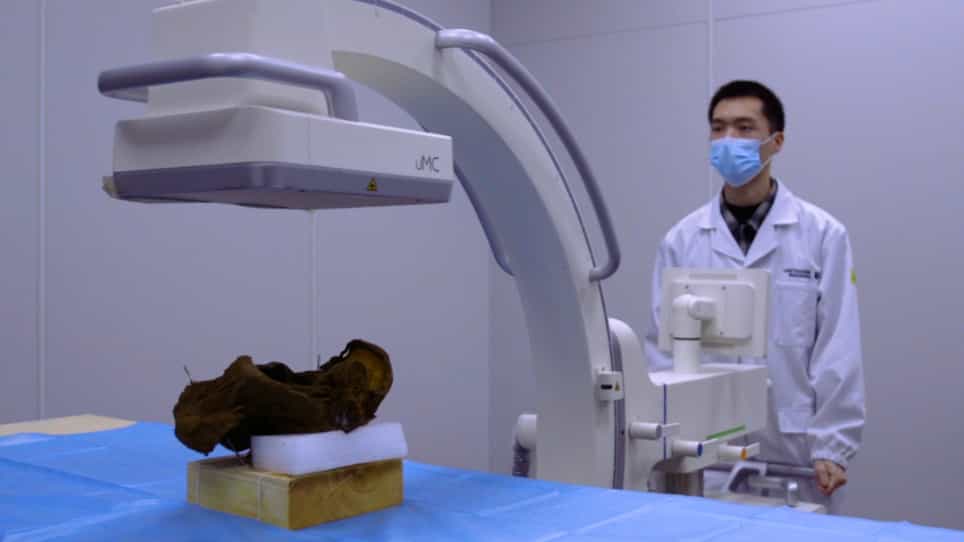

A Teleoperated Robotic System-Assisted Percutaneous Transiliac-Transsacral Screw Fixation Technique
Published on: January 6, 2023
A robotic C-arm fluoroscope
N Binder1, L Matthäus, R Burgkart
1Institute for Robotics and Cognitive Systems, University of Lübeck, Lübeck, Germany. binder@rob.uni-luebeck.de

Abstract:
Fluoroscopic C-arms are common devices for acquiring images during surgery. Manual positioning is time consuming and requires considerable experience. Trained users must often take several images to find the best viewing direction. If a second image must be taken from the same position, e.g. for postoperative control, the C-arm must be moved to the exact same position. Without guidance, this is often difficult to accomplish. We developed the idea to completely "robotize" a standard C-arm, i.e. to equip all joints with motors and encoders. A software environment provides for intelligent control. To archive this goal a complete kinematic analysis of the fluoroscope was necessary. On the basis of this analysis a number of clinical applications have been developed: (1) simplified positioning via cartesian control; (2) automatic acquisition of panoramic images; (3) 3D CT with arbitrary viewing angles; (4) 4D intraoperative CT with/without respiration triggering; (5) automated anatomy-oriented positioning. The goal of this research is thus three-fold: minimise radiation exposure of the OR staff, reduce positioning time and offer enhanced imaging capability.
Related Concept Videos
 01:20
Imaging Studies for Cardiovascular System III: X-Ray
Definition and Purpose
An X-ray, or radiograph, is a non-invasive method that uses ionizing radiation to take images of internal structures. It is mainly used in cardiac imaging to examine the heart, lungs, and major blood vessels, aiming to identify abnormalities in the heart's size, shape, and position, such as heart failure, congenital defects, and vascular...
 01:25
Ultrasound II: Endoscopic Ultrasound and FibroScan
Endoscopic Ultrasound (EUS):