Related Experiment Video
Updated: Jul 14, 2026
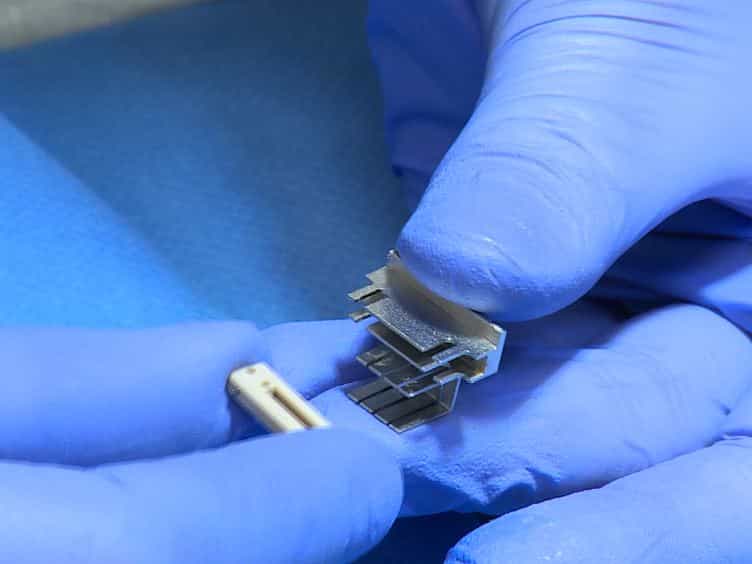

Adjustable Stiffness, External Fixator for the Rat Femur Osteotomy and Segmental Bone Defect Models
Published on: October 9, 2014
A hexapod robot external fixator for computer assisted fracture reduction and deformity correction
K Seide1, M Faschingbauer, M E Wenzl
1Berufsgenossenschaftliches Unfallkrankenhaus (Trauma Center), Hamburg, Germany. k.seide@buk-hamburg.de

Abstract:
Using hexapod robot kinematics, an external fixator adjustable in all six spatial degrees of freedom was developed. As usual with a robot system, bone movements can be accomplished with high precision. Contrary to conventional external fixators any three-dimensional movement is realisable without giving up stability or the necessity to change parts of the construction during the treatment. At first a manually controlled fixator with appropriate software was developed. Then electromotor elements were added, resulting in a "fracture reduction robot" and a fixator featuring load measurement capabilities was built. Finally the concept was extended into an "intelligent fixator" which will accomplish automatically controlled fracture and deformity treatment in the future.