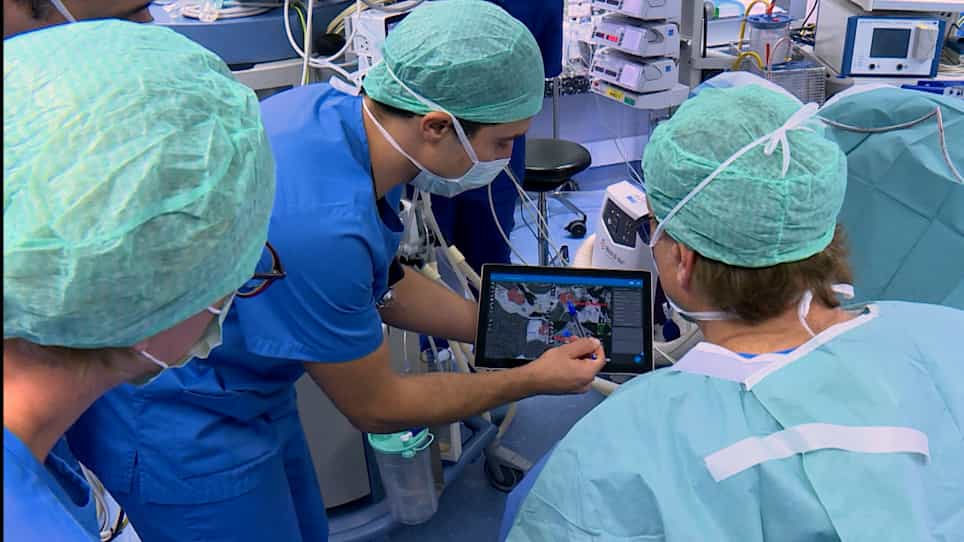
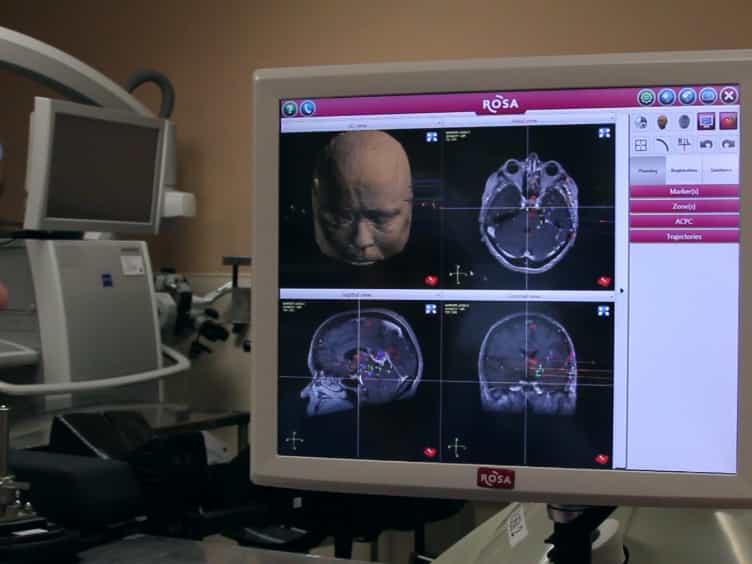
Related Experiment Video
Updated: Jul 14, 2026
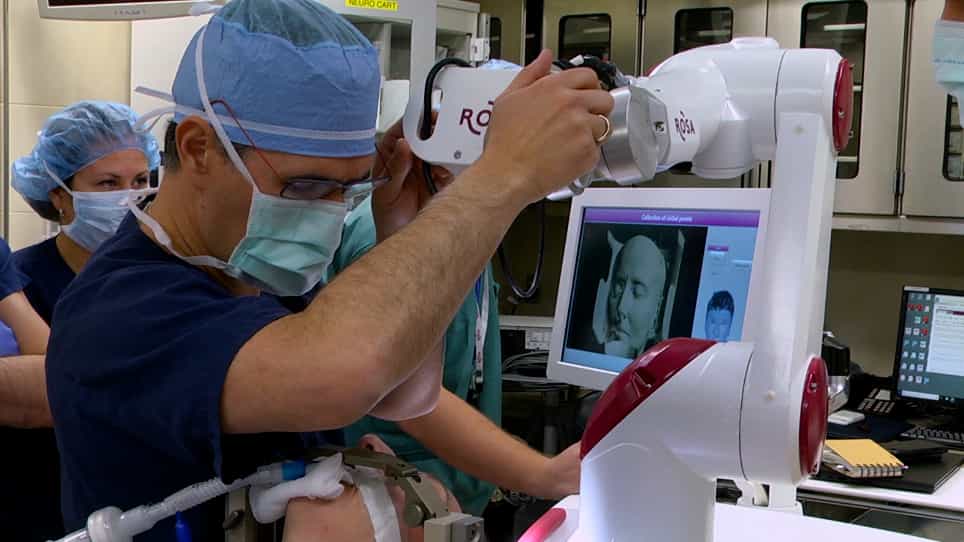

Operative Technique and Nuances for the Stereoelectroencephalographic (SEEG) Methodology Utilizing a Robotic Stereotactic Guidance System
Published on: June 9, 2023
Robot- and computer-assisted craniotomy: resection planning, implant modelling and robot safety
1Helmholtz-Institute for Biomedical Engineering, RWTH Aachen University, Germany. bast@hia.rwth.aachen.de

Background:
In cases of cranial tumour, manual resection of the cancerous tissue can be very stressful and time-consuming, due to the adhesion of the subjacent dura mater. Computer-assisted planning, navigation and robotic craniotomy, with optional skull reconstruction using customized implants, are of increasing clinical interest in craniofacial and neurosurgery.
Methods:
Using preoperative computed tomography (CT) images, an automatic segmentation of the tumour is performed, followed by resection planning. The skull reconstruction is performed using computer-assisted implant modeling and manufacturing. Risk analysis of the robot-guided intervention led to the development of a new hexapod robot system.
Results:
Results from registration and robot accuracy on plastic and Anatomical skull are shown. The concept of a stand-alone safety system is presented to supervise the robot during the intervention. The entire process from preoperative CT scan to intraoperative robot assisted removal of tumourous bone is shown in laboratory and anatomical trials.
Conclusion:
The laboratory and anatomy studies conducted so far provided a substantial basis for further improvement of the system's integration in the surgical workflow and the final approval of the system for initial clinical studies.