On perturbation and pattern coexistence in postural coordination dynamics
Related Experiment Video
Updated: Jul 13, 2026
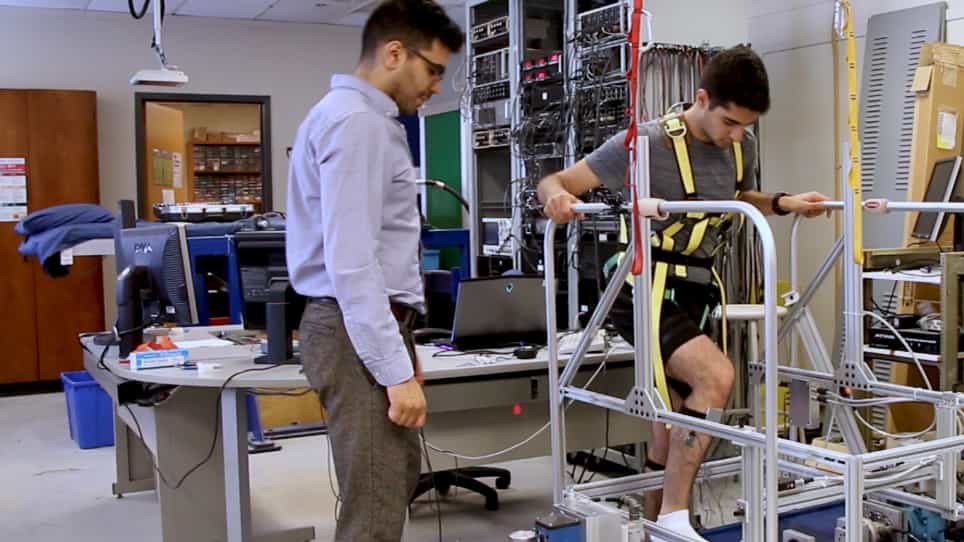
Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
Benoît G Bardy1, Olivier Oullier, Julien Lagarde
1Laboratoire Efficience et Déficience Motrices, Université Montpellier I and Institut Universitaire de France, Paris, France. benoit.bardy@univ-montpl.fr

Abstract:
In studies of postural control, investigators have used either experimentally induced perturbations to stance or unperturbed stance. The distinction between perturbed and unperturbed stance has gained renewed importance in the context of inphase and antiphase coordination of the hips and ankles. Several contributions have replicated the findings published over the past decade, suggesting the possibility of a unified view of postural control. However, any proposed unified view depends on how so called perturbed and unperturbed are defined. The authors argue that, to date, there is no explicit and general definition of those terms. The main reason is that all perturbations are relative and depend on appropriate frames of reference for perception and action. Arguments about empirical or theoretical unification of perturbed and unperturbed stance are premature.
Related Concept Videos
 01:23
Stability of Equilibrium Configuration
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's response.
 01:13
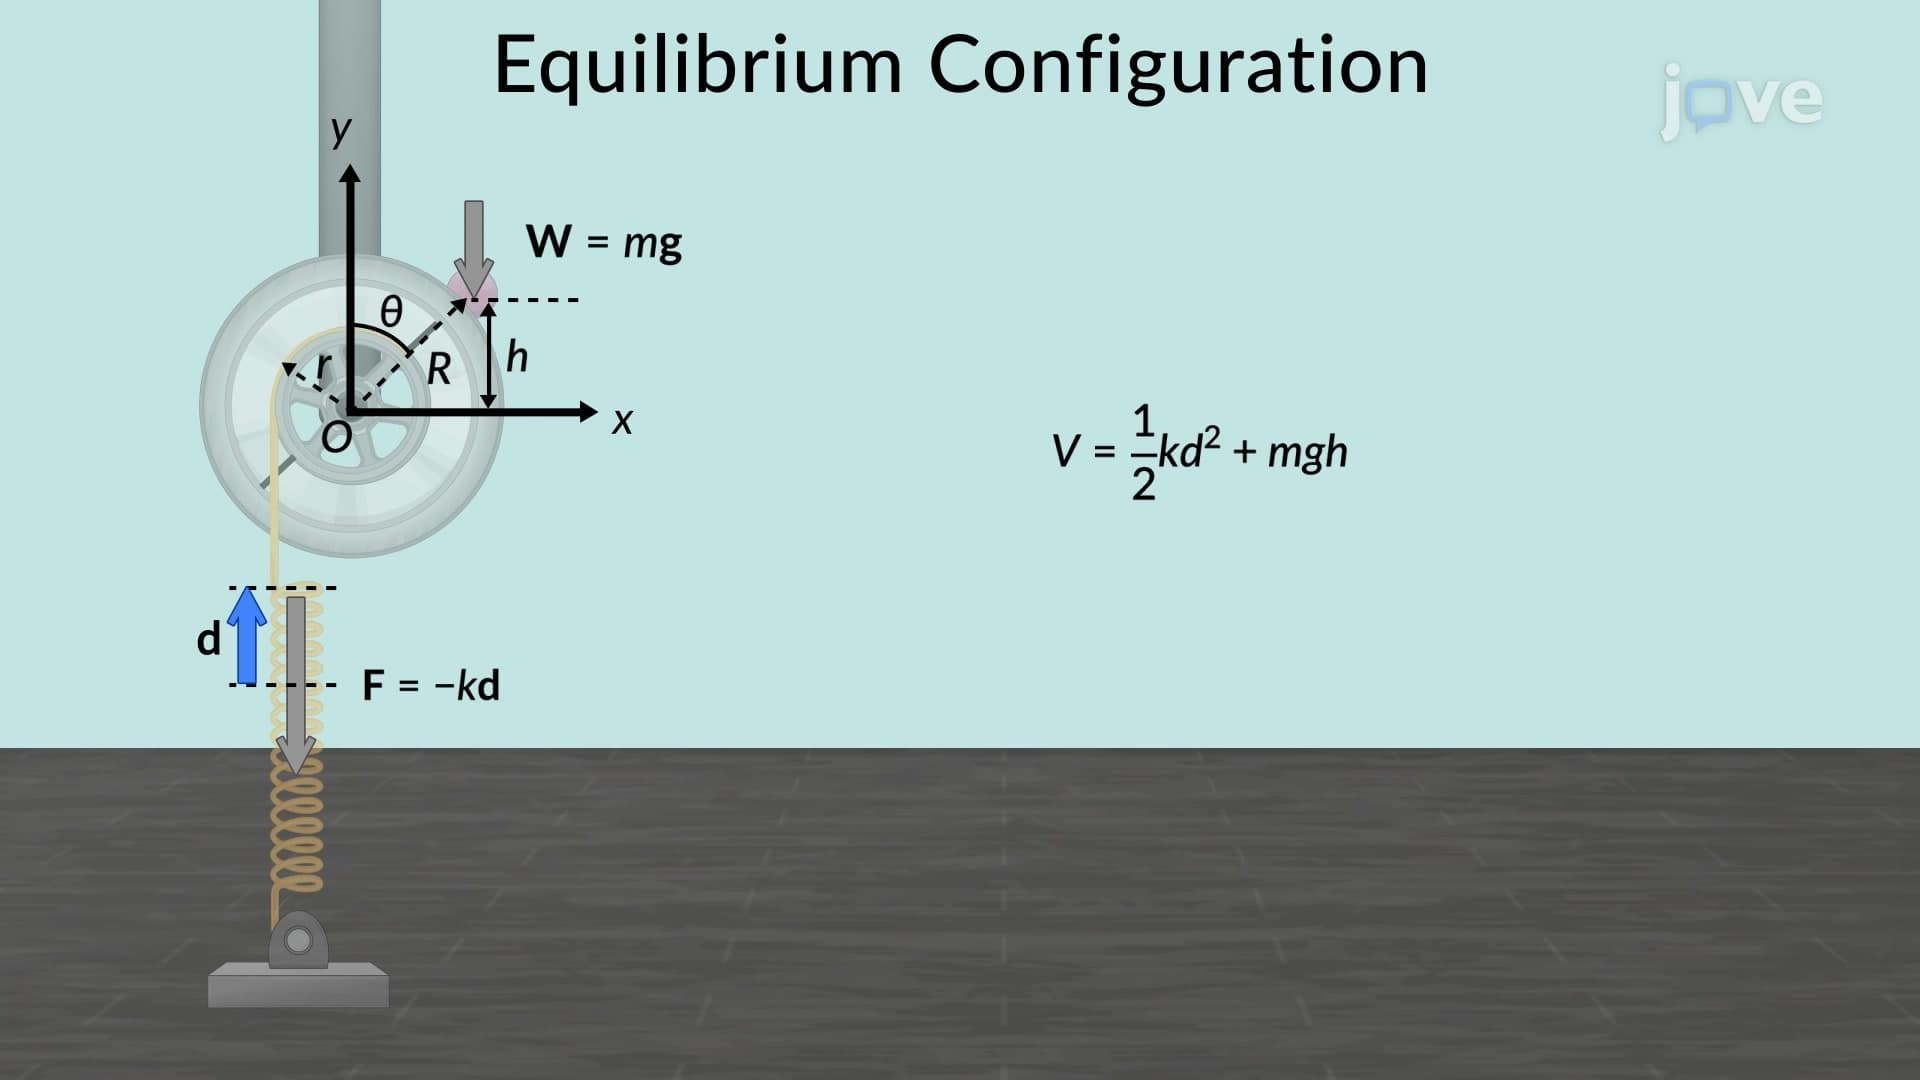
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 00:49
Rigid Body Equilibrium Problems - I
 01:04
Oscillations about an Equilibrium Position