Related Experiment Video
Updated: Jul 13, 2026
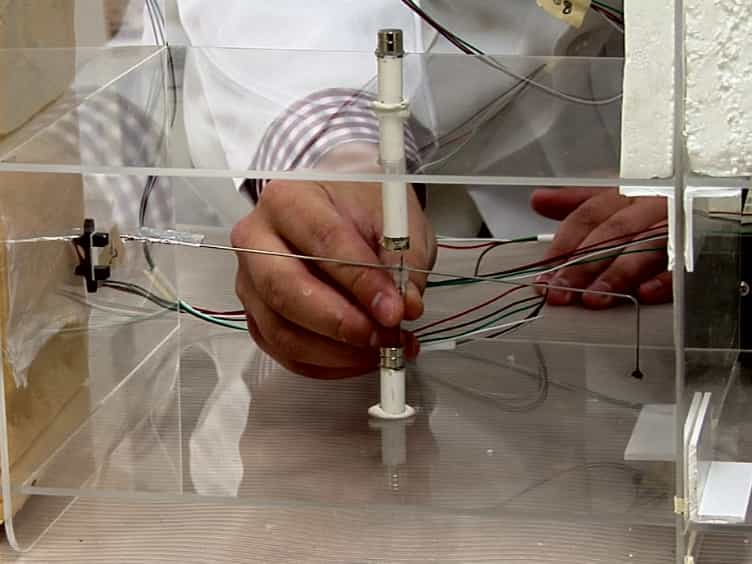

A Simple Flight Mill for the Study of Tethered Flight in Insects
Published on: December 10, 2015
On mathematical modelling of insect flight dynamics in the context of micro air vehicles
Rafał Zbikowski1, Salman A Ansari, Kevin Knowles
1Department of Aerospace, Power and Sensors, Cranfield University, Defence Academy of the UK, Shrivenham, UK. R.W.Zbikowski@cranfield.ac.uk

Abstract:
We discuss some aspects of mathematical modelling relevant to the dynamics of insect flight in the context of insect-like flapping-wing micro air vehicles (MAVs). MAVs are small flying vehicles developed to reconnoître in confined spaces. This requires power-efficient, highly-manoeuvrable, low-speed flight with stable hover. All of these attributes are present in insect flight and hence the focus on reproducing the functionality of insect flight by engineering means. Empirical research on insect flight dynamics is limited by experimental difficulties. Force and moment measurements require tethering the animal whose behaviour may then differ from free flight. The measurements are made when the insect actively tries to control its flight, so that its open-loop dynamics cannot be observed. Finally, investigation of the sensory-motor system responsible for flight is even more challenging. Despite these difficulties, much empirical progress has been made recently. Further progress, especially in the context of MAVs, can be achieved by the complementary information derived from appropriate mathematical modelling. The focus here is on a means of computing the data not easily available from experiments and also on making mathematical predictions to suggest new experiments. We consider two aspects of mathematical modelling for insect flight dynamics. The first one is theoretical (computational), as opposed to empirical, generation of the aerodynamic data required for the six-degrees-of-freedom equations of motion. For this purpose we first explain insect wing kinematics and the salient features of the corresponding flow. In this context, we show that aerodynamic modelling is a feasible option for certain flight regimes, focusing on a successful example of modelling hover. Such modelling progresses from the first principles of fluid mechanics, but relies on simplifications justified by the known flow phenomenology and/or geometric and kinematic symmetries. This is relevant to six types of fundamental manoeuvres, which we define as those flight conditions for which only one component of the translational and rotational body velocities is nonzero and constant. The second aspect of mathematical modelling for insect flight dynamics addressed here deals with the periodic character of the aerodynamic force and moment production. This leads to consideration of the types of solutions of nonlinear equations forced by nonlinear oscillations. In particular, the mechanism of synchronization seems relevant and should be investigated further.
Related Concept Videos
 01:30
Vector Functions and Motion: Problem Solving
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:29
Application of Linearization and Approximation
 01:17
Bernoulli's Principle: Applications
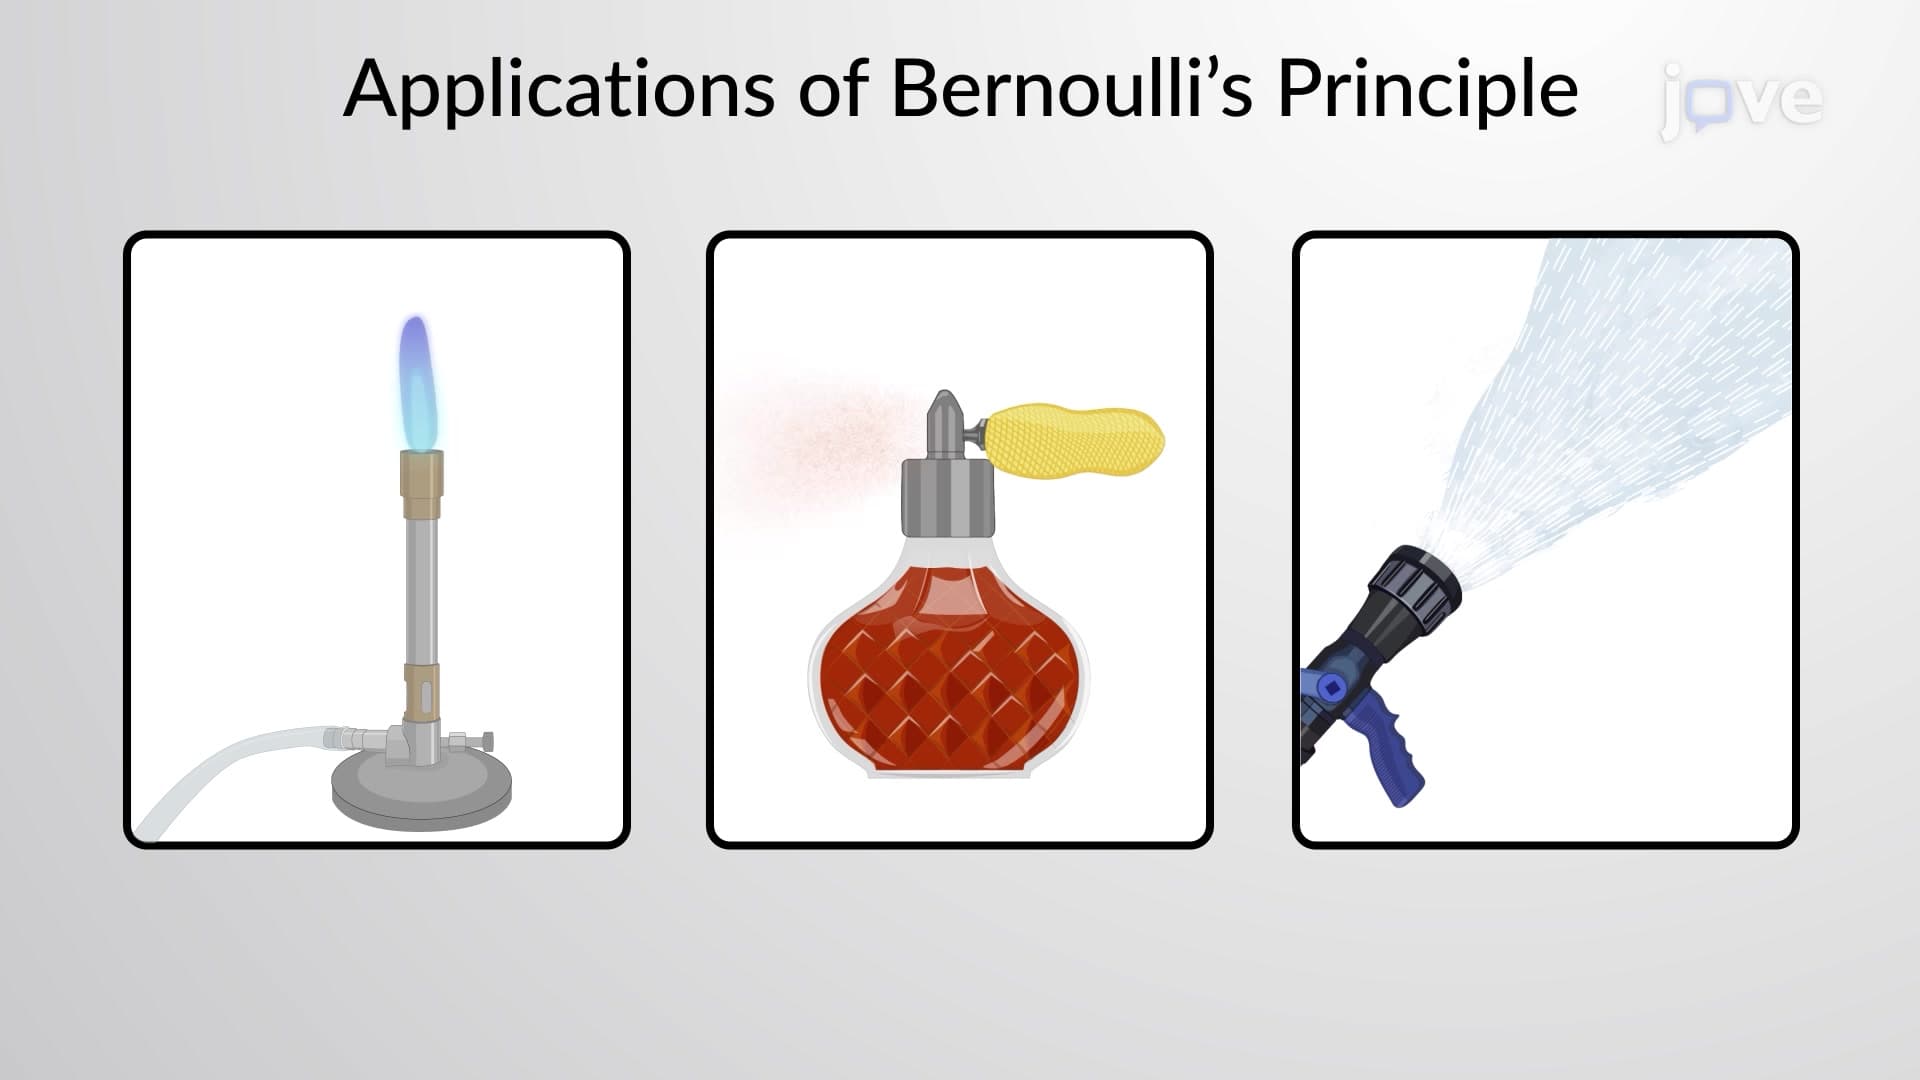
Entrainment devices use a high fluid speed to create low pressures and, thus, entrain one fluid into another. Some examples of these devices are given below:
 01:16
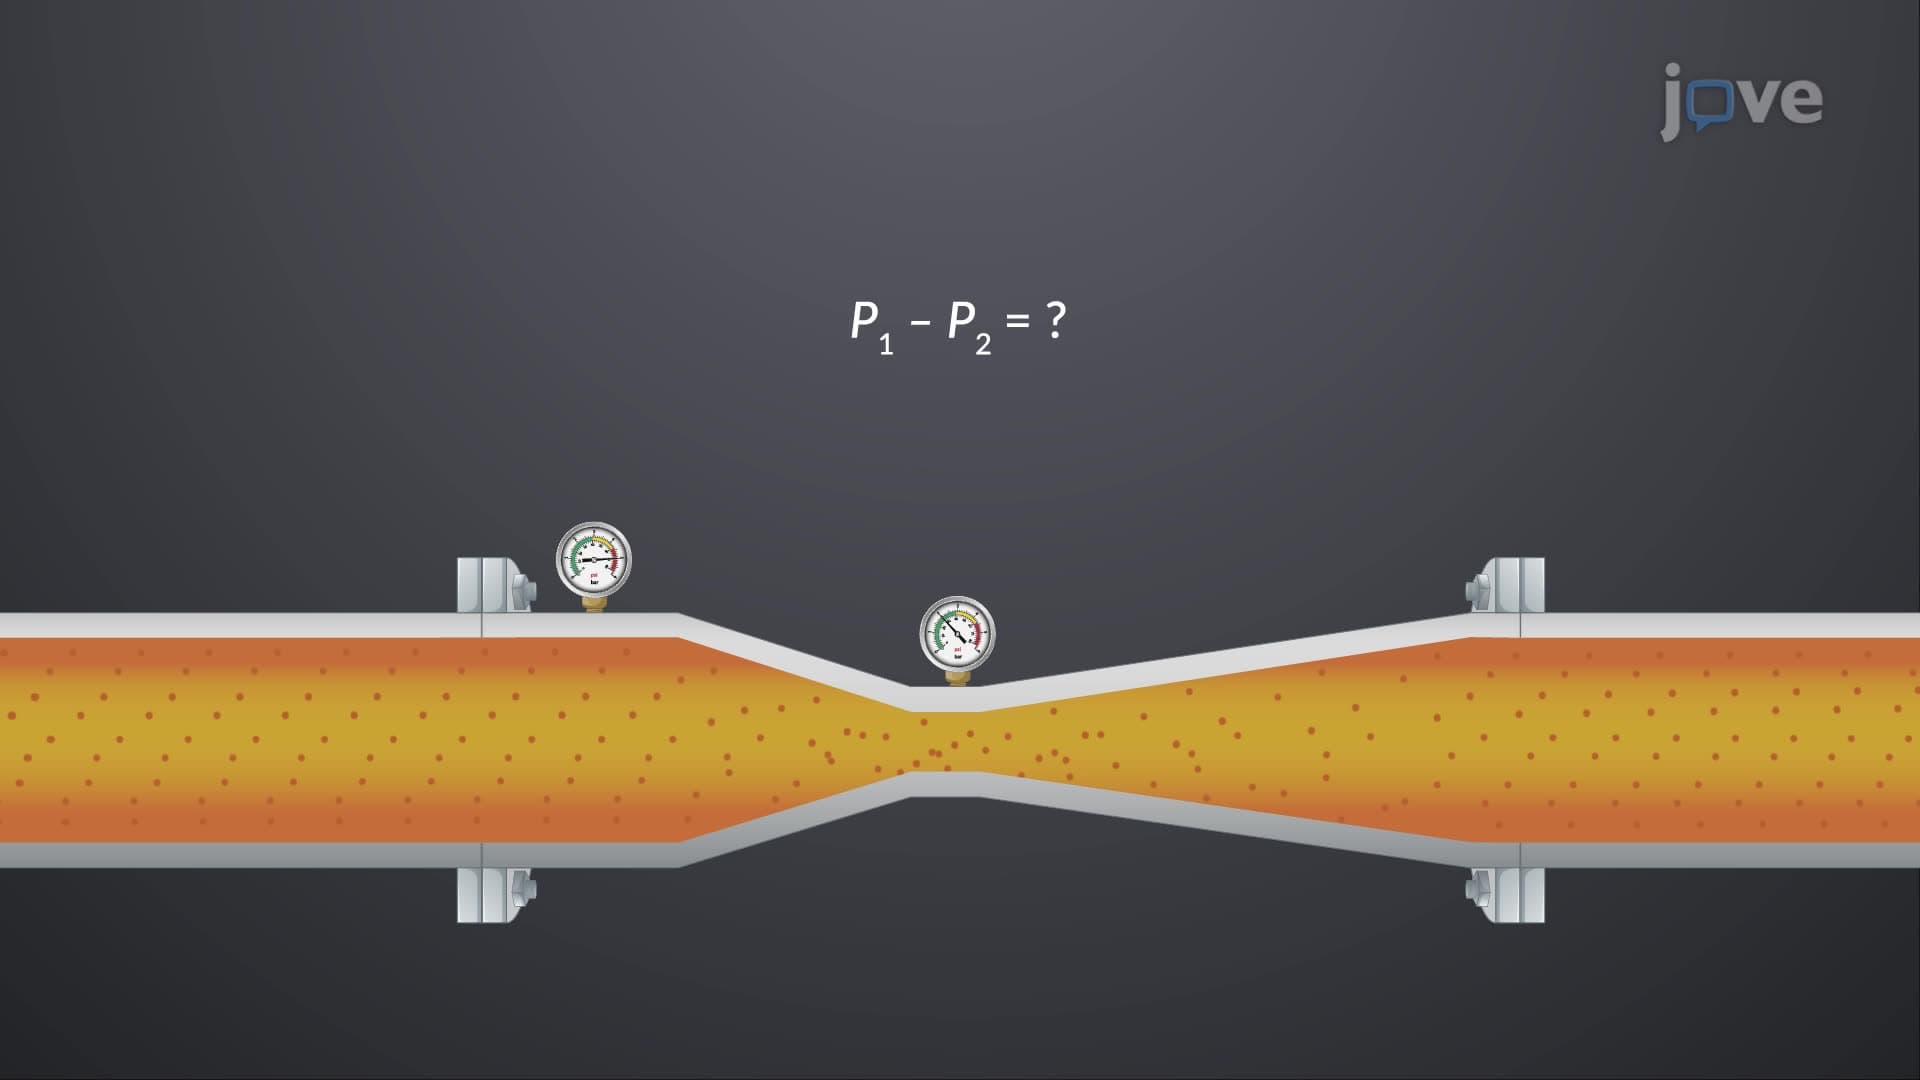
Bernoulli's Equation: Problem Solving
The first step is to compute the cross-sectional areas of the pipe and the Venturi throat to analyze the pressure difference indicated by the pressure gauge. Next, the continuity equation is...