ARMin: a robot for patient-cooperative arm therapy
Related Experiment Video
Updated: Jul 13, 2026

Robotic Mirror Therapy System for Functional Recovery of Hemiplegic Arms
Published on: August 15, 2016
Tobias Nef1, Matjaz Mihelj, Robert Riener
1Sensory-Motor Systems Laboratory, ETH Zürich, TAN E, Tannenstrasse 1, 8092 Zurich, Switzerland. nef@mavt.ethz.ch

Abstract:
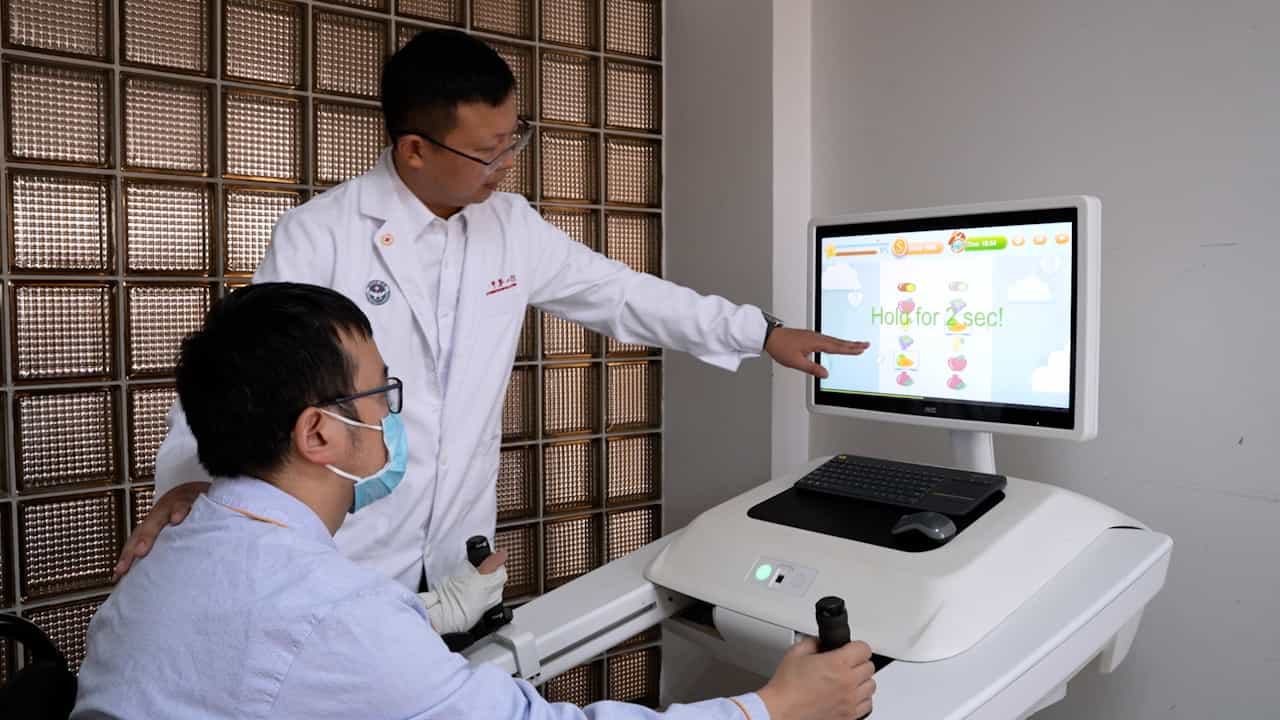
Task-oriented, repetitive and intensive arm training can enhance arm rehabilitation in patients with paralyzed upper extremities due to lesions of the central nervous system. There is evidence that the training duration is a key factor for the therapy progress. Robot-supported therapy can improve the rehabilitation allowing more intensive training. This paper presents the kinematics, the control and the therapy modes of the arm therapy robot ARMin. It is a haptic display with semi-exoskeleton kinematics with four active and two passive degrees of freedom. Equipped with position, force and torque sensors the device can deliver patient-cooperative arm therapy taking into account the activity of the patient and supporting him/her only as much as needed. The haptic display is combined with an audiovisual display that is used to present the movement and the movement task to the patient. It is assumed that the patient-cooperative therapy approach combined with a multimodal display can increase the patient's motivation and activity and, therefore, the therapeutic progress.