Optical information for car following: the driving by visual angle (DVA) model
Related Experiment Video
Updated: Jul 11, 2026
Binocular Dynamic Visual Acuity in Eyeglass-Corrected Myopic Patients
Published on: March 29, 2022
George J Andersen1, Craig W Sauer
1Department of Psychology, University of California, Riverside, CA 92521, USA. andersen@ucr.edu

Objective:
The present study developed and tested a model of car following by human drivers.
Background:
Previous models of car following are based on 3-D parameters such as lead vehicle speed and distance information, which are not directly available to a driver. In the present paper we present the driving by visual angle (DVA) model, which is based on the visual information (visual angle and rate of change of visual angle) available to the driver.
Method:
Two experiments in a driving simulator examined car-following performance in response to speed variations of a lead vehicle defined by a sum of sine wave oscillations and ramp acceleration functions. In addition, the model was applied to six driving events using real world-driving data.
Results:
The model provided a good fit to car-following performance in the driving simulation studies as well as in real-world driving performance. A comparison with the advanced interactive microscopic simulator for urban and nonurban networks (AIMSUN) model, which is based on 3-D parameters, suggests that the DVA was more predictive of driver behavior in matching lead vehicle speed and distance headway.
Conclusion:
Car-following behavior can be modeled using only visual information to the driver and can produce performance more predictive of driver performance than models based on 3-D (speed or distance) information.
Application:
The DVA model has applications to several traffic safety issues, including automated driving systems and traffic flow models.
Related Concept Videos
 01:29
Sight Distance in a Vertical Curve
 01:15
Depth Perception and Spatial Vision
 01:24
Vision
 00:56
Doppler Effect - I
 01:05
Doppler Effect - II
 01:27
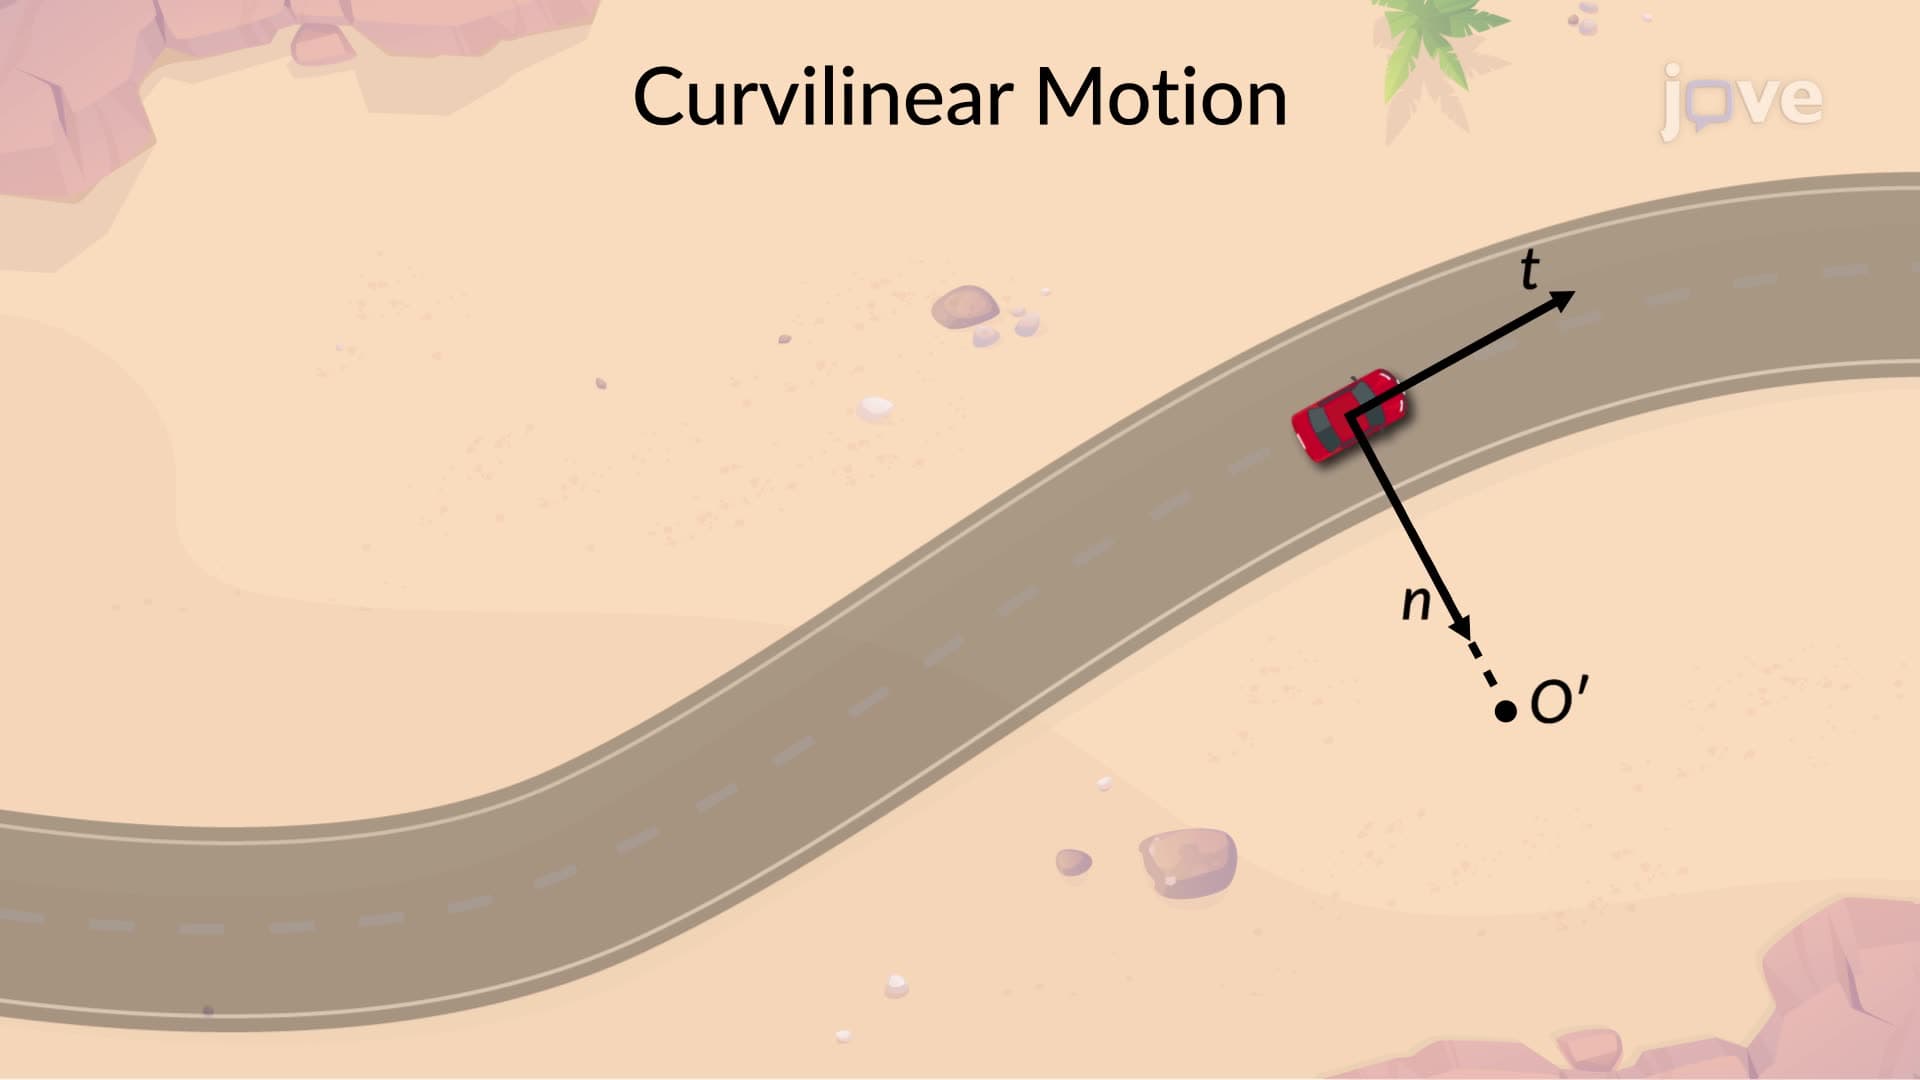
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...