Related Experiment Video
Updated: Jul 10, 2026
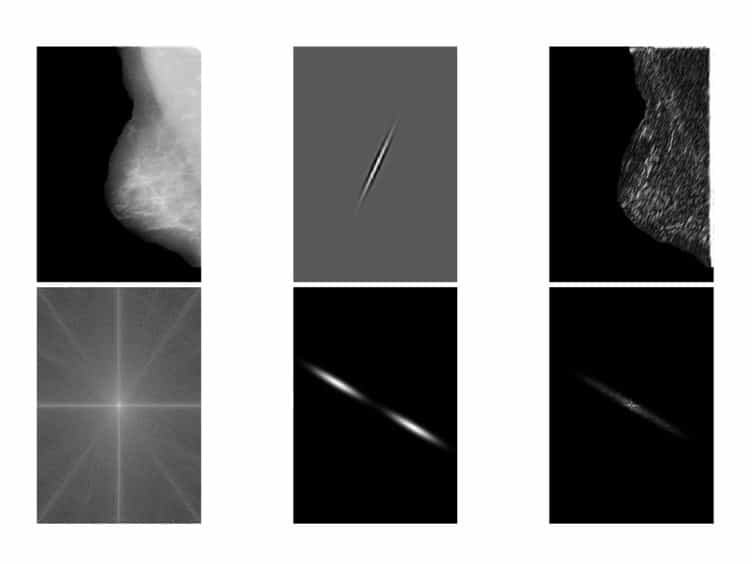
Detection of Architectural Distortion in Prior Mammograms via Analysis of Oriented Patterns
Published on: August 30, 2013
Representing images using nonorthogonal Haar-like bases
Feng Tang1, Ryan Crabb, Hai Tao
1Department of Computer Engineering, Univesity of California, Santa Cruz, CA 95064, USA. tang@soe.ucsc.edu

Abstract:
Efficient and compact representation of images is a fundamental problem in computer vision. In this paper, we propose methods that use Haar-like binary box functions to represent a single image or a set of images. A desirable property of these box functions is that their inner product operation with an image can be computed very efficiently. We propose two closely related novel subspace methods to model images: the non-orthogonal binary subspace (NBS) method and binary principal component analysis (B-PCA) algorithm. NBS is spanned directly by binary box functions and can be used for image representation, fast template matching and many other vision applications. B-PCA is a structure subspace that inherits the merits of both NBS (fast computation) and PCA (modeling data structure information). B-PCA base vectors are obtained by a novel PCA guided NBS method. We also show that BPCA base vectors are nearly orthogonal to each other. As a result, in the non-orthogonal vector decomposition process, the computationally intensive pseudo-inverse projection operator can be approximated by the direct dot product without causing significant distance distortion. Experiments on real image datasets show promising performance in image matching, reconstruction and recognition tasks with significant speed improvement.
Related Concept Videos
 01:20
Transformations of Functions III
 01:27
The Normal and Binormal Vectors
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 01:16
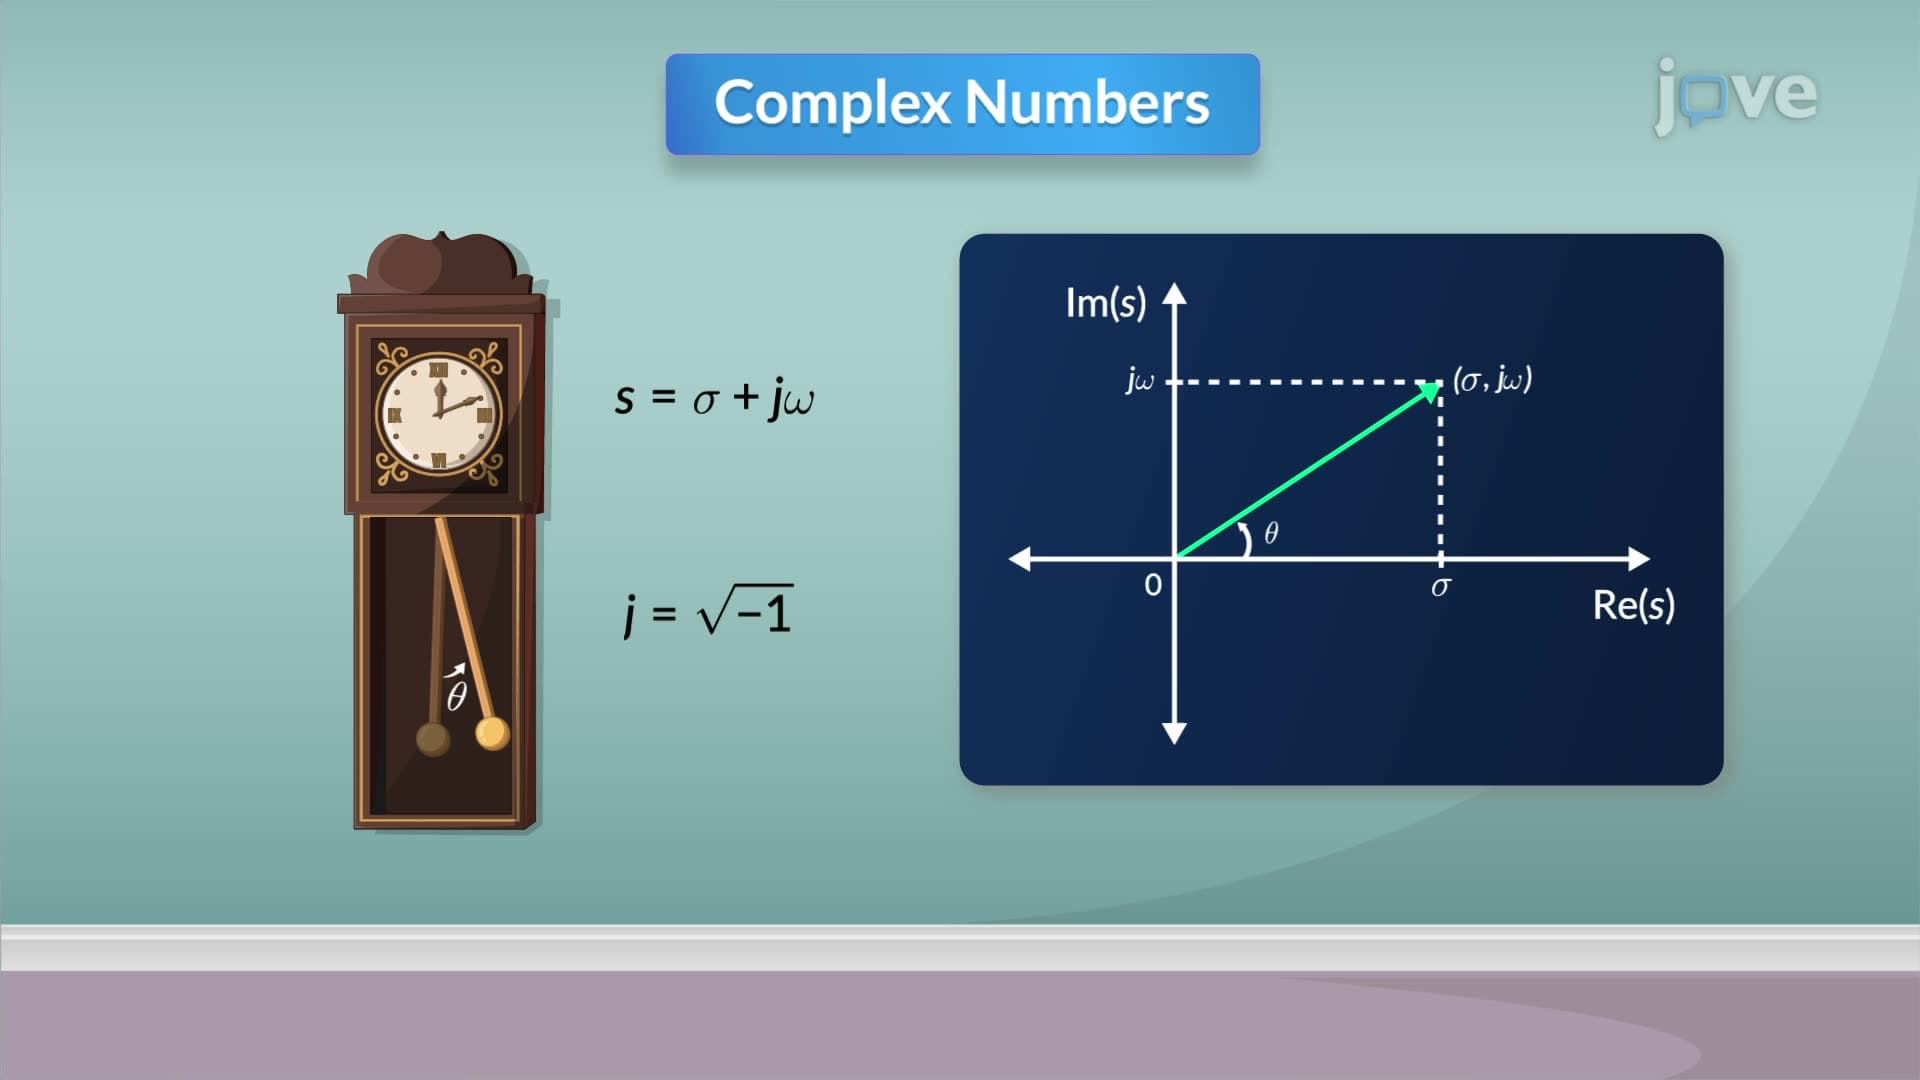
Vector Representation of Complex Numbers
Consider a function defined as the product of the complex factors in the numerator divided by the product of the complex factors in the denominator.
 01:24
Convolution: Math, Graphics, and Discrete Signals
To simplify the convolution integral, it is assumed that both the input signal and impulse response are zero for negative time values. The graphical convolution process...
 01:10
Vector Algebra: Graphical Method
We use the laws of geometry to construct resultant vectors, followed by trigonometry to find vector magnitudes and directions. For a geometric construction of the sum of two vectors in a plane, we follow the parallelogram rule. Suppose two vectors are at arbitrary positions. Translate either one of...