Related Experiment Video
Updated: Jul 10, 2026
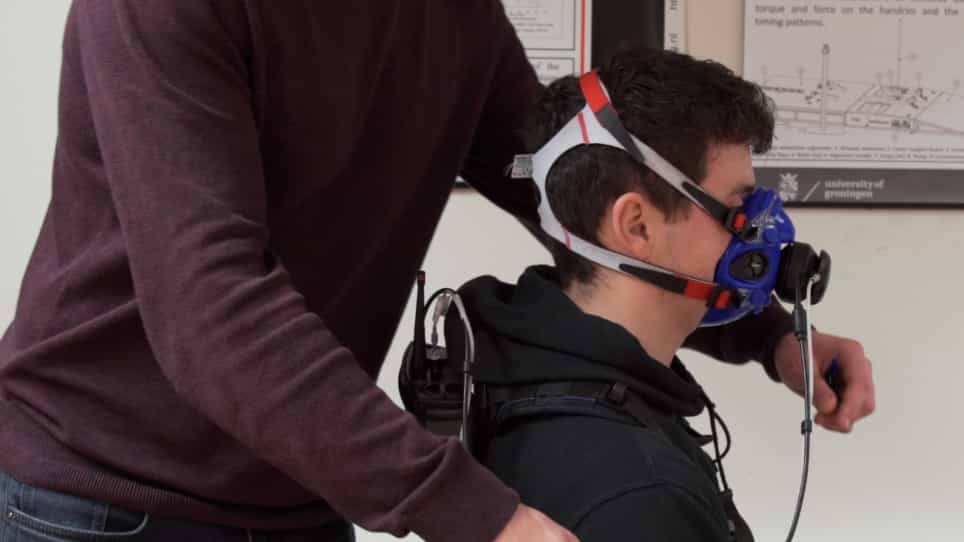

Determining and Controlling External Power Output During Regular Handrim Wheelchair Propulsion
Published on: February 5, 2020
Shoulder kinematics and kinetics during two speeds of wheelchair propulsion
Alicia M Koontz1, Rory A Cooper, Michael L Boninger
1Department of Rehabilitation Science and Technology, University of Pittsburgh, PA, USA. akoontz@pitt.edu

Abstract:
The primary objective of this study was to examine the kinematics and kinetics of the shoulder during wheelchair propulsion at a slow and moderate speed. Twenty-seven individuals with paraplegia propelled their wheelchairs at speeds of 0.9 m/s and 1.8 m/s while a motion analysis system captured movements of their upper limbs and SMART(Wheel)s simultaneously recorded their pushrim kinetics. Intraclass R correlation and Cronbach's coefficient alpha statistics revealed that all shoulder parameters were stable and consistent between strokes and speeds. The shoulder exhibited a greater range of motion, and forces and moments at the shoulder were 1.2 to 2.0 times greater (p < 0.05) during the 1.8 m/s speed trial. Peak posterior forces occurred near the end of the propulsion phase, and at the same time, the shoulder was maximally flexed and minimally abducted (p > 0.1). Shoulder positioning and the associated peak shoulder loads during propulsion may be important indicators for identifying manual wheelchair users at risk for developing shoulder pain and injury.
More Related Videos
Related Concept Videos
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:10
Relative Motion Analysis - Acceleration
 01:16
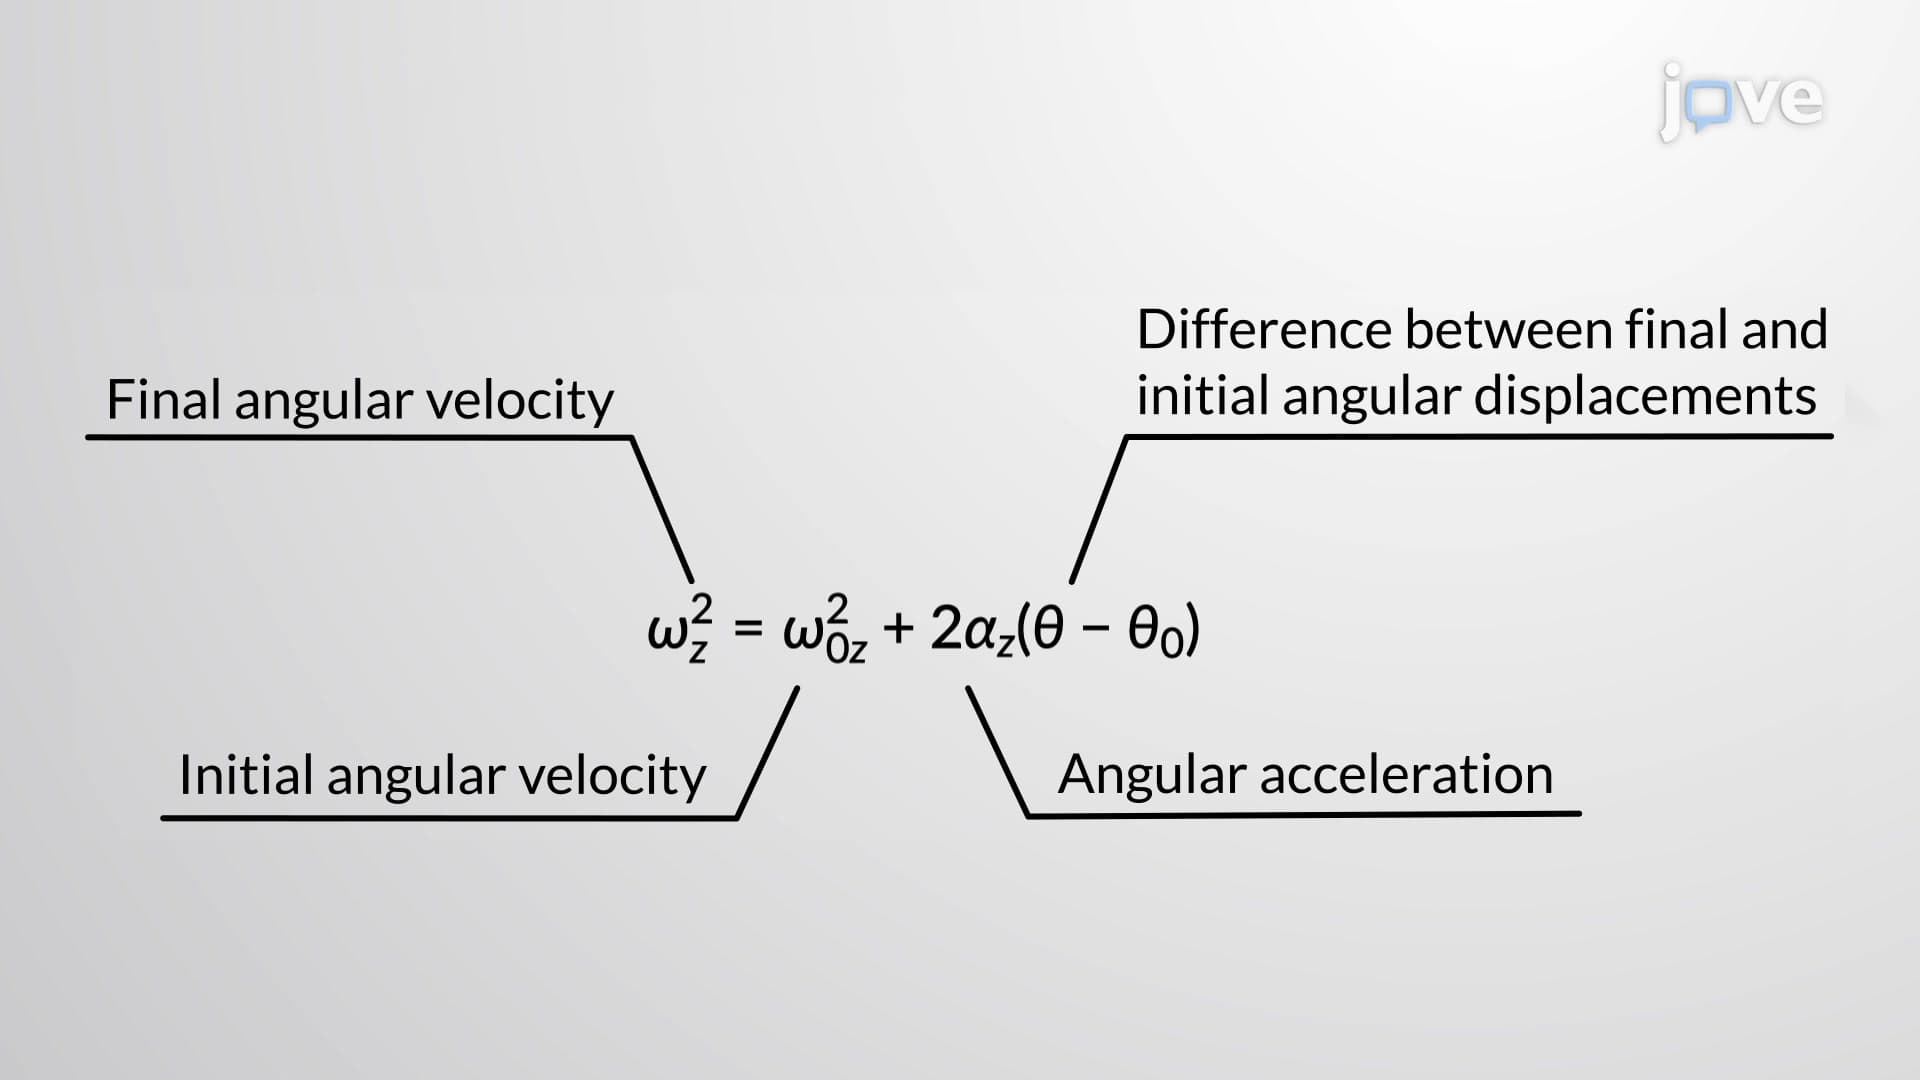
Rotation with Constant Angular Acceleration - II
The first...
 01:15
Kinematic Equations: Problem Solving
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:16
Equation of Motion: General Plane motion - Problem Solving
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...