Related Experiment Video
Updated: Jul 10, 2026
05:44
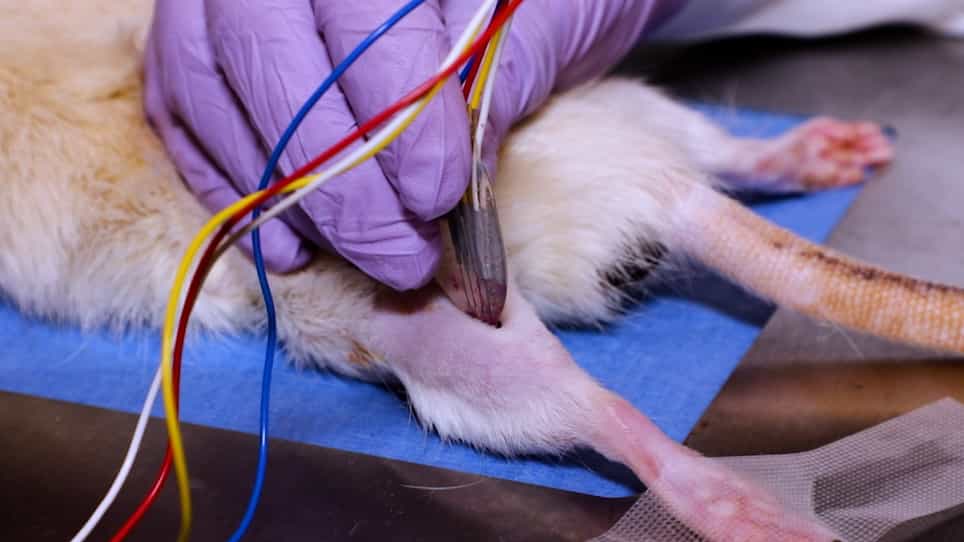
Performing In Vivo and Ex Vivo Electrical Impedance Myography in Rodents
Published on: June 8, 2022
A simple highly efficient non invasive EMG-based HMI
N Vitiello1, U Olcese, C M Oddo
1ARTS Lab., Scuola Superiore Sant'Anna, Pisa, Italy. n.vitiello@sssup.it

Abstract:
Muscle activity recorded non-invasively is sufficient to control a mobile robot if it is used in combination with an algorithm for its asynchronous analysis. In this paper, we show that several subjects successfully can control the movements of a robot in a structured environment made up of six rooms by contracting two different muscles using a simple algorithm. After a small training period, subjects were able to control the robot with performances comparable to those achieved manually controlling the robot.