Related Experiment Video
Updated: Jul 10, 2026
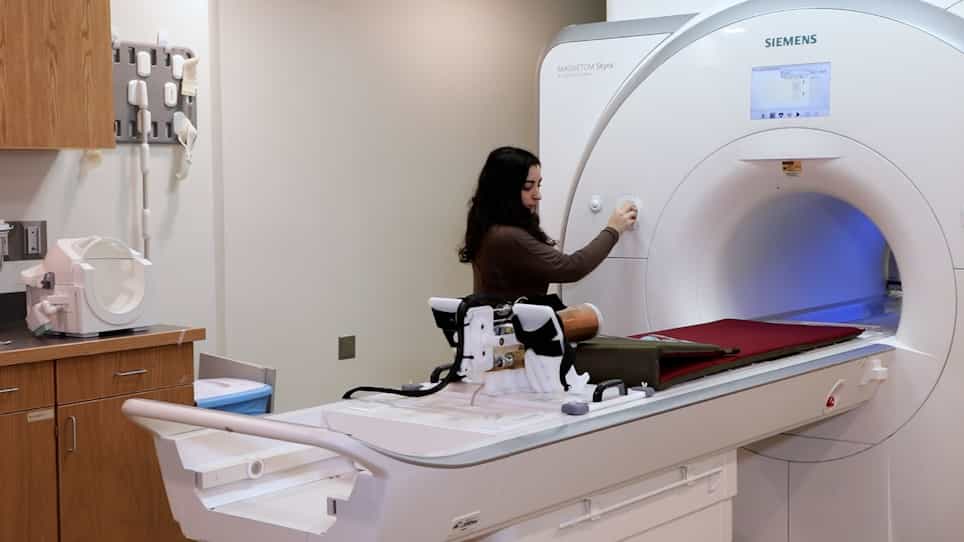

Use of a Foot-Induced Digitally Controlled Resistance Device for Functional Magnetic Resonance Imaging Evaluation in Patients with Foot Paresis
Published on: July 7, 2023
FlexCVA: a continuously variable actuator for active orthotics
Robert W Horst1, Richard R Marcus
1Tibion Corp., Moffett Field, CA 94035, USA. bob.horst@tibion.com

Abstract:
Active orthotic devices require actuators with high torque, a free movement mode, high efficiency, and small size and weight. The FlexCVA is a new type of actuator that addresses these requirements in a unique way. It provides continuously varying torque through the use of two belts alternately deflected by cams. The belts alternate in supplying output torque with one belt pulling the output while the slack is removed from the other belt. The drive ratio is automatically adjusted in response to the load by varying the deflection distance of the belts. The resulting actuator prototype has been demonstrated to supply up to 34 Nm of output torque, and its free movement mode allows it to be backdriven at speeds greater than 400 deg/sec.

Related Concept Videos
 01:26
Oral Drug Delivery Systems: Continuous-Release Systems
 01:10
Ankle Joint
 01:15
Torque Free Motion
 01:20
Motor Unit Stimulation
The latent period of contraction marks the onset of excitation-contraction coupling, when the action potential propagates across the sarcolemma, preparing the muscle fibers for contraction. As the fibers enter the contraction phase, the...
 01:30
Modified-Release Drug Delivery Systems: Stimuli-Activated
 01:10
Bones of the Lower Limb: Tibia and Fibula