Related Experiment Video
Updated: Jul 10, 2026


Deep-Learning Based Multi-Joint Synchronous Tracking for Objective Quantification of Hindlimb Locomotor Kinematics in Rats
Published on: April 3, 2026
The formation of trajectories during goal-oriented locomotion in humans. II. A maximum smoothness model
Quang-Cuong Pham1, Halim Hicheur, Gustavo Arechavaleta
1Laboratoire de Physiologie de Perception et de l'Action, Collège de France, CNRS UMR7152, 11 place Marcelin Berthelot, 75005 Paris, France. cuong.pham@normalesup.org

Abstract:
Despite the theoretically infinite number of possible trajectories a human may take to reach a distant doorway, we observed that locomotor trajectories corresponding to this task were actually stereotyped, both at the geometric and the kinematic levels. In this paper, we propose a computational model for the formation of human locomotor trajectories. Our model is adapted from smoothness maximization models that have been studied in the context of hand trajectory generation. The trajectories predicted by our model are very similar to the experimentally recorded ones. We discuss the theoretical implications of this result in the context of movement planning and control in humans. In particular, this result supports the hypothesis that common principles, such as smoothness maximization, may govern the generation of very different types of movements (in this case, hand movements and whole-body movements).

Related Concept Videos
 01:26
Orthogonal Trajectories
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:23
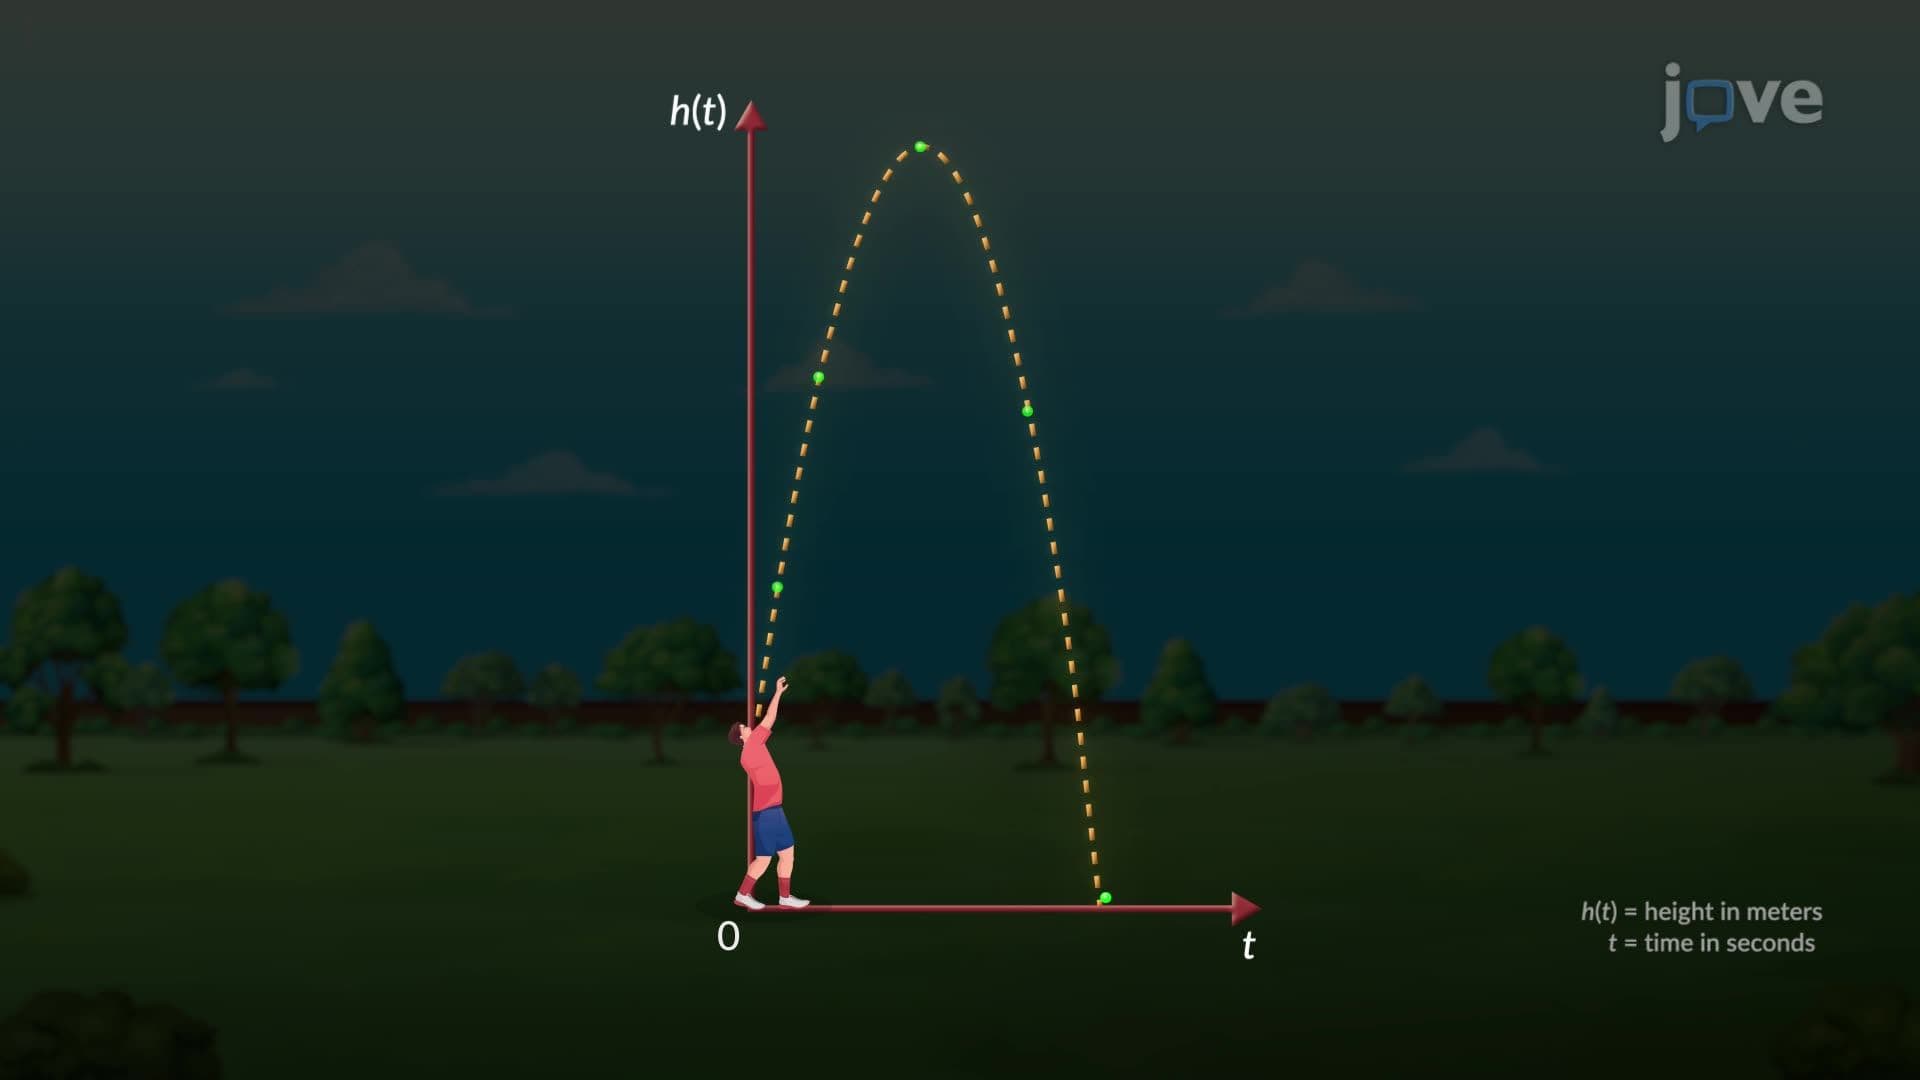
Quadratic Models
 01:25
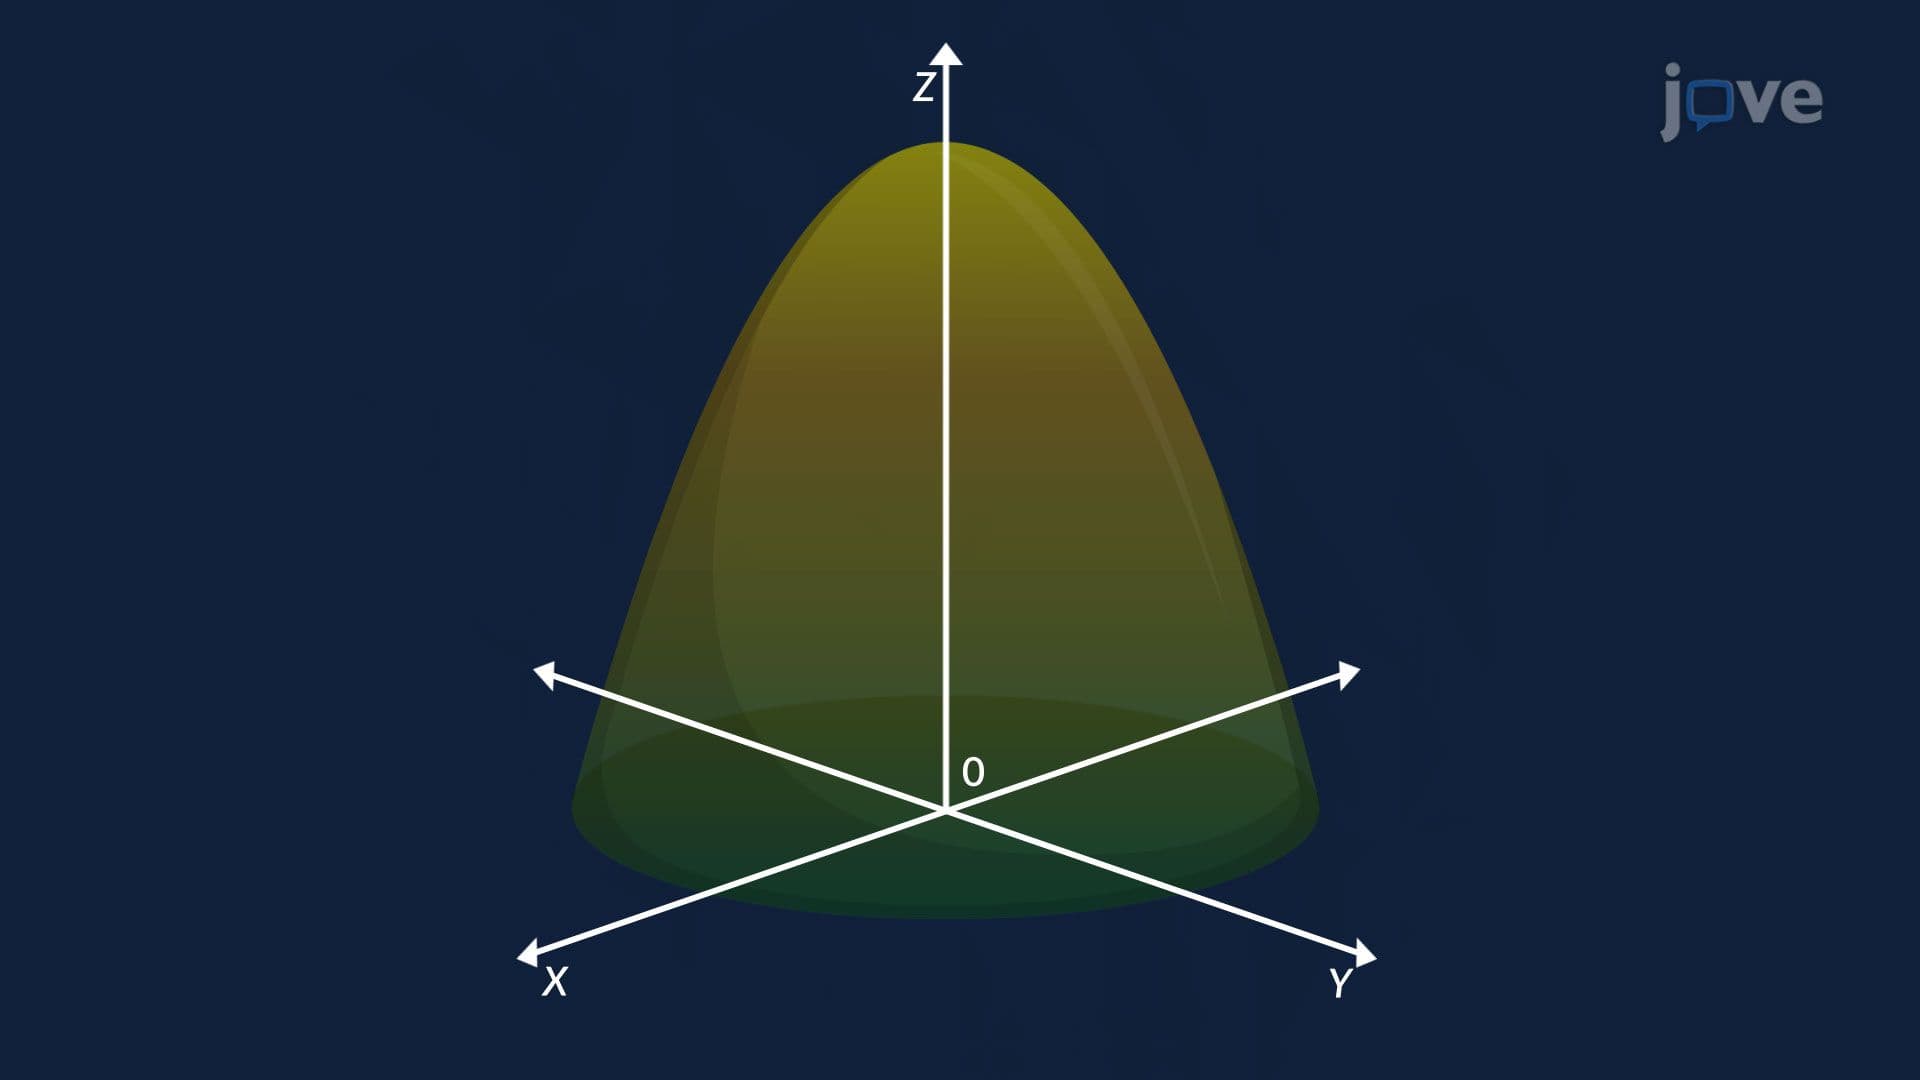
Maximizing the Directional Derivative