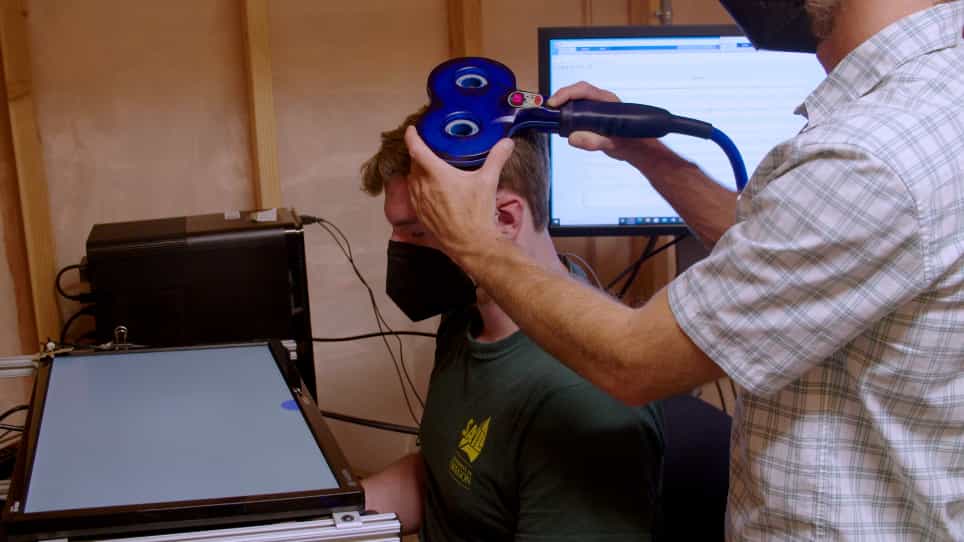
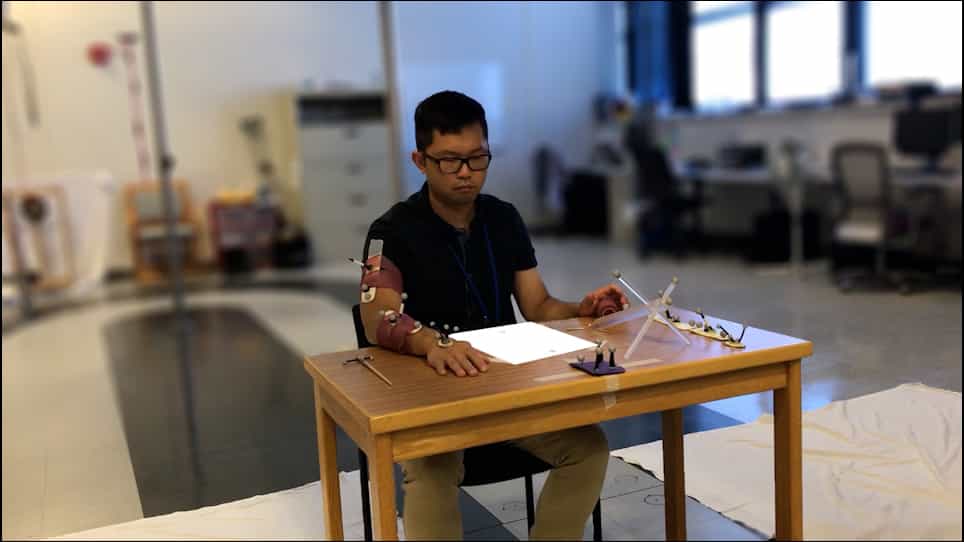
Related Experiment Video
Updated: Jul 10, 2026


Estimation of Contact Regions Between Hands and Objects During Human Multi-Digit Grasping
Published on: April 21, 2023
Formation of an internal model of environment dynamics during upper limb reaching movements: a fuzzy approach
Chad MacDonald1, Zahra Moussavi, Thompson Sarkodie-Gyan
1Electrical and Computer Engineering, University of Texas, El Paso, El Paso, TX 79968, USA. cemacdonald@utep.edu

Abstract:
This paper presents the development and simulation of a fuzzy logic based learning mechanism to emulate human motor learning. In particular, fuzzy inference was used to develop an internal model of a novel dynamic environment experienced during planar reaching movements with the upper limb. A dynamic model of the human arm was developed and a fuzzy if-then rule base was created to relate trajectory movement and velocity errors to internal model update parameters. An experimental simulation was performed to compare the fuzzy system's performance with that of human subjects. It was found that the dynamic model behaved as expected, and the fuzzy learning mechanism created an internal model that was capable of opposing the environmental force field to regain a trajectory closely resembling the desired ideal.