Error generalization as a function of velocity and duration: human reaching movements
Related Experiment Video
Updated: Jul 10, 2026
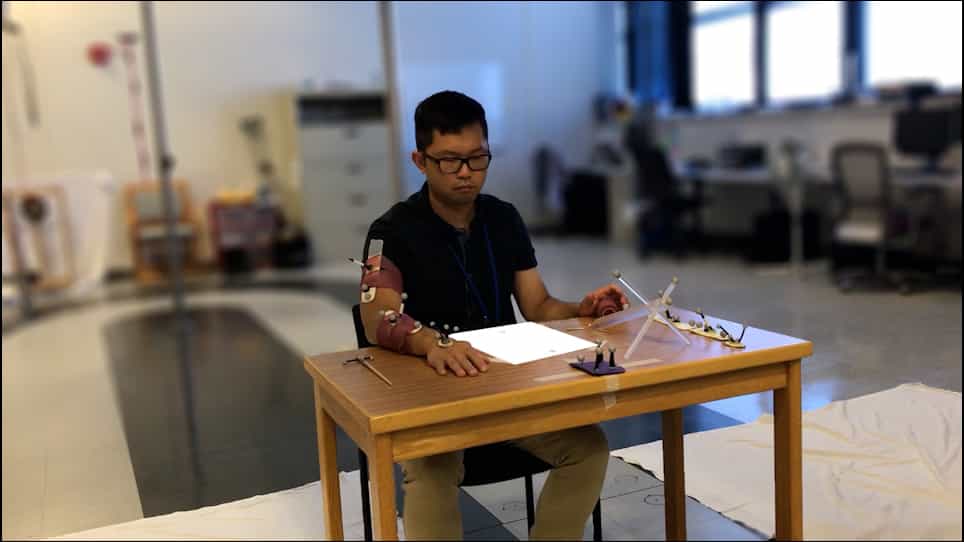
The Impact of Motor Task Conditions on Goal-Directed Arm Reaching Kinematics and Trunk Compensation in Chronic Stroke Survivors
Published on: May 2, 2021
1Department of Physiology and Pharmacology, State University of New York Downstate School of Medicine, 450 Clarkson Ave., Brooklyn, NY 11203, USA. joe.francis@downstate.edu

Abstract:
Our sensory-motor control system has a remarkable ability to adapt to novel dynamics during reaching movements and generalizes this adaptation to movements made in different directions, positions and even speeds. The degree and pattern of this generalization are of great importance in deducing the underlying mechanisms that govern our motor control. In this report we expand our knowledge on the generalization between movements made at different speeds. We wished to determine the pattern of generalization between different speed and duration movements on a trial-by-trial basis. In addition, we tested three hypotheses for the pattern of generalization. The first hypothesis was that the generalization was maximum for the speed of the movement just made with a linear decrease in generalization as one moves away from that preferred speed. The second was that the generalization is always highest for the fastest speed movements and linearly decreases with speed. The last hypothesis came from our preliminary results, which suggested that the generalization plateaus. Human subjects made targeted reaching movements at four different maximum speeds (15, 35, 55 and 75 cm/s) presented in pseudorandom order to one spatial target (15 cm extent) while holding onto a robotic manipulandum that produced a viscous curl field. Catch trials (trial where the curl field was unexpectedly removed) were used to probe the generalization between the four speed/durations on a movement-by-movement basis. We found that the pattern of generalization was linear between the first three speed categories (15-55 cm/s), but plateaued after the 55 cm/s category. We compared the subjects' results with a simulated adaptive controller that used a population code by combining the output of basis elements. These basis elements encoded limb velocity and associated this with a force expectation at that velocity. We found that using a basis set of Gaussians the adaptive controller produced movements that generalized in virtually the exact manner as the subjects, as we have previously demonstrated for movements made to different spatial targets. Thus, the human internal model may employ such a population code.
Related Concept Videos
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:18
Velocity of an Object
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:12
Average Velocity
 01:12
Average and Instantaneous Velocity Vectors
 01:30
Vector Functions and Motion: Problem Solving