Related Experiment Video
Updated: Jul 9, 2026
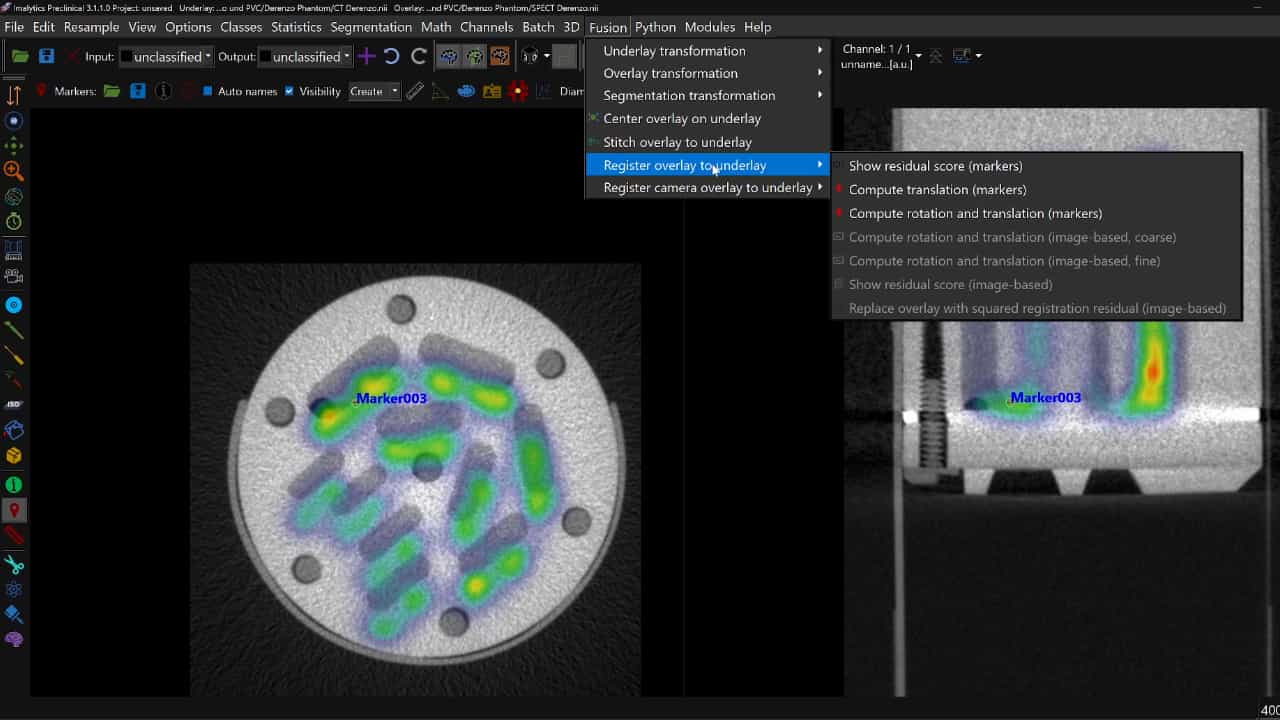
Multimodal Cross-Device and Marker-Free Co-Registration of Preclinical Imaging Modalities
Published on: October 27, 2023
On fiducial target registration error in the presence of anisotropic noise
Burton Ma1, Mehdi H Moghari, Randy E Ellis
1Human Mobility Research Centre, Kingston General Hospital, Kingston, Ontario, Canada. mab@cs.queensu.ca

Abstract:
We study the effect of anisotropic noise on target registration error (TRE) by using a tracked and calibrated stylus tip as the fiducial registration application. We present a simple, efficient unscented Kalman filter algorithm that is suitable for fiducial registration even with a small number of fiducials. We also derive an equation that predicts TRE under anisotropic noise. The predicted TRE values are shown to closely match the simulated TRE values achieved using our UKF-based algorithm.