Three-view multibody structure from motion
Related Experiment Video
Updated: Jul 9, 2026
Four-Dimensional CT Analysis Using Sequential 3D-3D Registration
Published on: November 23, 2019
1Department of Biomedical Engineering, The Johns Hopkins University, Baltimore, MD 21218, USA. rvidal@cis.jhu.edu

Abstract:
We propose a geometric approach to 3-D motion segmentation from point correspondences in three perspective views. We demonstrate that after applying a polynomial embedding to the point correspondences they become related by the socalled multibody trilinear constraint and its associated multibody trifocal tensor, which are natural generalizations of the trilinear constraint and the trifocal tensor to multiple motions. We derive a rank constraint on the embedded correspondences, from which one can estimate the number of independent motions as well as linearly solve for the multibody trifocal tensor. We then show how to compute the epipolar lines associated with each image point from the common root of a set of univariate polynomials and the epipoles by solving a pair of plane clustering problems using Generalized PCA (GPCA). The individual trifocal tensors are then obtained from the second order derivatives of the multibody trilinear constraint. Given epipolar lines and epipoles, or trifocal tensors, one can immediately obtain an initial clustering of the correspondences. We use this clustering to initialize an iterative algorithm that alternates between the computation of the trifocal tensors and the segmentation of the correspondences. We test our algorithm on various synthetic and real scenes, and compare with other algebraic and iterative algorithms.
Related Concept Videos
 01:30
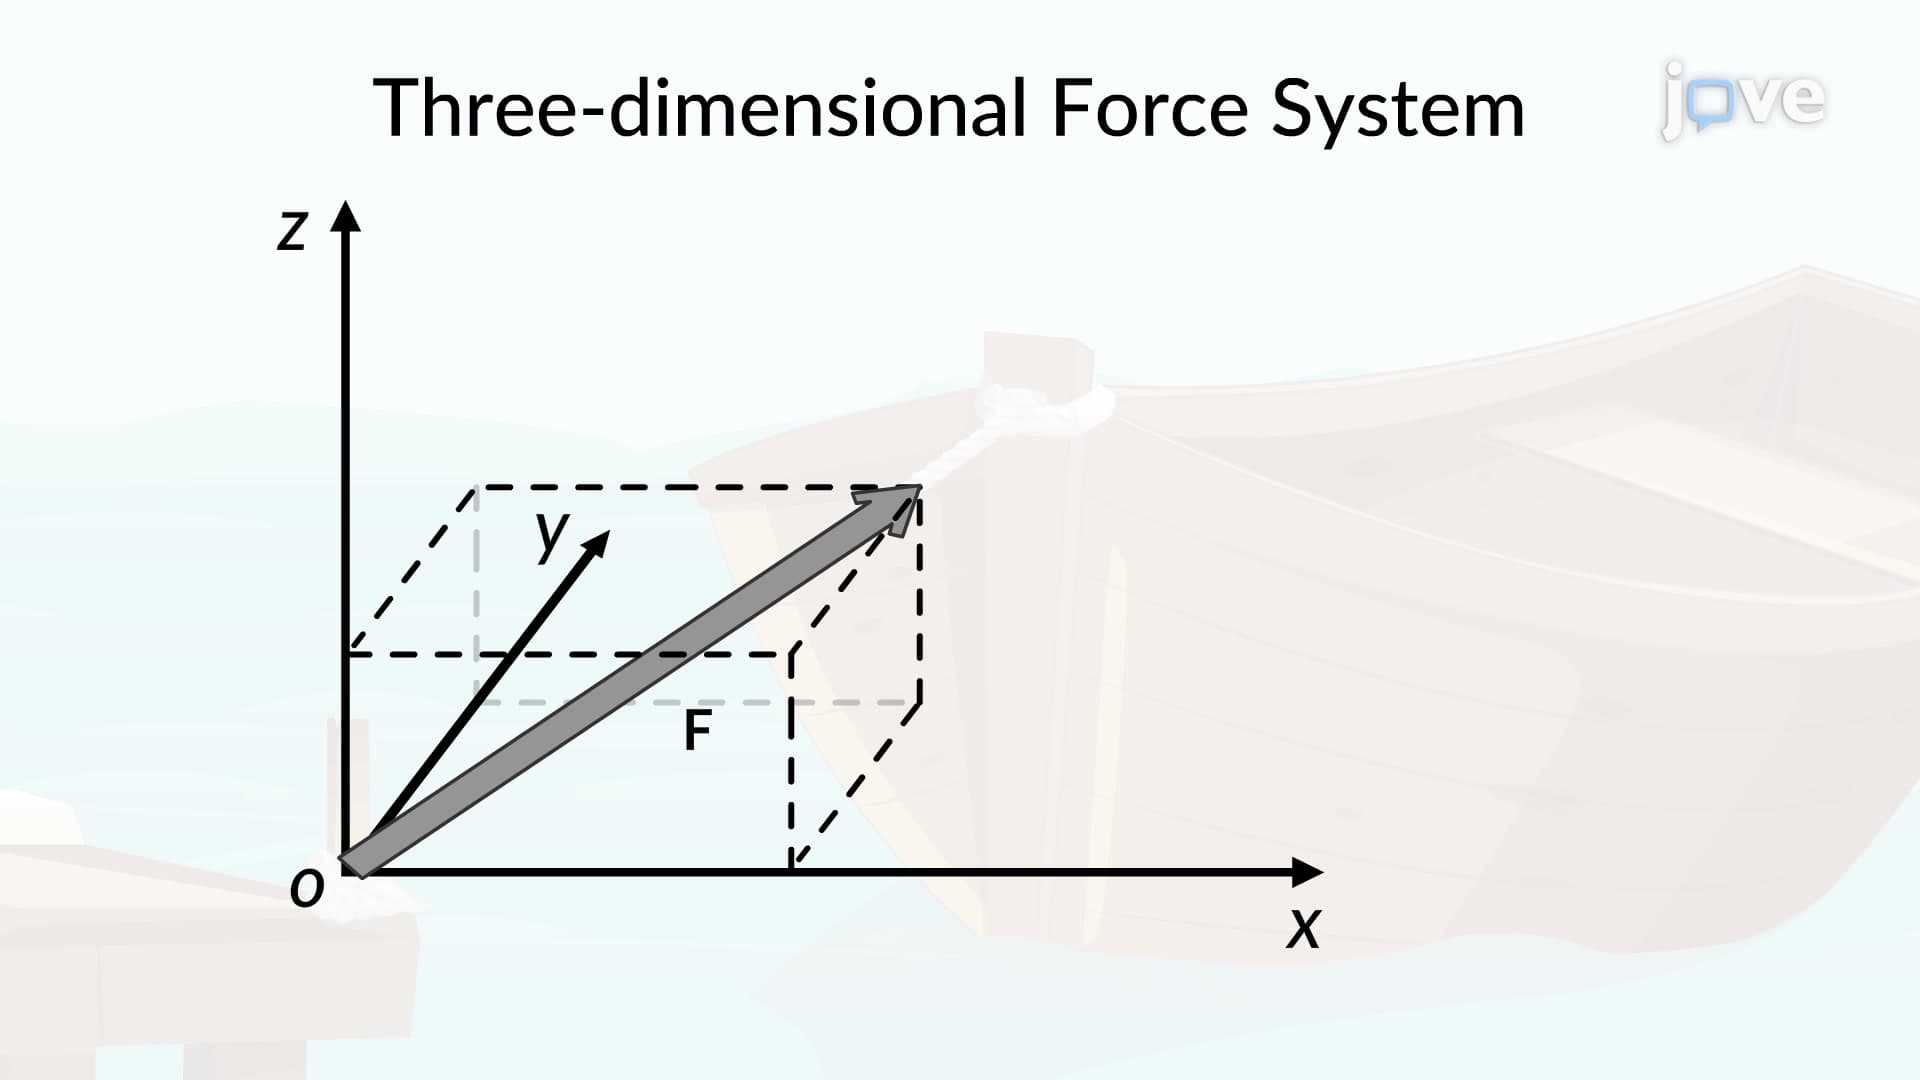
Three-Dimensional Force System
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:18
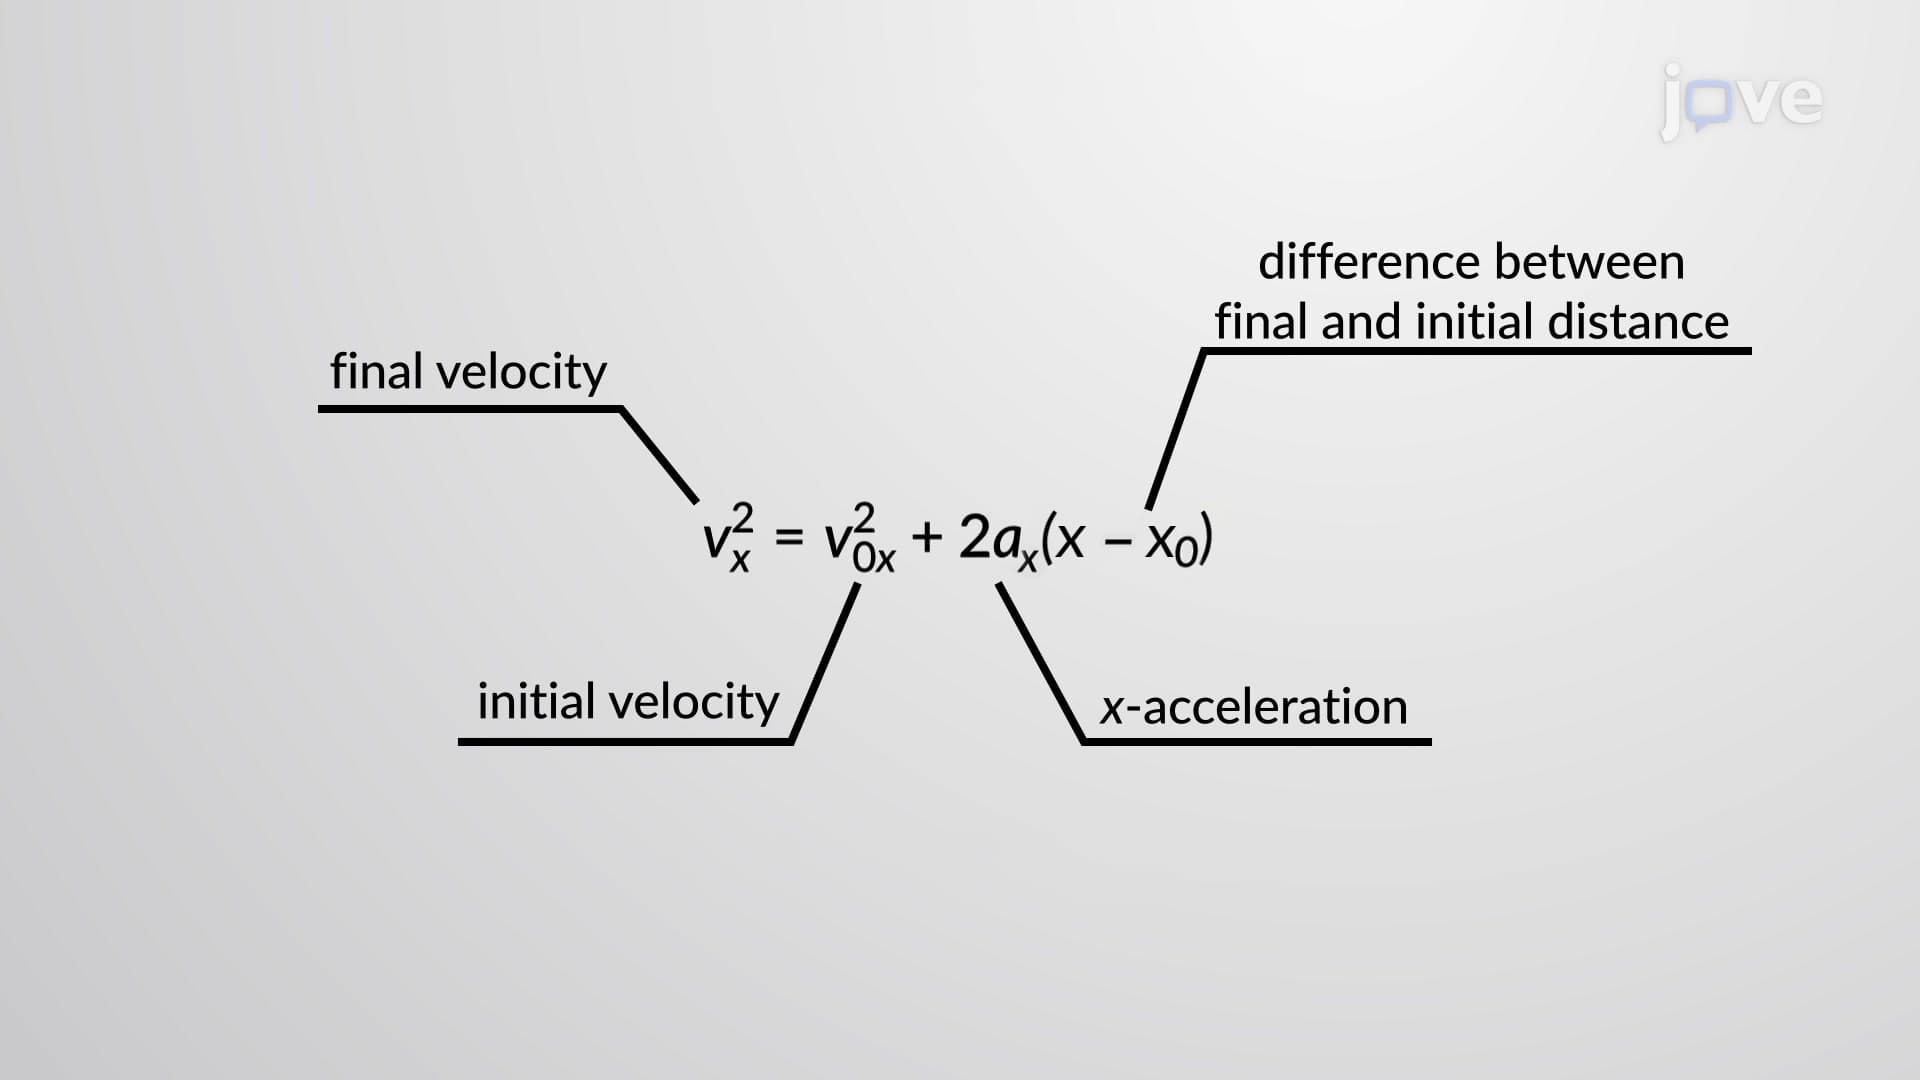
Kinematic Equations - III
Using the kinematic equations,...