Gaussian process dynamical models for human motion
Related Experiment Video
Updated: Jul 9, 2026
Simulation of Human-induced Vibrations Based on the Characterized In-field Pedestrian Behavior
Published on: April 13, 2016
Jack M Wang1, David J Fleet, Aaron Hertzmann
1Department of Computer Science, University of Toronto, 40 St. George Street, Toronto, Ontario M5S 2E4 Canada. jmwang@dgp.toronto.edu

Abstract:
We introduce Gaussian process dynamical models (GPDM) for nonlinear time series analysis, with applications to learning models of human pose and motion from high-dimensionalmotion capture data. A GPDM is a latent variable model. It comprises a low-dimensional latent space with associated dynamics, and a map from the latent space to an observation space. We marginalize out the model parameters in closed-form, using Gaussian process priors for both the dynamics and the observation mappings. This results in a non-parametric model for dynamical systems that accounts for uncertainty in the model. We demonstrate the approach, and compare four learning algorithms on human motion capture data in which each pose is 50-dimensional. Despite the use of small data sets, the GPDM learns an effective representation of the nonlinear dynamics in these spaces.

Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:23
Quadratic Models
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:17
Kinematic Equations - II
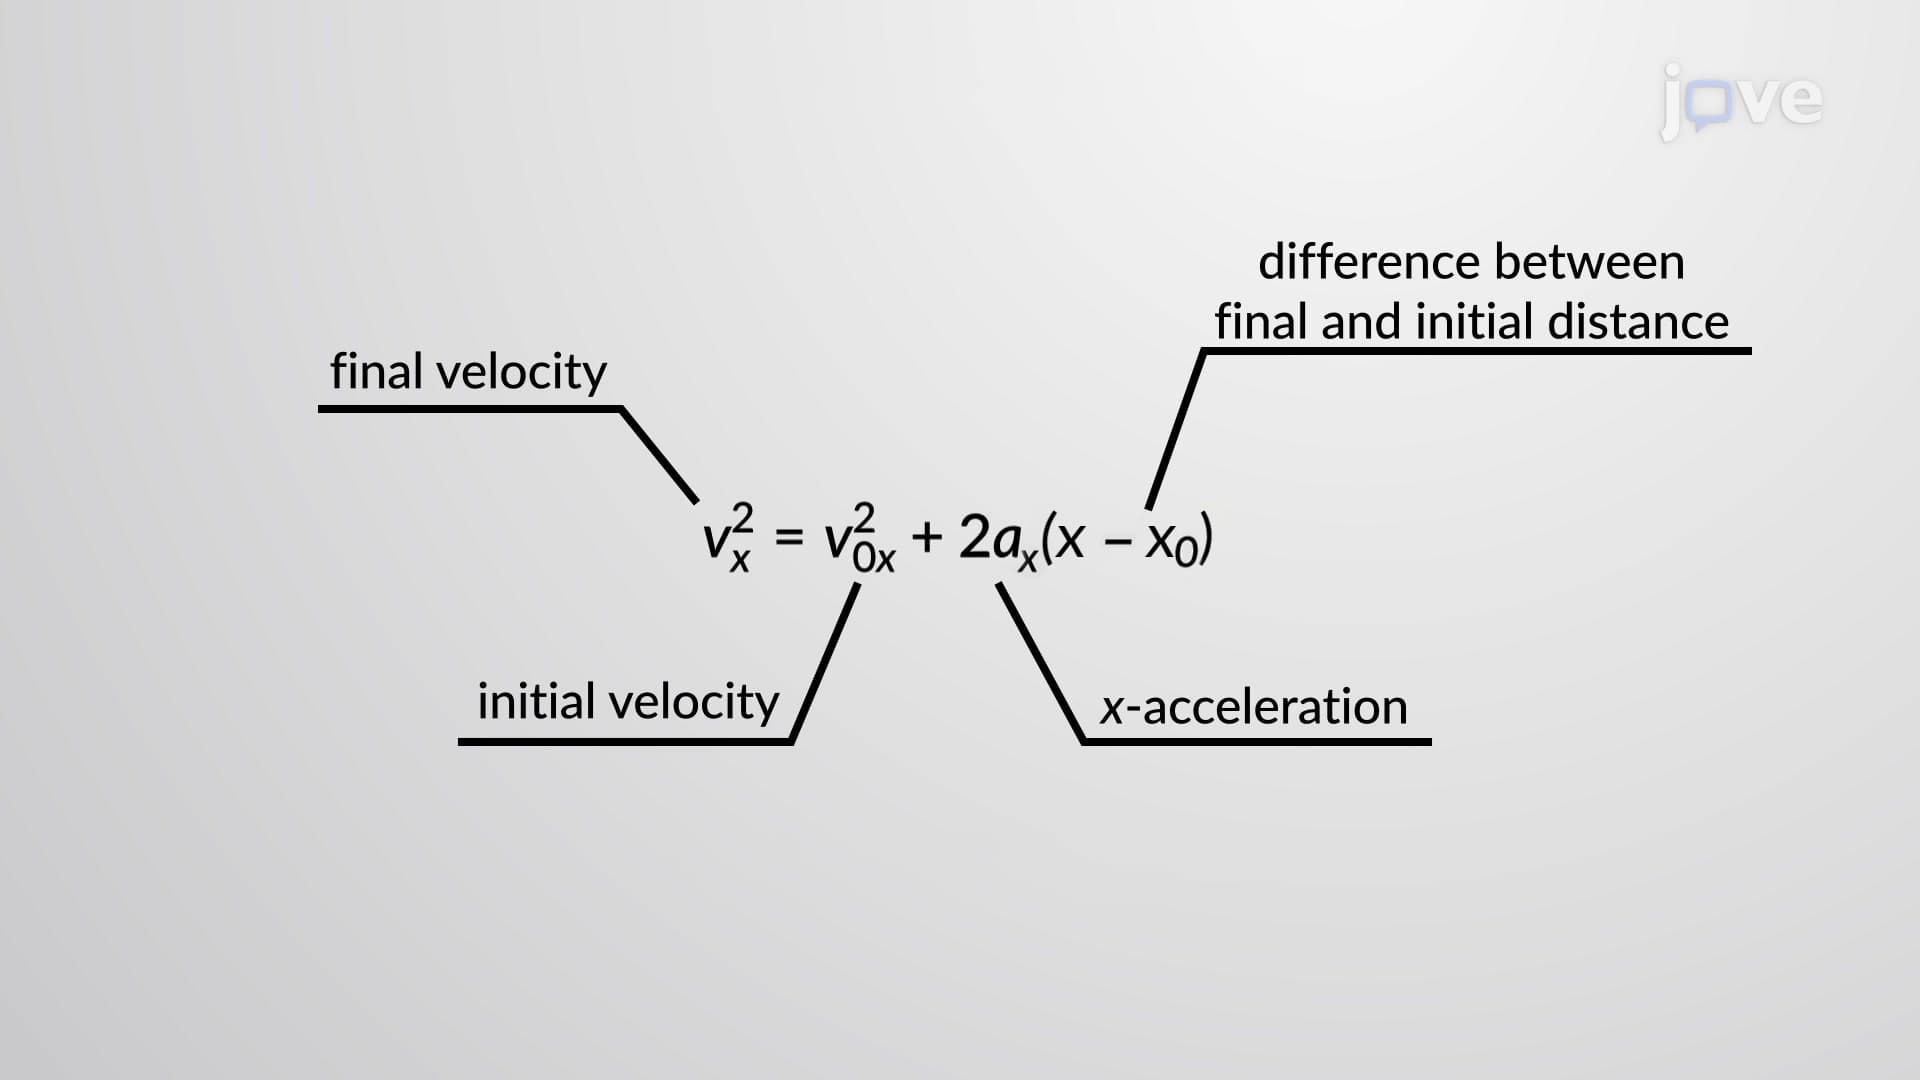
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...
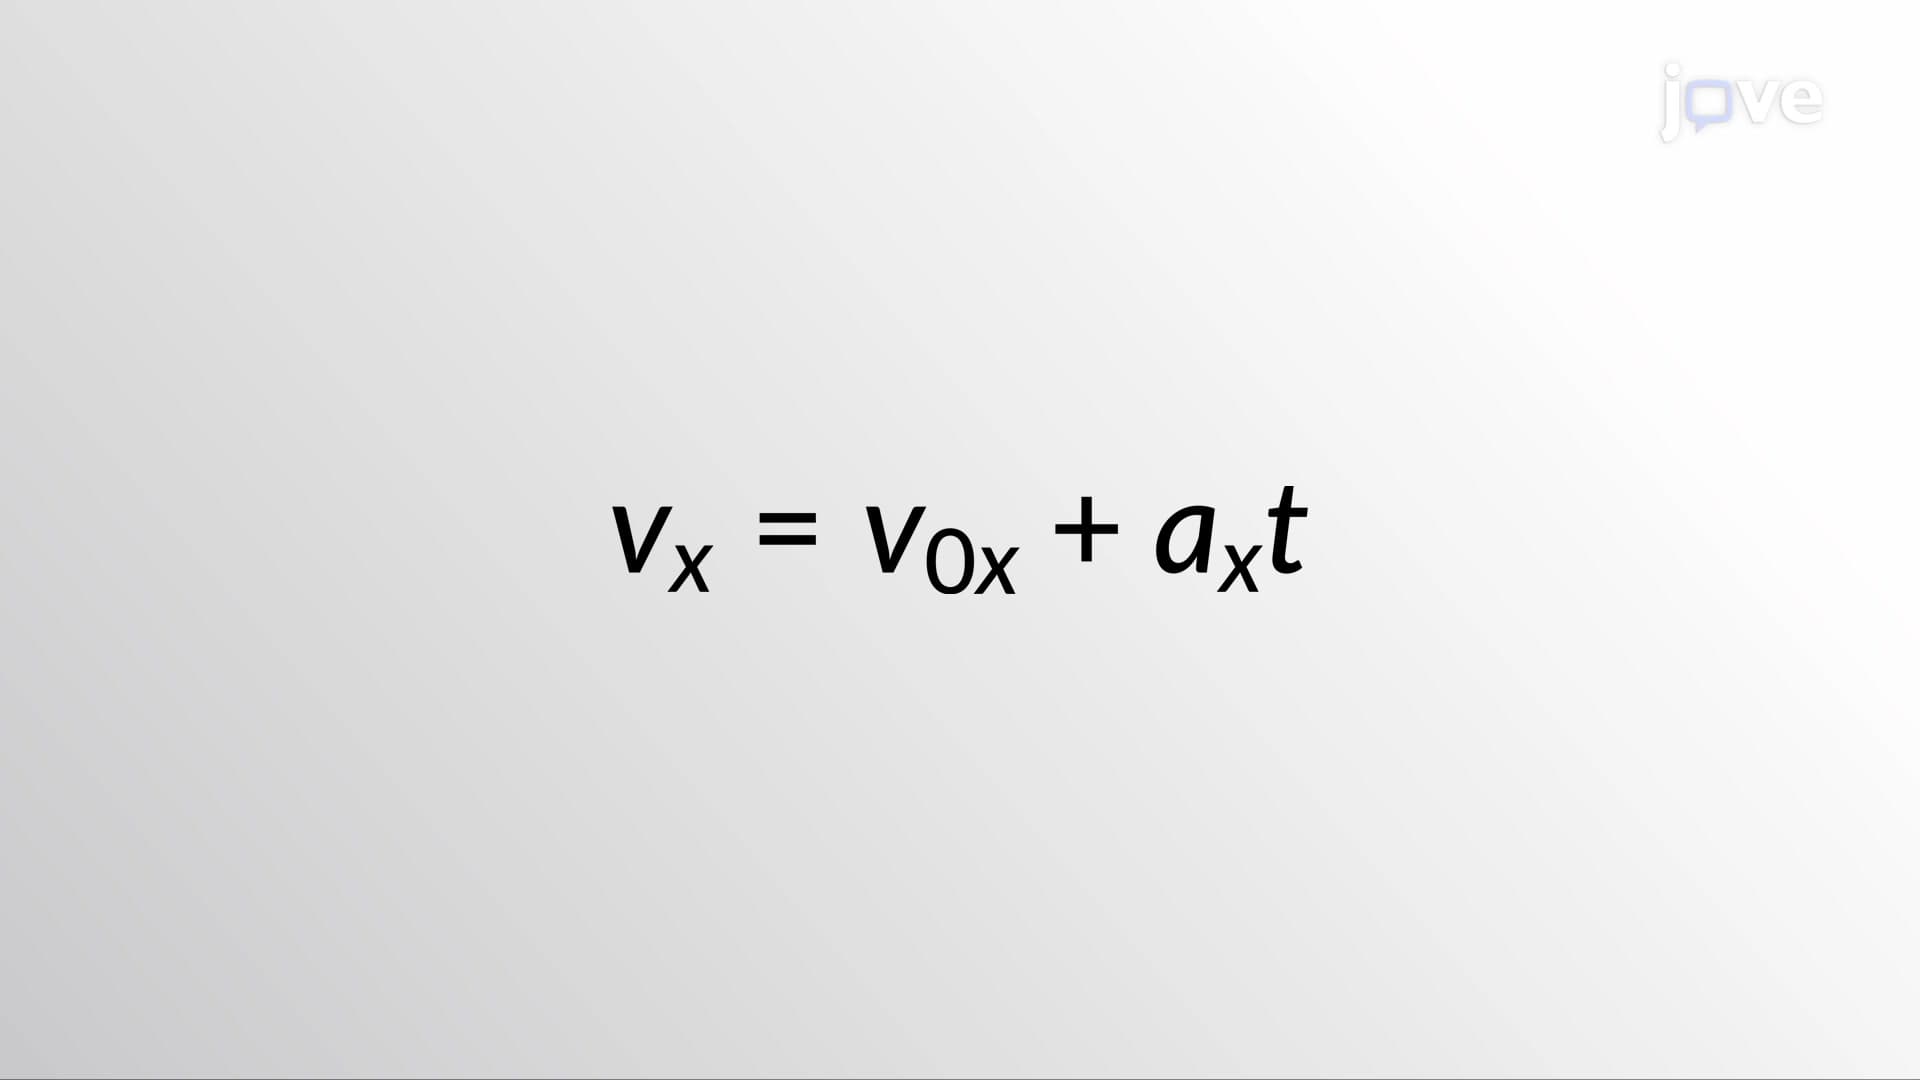 01:26
Kinematic Equations - I