Related Experiment Video
Updated: Jul 9, 2026
Age-dependent Dynamics of Locomotion in Caenorhabditis elegans: A Lyapunov Exponent Analysis
Published on: September 23, 2025
Dynamics and computation of continuous attractors
Si Wu1, Kosuke Hamaguchi, Shun-Ichi Amari
1Department of Informatics, University of Sussex, Brighton BN1 9QH, U.K. siwu@sussex.ac.uk

Abstract:
Continuous attractor is a promising model for describing the encoding of continuous stimuli in neural systems. In a continuous attractor, the stationary states of the neural system form a continuous parameter space, on which the system is neutrally stable. This property enables the neutral system to track time-varying stimuli smoothly, but it also degrades the accuracy of information retrieval, since these stationary states are easily disturbed by external noise. In this work, based on a simple model, we systematically investigate the dynamics and the computational properties of continuous attractors. In order to analyze the dynamics of a large-size network, which is otherwise extremely complicated, we develop a strategy to reduce its dimensionality by utilizing the fact that a continuous attractor can eliminate the noise components perpendicular to the attractor space very quickly. We therefore project the network dynamics onto the tangent of the attractor space and simplify it successfully as a one-dimensional Ornstein-Uhlenbeck process. Based on this simplified model, we investigate (1) the decoding error of a continuous attractor under the driving of external noisy inputs, (2) the tracking speed of a continuous attractor when external stimulus experiences abrupt changes, (3) the neural correlation structure associated with the specific dynamics of a continuous attractor, and (4) the consequence of asymmetric neural correlation on statistical population decoding. The potential implications of these results on our understanding of neural information processing are also discussed.
Related Concept Videos
 01:31
Classification of Systems-II
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system.
 01:14
Energy Diagrams - I
Take the example of a skater on a parabolic ramp. The potential energy at different points along the ramp will be proportional to the height of the ramp, which varies quadratically with the horizontal position on the ramp. As the skater moves down the ramp from the highest position,...
 01:19
Limits with Oscillating Discontinuities
 01:24
Convolution: Math, Graphics, and Discrete Signals
To simplify the convolution integral, it is assumed that both the input signal and impulse response are zero for negative time values. The graphical convolution process...
 01:28
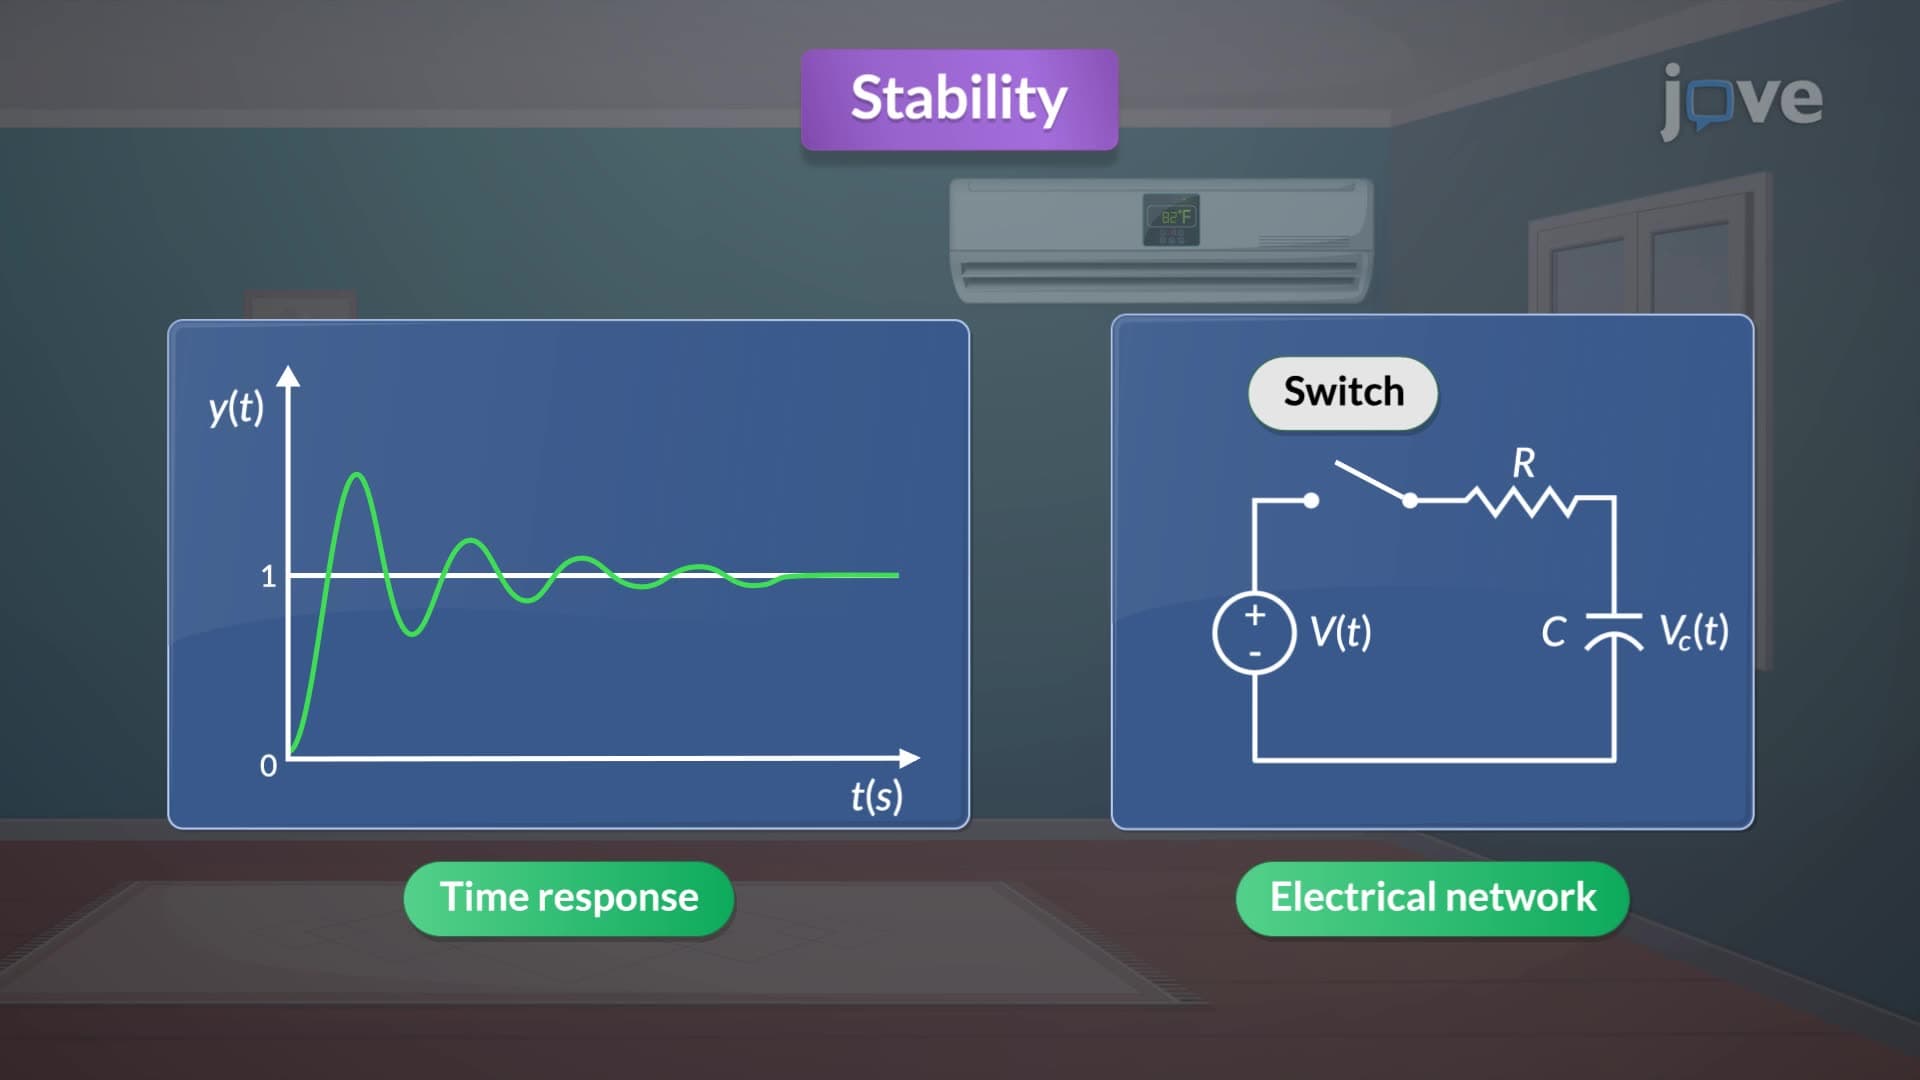
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...