Related Experiment Video
Updated: Jul 9, 2026


Sit-to-stand-and-walk from 120% Knee Height: A Novel Approach to Assess Dynamic Postural Control Independent of Lead-limb
Published on: August 30, 2016
Point-based rigid-body registration using an unscented Kalman filter
Mehdi Hedjazi Moghari1, Purang Abolmaesumi
1Department of Electrical and Computer Engineering, Queen's University, Kingston ON K7L 3N6, Canada.

Abstract:
We present and validate a novel registration algorithm mapping two data sets, generated from a rigid object, in the presence of Gaussian noise. The proposed method is based on the Unscented Kalman Filter (UKF) algorithm that is generally employed for analyzing nonlinear systems corrupted by additive Gaussian noise. First, we employ our proposed registration algorithm to fit two randomly generated data sets in the presence of isotropic Gaussian noise, when the corresponding points between the two data sets are assumed to be known. Then, we extend the registration method to the case where the data (with known correspondences) is stimulated by anisotropic Gaussian noise. The new registration method not only reliably converges to the correct registration solution, but it also estimates the variance, as a confidence measure, for each of the estimated registration transformation parameters. Furthermore, we employ the proposed registration algorithm for rigid-body, point-based registration where corresponding points between two registering data sets are unknown. The algorithm is tested on point data sets which are garnered from a pelvic cadaver and a scaphoid bone phantom by means of computed tomography (CT) and tracked free-hand ultrasound imaging. The collected 3-D points in the ultrasound frame are registered to the 3-D meshes in the CT frame by using the proposed and the standard Iterative Closest Points (ICP) registration algorithms. Experimental results demonstrate that our proposed method significantly outperforms the ICP registration algorithm in the presence of additive Gaussian noise. It is also shown that the proposed registration algorithm is more robust than the ICP registration algorithm in terms of outliers in data sets and initial misalignment between the two data sets.
More Related Videos

Related Concept Videos
 01:21
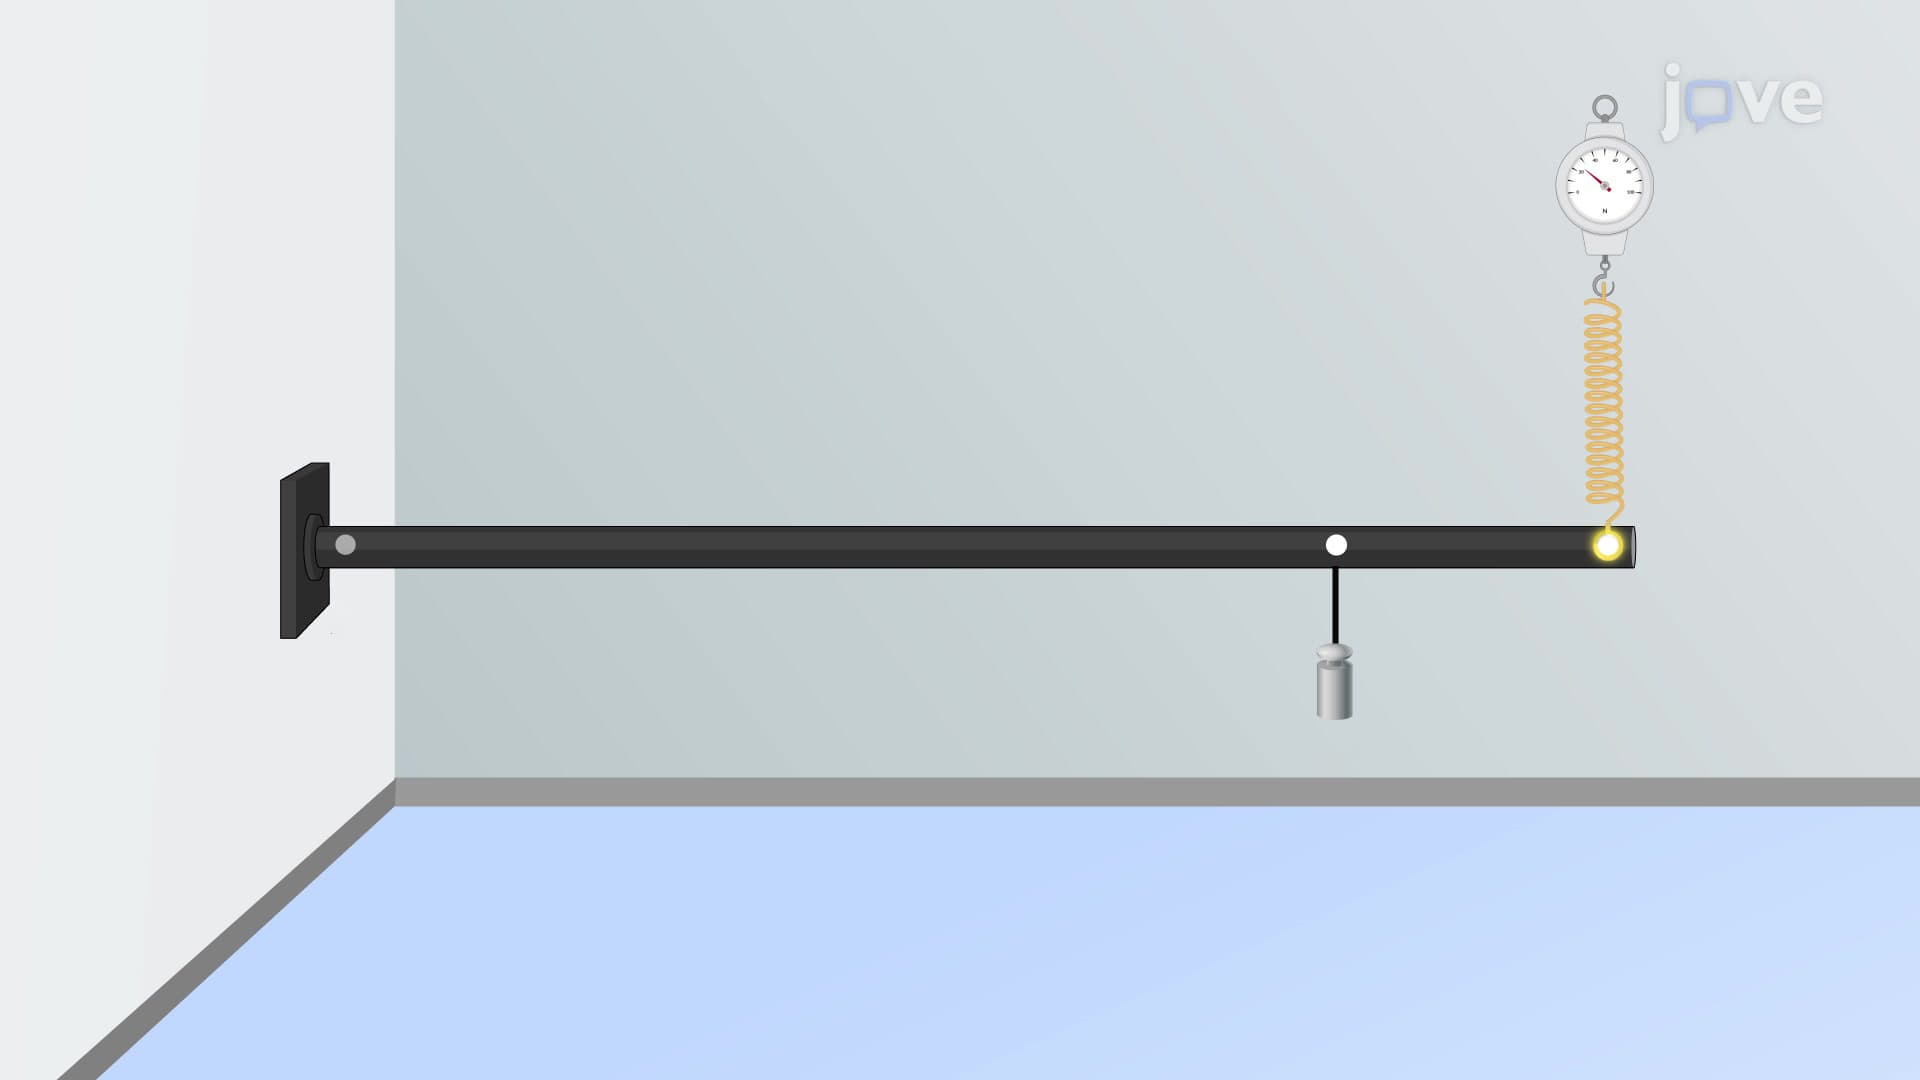
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 00:49
Rigid Body Equilibrium Problems - I
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:13
Kinetic Energy for a Rigid Body
 01:12
Equation of Motion for a Rigid Body
The combined moments generated about the center of mass of the object are equal to the rate of change of the angular momentum of the body. An external force, when applied at a different point...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...