Related Experiment Video
Updated: Jul 8, 2026

Uncovering Beat Deafness: Detecting Rhythm Disorders with Synchronized Finger Tapping and Perceptual Timing Tasks
Published on: March 16, 2015
The effects of metronomic pendular adjustment versus tap-tempo input on the stability and accuracy of tempo
1Music Science Research, Department of the Arts, Ben-Gurion University of the Negev, P.O. Box 653, Beer-Sheva, 84105, Israel. wbrodsky@bgumail.bgu.ac.il

Abstract:
This study explores tempo stability and accuracy while comparing two subject-response modes: the traditional metronomic pendular adjustment task versus tap-tempo input. Experiment 1 questioned if a single correct tempo measurement consistently emerges from repeated listenings, and if subject-response mode affects tempo stability and accuracy. Experiment 2 assessed incremental improvement between two repeated sessions, and questioned the incidence of self-pacing or congruent effects of potential delays on tempo responses. While single-session studies have shown that listeners find some tempos more enjoyable, can notice discrete differences in pace, and can remember rhythmic speed over prolonged periods of time, the current study employs a multiple-session format focusing on two diametrically opposed subject-response modes. The findings show that tempo responses by listeners without formal music training were consistent across listening sessions, and that responses from tap-tempo input were significantly more stable and accurate than responses from metronomic pendular adjustment tasks.
Related Concept Videos
 01:28
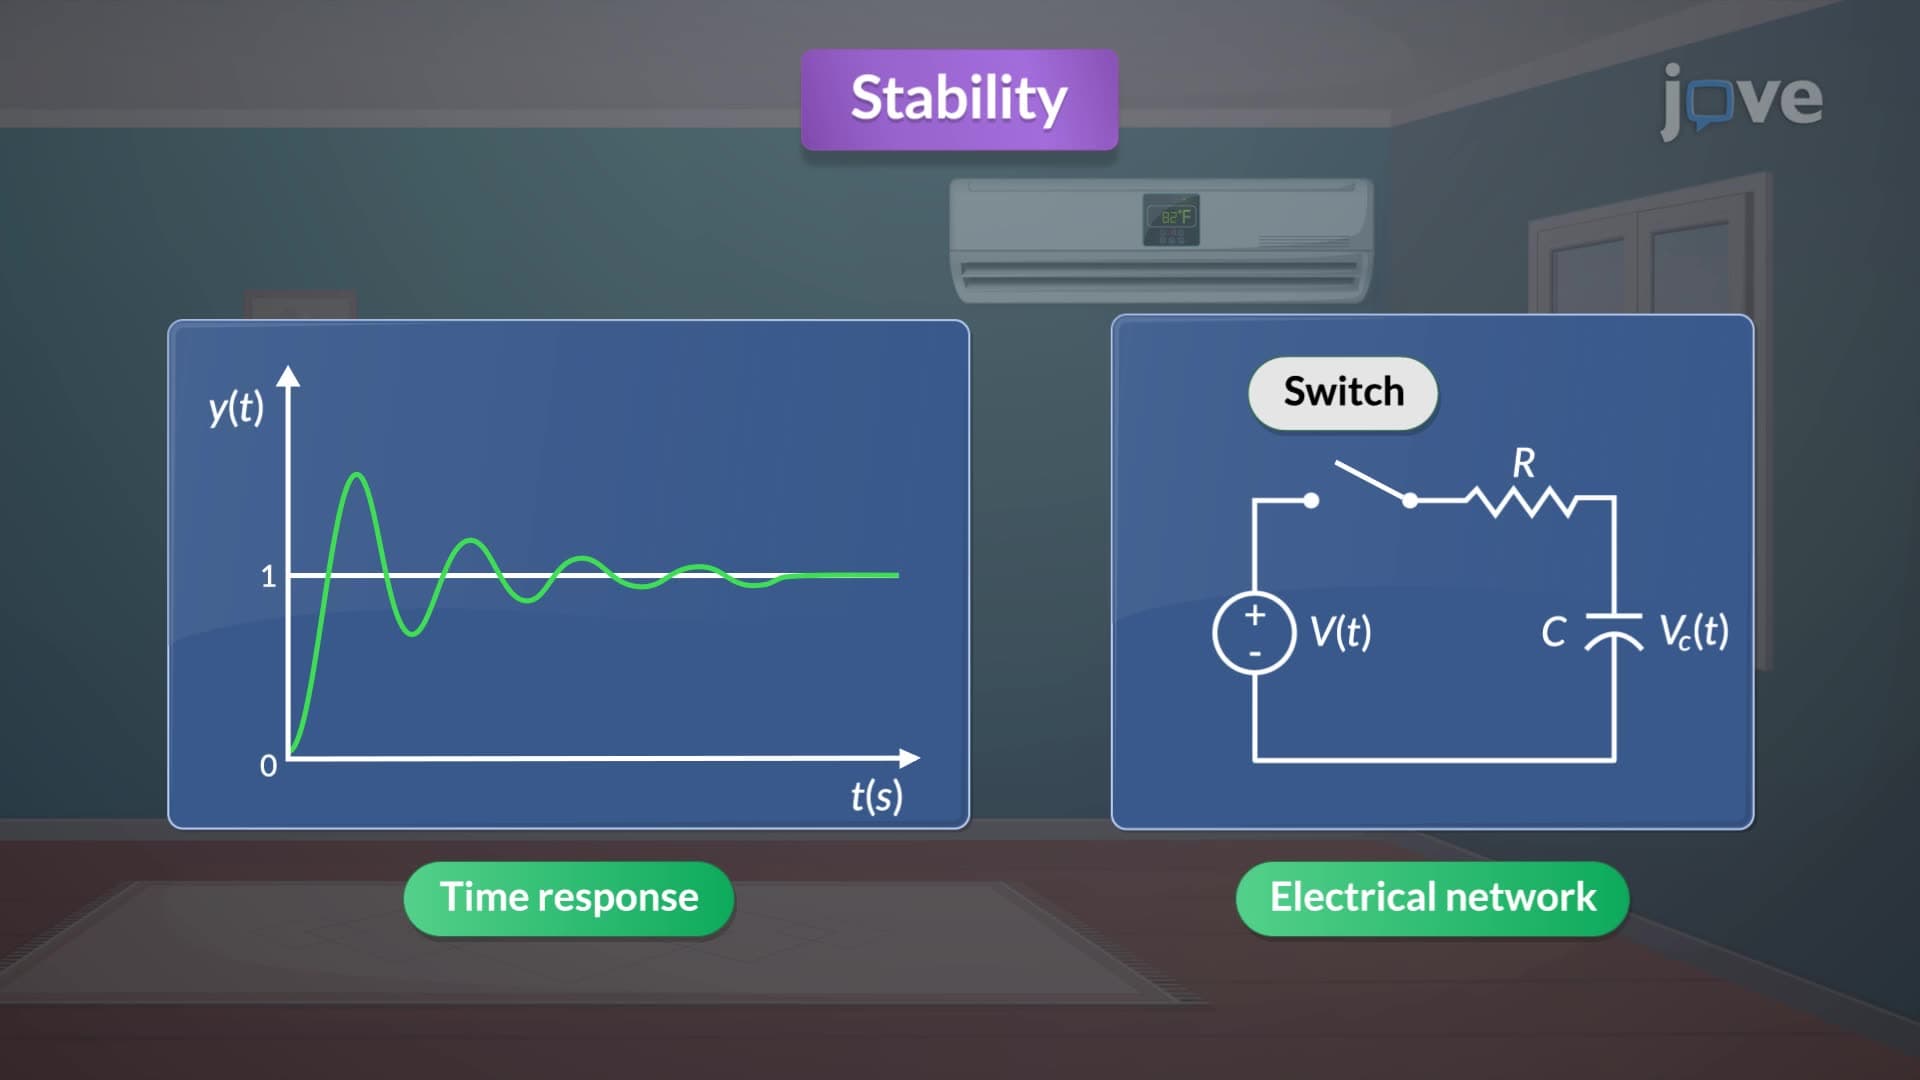
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:18
Errors in Taping
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:06
Physical Pendulum
When dealing with complicated systems, the mass moment of inertia is an important parameter, as it describes the mass...
 01:10
Simple Pendulum
The period of a simple pendulum depends on two factors: its length and the acceleration due to gravity. The period is completely independent of any other factors, such as mass or maximum displacement. For small displacements, a pendulum is...