Related Experiment Video
Updated: Jul 7, 2026
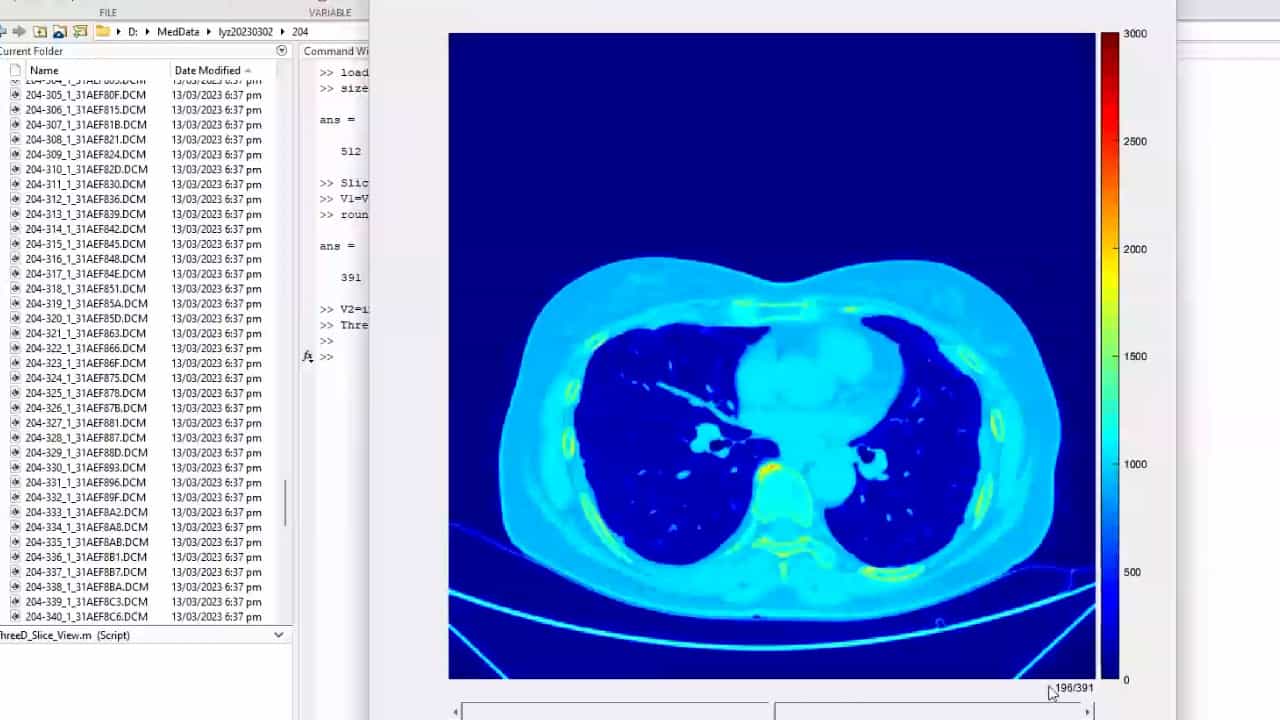
Three-Dimensional Reconstruction for the Whole Lung with Early Multiple Pulmonary Nodules
Published on: October 13, 2023
One-dimensional dense disparity estimation for three-dimensional reconstruction
Lionel Oisel1, Etienne Mémin, Luce Morin
1IRISA, Campus de Beaulieu, 35042 Rennes, France.

Abstract:
We present a method for fully automatic three-dimensional (3D) reconstruction from a pair of weakly calibrated images in order to deal with the modeling of complex rigid scenes. A two-dimensional (2D) triangular mesh model of the scene is calculated using a two-step algorithm mixing sparse matching and dense motion estimation approaches. The 2D mesh is iteratively refined to fit any arbitrary 3D surface. At convergence, each triangular patch corresponds to the projection of a 3D plane. The proposed algorithm relies first on a dense disparity field. The dense field estimation modelized within a robust framework is constrained by the epipolar geometry. The resulting field is then segmented according to homographic models using iterative Delaunay triangulation. In association with a weak calibration and camera motion estimation algorithm, this 2D planar model is used to obtain a VRML-compatible 3D model of the scene.
Related Concept Videos
 01:15
Depth Perception and Spatial Vision
 01:20
Divergence Theorem in 3D Space
 01:28
Cylinders in Three-Dimensional Space
 01:29
Three-Dimensional Analysis of Strain
 01:05
Estimation of the Physical Quantities