Related Experiment Video
Updated: Jul 7, 2026

Automated Joint Space Detection Improves Bone Segmentation Accuracy
Published on: November 28, 2025
An /spl omega/-automata approach to the representation of bilevel images
1Dept. of Electr. Eng., Nat. Taiwan Univ., Taipei, Taiwan.

Abstract:
We use /spl omega/-automata (i.e., automata over infinite words) as a device for representing bilevel images. A major advantage of our approach, as opposed to using the conventional finite automata, lies in that /spl omega/-automata are capable of representing image objects of zero size, such as lines and points. To demonstrate the feasibility of our approach, we also show how a number of image processing operations, including shift, flip, rotation, complement, boundary, difference, union, intersection, and size, can be effectively carried out in the framework of /spl omega/-automata. In particular, the size of an image represented by an /spl omega/-automaton is measured based on the theory of Markov chains. In comparison with other automata-based image representation schemes reported in the literature, our approach is capable of supporting a richer set of operations, which can be performed on the automata directly and easily.
Related Concept Videos
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:22
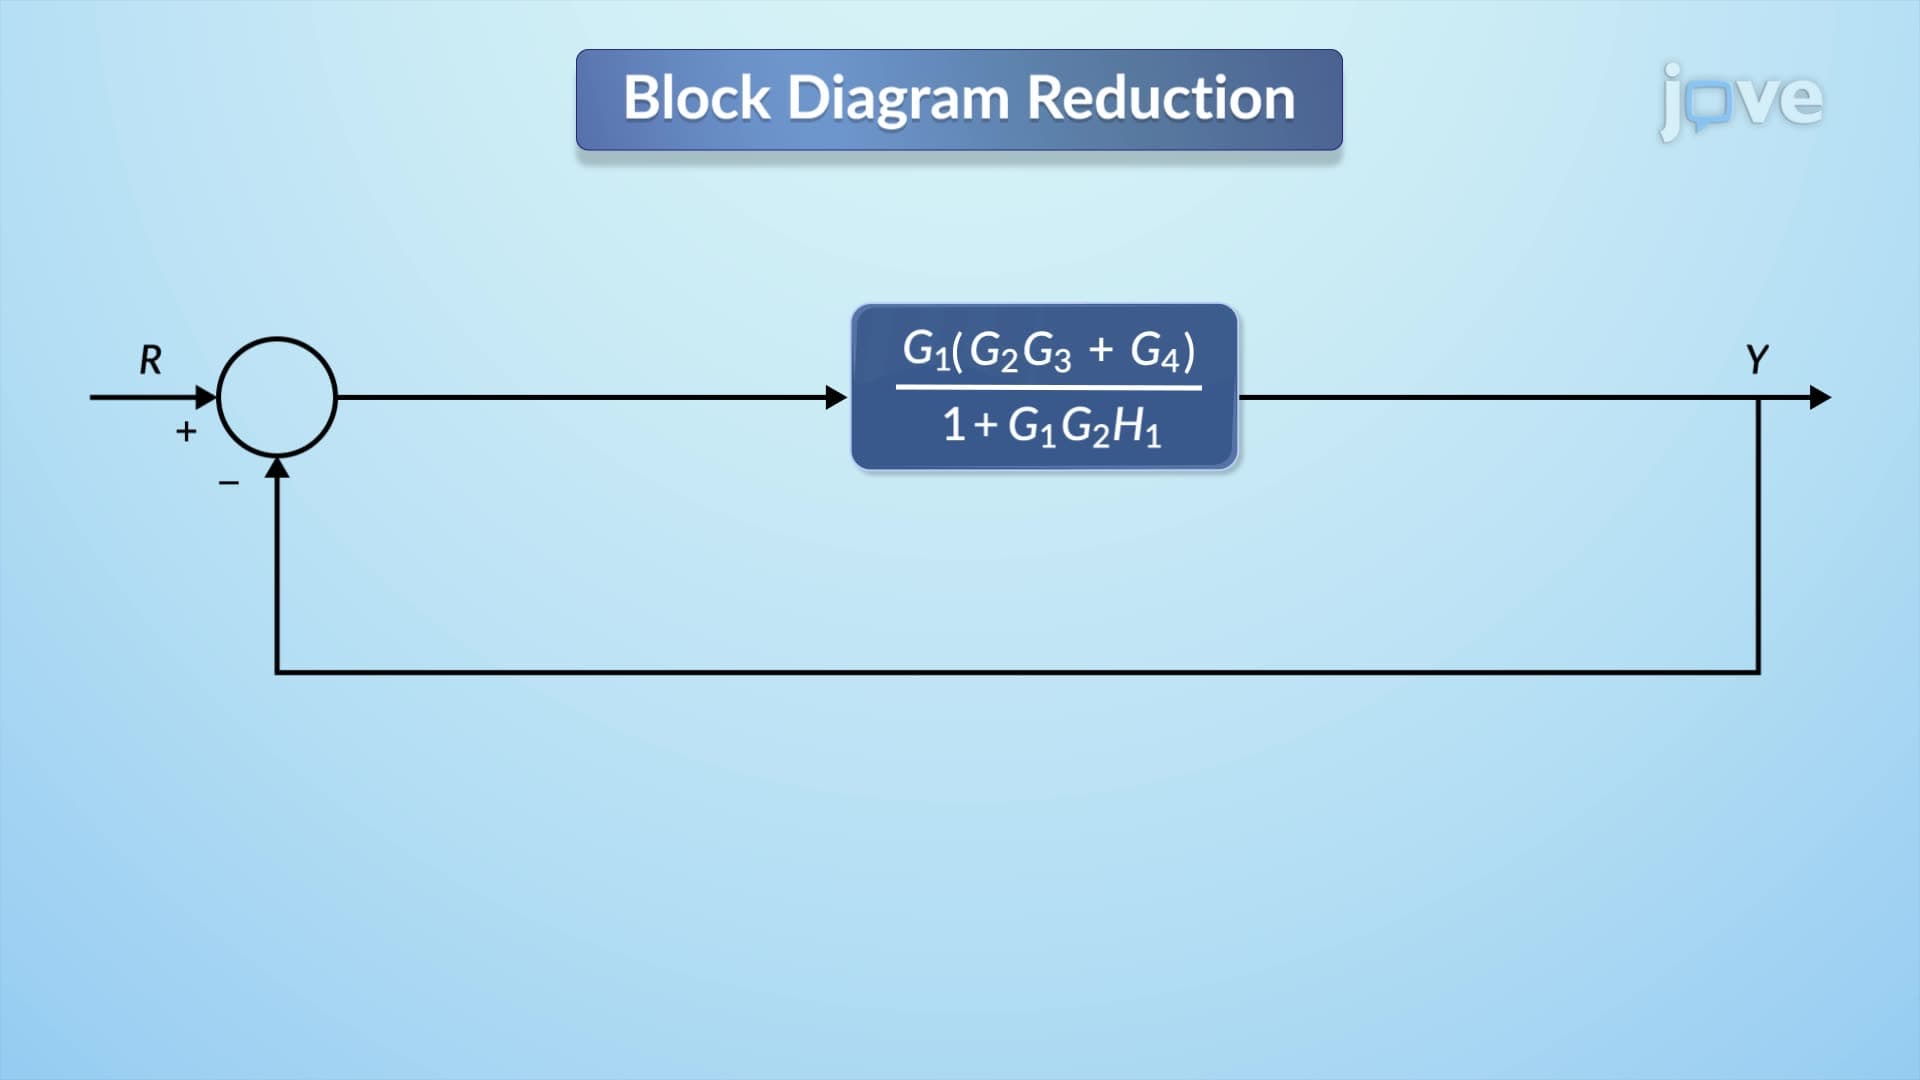
Block Diagram Reduction
The first step in this process is the identification and relocation of a branch point. A branch point, where a...
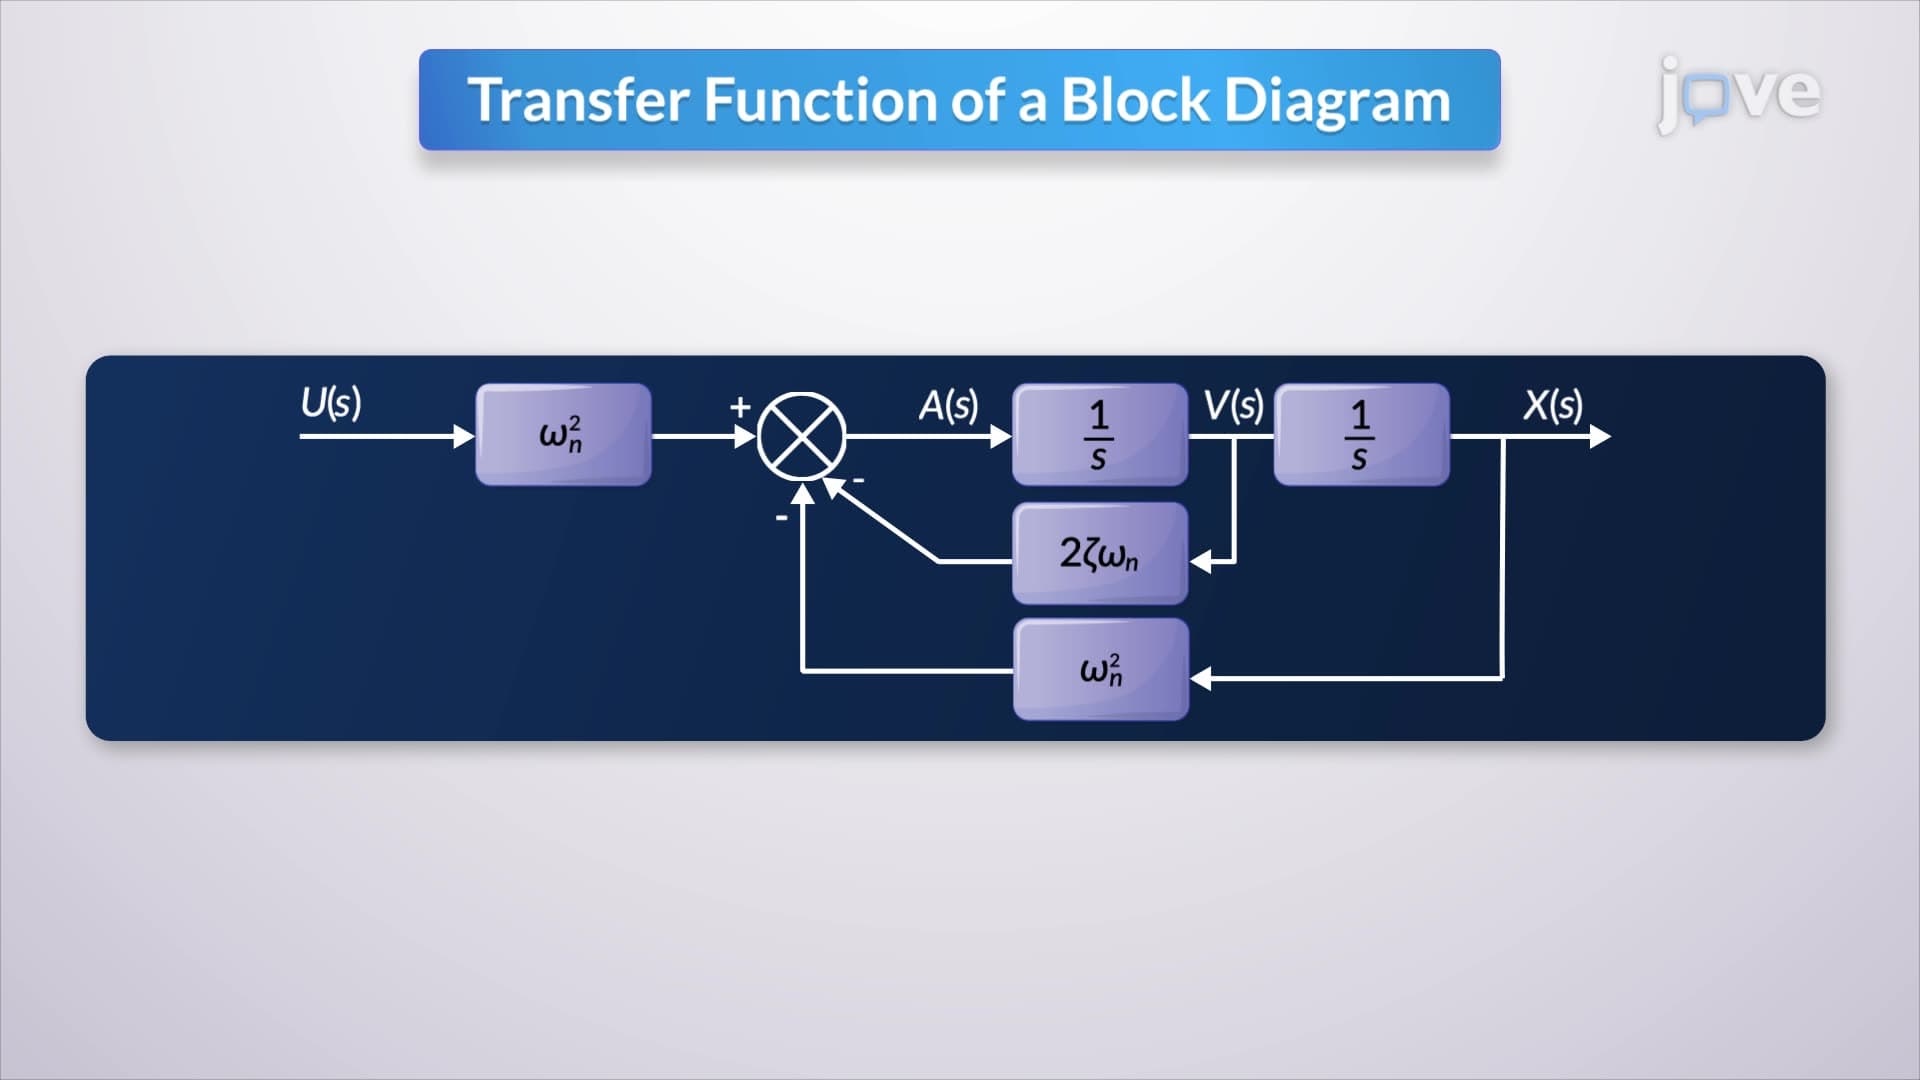 01:20
Relation between Mathematical Equations and Block Diagrams
 01:28
Graphical Representation of Inequalities
 01:24
Sequence Networks of Rotating Machines
Zero-sequence current induces a voltage drop across the generator's neutral impedance and other...