Related Experiment Video
Updated: Jul 7, 2026

Design and Analysis for Fall Detection System Simplification
Published on: April 6, 2020
The identification of vertical velocity profiles using an inertial sensor to investigate pre-impact detection of
A K Bourke1, K J O'Donovan, G Olaighin
1Biomedical Electronics Laboratory, Department of Electronic and Computer Engineering, University of Limerick, Limerick, Ireland. alan.bourke@ul.ie

Abstract:
This study investigates distinguishing falls from normal Activities of Daily Living (ADL) by thresholding of the vertical velocity of the trunk. Also presented is the design and evaluation of a wearable inertial sensor, capable of accurately measuring these vertical velocity profiles, thus providing an alternative to optical motion capture systems. Five young healthy subjects performed a number of simulated falls and normal ADL and their trunk vertical velocities were measured by both the optical motion capture system and the inertial sensor. Through vertical velocity thresholding (VVT) of the trunk, obtained from the optical motion capture system, at -1.3 m/s, falls can be distinguished from normal ADL, with 100% accuracy and with an average of 323 ms prior to trunk impact and 140 ms prior to knee impact, in this subject group. The vertical velocity profiles obtained using the inertial sensor, were then compared to those obtained using the optical motion capture system. The signals from the inertial sensor were combined to produce vertical velocity profiles using rotational mathematics and integration. Results show high mean correlation (0.941: Coefficient of Multiple Correlations) and low mean percentage error (6.74%) between the signals generated from the inertial sensor to those from the optical motion capture system. The proposed system enables vertical velocity profiles to be measured from elderly subjects in a home environment where as this has previously been impractical.
More Related Videos
 06:52
An Inertial Measurement Unit Based Method to Estimate Hip and Knee Joint Kinematics in Team Sport Athletes on the Field
Published on: May 26, 2020
 05:26
Using Motion Capture Technology in the Instrumented Timed Up and Go Test to Detect the Risk of Falling in Aged Adults
Published on: October 25, 2024
Related Concept Videos
 01:26
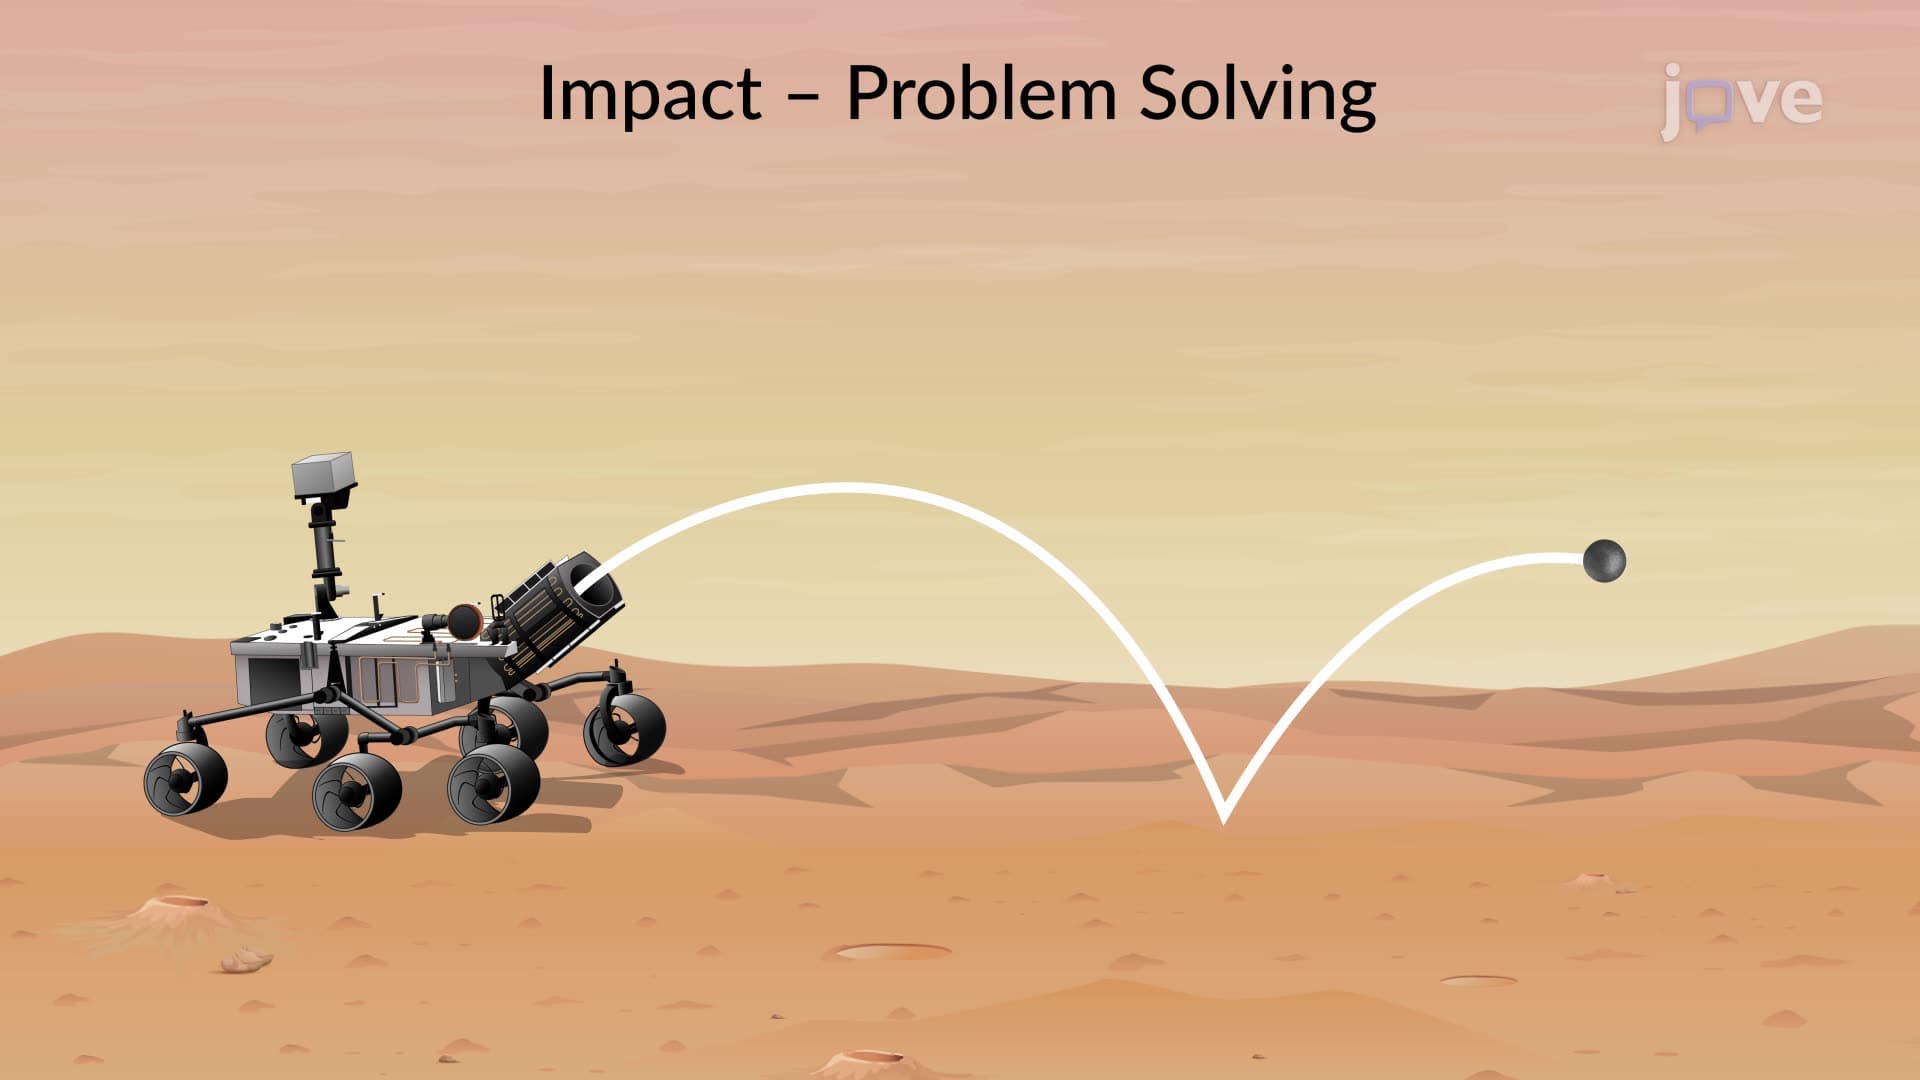
Impact: Problem Solving
By designating the launch point as the origin and utilizing kinematic equations, the vertical component of the projectile's velocity at the point of impact is...
 01:05
Free-falling Bodies: Example
The...
 01:12
Measuring Acceleration Due to Gravity
A simple pendulum can be described as a point mass and a string. Meanwhile, a physical pendulum is any object whose oscillations are similar to a simple pendulum, but cannot be modeled as a point mass on a string because its mass is distributed over a larger area. The behavior of a physical pendulum can be modeled using the principles of...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:10
Relative Motion Analysis - Acceleration
 01:30
Vector Functions and Motion: Problem Solving