Related Experiment Video
Updated: Jul 7, 2026

Experiments on Ultrasonic Lubrication Using a Piezoelectrically-assisted Tribometer and Optical Profilometer
Published on: September 28, 2015
Elastic contact conditions to optimize friction drive of surface acoustic wave motor
M Kuribayashi Kurosawa1, M Takahashi, T Higuchi
1Department of Precision Engineering, Graduate School of Engineering, The University of Tokyo, 7-3-1 Hongo, Bunkyo-Ku, Tokyo 113-8656, Japan. mkur@pe.utokyo.ac.jp

Abstract:
The optimum pressing force, namely the preload, for a slider to obtain superior operation conditions in a surface acoustic wave motor have been examined. We used steel balls as sliders. The preload was controlled using a permanent magnet. The steel balls were 0.5, 1, and 2 mm diameter, with the differences in diameter making it possible to change contact conditions, such as the contact pressure, contact area, and deformation of the stator and the slider. The stator transducer was lithium niobate, 128 degrees rotated, y-cut x-propagation substrate. The driving frequency of the Rayleigh wave was about 10 MHz. Hence, the particle vibration amplitude at the surface is as small as 10 nm. For superior friction drive conditions, a high contact pressure was required. For example, in the case of the 1 mm diameter steel ball at the sinusoidal driving voltage of 180 V(peak), the slider speed was 43 cm/sec, the thrust output force was 1 mN, and the acceleration was 23 times as large as the gravitational acceleration at a contact pressure of 390 MPa. From the Hertz theory of contact stress, the contact area radius was only 3 microm. The estimation of the friction drive performance was carried out from the transient traveling distance of the slider in a 3 msec burst drive. As a result, the deformation of the stator and the slider by the preload should be half of the vibration amplitude. This condition was independent of the ball diameter and the vibration amplitude. The output thrust per square millimeter was 50 N, and the maximum speed was 0.7 m/sec. From these results, we conclude that it is possible for the surface acoustic wave motor to have a large output force, high speed, quick response, long traveling distance, and a thin micro linear actuator.
Related Concept Videos
 01:30
Dry Friction
To illustrate this concept, imagine a wooden crate resting on a rough, non-uniform horizontal surface. When an external force is applied to...
 01:26
Kinetic Friction
 01:23
Design Example: Deciding Thickness of Lubricating Fluid in a Shaft
To calculate the required thickness of the lubricant layer, the tangential velocity at the shaft's surface must first be determined. This velocity is calculated by converting the rotational speed to angular velocity...
 01:07
Frictional Force
 01:05
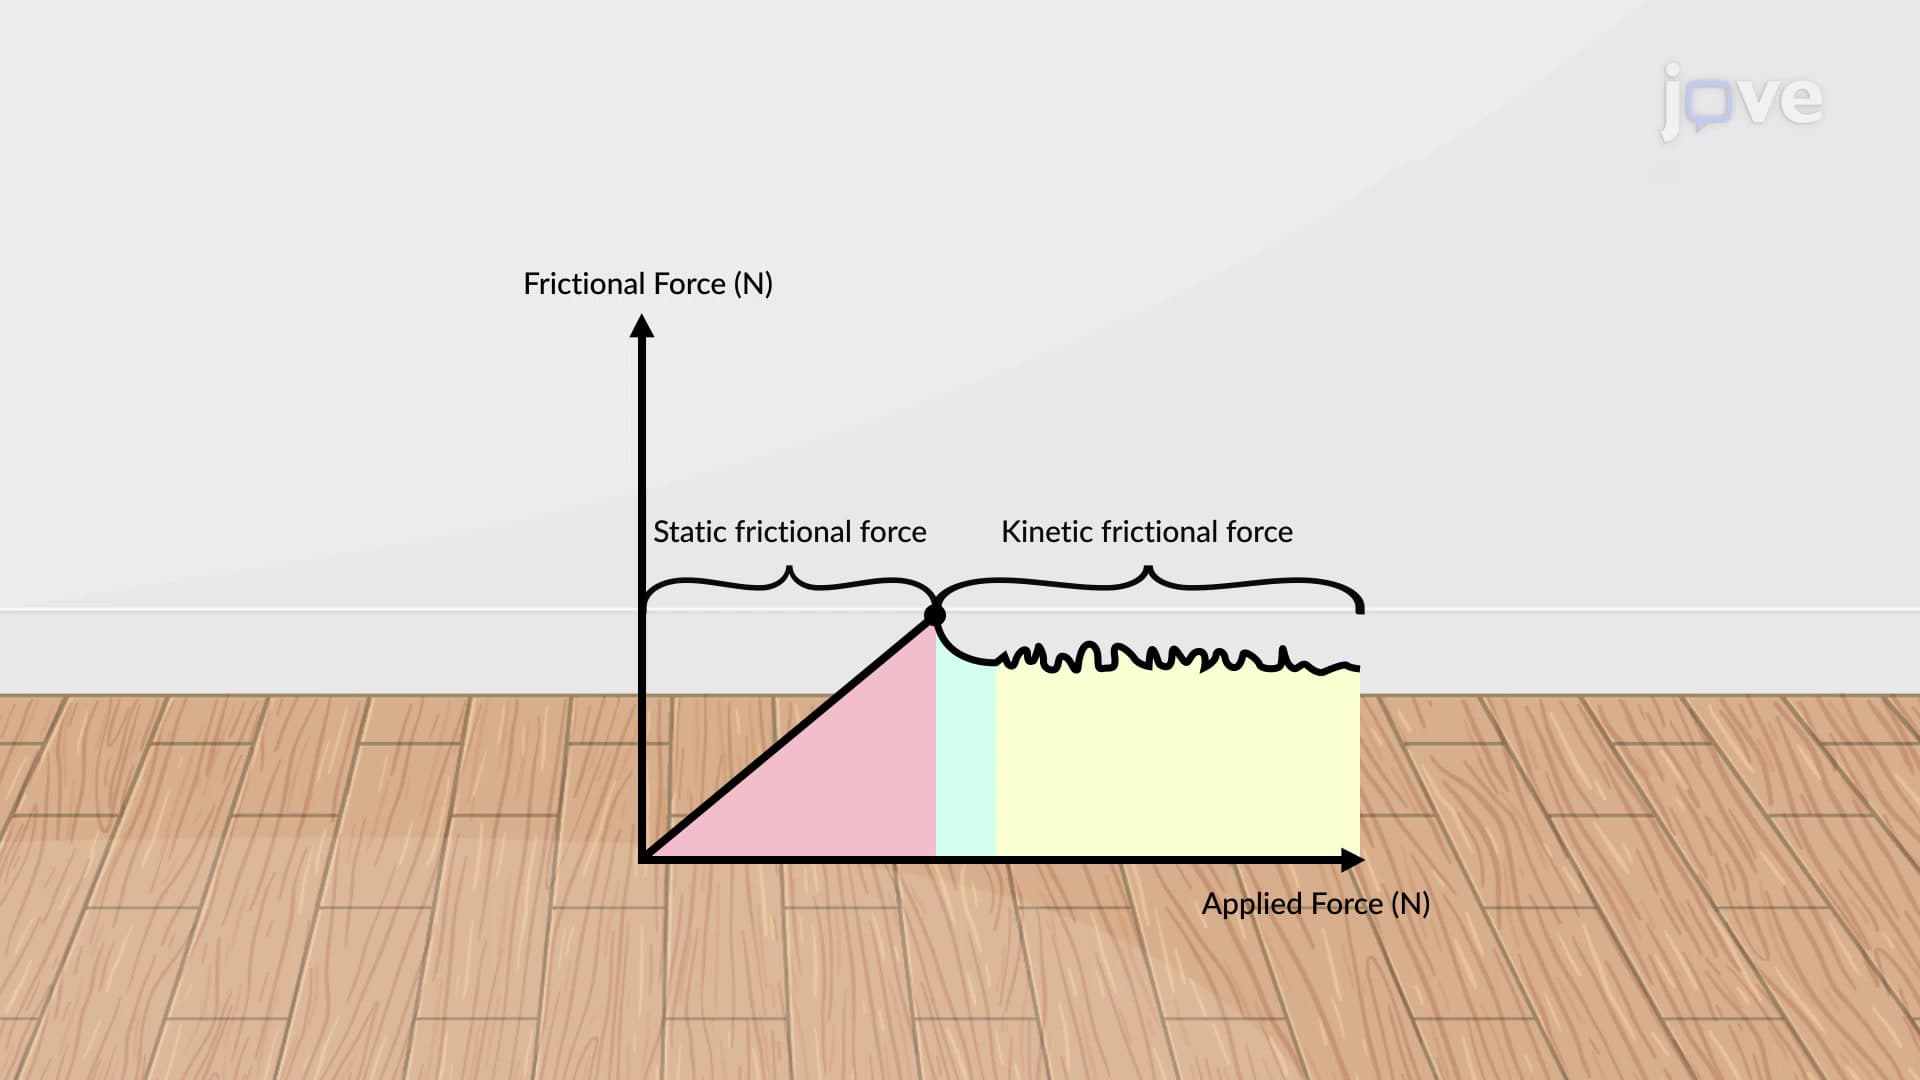
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:21
Characteristics of Dry Friction
Before the wheelbarrow starts moving, the static frictional force acts tangentially to the contact surface, opposing the force that is about to induce the motion. This frictional force prevents the...