Related Experiment Video
Updated: Jul 7, 2026


Asymmetric Walkway: A Novel Behavioral Assay for Studying Asymmetric Locomotion
Published on: January 15, 2016
An analog CMOS central pattern generator for interlimb coordination in quadruped locomotion

Abstract:
This paper proposes a neuromorphic analog CMOS controller for interlimb coordination in quadruped locomotion. Animal locomotion, such as walking, running, swimming, and flying, is based on periodic rhythmic movements. These rhythmic movements are driven by the biological neural network, called the central pattern generator (CPG). In recent years, many researchers have applied CPG to locomotion controllers in robotics. However, most of these have been developed with digital processors and, thus, have several problems, such as high power consumption. In order to overcome such problems, a CPG controller with analog CMOS circuit is proposed. Since the CMOS transistors in the circuit operate in their subthreshold region and under low supply voltage, the controller can reduce power consumption. Moreover, low-cost production and miniaturization of controllers are expected. We have shown through computer simulation, such circuit has the capability to generate several periodic rhythmic patterns and transitions between their patterns promptly.

Related Concept Videos
 01:18
Hierarchy of Motor Control
 01:22
Indirect Motor Pathways
The vestibulospinal tract originates in the vestibular nuclei of the brainstem. The vestibular system detects changes in...
 01:11
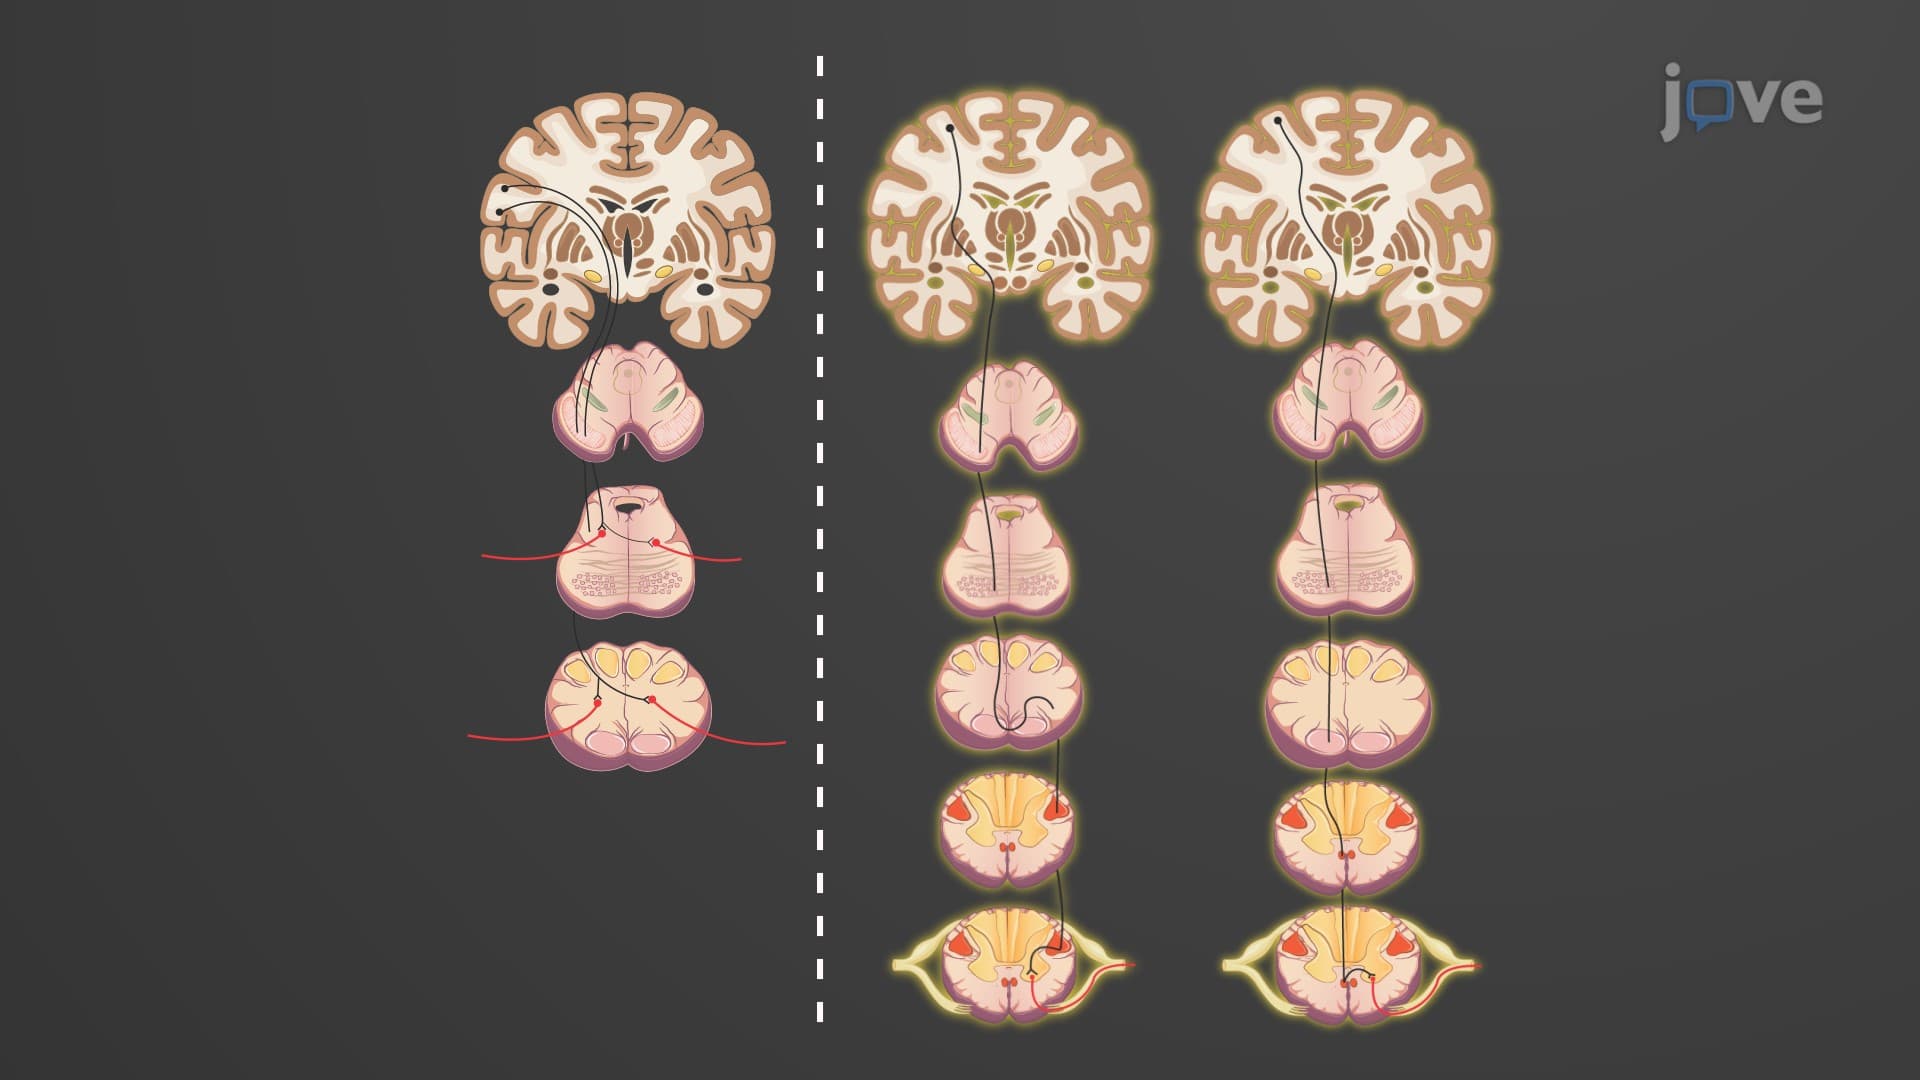
Direct Motor Pathways
The corticospinal tract is responsible for the voluntary movement of the limbs and trunk. It originates in the cerebral cortex of the brain and descends through the cerebrum's internal capsule and the...