Related Experiment Video
Updated: Jul 7, 2026

Online Virtual Reality Networked Control Laboratory Applied in Control Engineering Education
Published on: February 23, 2024
Optoelectronic implementation of real-time control of an inverted pendulum by fuzzy-logic-control units based on a
1Optical Information Section, Optoelectronics Division, Electrotechnical Laboratory, Tsukuba, Ibaraki, 305 Japan.

Abstract:
We have realized a novel optoelectronic implementation of an analog fuzzy-inference architecture, using the movement of the center of gravity of a far-field pattern. In the inference process Gaussianlike membership functions and a product-sum-gravity method are used. Antecedent membership functions and the grade evaluations are realized by combining light-emitting-diode (LED) arrays for sequential light emission and position-sensing devices for center-of-gravity detection. Consequent and defuzzification operations are realized by a LED array and a position-sensing device. High-speed fuzzy inference of more than several tens of mega fuzzy logical inference per second is possible with these units. The usefulness of the system is demonstrated by the real-time standing control of an inverted pendulum.
More Related Videos
 11:44
Real-Time DC-dynamic Biasing Method for Switching Time Improvement in Severely Underdamped Fringing-field Electrostatic MEMS Actuators
Published on: August 15, 2014
 09:01
Gain-compensation Methodology for a Sinusoidal Scan of a Galvanometer Mirror in Proportional-Integral-Differential Control Using Pre-emphasis Techniques
Published on: April 4, 2017
Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:06
Physical Pendulum
When dealing with complicated systems, the mass moment of inertia is an important parameter, as it describes the mass...
 01:09
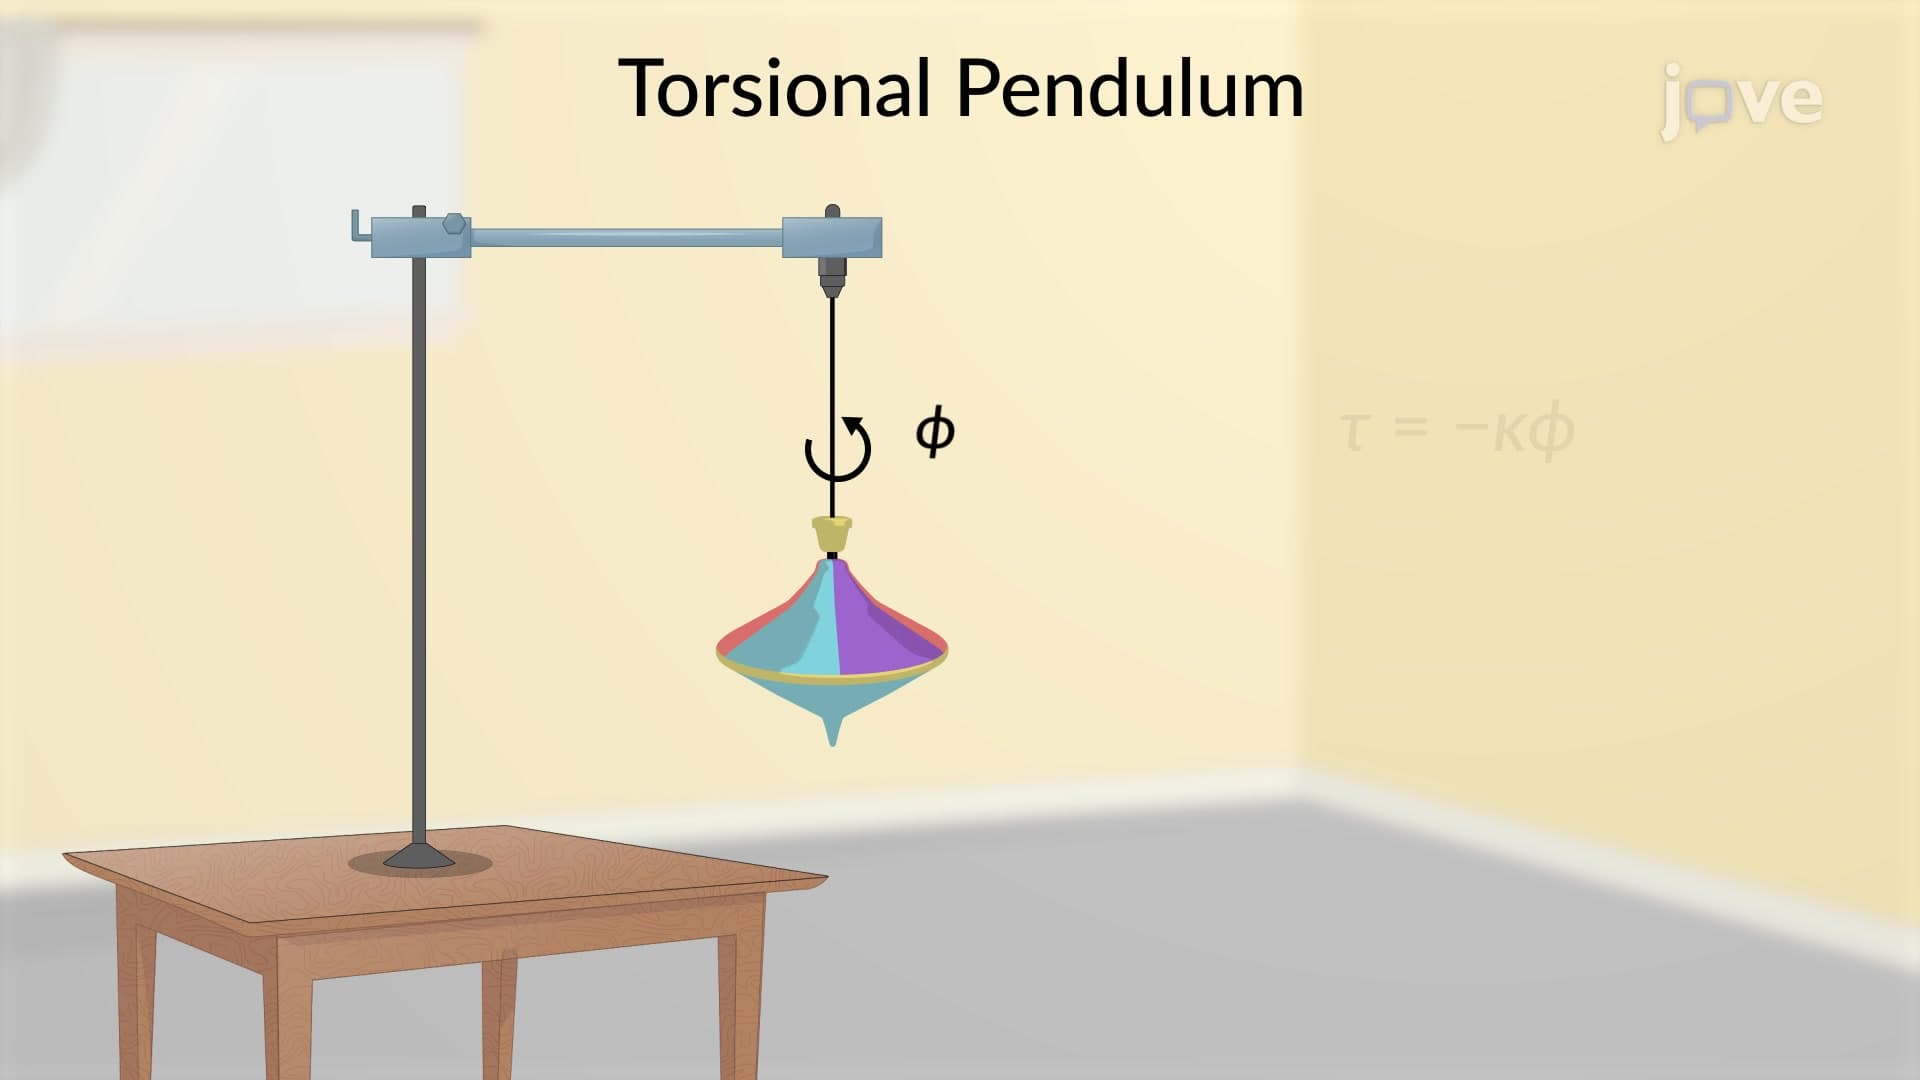
Torsional Pendulum
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played by the...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:10
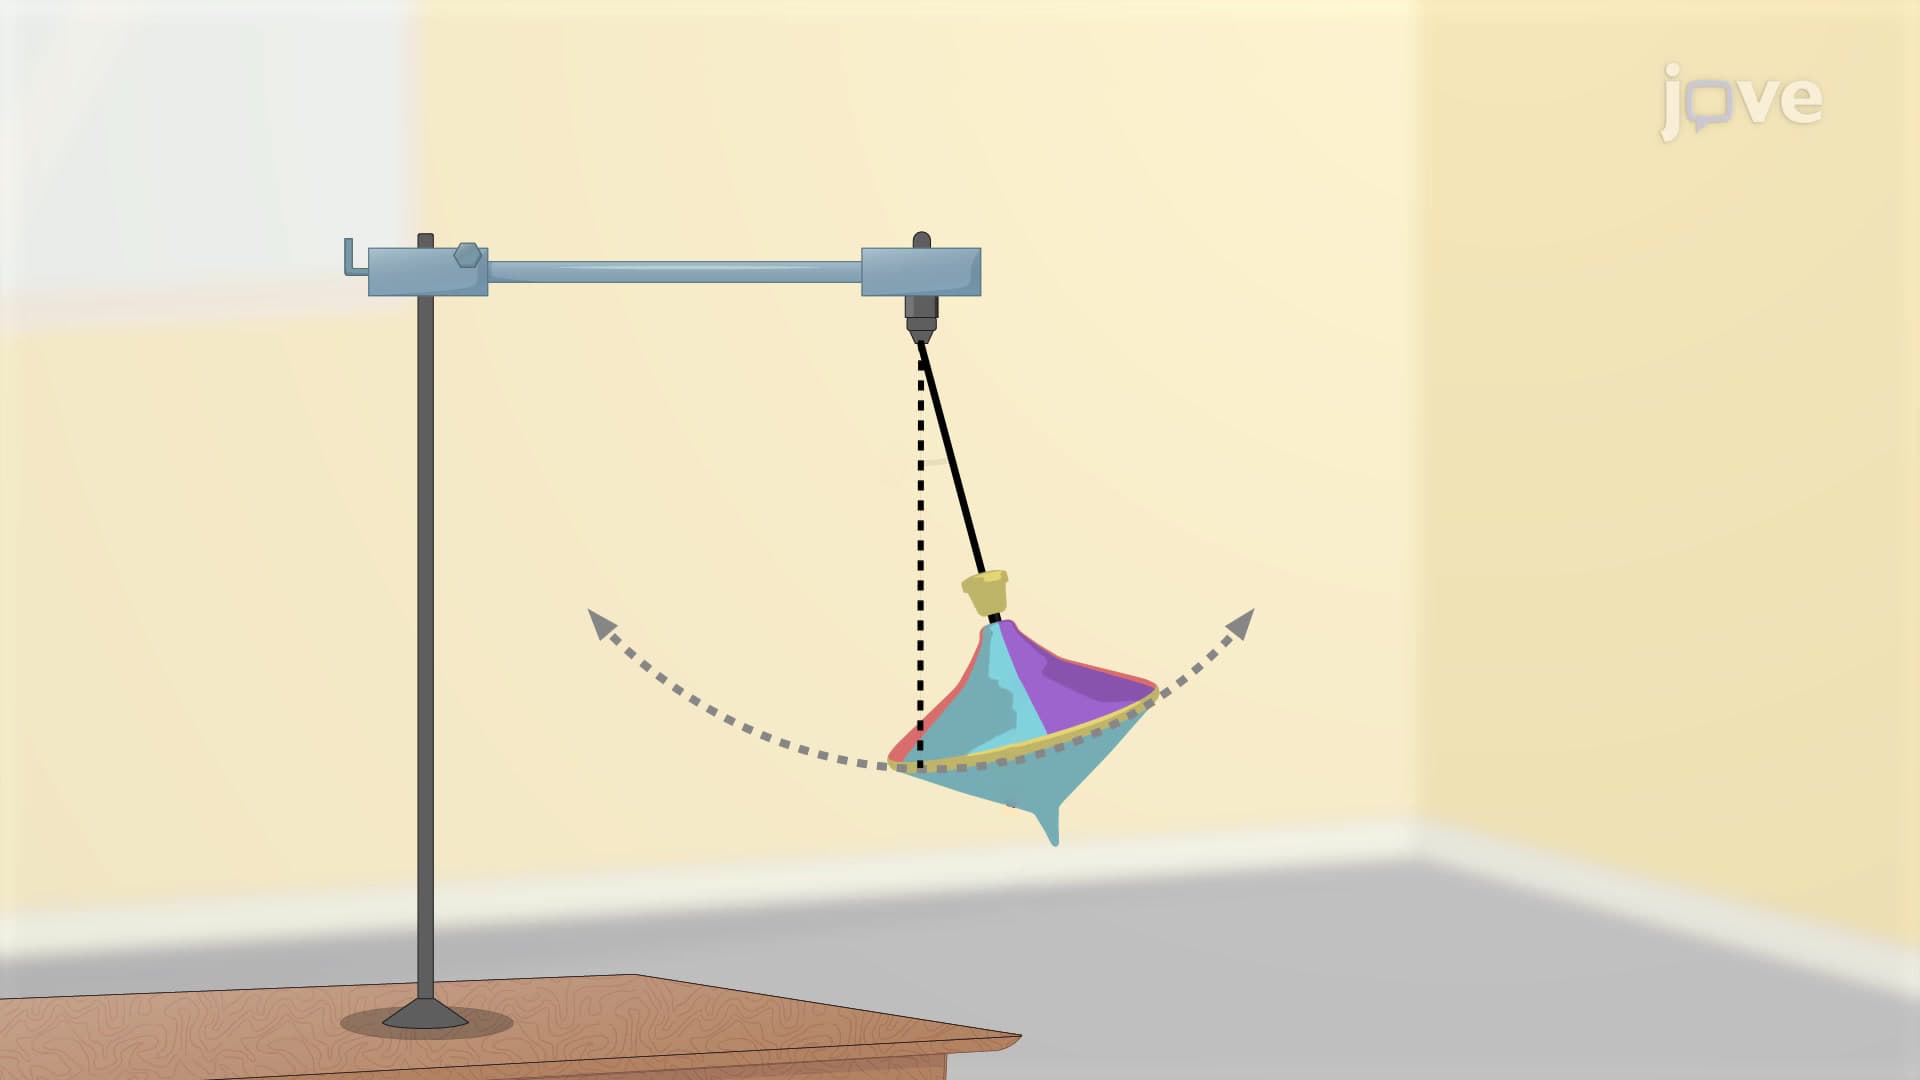
Simple Pendulum
The period of a simple pendulum depends on two factors: its length and the acceleration due to gravity. The period is completely independent of any other factors, such as mass or maximum displacement. For small displacements, a pendulum is...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...