Neural and fuzzy robotic hand control
Related Experiment Video
Updated: Jul 7, 2026
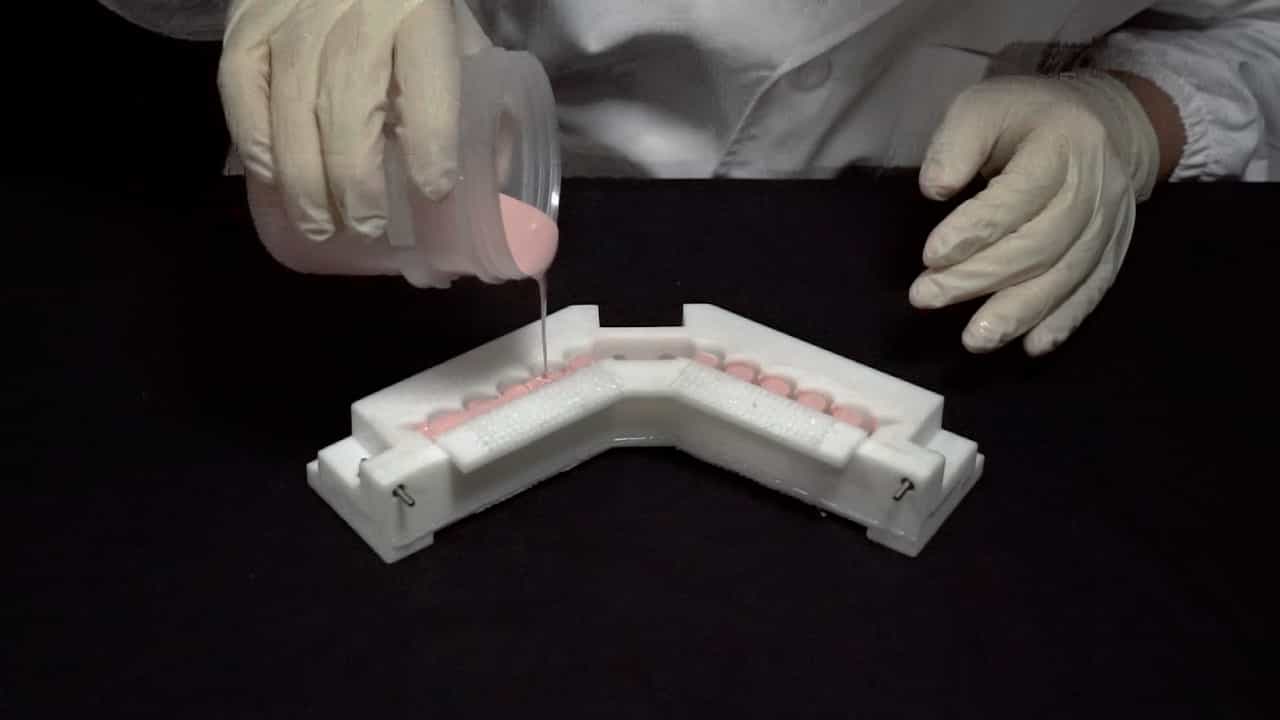
A Flexible Wearable Supernumerary Robotic Limb for Chronic Stroke Patients
Published on: October 27, 2023
1Dept. of Electr. Eng., Binghamton Univ., NY.

Abstract:
An efficient first grasp for a wheelchair robotic arm-hand with pressure sensing is determined and presented. The grasp is learned by combining the advantages of neural networks and fuzzy logic into a hybrid control algorithm which learns from its tip and slip control experiences. Neurofuzzy modifications are outlined, and basic steps are demonstrated in preparation for physical implementation. Choice of object approach vector based on fuzzy tip and slip data and an expert supervisor, as well as training of a diagnostic neural tip and slip controller, are the focus of this work.
Related Concept Videos
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:18
Hierarchy of Motor Control
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...