Related Experiment Video
Updated: Jul 7, 2026

X-ray Beam Induced Current Measurements for Multi-Modal X-ray Microscopy of Solar Cells
Published on: August 20, 2019
Fast recursive filters for simulating nonlinear dynamic systems
1Netherlands Institute for Neuroscience, Royal Netherlands Academy of Arts and Sciences, Amsterdam, and Institute for Mathematics and Computing Science, University of Groningen, The Netherlands. j.h.van.hateren@rug.nl

Abstract:
A fast and accurate computational scheme for simulating nonlinear dynamic systems is presented. The scheme assumes that the system can be represented by a combination of components of only two different types: first-order low-pass filters and static nonlinearities. The parameters of these filters and nonlinearities may depend on system variables, and the topology of the system may be complex, including feedback. Several examples taken from neuroscience are given: phototransduction, photopigment bleaching, and spike generation according to the Hodgkin-Huxley equations. The scheme uses two slightly different forms of autoregressive filters, with an implicit delay of zero for feedforward control and an implicit delay of half a sample distance for feedback control. On a fairly complex model of the macaque retinal horizontal cell, it computes, for a given level of accuracy, one to two orders of magnitude faster than the fourth-order Runge-Kutta. The computational scheme has minimal memory requirements and is also suited for computation on a stream processor, such as a graphical processing unit.
More Related Videos
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
 08:35
Interactive and Visualized Online Experimentation System for Engineering Education and Research
Published on: November 24, 2021
Related Concept Videos
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 01:21
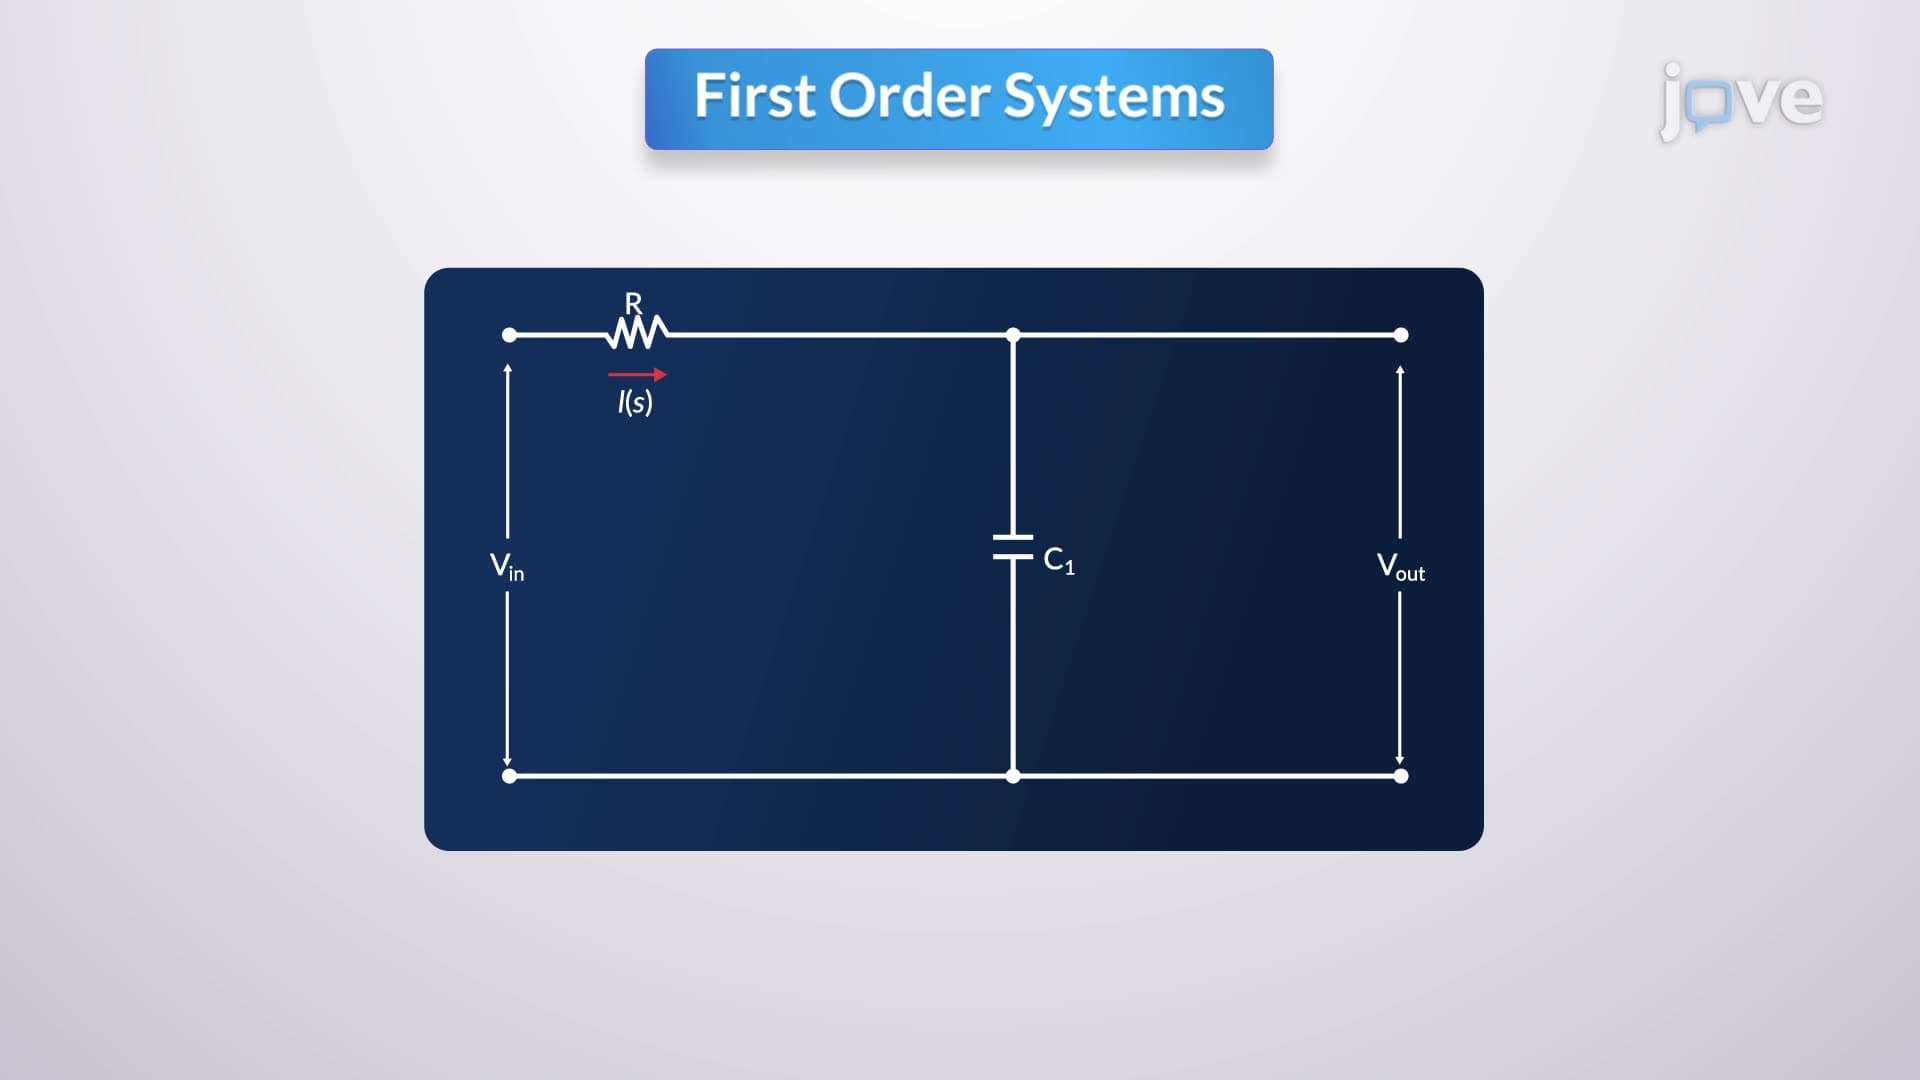
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:18
Second Order systems II
If ζ...
 01:25
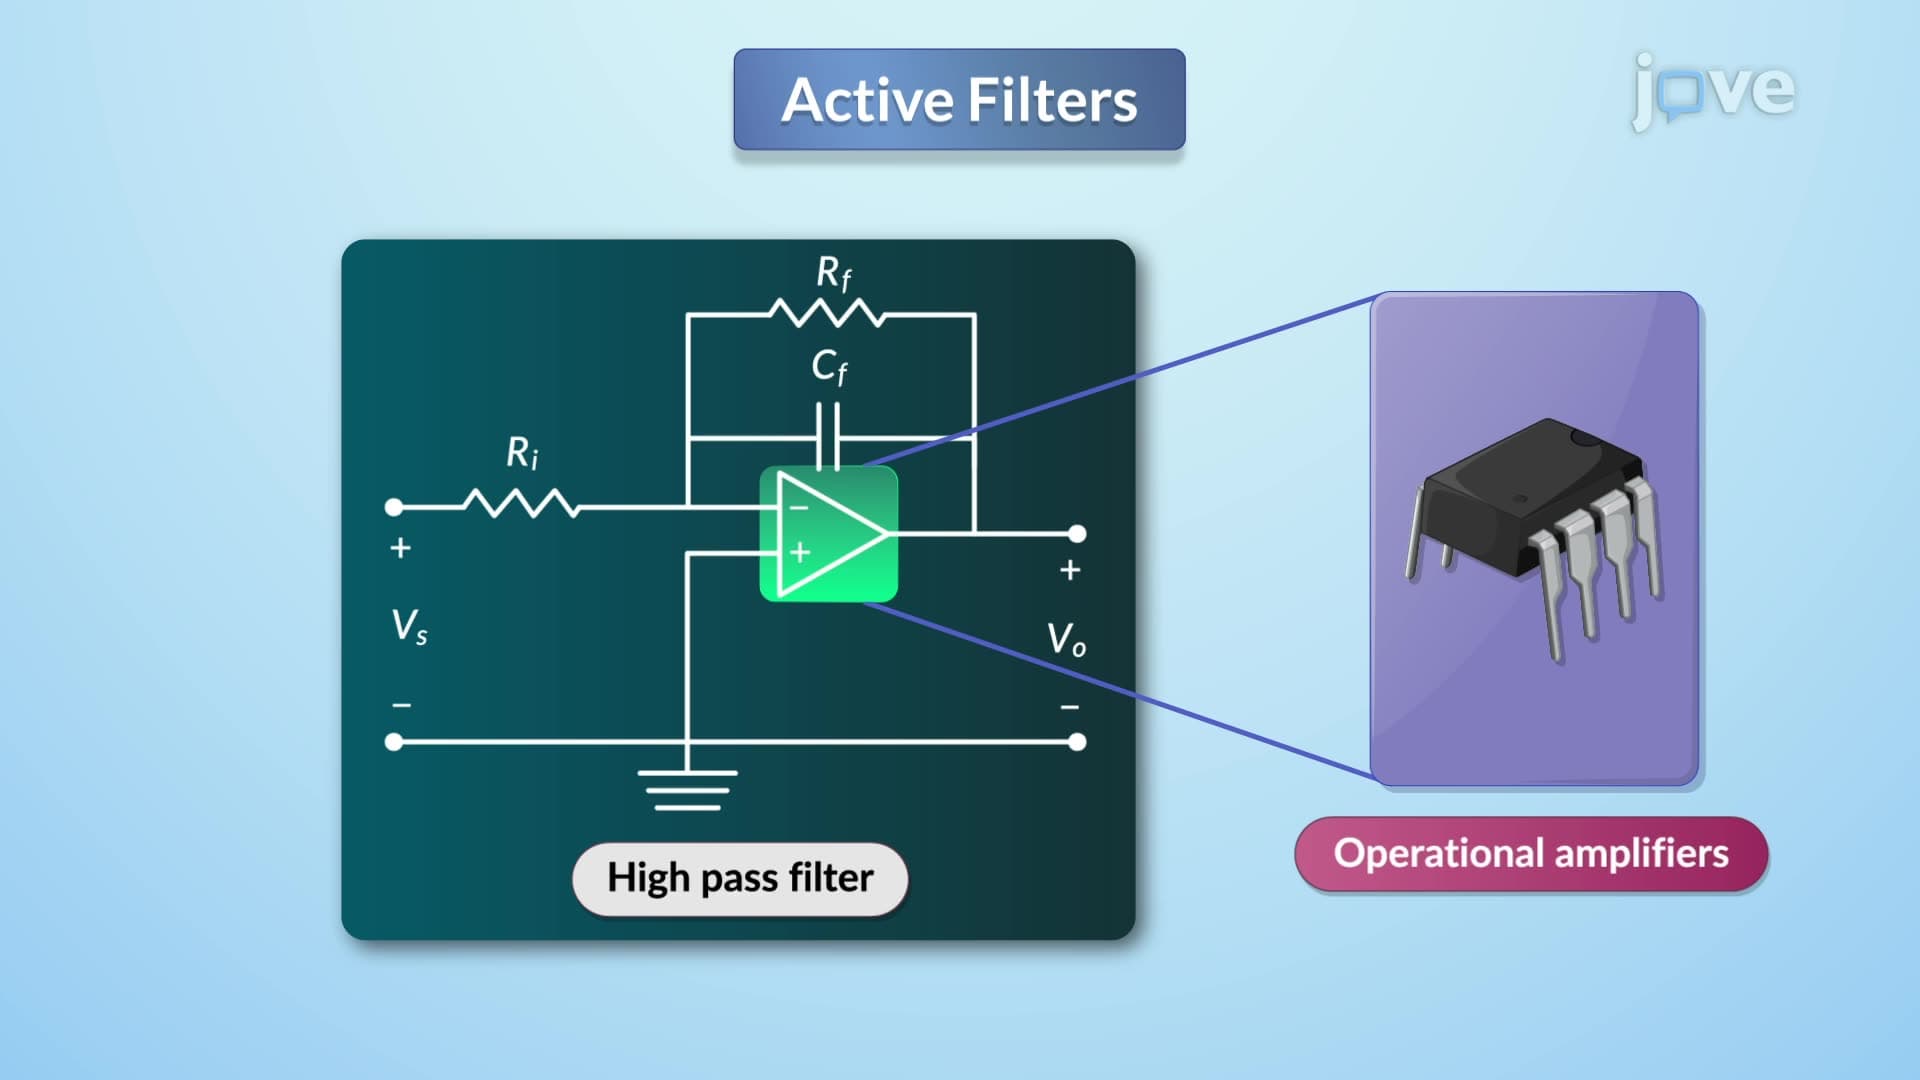
Active Filters
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be calculated...