Universal stabilization using control Lyapunov functions, adaptive derivative feedback, and neural network approximators
Related Experiment Video
Updated: Jun 29, 2026

An Experimental Platform to Study the Closed-loop Performance of Brain-machine Interfaces
Published on: March 10, 2011
1Dept. of Electr. Eng. Syst., Univ. of Southern California, Los Angeles, CA.

Abstract:
In this paper, the problem of stabilization of unknown nonlinear dynamical systems is considered. An adaptive feedback law is constructed that is based on the switching adaptive strategy proposed by the author and uses linear-in-the-weights neural networks accompanied with appropriate robust adaptive laws in order to estimate the time-derivative of the control Lyapunov function (CLF) of the system. The closed-loop system is shown to be stable; moreover, the state vector of the controlled system converges to a ball centered at the origin and having a radius that can be made arbitrarily small by increasing the high gain K and the number of neural network regressor terms. No growth conditions on the nonlinearities of the system are imposed with the exception that such nonlinearities are sufficiently smooth. Finally, we mention that neither the system dynamics or the CLF of the system need to be known in order to apply the proposed methodology.
More Related Videos
 09:01
Gain-compensation Methodology for a Sinusoidal Scan of a Galvanometer Mirror in Proportional-Integral-Differential Control Using Pre-emphasis Techniques
Published on: April 4, 2017
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
Related Concept Videos
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:26
Linear Approximation in Frequency Domain
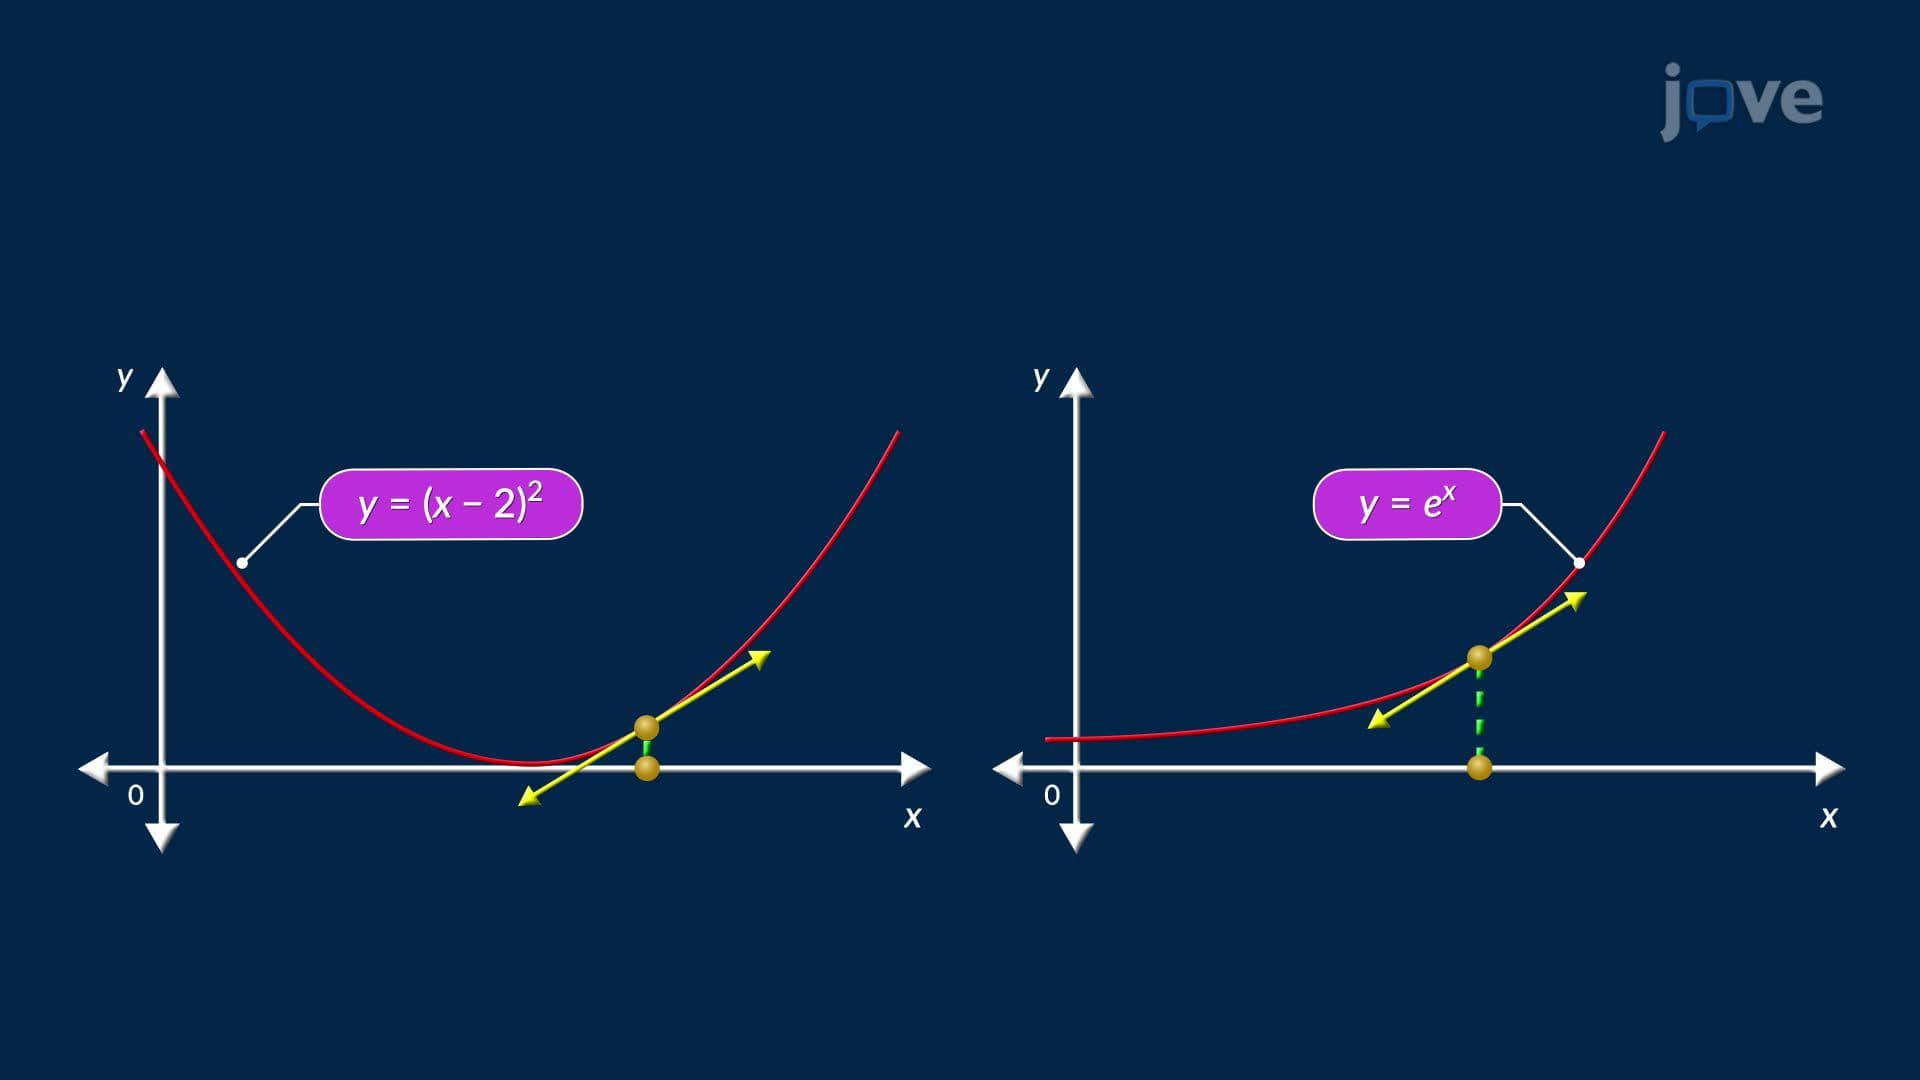
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:26
Linearization and Approximation
 01:29
Application of Linearization and Approximation