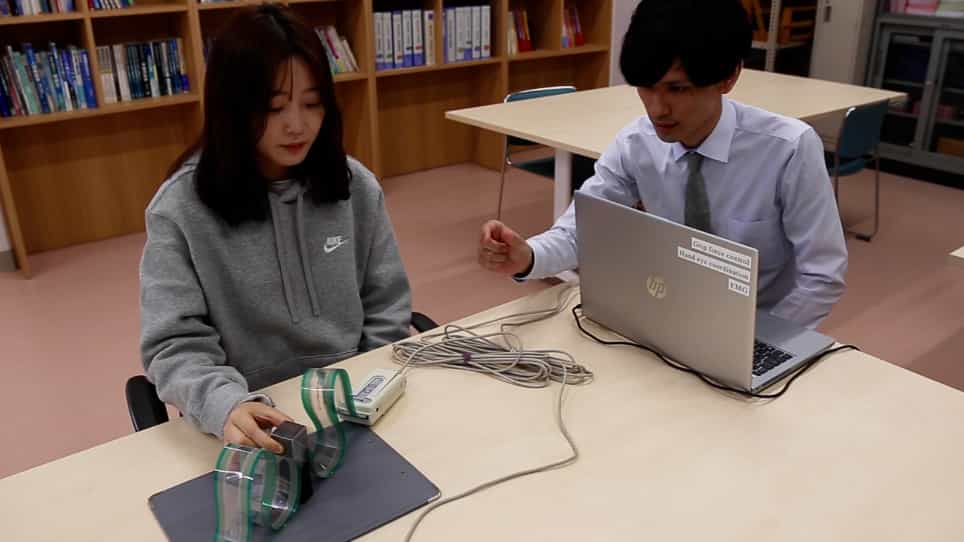
Improved grasp force sensitivity for prosthetic hands through force-derivative feedback
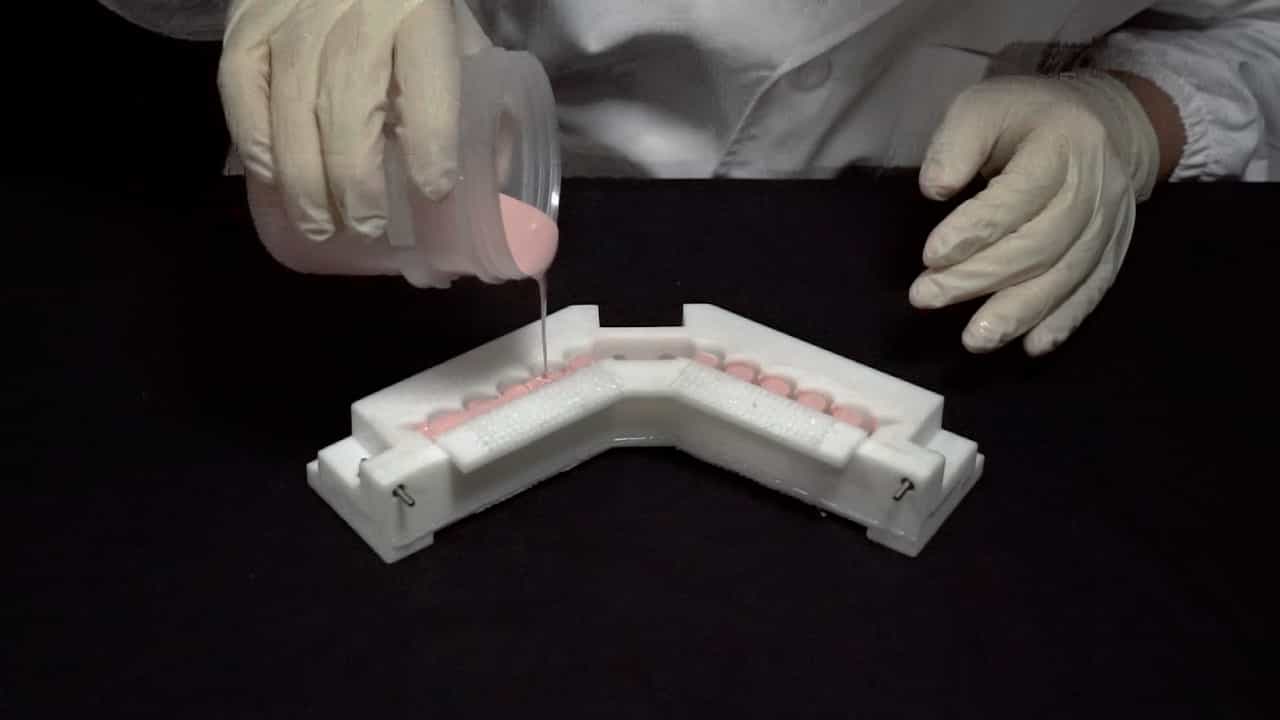
Related Experiment Video
Updated: Jul 7, 2026
03:55
A Flexible Wearable Supernumerary Robotic Limb for Chronic Stroke Patients
Published on: October 27, 2023
Erik D Engeberg1, Sanford Meek
1Department of Mechanical Engineering, University of Utah, Salt Lake City, UT 84112 USA. e.engeberg@utah.edu
IEEE Transactions on Bio-Medical Engineering
|February 14, 2008

Abstract:
Sensitivity of applied grasp force is improved for a myoelectrically controlled prosthetic hand under force control through normal force-derivative feedback. Benchtop experiments and results from 12 human test subjects indicate that normal force-derivative feedback can be used in prosthetic hands to help prevent accidental damage to delicate objects.