Related Experiment Video
Updated: Jul 7, 2026


Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
On the origin of planar covariation of elevation angles during human locomotion
Y P Ivanenko1, A d'Avella, R E Poppele
1Department of Neuromotor Physiology, Scientific Institute Foundation Santa Lucia, 306 via Ardeatina, 00179 Rome, Italy. y.ivanenko@hsantalucia.it

Abstract:
Leg segment rotations in human walking covary, so that the three-dimensional trajectory of temporal changes in the elevation angles lies close to a plane. Recently the role of central versus biomechanical constraints on the kinematics control of human locomotion has been questioned. Here we show, based on both modeling and experimental data, that the planar law of intersegmental coordination is not a simple consequence of biomechanics. First, the full limb behavior in various locomotion modes (walking on inclined surface, staircase stepping, air-stepping, crouched walking, hopping) can be expressed as 2 degrees of freedom planar motion even though the orientation of the plane and pairwise segment angle correlations may differ substantially. Second, planar covariation is not an inevitable outcome of any locomotor movement. It can be systematically violated in some conditions (e.g., when stooping and grasping an object on the floor during walking or in toddlers at the onset of independent walking) or transferred into a simple linear relationship in others (e.g., during stepping in place). Finally, all three major limb segments contribute importantly to planar covariation and its characteristics resulting in a certain endpoint trajectory defined by the limb axis length and orientation. Recent advances in the neural control of movement support the hypothesis about central representation of kinematics components.
Related Concept Videos
 01:20
Elevation of Intermediate Points on Vertical Curves
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:27
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:14
Interpretations of Partial Derivatives
 01:20
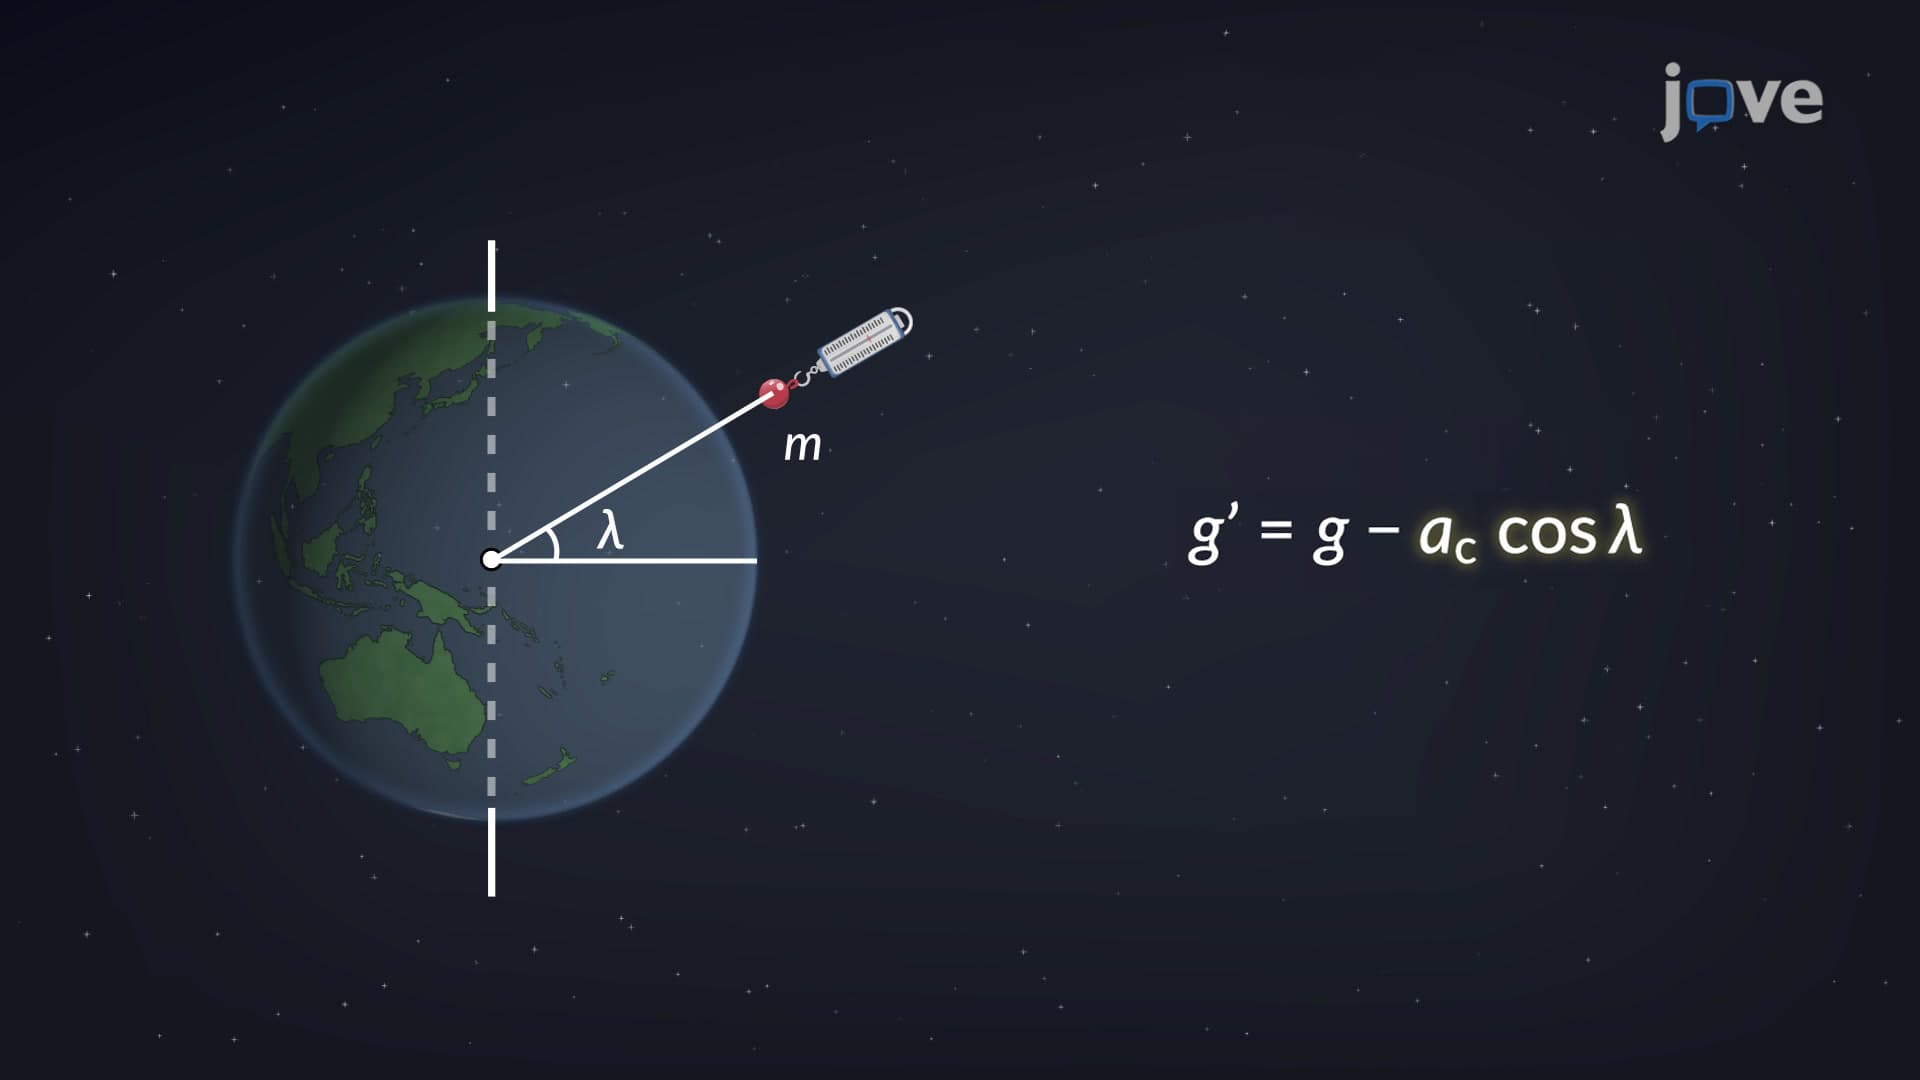
Variation in Acceleration due to Gravity near the Earth's Surface
The difference between the true and apparent weights is proportional to the square of the Earth's angular speed. Since the...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...