Related Experiment Video
Updated: Jul 7, 2026

High-resolution, High-speed, Three-dimensional Video Imaging with Digital Fringe Projection Techniques
Published on: December 3, 2013
Positioning of Noncooperative Objects by use of Joint Transform Correlation Combined with Fringe Projection

Abstract:
Automated assembly and quality control require reliable systems for the detection of the position and the orientation of complicated objects. Correlation methods are well suited, but they are affected by structured backgrounds, varying illumination conditions, and textured or dirty object surfaces. Using fringe projection to exploit the three-dimensional topography of objects, we improve the performance of a nonlinear joint transform correlator. Positioning of noncooperative objects with subpixel accuracy is demonstrated. Additionally, the tilt angle of an arbitrarily shaped object is measured by projection of object-adapted fringes that produce a homogeneous fringe pattern in the image plane. An accuracy of better than 1 degrees is achieved.


Related Concept Videos
 01:00
Position and Displacement Vectors
Further, several important kinds of...
01:00Position and Displacement Vectors
Further, several important kinds of...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:25
Coplanar Forces
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:29
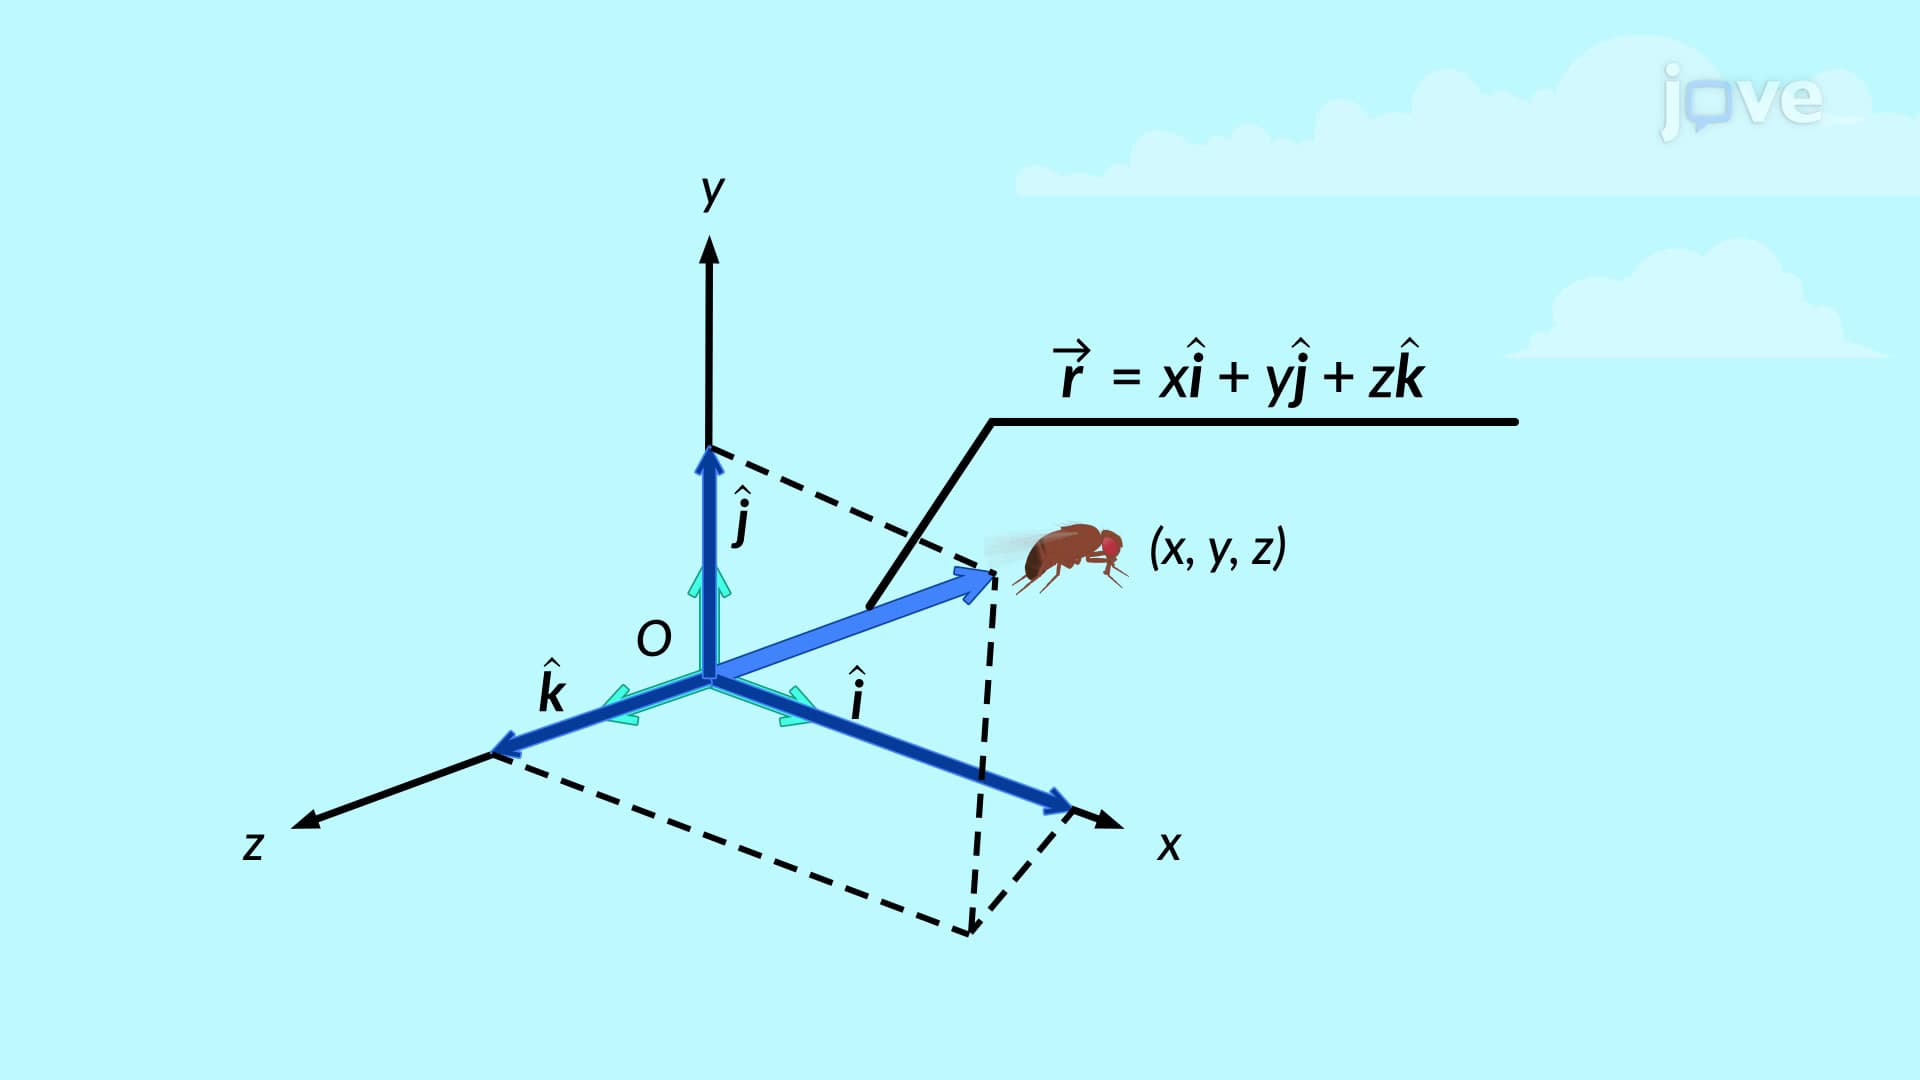
Position Vectors
For instance, we want to locate a point P(x, y, z) relative to the origin of coordinates O. In that case, we can define a position...