Deformations of the constraint algebra of Ashtekar's Hamiltonian formulation of general relativity

Kirill Krasnov1

  • 1School of Mathematical Sciences, University of Nottingham, Nottingham, NG7 2RD, United Kingdom.

Related Concept Videos

Space-Time Curvature and the General Theory of Relativity01:17

Space-Time Curvature and the General Theory of Relativity

In 1905, Albert Einstein published his special theory of relativity. According to this theory, no matter in the universe can attain a speed greater than the speed of light in a vacuum, which thus serves as the speed limit of the universe.
This has been verified in many experiments. However, space and time are no longer absolute. Two observers moving relative to one another do not agree on the length of objects or the passage of time. The mechanics of objects based on Newton's laws of motion,...
Lagrange Multipliers: One Constraint01:29

Lagrange Multipliers: One Constraint
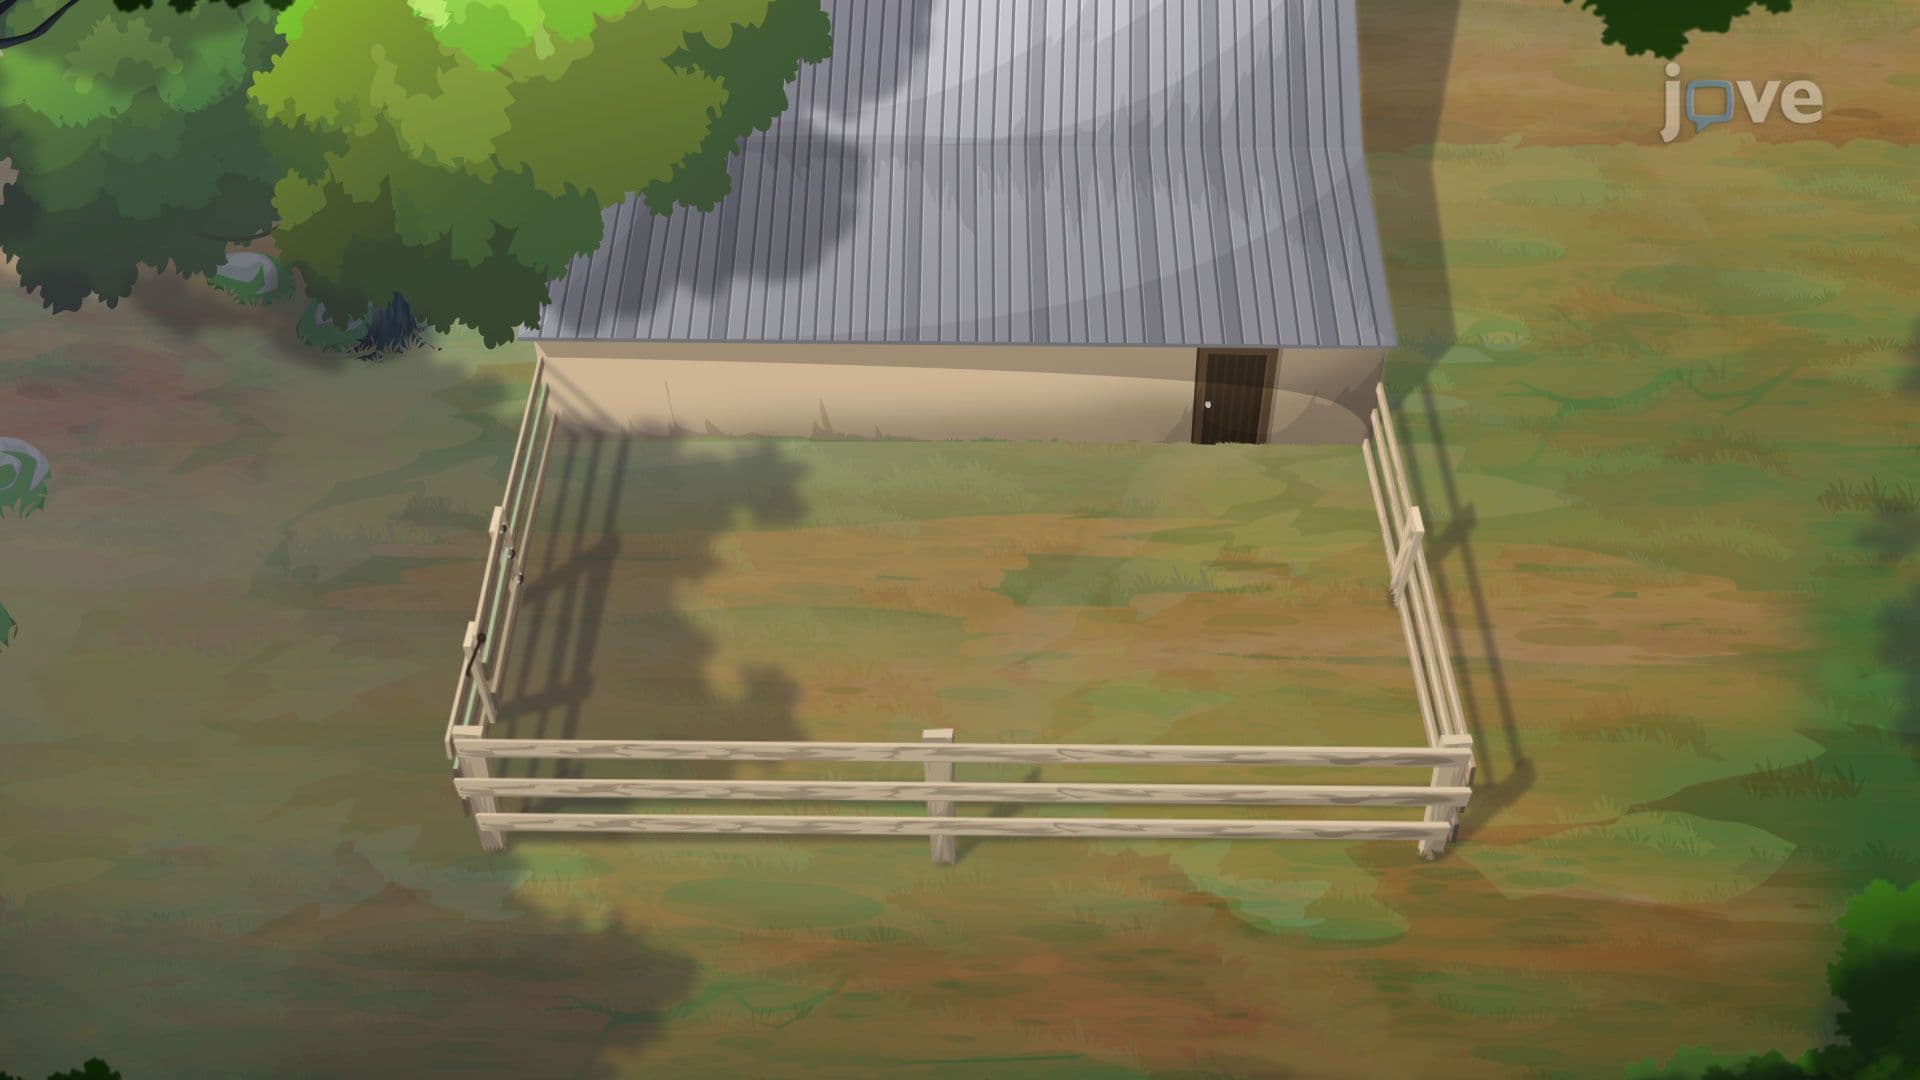
In constrained optimization, the objective is to maximize or minimize a quantity while satisfying a fixed condition. A standard example is a rectangular pen built against a barn wall using 100 meters of fencing. Because the wall provides one side of the enclosure, only the other three sides require fencing. The problem is to find the dimensions that produce the greatest possible area.Let L represent the length parallel to the wall and W the width perpendicular to it. The area of the pen is A =...
Constraints and Statical Determinacy01:26

Constraints and Statical Determinacy
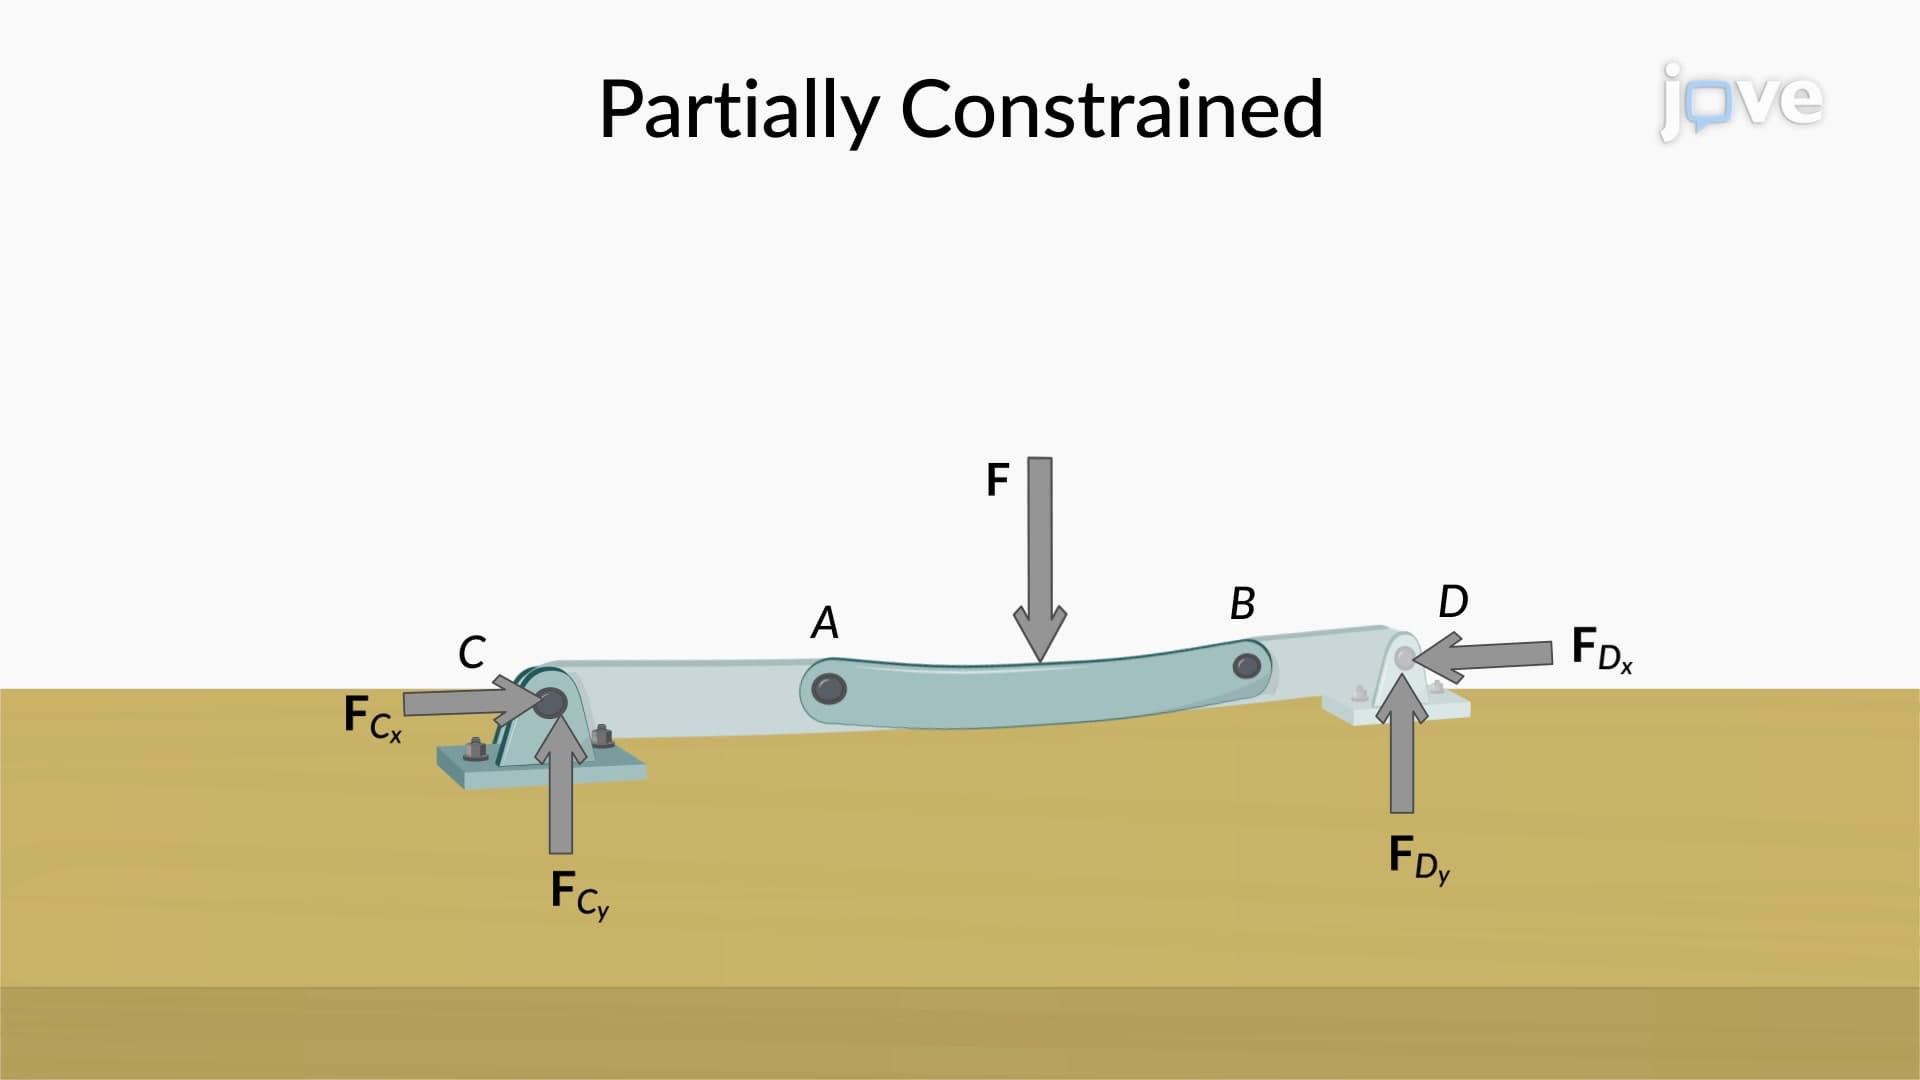
In structural engineering, the equilibrium of a system is not only determined by its equations of equilibrium but also with the help of constraints. Constraints refer to restrictions on the motion of a system. The proper combinations of constraints can minimize the total number of constraints needed to maintain a system in mechanical equilibrium. When this happens, the system is said to be statically determinate. For such systems, the unknown reaction supports can be estimated using equilibrium...
Cartesian Form for Vector Formulation01:26

Cartesian Form for Vector Formulation
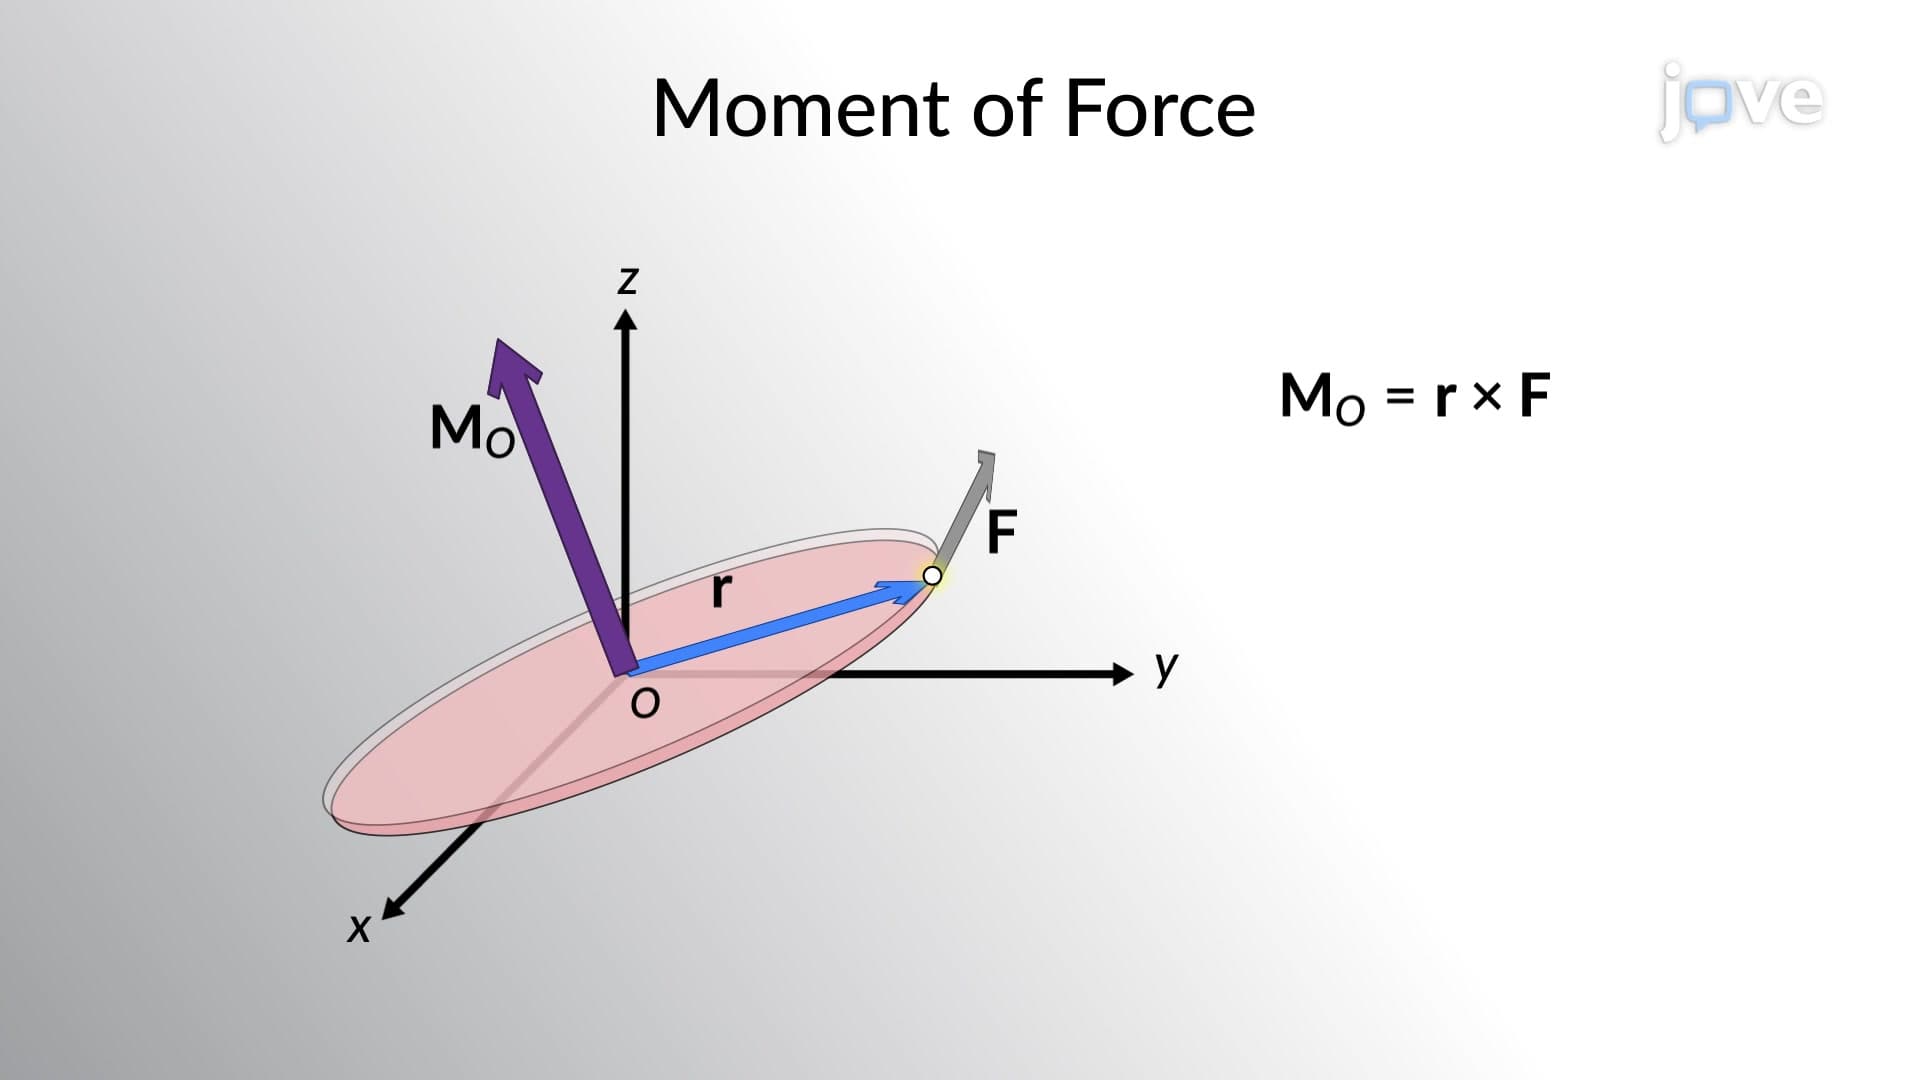
The Cartesian form for vector formulation is a process to calculate  the moment of force using the position and force vectors. The moment of force is defined as the cross-product of these vectors, making it a vector quantity. The Cartesian form of the position and force vectors involves unit vectors, which can be used to express the cross-product in determinant form.
Lagrange Multipliers: Two Constraints01:28

Lagrange Multipliers: Two Constraints
The method of Lagrange multipliers with two constraints is used to optimize a function subject to two independent constraints. In many applications, the objective function represents a quantity to be maximized or minimized, such as cost, area, distance, or energy. The two constraints represent requirements that the solution must satisfy, such as fixed volume, limited resources, or prescribed dimensions.For a function of three variables, each constraint forms a surface in three-dimensional space.
Torsion in Vector Calculus01:20

Torsion in Vector Calculus

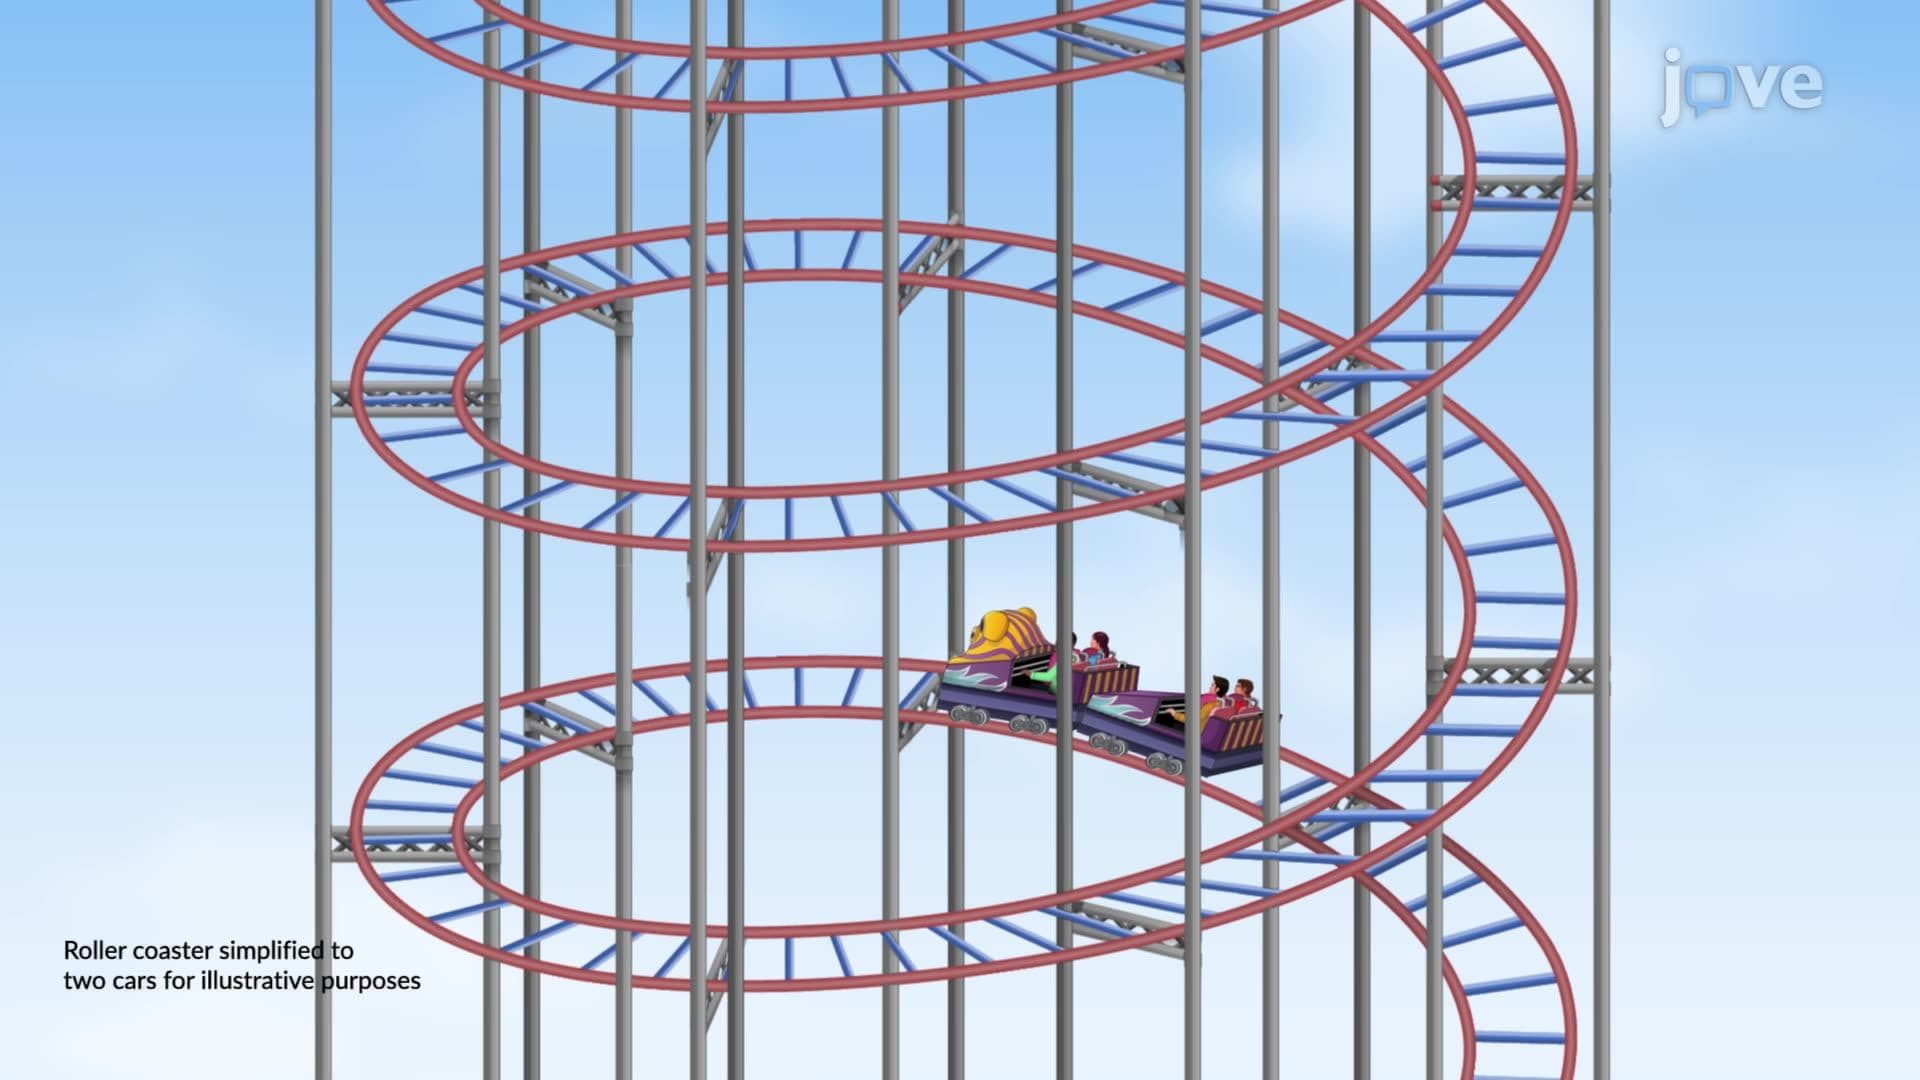
A toy train ascending a winding track that curves and tilts offers an intuitive view of torsion, a key geometric concept in the study of space curves. While curvature measures how sharply a path bends, torsion captures how the path twists out of the plane of bending. This twisting behavior is crucial in understanding three-dimensional motion and is precisely described using the Frenet–Serret framework.At each point along a space curve, the Frenet–Serret frame consists of three orthogonal unit...