Adaptive geometry image
Related Experiment Video
Updated: Jul 5, 2026

Photorealistic Learned Landscapes for Augmented Reality
Published on: June 27, 2025
1Computer Graphics Group/Visual System Laboratory, Department of Computer Science and Information Engineering, National Cheng-Kung University, Tainan, Taiwan, R.O.C. ippo@csie.ncku.edu.tw

Abstract:
We present a novel post-processing utility called adaptive geometry image (AGIM) for global parameterization techniques that can embed a 3D surface onto a rectangular1 domain. This utility first converts a single rectangular parameterization into many different tessellations of square geometry images(GIMs) and then efficiently packs these GIMs into an image called AGIM. Therefore, undersampled regions of the input parameterization can be up-sampled accordingly until the local reconstruction error bound is met. The connectivity of AGIM can be quickly computed and dynamically changed at rendering time. AGIM does not have T-vertices, and therefore no crack is generated between two neighboring GIMs at different tessellations. Experimental results show that AGIM can achieve significant PSNR gain over the input parameterization, AGIM retains the advantages of the original GIM and reduces the reconstruction error present in the original GIM technique. The AGIM is also for global parameterization techniques based on quadrilateral complexes. Using the approximate sampling rates, the PolyCube-based quadrilateral complexes with AGIM can outperform state-of-the-art multichart GIM technique in terms of PSNR.
Related Concept Videos
 01:30
Geometry of Hyperbolas
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:16
Perpendicular-Axis Theorem
Consider a circular disc of mass M and radius R lying along an x-y plane. The origin lies at the center of the disc, and the z-axis is perpendicular to the disc's plane. All three axes coincide at the disc's center. The moment of inertia of this...
 01:27
Gauss's Law: Planar Symmetry
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:12
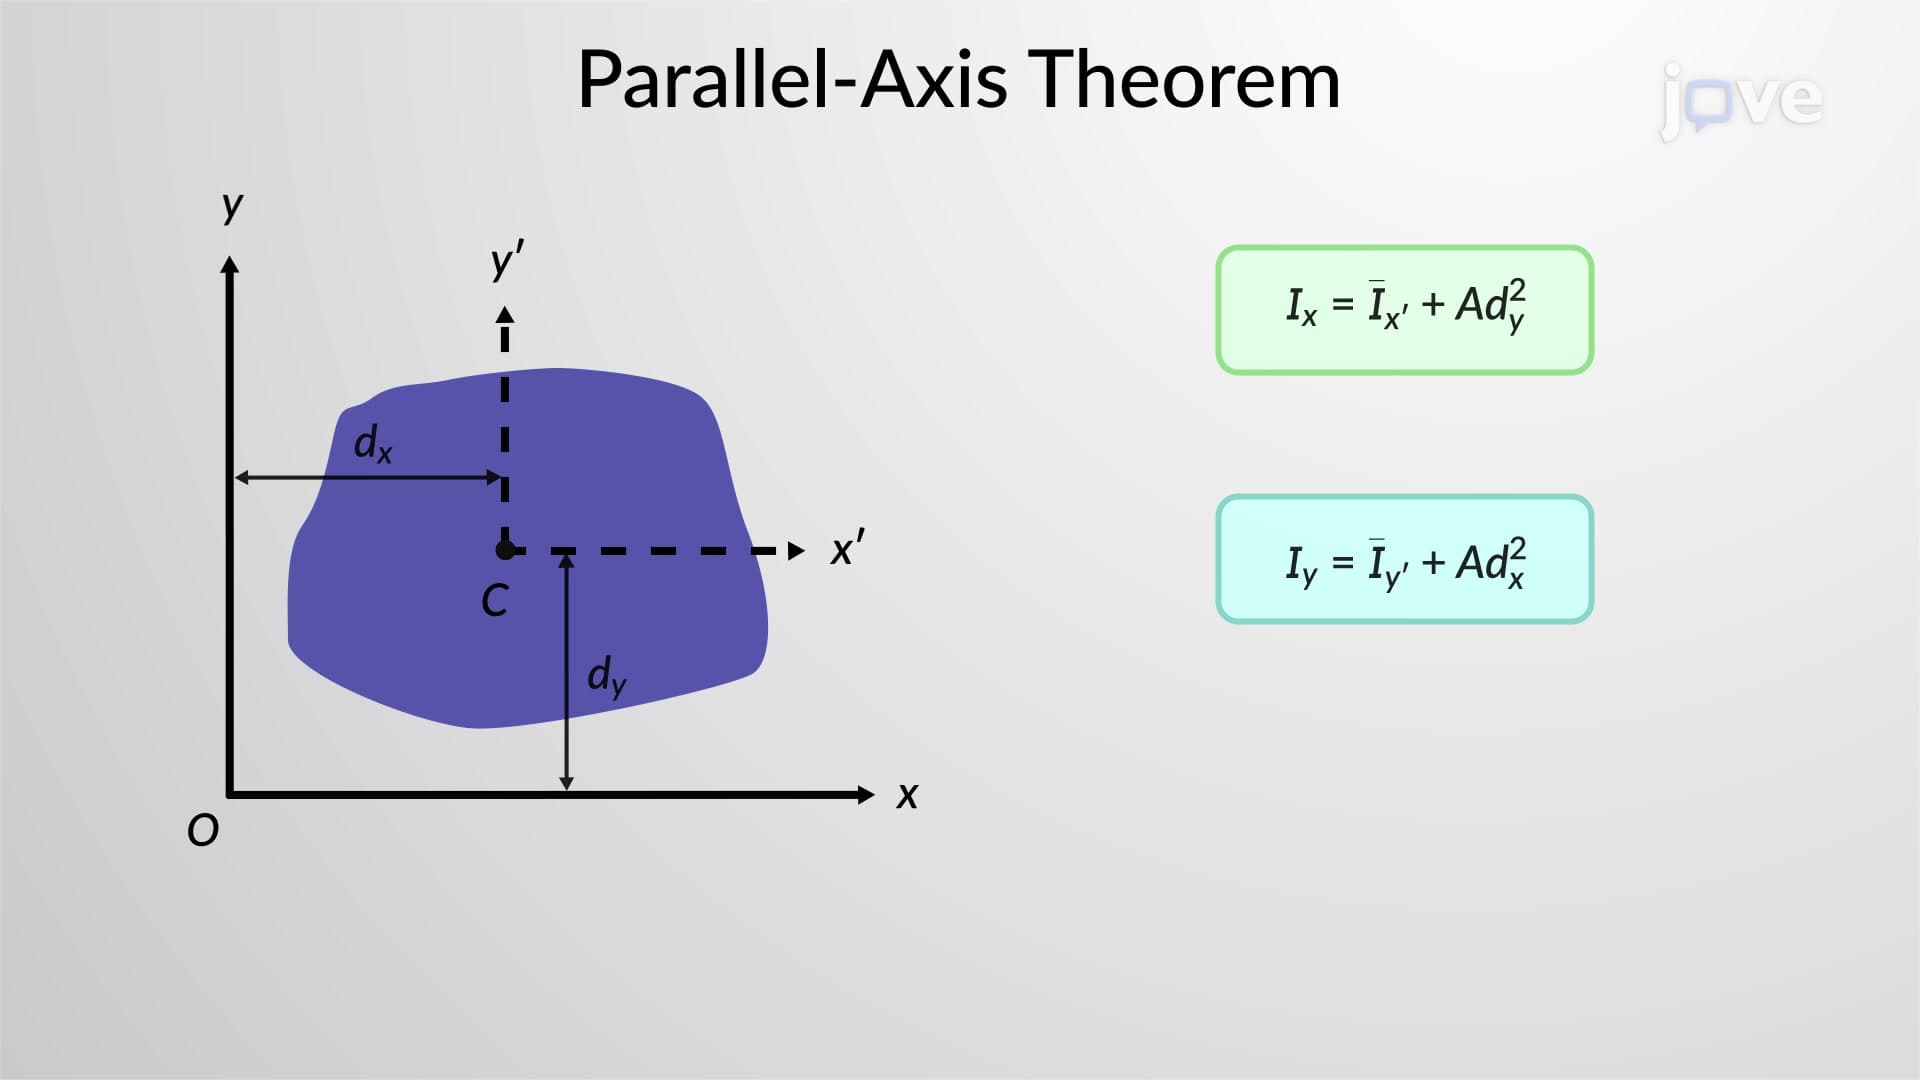
Parallel-Axis Theorem for an Area
For a flywheel approximated as a solid disc, consider an infinitesimal differential element with an arbitrary distance...