Related Experiment Video
Updated: Jul 5, 2026


Oscillation and Reaction Board Techniques for Estimating Inertial Properties of a Below-knee Prosthesis
Published on: May 8, 2014
The perception of limb orientation depends on the center of mass
Rolf van de Langenberg1, Idsart Kingma, Peter J Beek
1Faculty of Human Movement Sciences, VU University Amsterdam, Amsterdam, The Netherlands. r.vdlangenberg@fbw.vu.nl

Abstract:
Three experiments were conducted to test the hypothesis that the perception of limb orientation depends on inertial eigenvectors against the alternative that it depends on the center of mass. In all experiments, each participant pointed at visible targets with his or her occluded right arm while center-of-mass and inertial eigenvectors were manipulated independently. In Experiments 1 and 2, the arm was constrained to rotate exclusively about the shoulder, whereas in Experiment 3, the arm was allowed to rotate freely about both the shoulder and the elbow. The mechanical manipulations were applied either in the horizontal (Experiments 1 and 3) or vertical (Experiment 2) plane. Across experiments, pointing direction was affected by the center of mass and not by the inertial eigenvectors, albeit that simultaneous manipulation of both resulted in a more pronounced pointing bias than the isolated center-of-mass manipulation. These findings challenge the inertial eigenvector hypothesis and suggest that the center of mass plays a generic role in the perception of limb orientation.
Related Concept Videos
 00:59
Center of Mass
The knowledge of the center of mass can also help us to describe and predict the motion of objects. For example, when a ball is thrown into...
 01:03
Center of Mass: Introduction
 01:03
Finding the Center of Gravity
 00:58
Center of Gravity
 01:15
Center of Gravity
To determine its location, the principle of moments can be utilized by dividing the object into...
 01:12
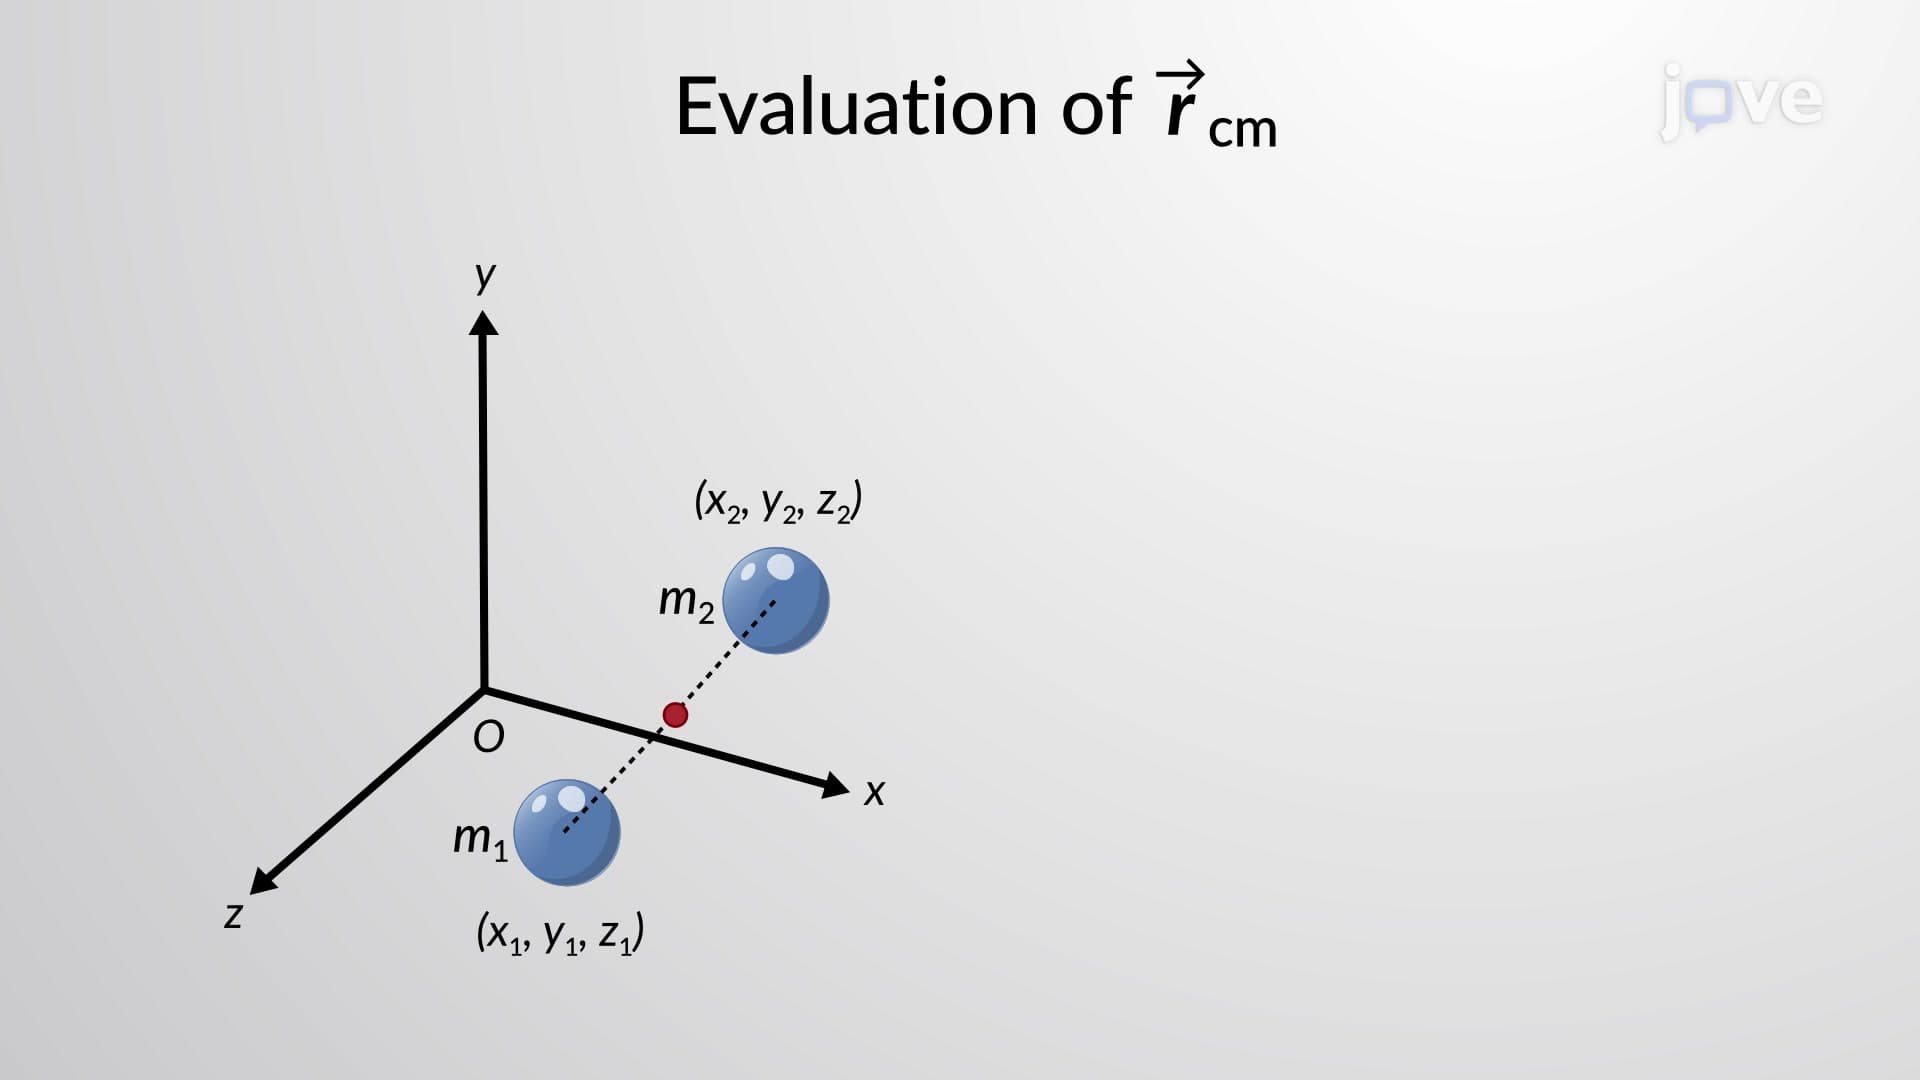
Significance of Center of Mass