Related Experiment Video
Updated: Jul 4, 2026

Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
The inverted pendulum model of bipedal standing cannot be stabilized through direct feedback of force and contractile
A J Knoek van Soest1, Leonard A Rozendaal
1Faculty of Human Movement Sciences and Research Institute MOVE, VU University, Van der Boechorststraat 9, Amsterdam, The Netherlands. k.vansoest@fbw.vu.nl

Abstract:
Control of bipedal standing is typically analyzed in the context of a single-segment inverted pendulum model. The stiffness K (SE) of the series elastic element that transmits the force generated by the contractile elements of the ankle plantarflexors to the skeletal system has been reported to be smaller in magnitude than the destabilizing gravitational stiffness K ( g ). In this study, we assess, in case K (SE) + K ( g ) < 0, if bipedal standing can be locally stable under direct feedback of contractile element length, contractile element velocity (both sensed by muscle spindles) and muscle force (sensed by Golgi tendon organs) to alpha-motoneuron activity. A theoretical analysis reveals that even though positive feedback of force may increase the stiffness of the muscle-tendon complex to values well over the destabilizing gravitational stiffness, dynamic instability makes it impossible to obtain locally stable standing under the conditions assumed.
Related Concept Videos
 01:18
Indeterminate Structure
 01:10
Simple Pendulum
The period of a simple pendulum depends on two factors: its length and the acceleration due to gravity. The period is completely independent of any other factors, such as mass or maximum displacement. For small displacements, a pendulum is...
 01:06
Physical Pendulum
When dealing with complicated systems, the mass moment of inertia is an important parameter, as it describes the mass...
 01:14
Stability of structures
 01:13
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...
 01:09
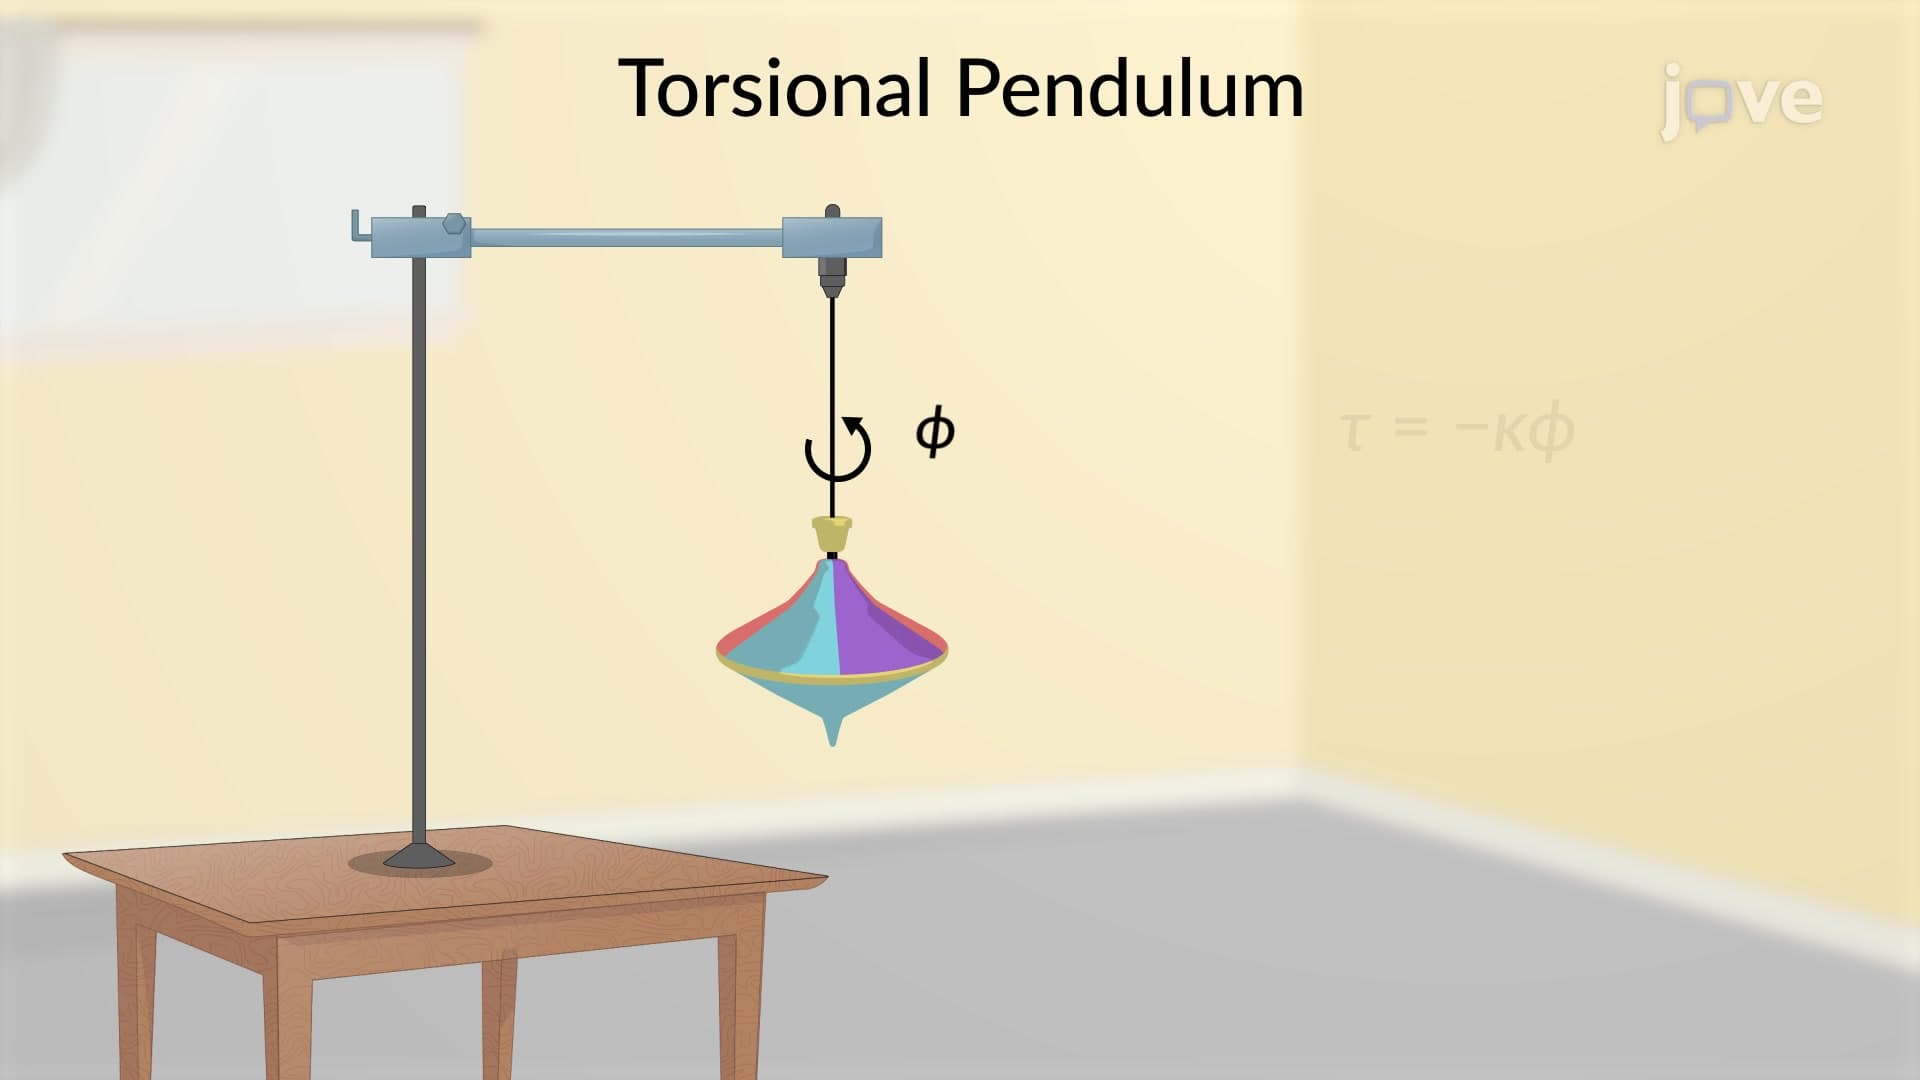
Torsional Pendulum
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played by the...