Explaining savings for visuomotor adaptation: linear time-invariant state-space models are not sufficient
Related Experiment Video
Updated: Jul 4, 2026

Visualizing Visual Adaptation
Published on: April 24, 2017
Eric Zarahn1, Gregory D Weston, Johnny Liang
1Motor Performance Laboratory, The Neurological Institute, New York, NY 10032, USA. ez84@columbia.edu

Abstract:
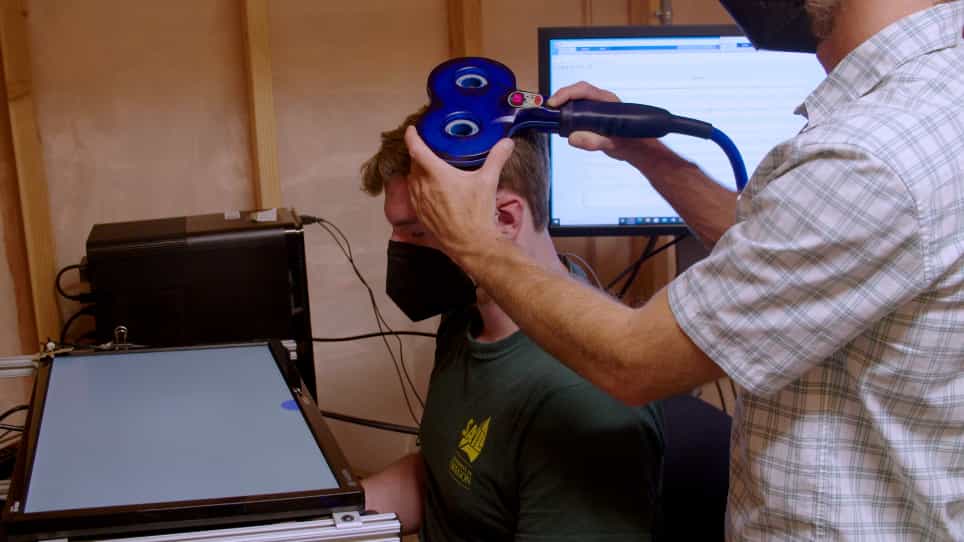
Adaptation of the motor system to sensorimotor perturbations is a type of learning relevant for tool use and coping with an ever-changing body. Memory for motor adaptation can take the form of savings: an increase in the apparent rate constant of readaptation compared with that of initial adaptation. The assessment of savings is simplified if the sensory errors a subject experiences at the beginning of initial adaptation and the beginning of readaptation are the same. This can be accomplished by introducing either 1) a sufficiently small number of counterperturbation trials (counterperturbation paradigm [CP]) or 2) a sufficiently large number of zero-perturbation trials (washout paradigm [WO]) between initial adaptation and readaptation. A two-rate, linear time-invariant state-space model (SSM(LTI,2)) was recently shown to theoretically produce savings for CP. However, we reasoned from superposition that this model would be unable to explain savings for WO. Using the same task (planar reaching) and type of perturbation (visuomotor rotation), we found comparable savings for both CP and WO paradigms. Although SSM(LTI,2) explained some degree of savings for CP it failed completely for WO. We conclude that for visuomotor rotation, savings in general is not simply a consequence of LTI dynamics. Instead savings for visuomotor rotation involves metalearning, which we show can be modeled as changes in system parameters across the phases of an adaptation experiment.
More Related Videos

Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be calculated...
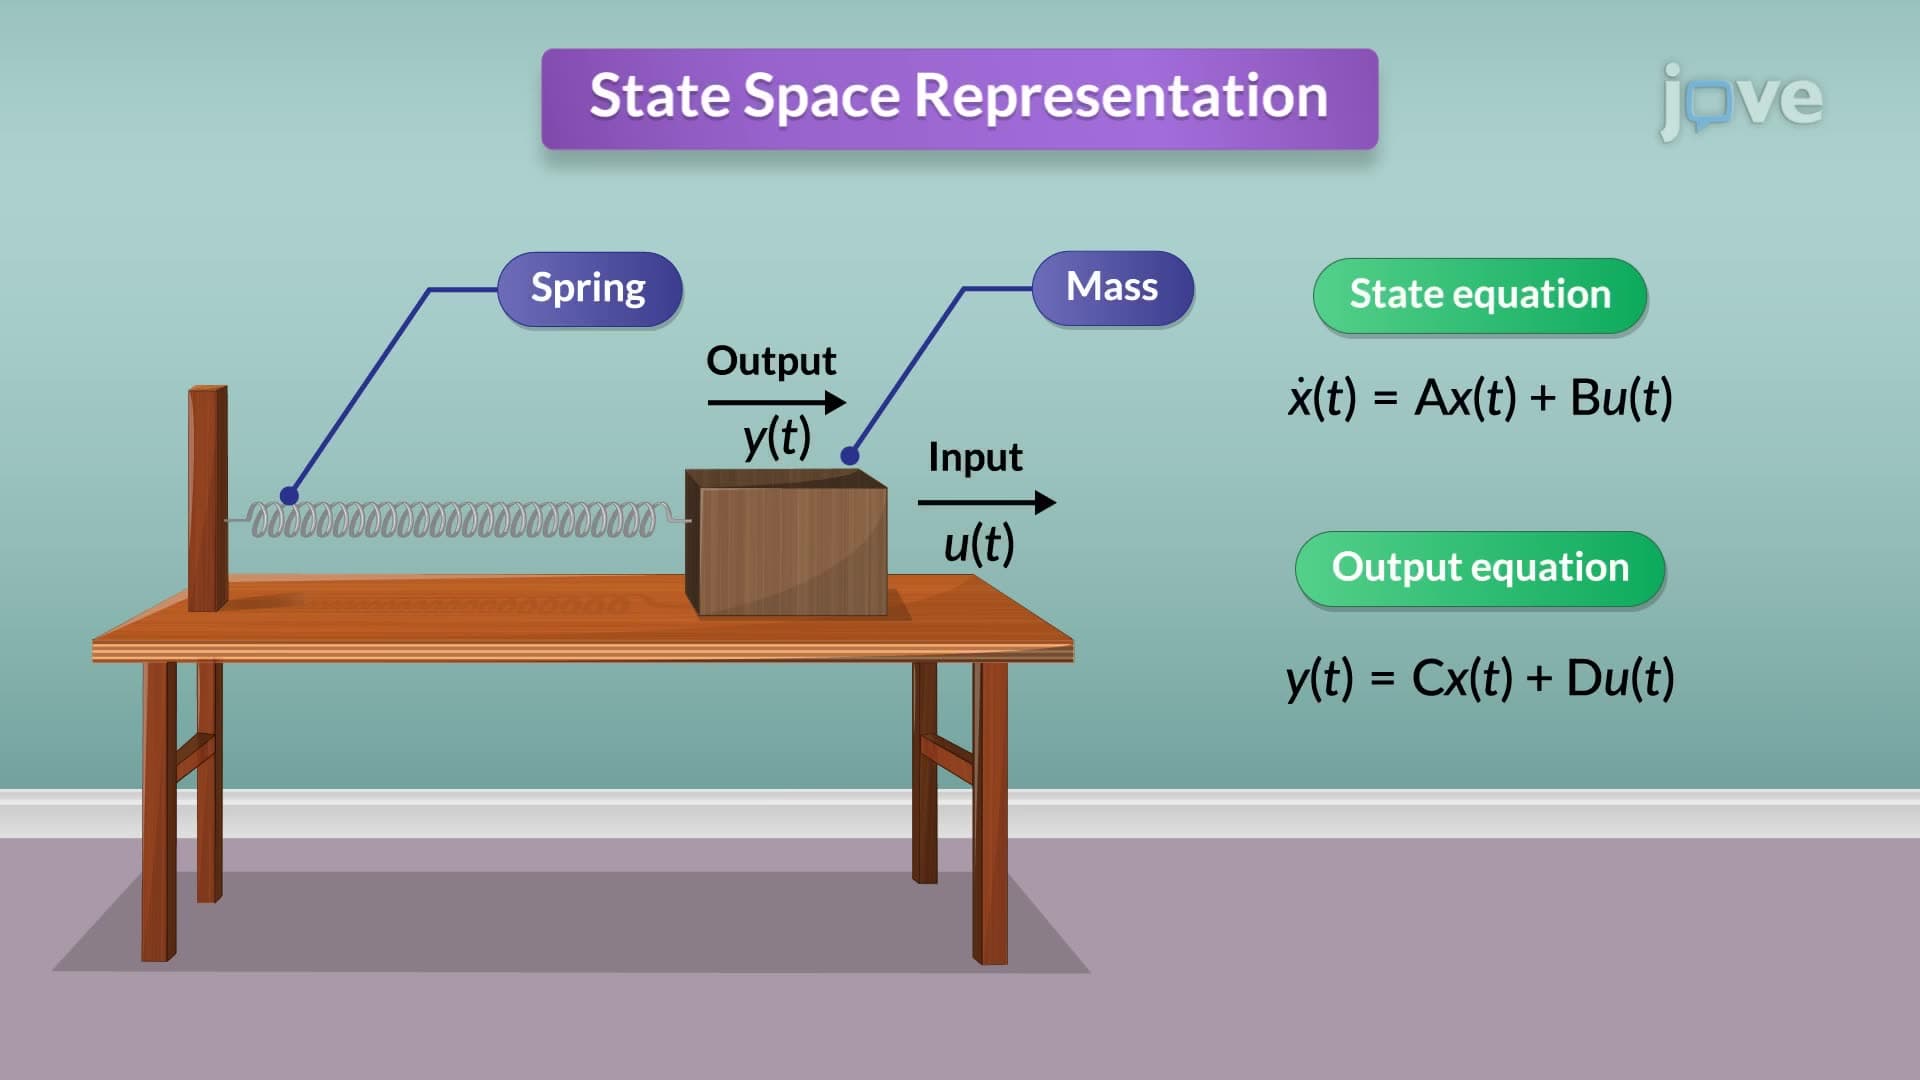 01:21
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
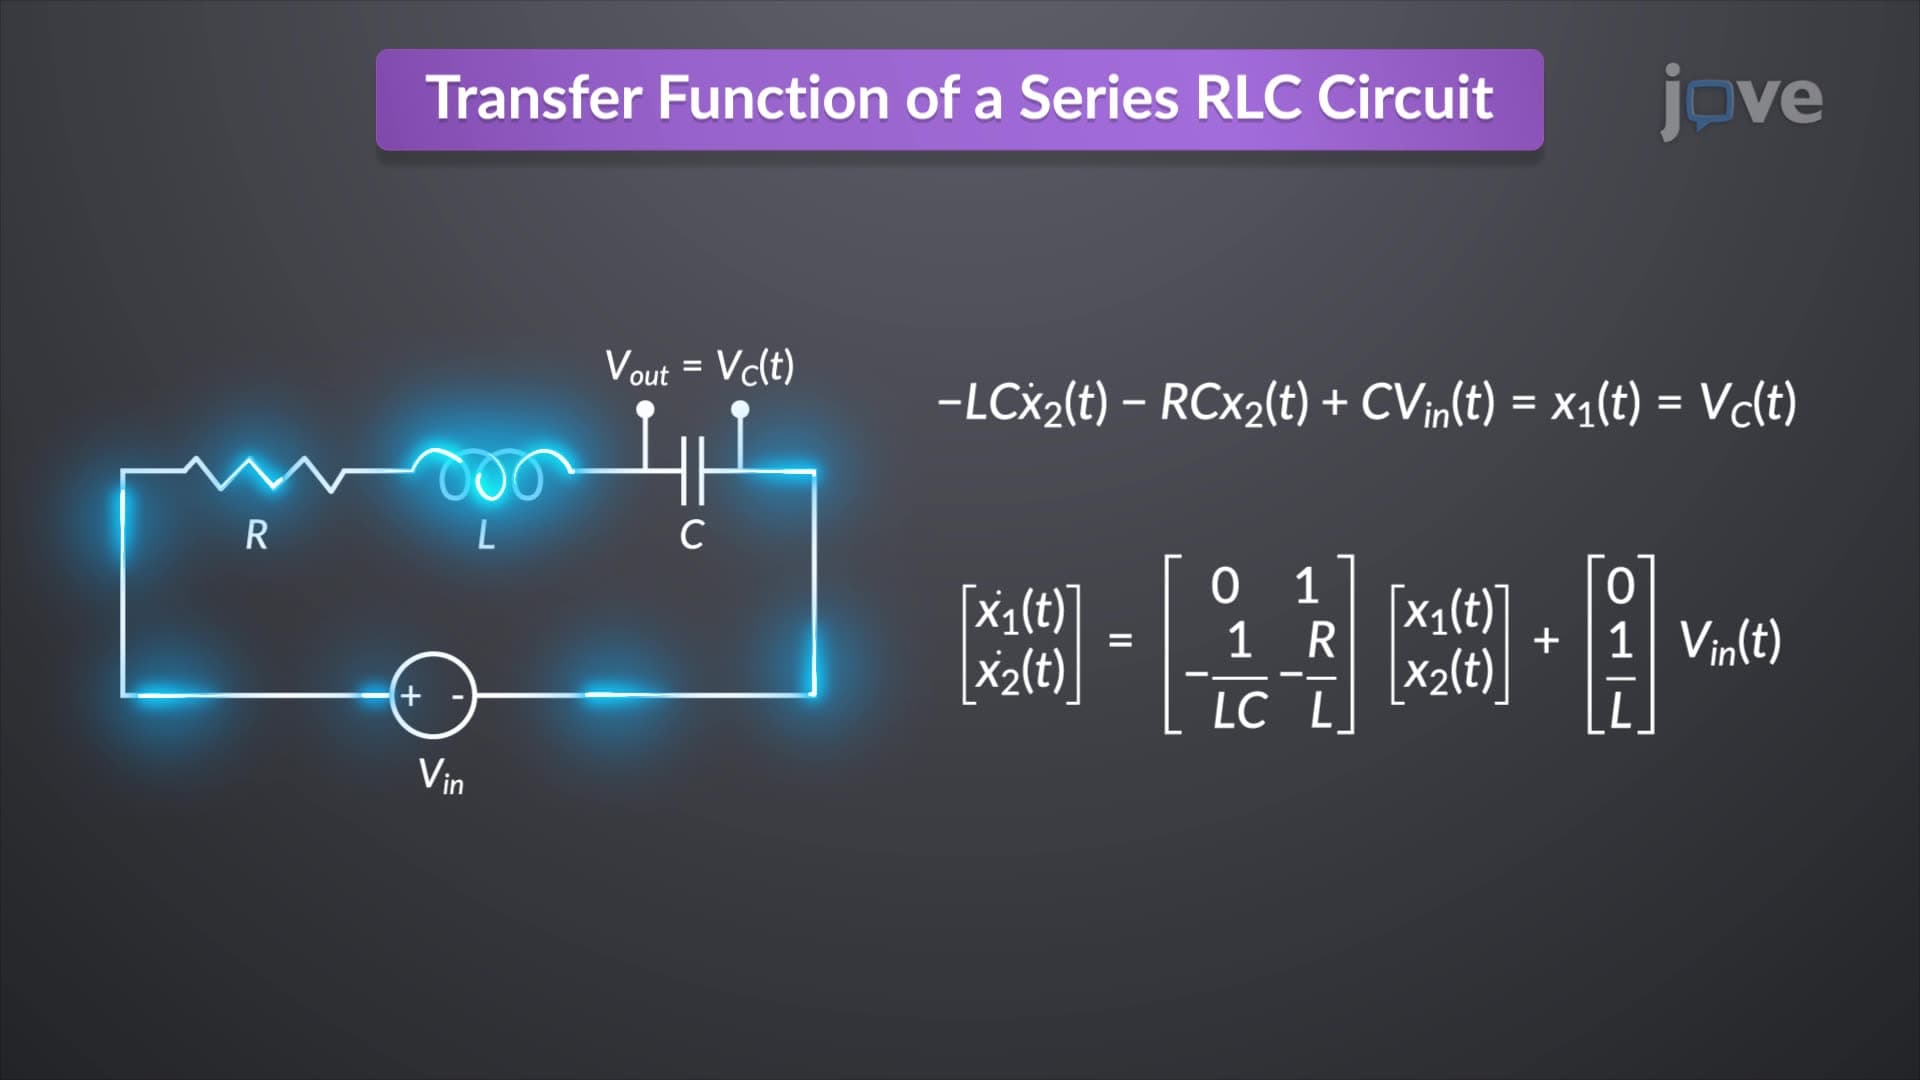 01:23
Transfer Function to State Space
In an RLC...
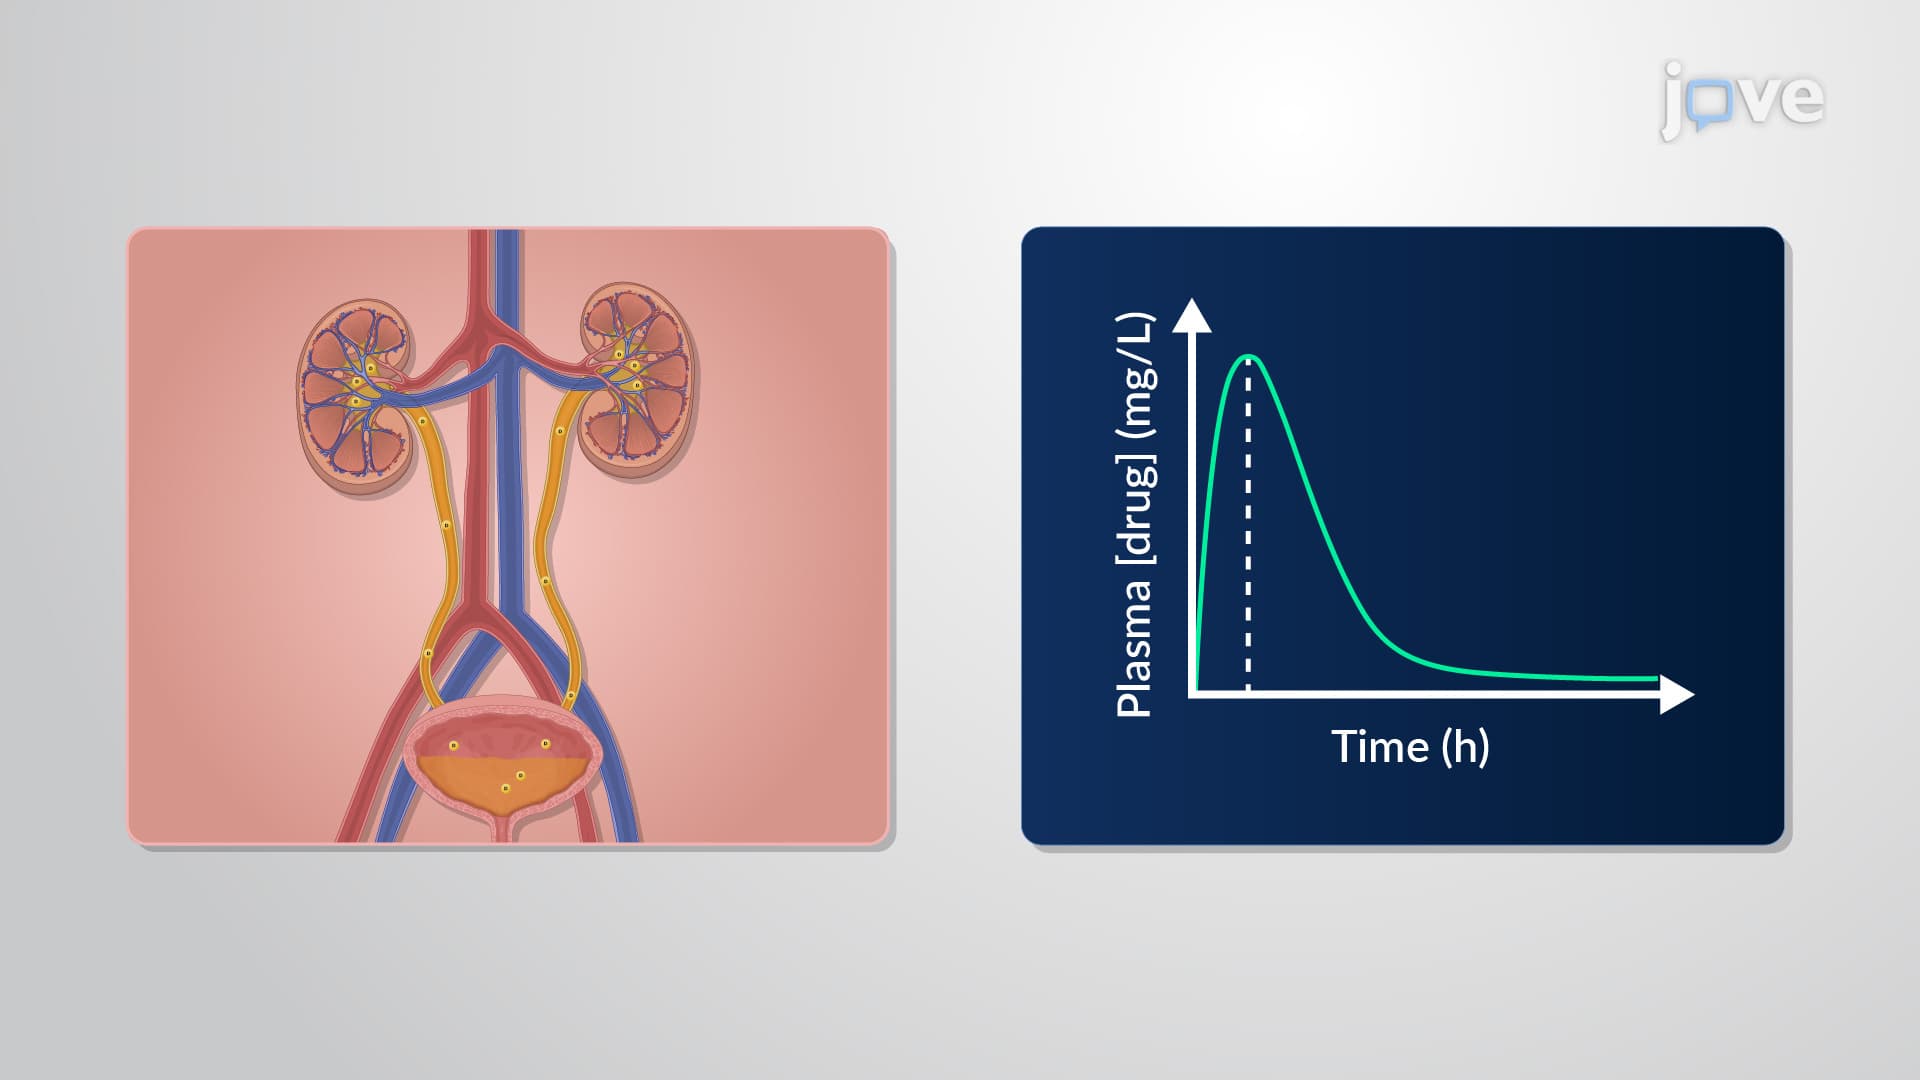 01:13
Parameters Affecting Nonlinear Elimination: Zero-Order Input, First-Order Absorption and Two-Compartment Model
When a drug is administered through a constant intravenous infusion and eliminated via nonlinear pharmacokinetics, it follows zero-order input. For example, oral drugs undergo first-order absorption upon administration and are eliminated through nonlinear pharmacokinetics.
In the case of subcutaneously administered drugs,...