Related Experiment Video
Updated: Jul 3, 2026
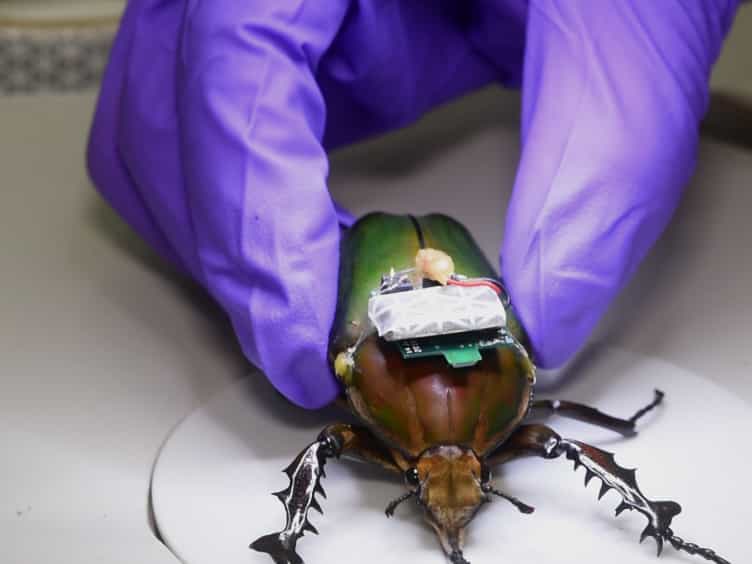

Insect-machine Hybrid System: Remote Radio Control of a Freely Flying Beetle (Mercynorrhina torquata)
Published on: September 2, 2016
Controlling a system with redundant degrees of freedom. I. Torque distribution in still standing stick insects
1Department of Biological Cybernetics and Theoretical Biology, University of Bielefeld, PO Box 10 01 31, Bielefeld 33501, Germany. jeremy.levy@uni-bielefeld.de

Abstract:
The question is investigated as to how a stick insect solves the task of distributing its body weight onto its six legs, i.e., how are the torques coordinated that are produced by the 18 joints (3 per leg). Three-dimensional force measurements of ground reaction forces have been used to calculate the torques developed by each of the 18 joints. Torques were found to change considerably although the body and the legs of the animal did not move. This result implies a tight cooperation between the 18 joint controllers. Indeed, in each individual experiment, strong correlations could be observed between specific pairs of joints. However, in spite of thorough analysis, no general correlation rules between torques could be detected. The only common attribute found for all experiments was that high absolute torques observed at the beginning of the experiment tend to converge to some minimum over time. Thus, the insects tend to decrease the torques while standing still, but do not use fixed rules. Rather they appear to exploit their extra degrees of freedom and produce time courses that can strongly vary between experiments. Possible mechanisms underlying this behaviour are discussed in a companion paper [Lévy and Cruse (2008) Controlling a system with redundant degrees of freedom: ii. solution of the force distribution problem without a body model, submitted].
Related Concept Videos
 01:14
Stability of structures
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:10
Torque
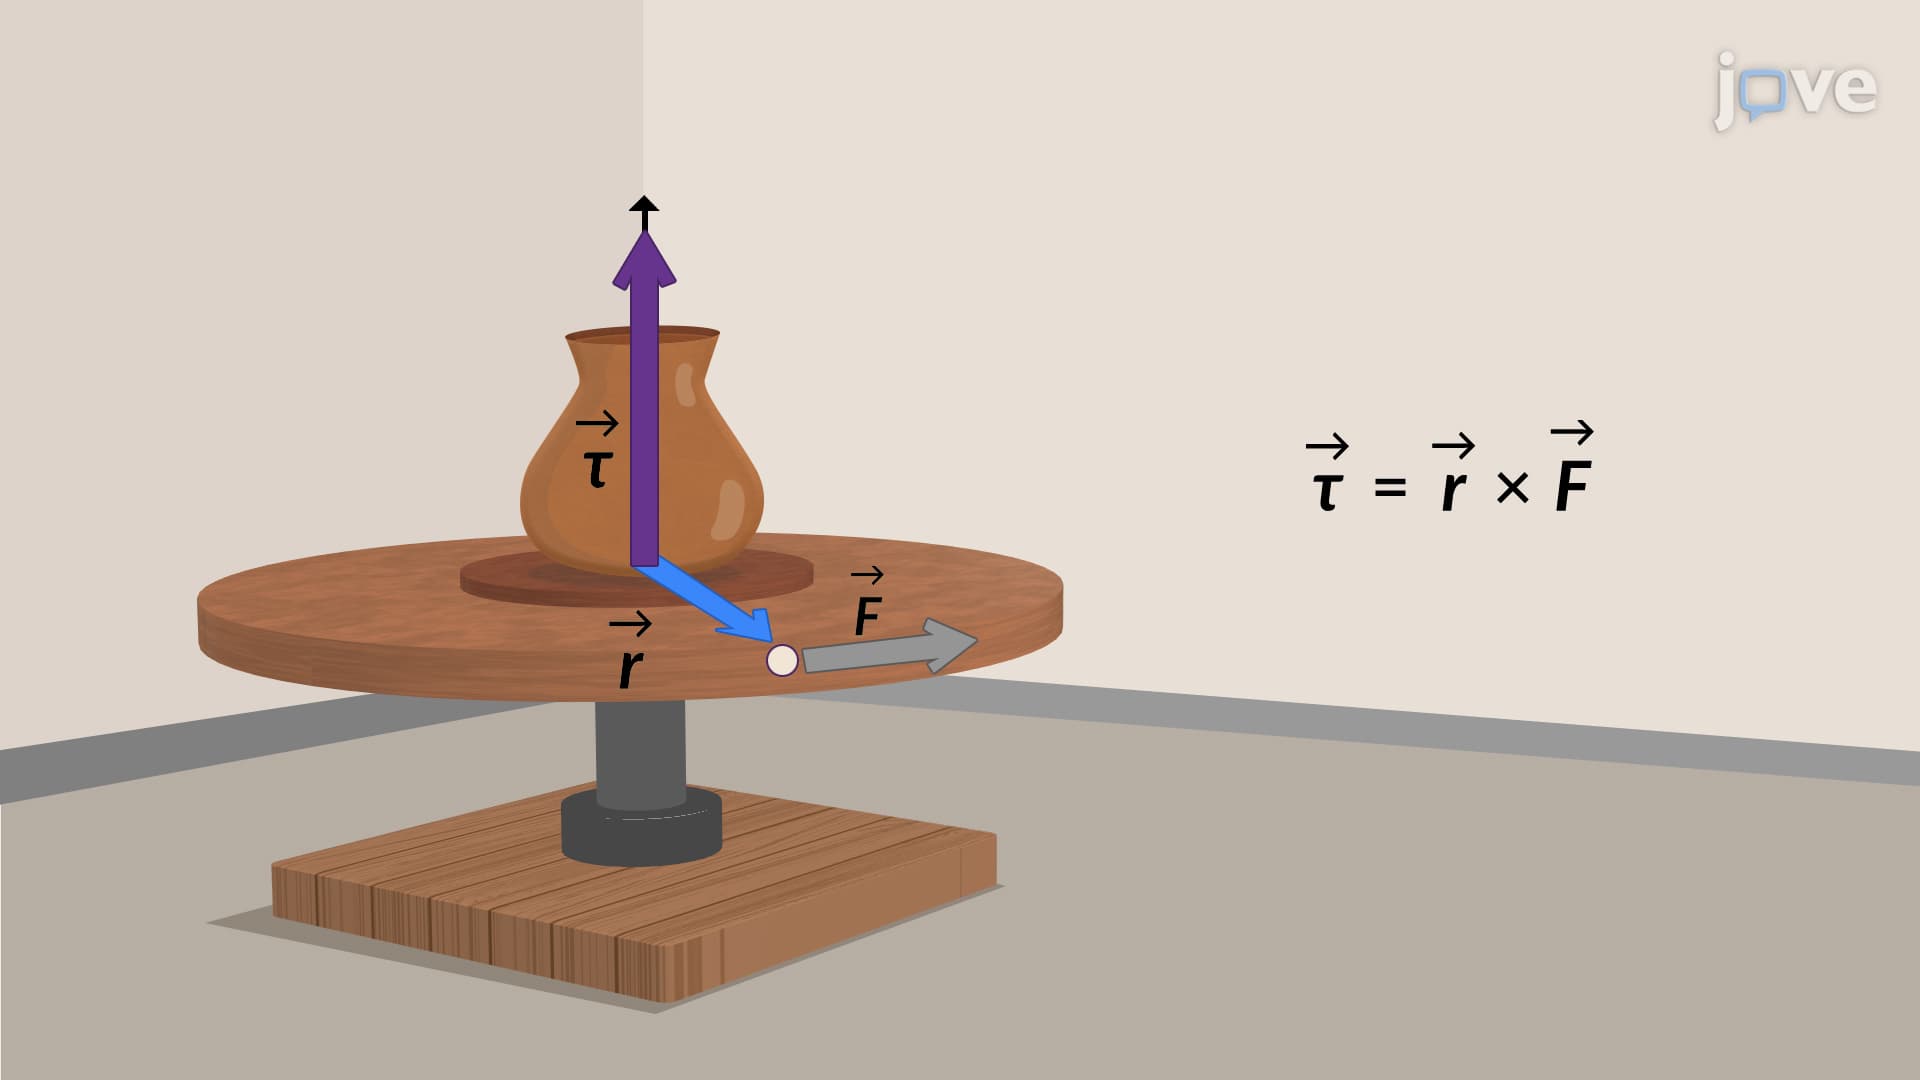
Torque can be considered as the rotational counterpart to force. Since forces change the translational...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...