Duffing oscillators: control and memory effects

Adriano A Batista1, F A Oliveira, H N Nazareno

  • 1Departamento de Física, Universidade Federal de Campina Grande, Campina Grande, Paraíba, 58109-970, Brazil.

Related Concept Videos

Design Example: Underdamped Parallel RLC Circuit01:17

Design Example: Underdamped Parallel RLC Circuit

Consider designing an oscillator circuit, a crucial component in various electronic devices and systems. The objective is to create an oscillator circuit with specific characteristics: a damped natural frequency of 4 kHz and a damping factor of 4 radians per second. To accomplish this, a parallel RLC circuit is employed, known for its ability to sustain oscillations at a resonant frequency. In this case, the damping factor is pivotal in achieving the desired performance.
Starting with a fixed...
Oscillations In An LC Circuit01:30

Oscillations In An LC Circuit

An idealized LC circuit of zero resistance can oscillate without any source of emf by shifting the energy stored in the circuit between the electric and magnetic fields. In such an LC circuit, if the capacitor contains a charge q before the switch is closed, then all the energy of the circuit is initially stored in the electric field of the capacitor. This energy is given by
Time-Domain Interpretation of PD Control01:07

Time-Domain Interpretation of PD Control

Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...
Types of Damping01:20

Types of Damping

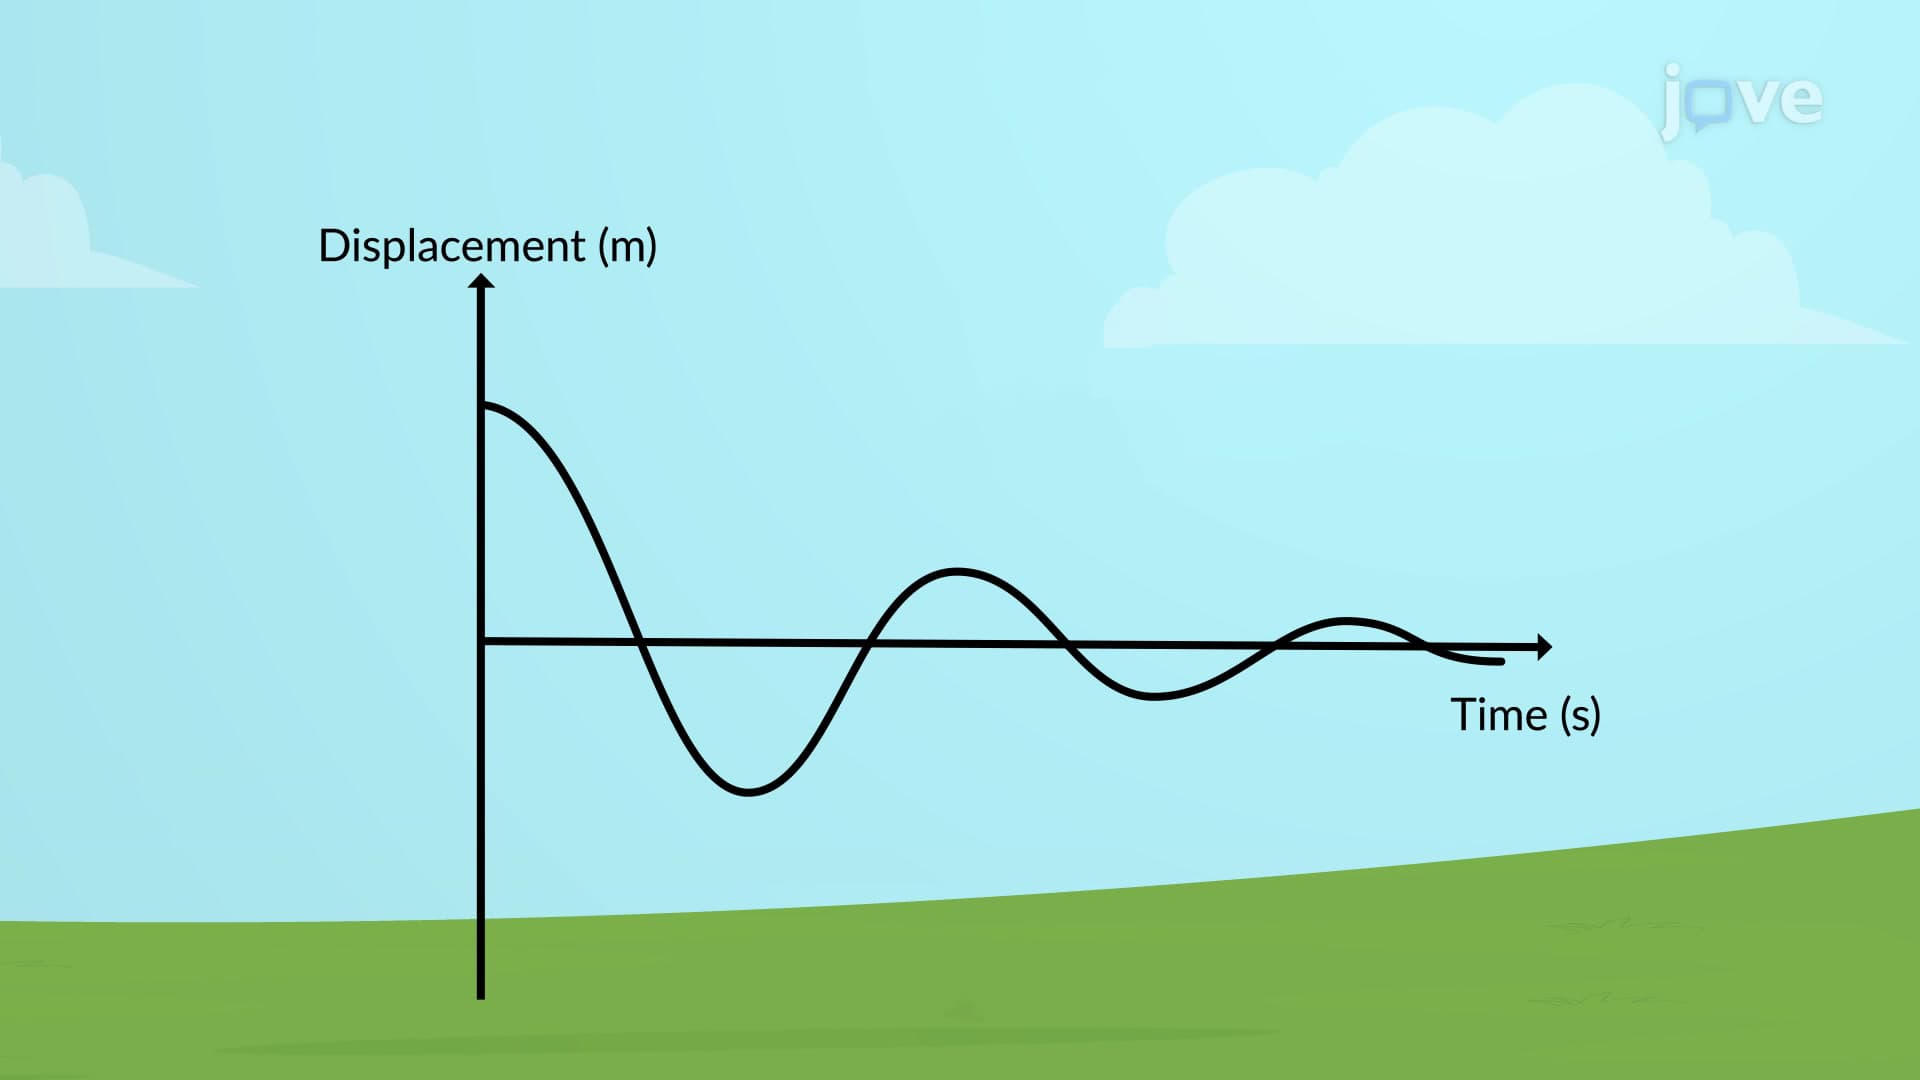
If the amount of damping in a system is gradually increased, the period and frequency start to become affected because damping opposes, and hence slows, the back and forth motion (the net force is smaller in both directions). If there is a very large amount of damping, the system does not even oscillate; instead, it slowly moves toward equilibrium. In brief, an overdamped system moves slowly towards equilibrium, whereas an underdamped system moves quickly to equilibrium but will oscillate about...
Damped Oscillations01:07

Damped Oscillations

In the real world, oscillations seldom follow true simple harmonic motion. A system that continues its motion indefinitely without losing its amplitude is termed undamped. However, friction of some sort usually dampens the motion, so it fades away or needs more force to continue. For example, a guitar string stops oscillating a few seconds after being plucked. Similarly, one must continually push a swing to keep a child swinging on a playground.
Although friction and other non-conservative...
Frequency-Domain Interpretation of PD Control01:24

Frequency-Domain Interpretation of PD Control

Proportional-Derivative (PD) controllers are widely used in fan control systems to improve stability and performance. A fan control system can be effectively represented using a Bode plot to illustrate the impact of a PD controller through its transfer function. The Bode plot visually conveys how PD control modifies the fan's response across various frequencies, providing a frequency domain interpretation of the controller's behavior.
The proportional control gain, combined with the system's...