Related Experiment Video
Updated: Jul 2, 2026

Measuring the Structure, Composition, and Change of Underwater Environments with Large-area Imaging
Published on: April 18, 2025
Estimation of relative order tensors, and reconstruction of vectors in space using unassigned RDC data and its
Xijiang Miao1, Rishi Mukhopadhyay, Homayoun Valafar
1Computer Science and Engineering, Swearingen Engineering Center, University of South Carolina, Columbia, SC 29308, USA.

Abstract:
Advances in NMR instrumentation and pulse sequence design have resulted in easier acquisition of Residual Dipolar Coupling (RDC) data. However, computational and theoretical analysis of this type of data has continued to challenge the international community of investigators because of their complexity and rich information content. Contemporary use of RDC data has required a-priori assignment, which significantly increases the overall cost of structural analysis. This article introduces a novel algorithm that utilizes unassigned RDC data acquired from multiple alignment media (nD-RDC, n3) for simultaneous extraction of the relative order tensor matrices and reconstruction of the interacting vectors in space. Estimation of the relative order tensors and reconstruction of the interacting vectors can be invaluable in a number of endeavors. An example application has been presented where the reconstructed vectors have been used to quantify the fitness of a template protein structure to the unknown protein structure. This work has other important direct applications such as verification of the novelty of an unknown protein and validation of the accuracy of an available protein structure model in drug design. More importantly, the presented work has the potential to bridge the gap between experimental and computational methods of structure determination.
Related Concept Videos
 01:00
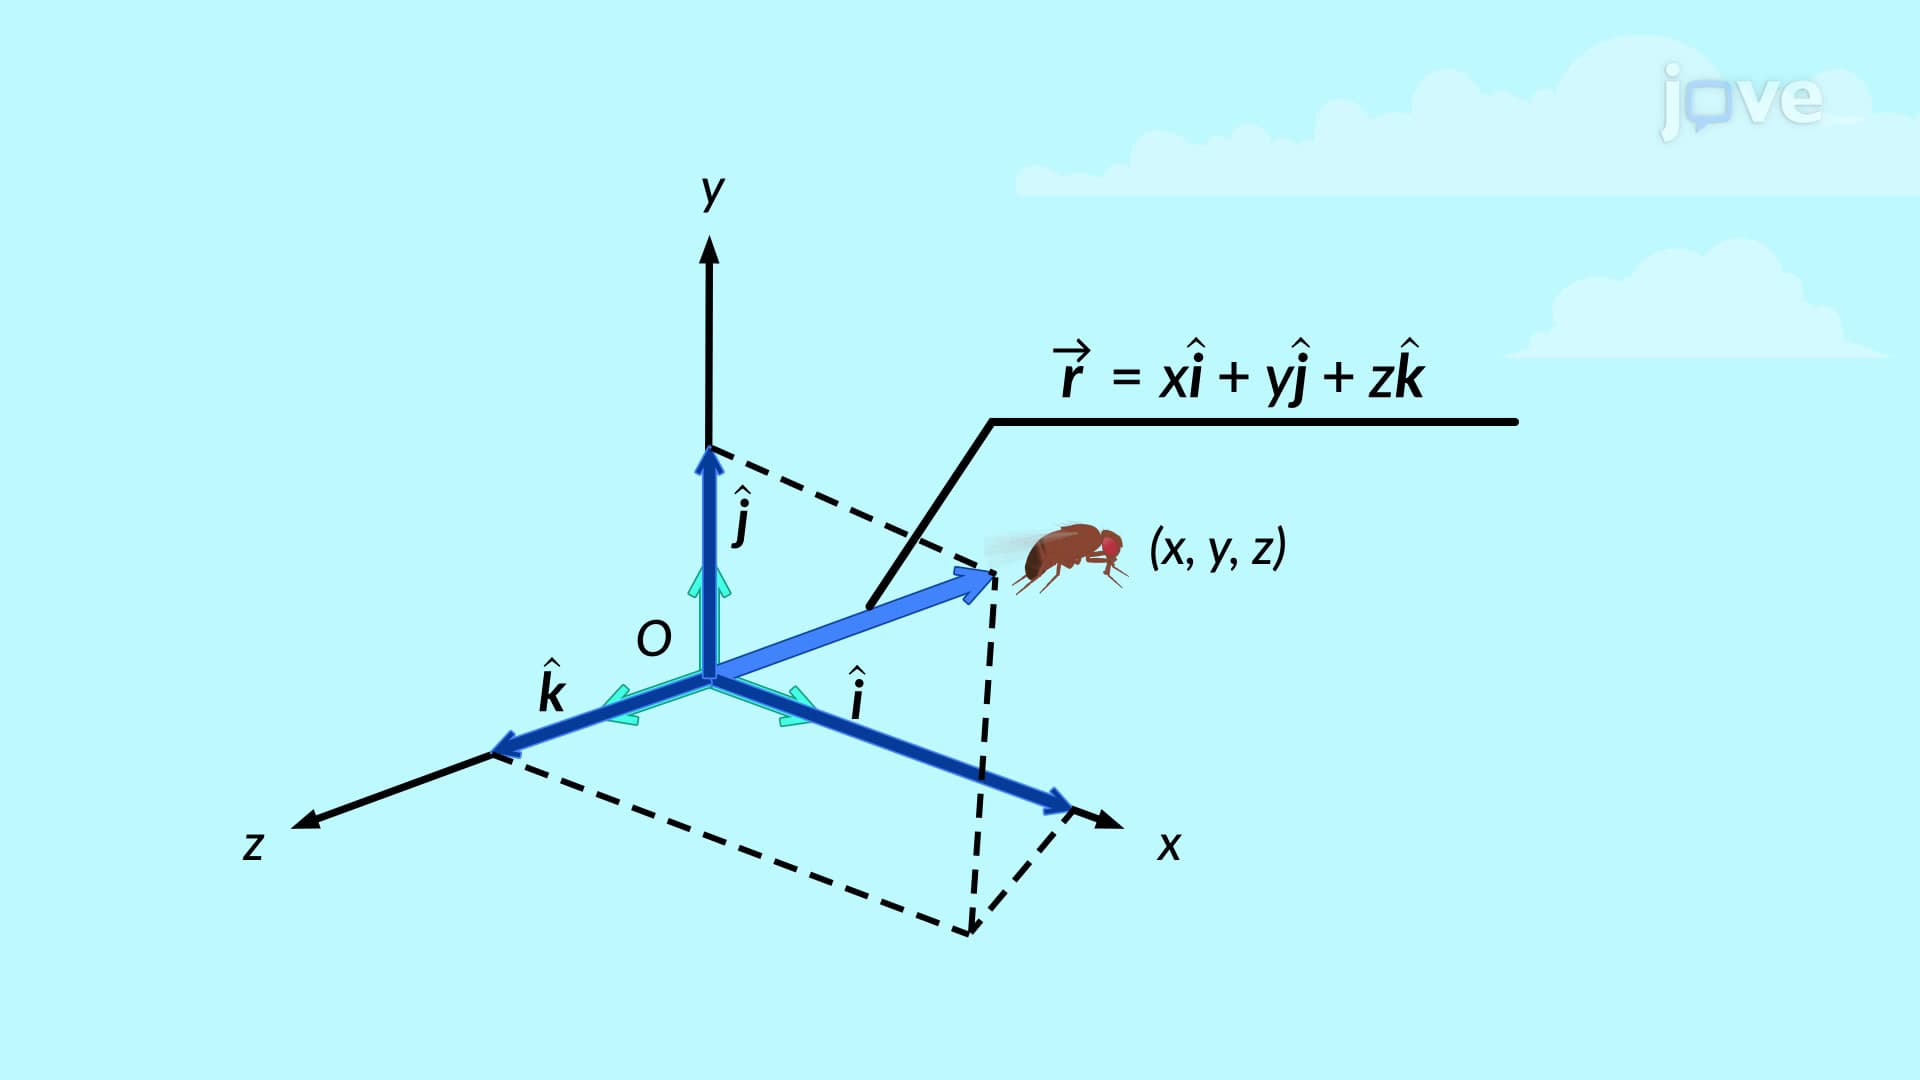
Position and Displacement Vectors
Further, several important kinds of...
01:00Position and Displacement Vectors
Further, several important kinds of...
 01:30
Vector Functions and Motion: Problem Solving
 01:29
Lines in Space
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...