Related Experiment Video
Updated: Jul 2, 2026

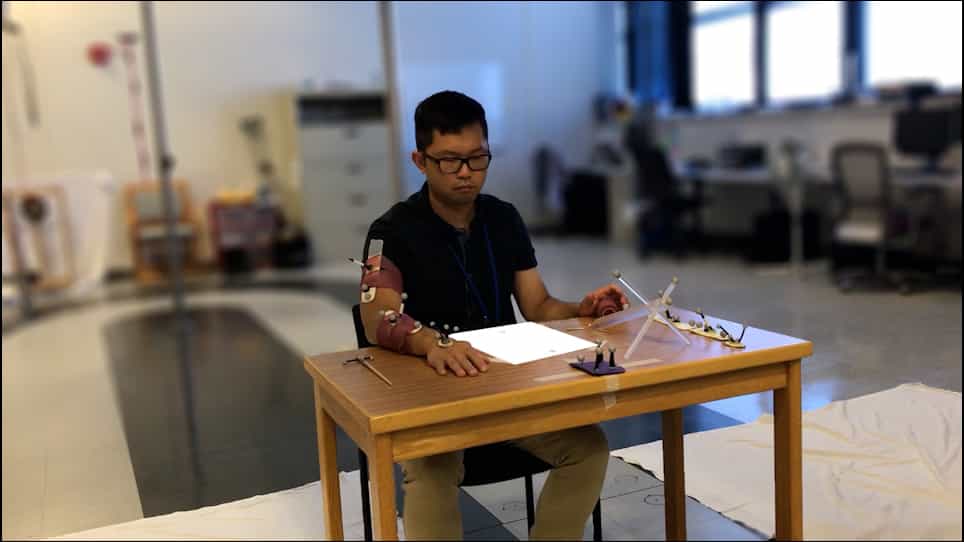
Kinematic Analysis Using 3D Motion Capture of Drinking Task in People With and Without Upper-extremity Impairments
Published on: March 28, 2018
Influence of age and movement complexity on kinematic hand movement parameters in childhood and adolescence
Stefan Mark Rueckriegel1, Friederike Blankenburg, Roland Burghardt
1Pediatric Neurooncology Program, Department of Pediatric Oncology and Hematology, Charité-Universitätsmedizin Berlin, Augustenburger Platz 1, 13353 Berlin, Germany.

Abstract:
Development of fine motor functions, especially drawing and handwriting, are crucial for performance in school, autonomy in everyday life and the general human development. A variety of neurological and psychiatric conditions in childhood and adolescence stunt the normal development of fine motor skills. We sought to define the normal development of the kinematic parameters of fine motor movement and determine the influence of gender, laterality of handedness and extracurricular training on fine motor skills. One hundred and eighty-seven children and adolescents (mean age: 11.6 years (+/-S.D.: 3.58), range: 6-18 years) were included in the study. Participants performed drawing and handwriting tasks on a digitizing graphic tablet. Movement and pressure data were transferred to a computer using a sensor-equipped pen and post-processed using CSWIN. Movements were segmented into strokes and several kinematic parameters were calculated. The kinematic parameters that were analyzed represented speed (frequency and stroke peak velocity), automation (number of direction changes of velocity per stroke), variability (variation coefficient of stroke peak velocity) and pressure. Progression of kinematic parameters for each movement domain of the handwriting and circle drawing tasks correlated significantly with age (Pearson's correlation, p<0.003). Speed, automation and pressure increased with age, whereas variability decreased. Nonlinear regressions revealed maturation of hand movements at a certain age. Age of completed maturation depended on the task complexity (drawing circles vs. handwriting) and kinematic parameters. In the speed and automation domains, handwriting movements finish maturing later than circle drawing. Male subjects drew circles at significantly higher speeds than female subjects. Fine motor practice and laterality of handedness did not influence kinematic parameters. A repeated measure ANOVA confirmed the significant interdependency between age and complexity level for speed and automation (p<0.001). The digitizing graphic tablet is an extremely valuable tool in determining the normal development of hand movement skills of children and adolescents by measuring relevant daily tasks like handwriting and drawing. In our study, we showed that future analyses of impaired movement in children and adolescents need to take age and gender into consideration. Furthermore, differences were observed in the maturation of different task complexities, the complex fine motor function reaching maturity later than basic and repetitive movement patterns.
Related Concept Videos
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:15
Kinematic Equations: Problem Solving
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:18
Hierarchy of Motor Control
 01:09
Changes in the Appendicular Skeleton with Age
Initially, the limb buds consist of a core of mesenchyme covered by a layer of ectoderm. The ectoderm at the end of the limb bud thickens to form a narrow crest called the apical ectodermal ridge. This ridge stimulates the underlying...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...