Related Experiment Video
Updated: Jul 2, 2026
A Modified Lean and Release Technique to Emphasize Response Inhibition and Action Selection in Reactive Balance
Published on: March 19, 2020
Stepping to recover balance in complex environments: is online visual control of the foot motion necessary or
Carol Y Scovil1, John L Zettel, Brian E Maki
1Centre for Studies in Aging, Sunnybrook Health Sciences Centre, Canada.

Abstract:
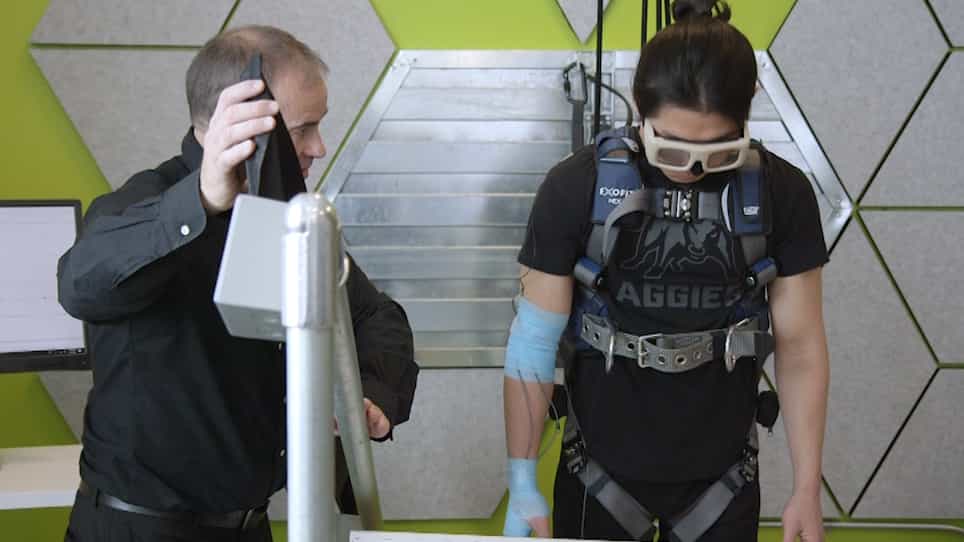
Rapid step reactions evoked by balance perturbation must accommodate constraints on limb motion imposed by obstacles and other environmental features. Recent results suggest that the required visuospatial information (VSI) is acquired and stored "proactively", prior to perturbation onset (PO); however, the extent to which "online" (post-PO) visual feedback can contribute is not known. To study this, we used large unpredictable platform perturbations to evoke rapid step reactions, while subjects wore liquid crystal goggles that occluded vision: (1) prior to PO (forcing use of online-VSI), (2) after PO (forcing use of stored-VSI), or (3) not at all (normal-VSI). Subjects stood behind a barrier in which the location of a narrow slot, through which the foot had to be moved during forward step reactions, was varied unpredictably between trials. Within subjects who were able to do the task (6 of 8 young adults tested), responses in stored-VSI and normal-VSI trials were very similar. However, in online-VSI trials, the foot-off time for the step through the slot was delayed (by approximately 50 ms, on average). Presumably, this delay allowed more time to acquire and process online-VSI regarding the required foot trajectory, yet subjects were still more likely to select the "wrong" foot (contralateral to the slot location) and to contact the barrier while moving the foot through the slot, in online-VSI trials. These results suggest a critical role for stored-VSI during the earliest phase of the step, in selecting the step limb and planning the initial trajectory. Online acquisition and processing of the required VSI may be too slow to allow effective control of this early phase, particularly in situations where the demands for accurate foot motion are high.