Related Experiment Video
Updated: Feb 5, 2026

Providing Meaningful Environmental Enrichment and Measuring Saliva Cortisol in Pigs Housed on Slatted Flooring
Published on: September 30, 2019
Abrasions and lameness in piglets born in different farrowing systems with different types of floor
Mate Zoric1, Ebba Nilsson, Sigbrit Mattsson
1National Veterinary Institute, SVA, 751 89 Uppsala, Sweden. Mate.Zoric@sva.se

Background:
The quality of the floor is essential to the welfare of piglets as abrasions often are recorded in newborn piglets, and such lesions may lead to lameness. Apart from animal suffering, lameness contributes to losses in form of dead piglets, decreased growth, and increased use of antibiotics and manual labour.
Methods:
In a herd with three different farrowing systems, 37 litters (390 piglets) were studied until the age of 3 weeks with respect to presence of skin wounds and abrasions. Lameness was registered until the age of 7 weeks. Eight lame piglets were sacrificed before medical treatment and subjected to necropsy including histopathological and microbiological examinations. Isolates of streptococci, staphylococci and E. coli were tested with respect to antimicrobial resistance. Mastitis was observed in ten sows.
Results:
The most severe abrasions at carpus and soles were seen in the system with a new solid concrete floor with a slatted floor over the dunging area. The lowest magnitude was observed in the deep litter system with peat. Sole bruising was more common in the systems with concrete floor compared to the deep litter system with peat, and the differce in prevalence was significant at all examination days. The lesions decreased with time and about 75% of the treatments for lameness were performed during the first three weeks of life. The overall prevalence of lameness was highest in the system with new solid concrete floor with a slatted floor over the dunging area (9.4%) followed by the old solid concrete floor (7.5%). A lower (p < 0.05) prevalence was seen in the deep litters system with peat (3.3%). No significant relationship between mastitis and abrasions or lameness in the offspring was observed.
Conclusion:
There were large differences in the prevalence of abrasions and lameness between the floor types. The deep litter system with peat provided a soft and good floor for piglets. The overall prevalence of lameness was only diagnosed in every fourth litter in that system compared to in every second litter in the systems with concrete floor. In contrast, the incidence of mastitis in the sows during the first week after farrowing was higher than in the systems with concrete floor.
Related Concept Videos
 02:44
The Born-Haber Cycle
 01:23
Abrasion Resistance of Concrete
One such test is the revolving disc test, where three plates...
 01:26
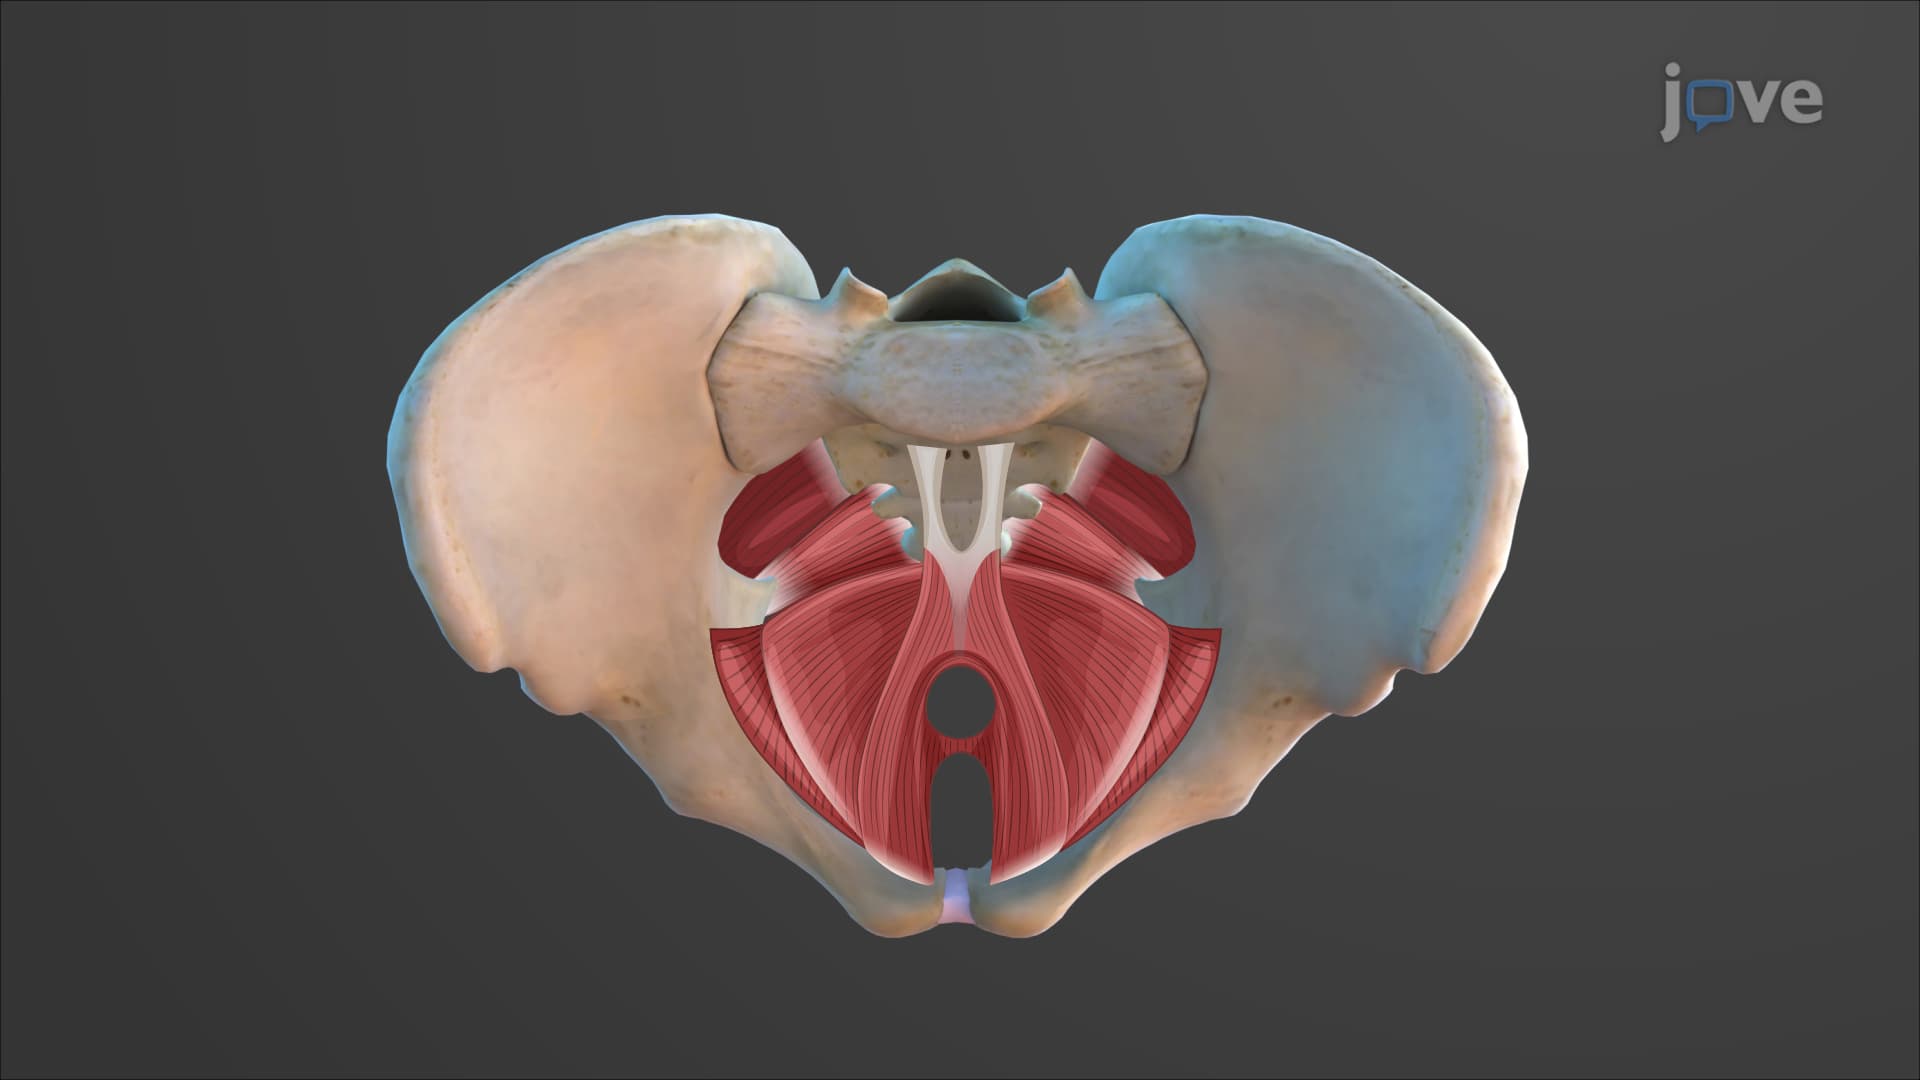
Muscles of the Pelvic Floor and Perineum
Perineal Layer
The perineum is a diamond-shaped area below the pelvic diaphragm, divided into an anterior urogenital triangle that contains the external genitals and a posterior anal triangle housing the anus. The urogenital...
 01:18
Second Order systems II
 01:21
First Order Systems
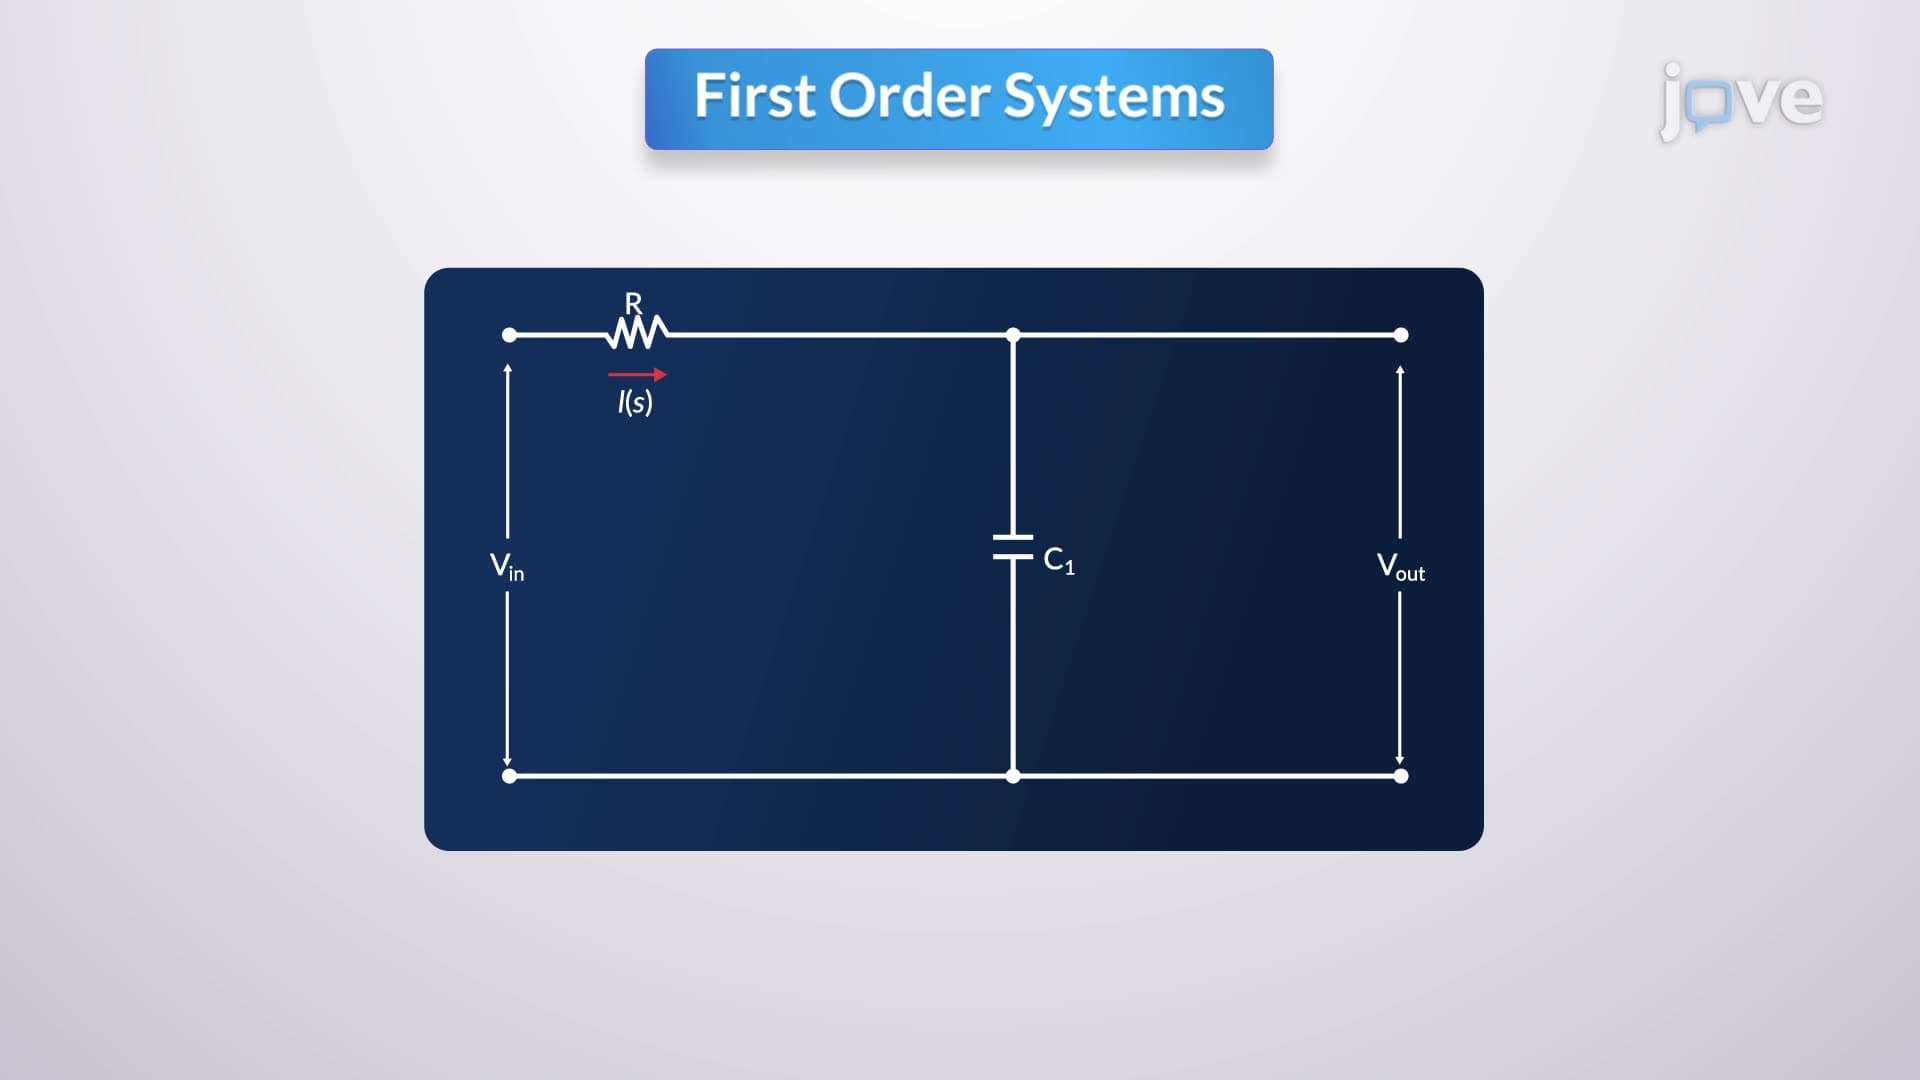
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:20
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...