Sensitivity for reverse-phi motion
Related Experiment Video
Updated: Jun 29, 2026
Quantification of Visual Feature Selectivity of the Optokinetic Reflex in Mice
Published on: June 23, 2023
Roger J E Bours1, Marijn C W Kroes, Martin J Lankheet
1Functional Neurobiology & Helmholtz Institute, Utrecht University, Padualaan 8, 3584 CH Utrecht, The Netherlands.

Abstract:
Low-level contrast information in the primary visual pathway is represented in two different channels. ON-center cells signal positive contrasts and OFF-center cells signal negative contrasts. In this study we address the question whether initial motion analysis is performed separately in these two channels, or also through combination of signals from ON and OFF cells. We quantitatively compared motion coherence detection for regular and for reverse-phi motion stimuli. In reverse-phi motion the contrast of a pattern flips during displacements. Sensitivity is therefore based on correlating positive and negative contrasts, whereas for regular motion it is based on correlating similar contrasts. We compared tuning curves for step size and temporal interval for stimuli in which motion information was limited to a single combination of step size and interval. Tuning for step size and temporal interval was highly similar for the two types of motion. Moreover, minimal coherence thresholds for both types of motion matched quantitatively, irrespective of dot density. We also measured sensitivity for so-called no-phi motion stimuli, in which the contrast of displaced dots was set to zero. Sensitivity for no-phi motion was low for stimuli containing only black or only white dots. When both dot polarities were present in the stimulus, sensitivity was absent. Thus, motion information based on separate contrasts was effectively cancelled by a component based on different contrasts. Together these results show equal efficiency in correlating dots of opposite contrast and of similar contrast, which strongly suggests efficient detection of correlations across ON and OFF channels.
More Related Videos
Related Concept Videos
 01:30
Derivatives of Inverse Trigonometric Functions
 01:17
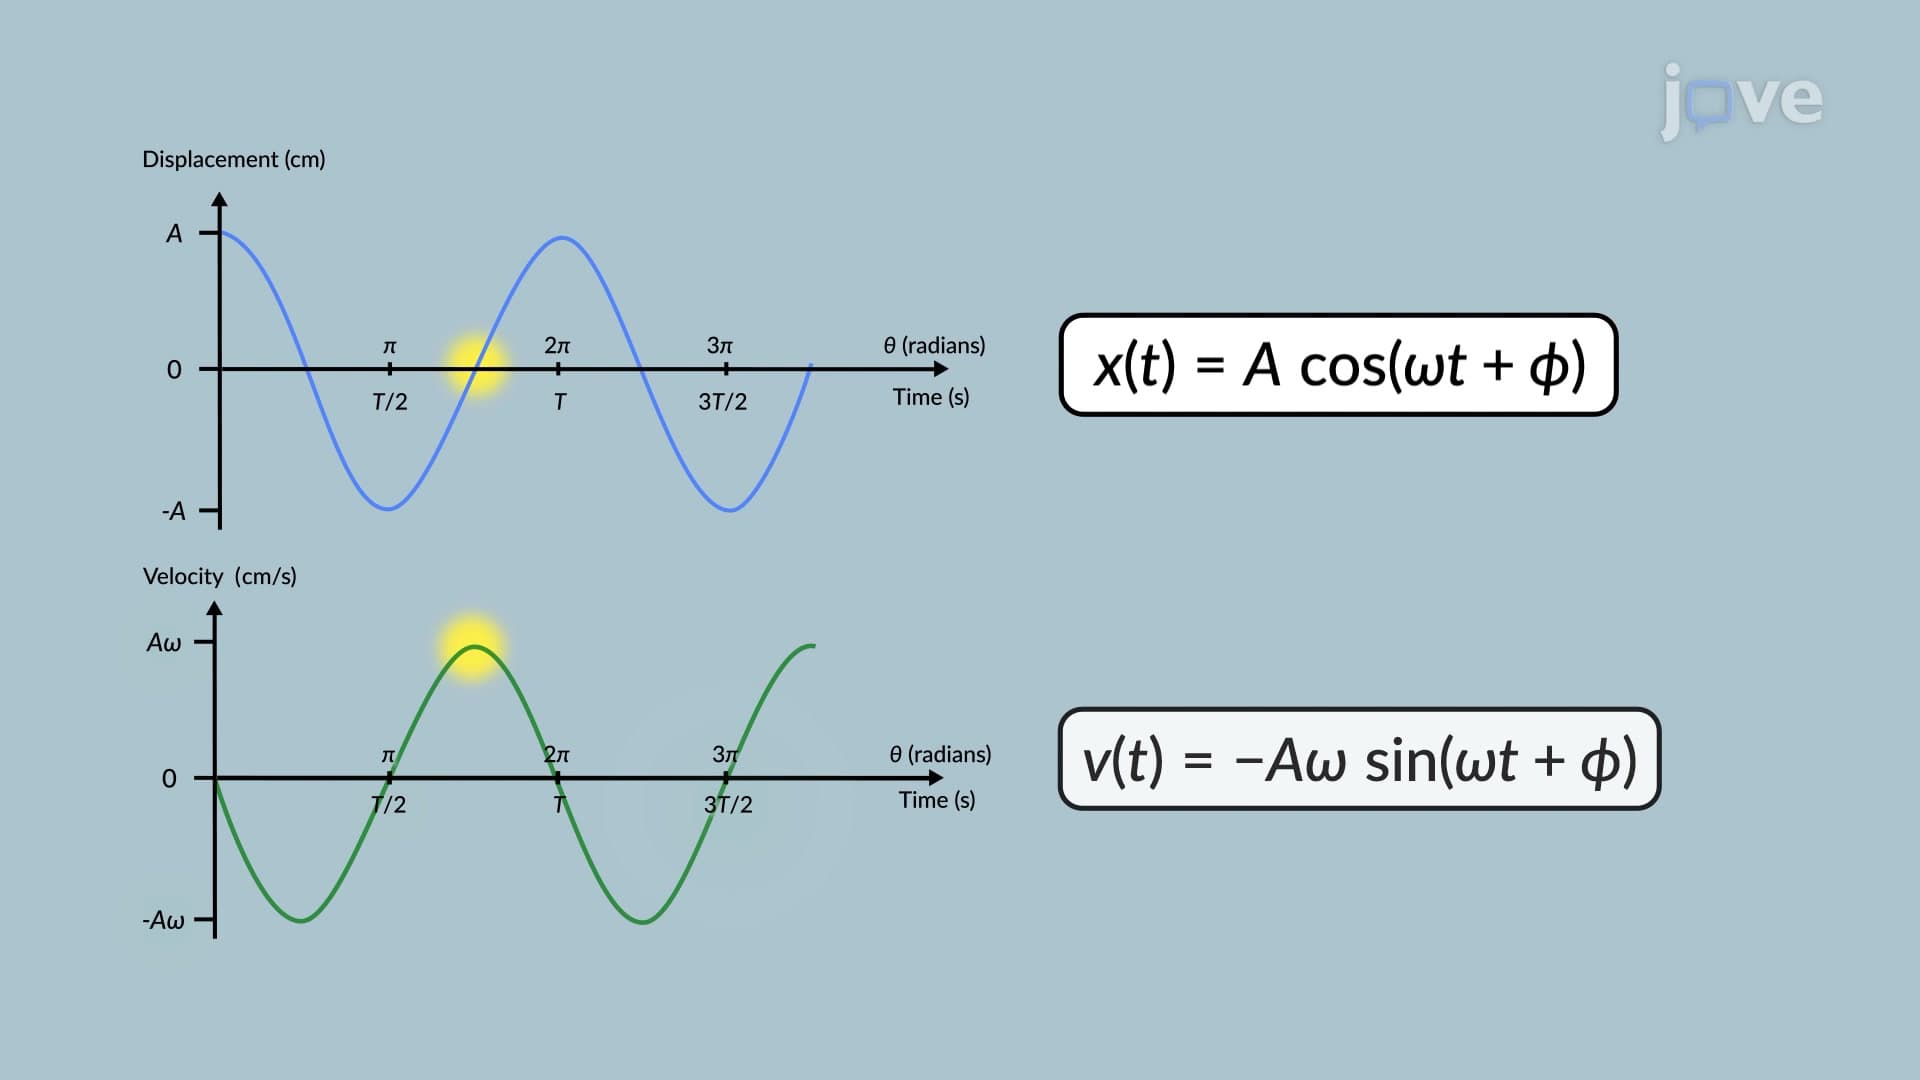
Characteristics of Simple Harmonic Motion
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...